 Repository
 Open source
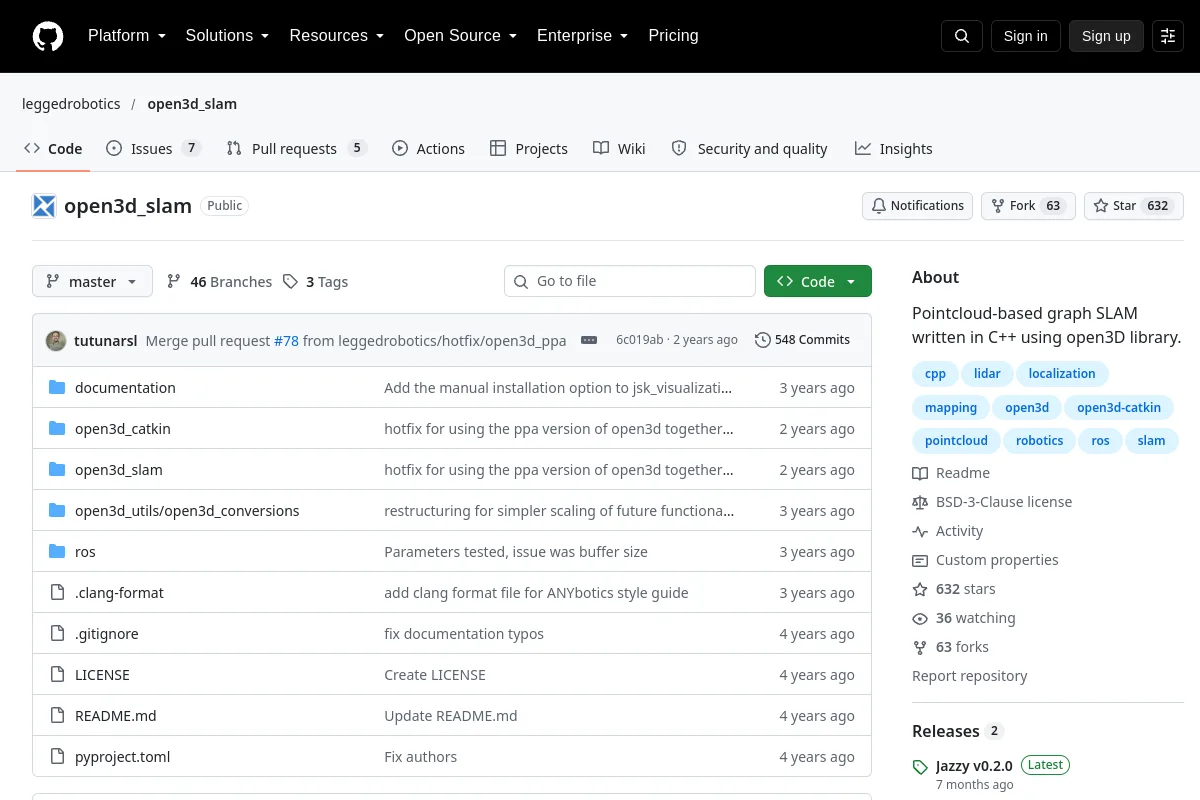
open3d_slam · leggedrobotics
Pointcloud-based graph SLAM written in C++ using open3D library.
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Explore mapping, localization, odometry and navigation software for autonomous robots.
Repository
Open source
Pointcloud-based graph SLAM written in C++ using open3D library.
Navigation & SLAM Repository
 Research
Safety-critical controllers for single/multi robotic navigation: CBF-QP, MPC-CBF, and etc.
Navigation & SLAM Repository
 Research
Official repo of "BEVBert: Multimodal Map Pre-training for Language-guided Navigation"
Navigation & SLAM Repository
 Repository
 Open source
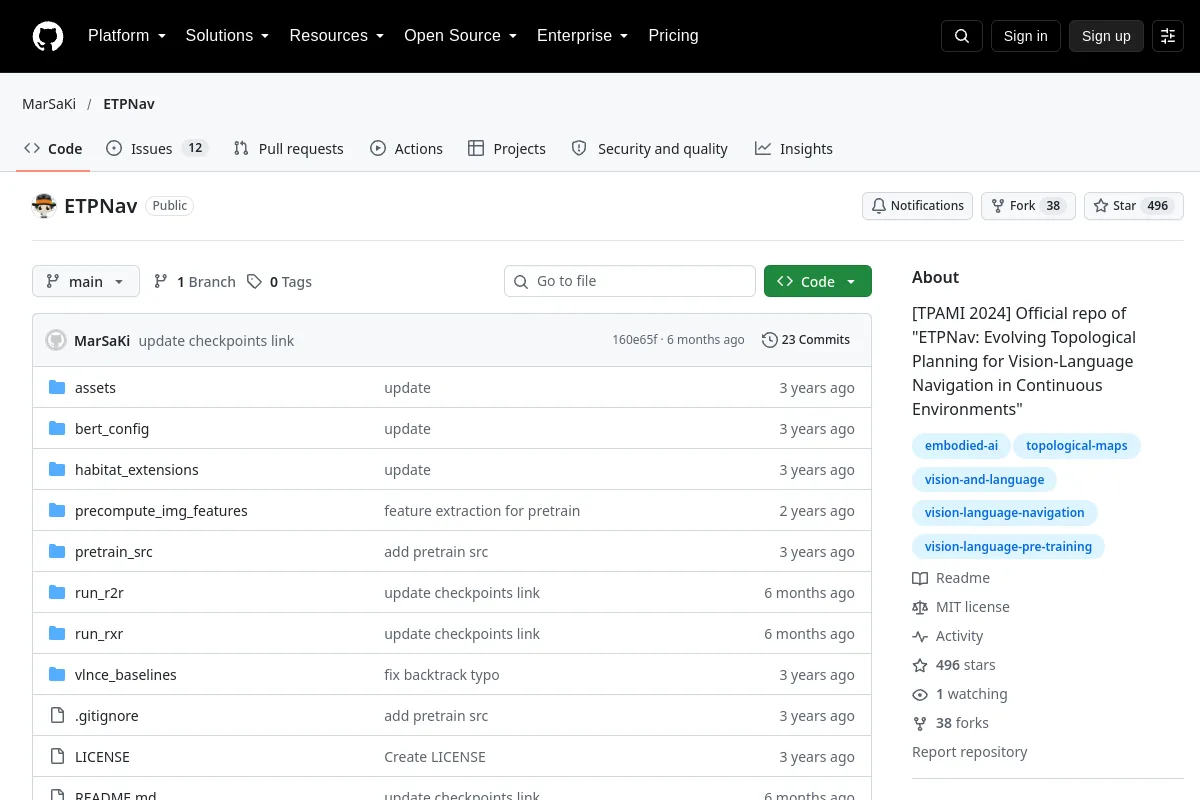
Official repo of "ETPNav: Evolving Topological Planning for Vision-Language Navigation in Continuous Environments"
Navigation & SLAM Repository
 Repository
 Open source
A collection of GTSAM factors and optimizers for point cloud SLAM
Navigation & SLAM Repository
 Open source
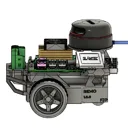
DiffBot is an autonomous 2wd differential drive robot using ROS Noetic on a Raspberry Pi 4 B. With its SLAMTEC Lidar and the ROS Control hardware interface it's capable of navigating in an…
Navigation & SLAM Repository
 Open source
Point-SLAM: Dense Neural Point Cloud-based SLAM
Navigation & SLAM Repository
 Open source
Ultra-Fusion: A Resilient Tightly-Coupled Multi-Sensor Fusion SLAM Framework under Sensor Degradation and Spatiotemporal Perturbation
Navigation & SLAM Repository
 Research
Deep Reinforcement Learning for mobile robot navigation in IR-SIM simulation. Using DRL (SAC, TD3, PPO, DDPG) neural networks, a robot learns to navigate to a random goal point in a simulated…
Navigation & SLAM Repository
 Open source
Active Neural SLAM code for learning to explore environments.
Navigation & SLAM Repository
 Open source
Leg-KILO: Robust Kinematic-Inertial-Lidar Odometry for Dynamic Legged Robots
Navigation & SLAM Repository
 Research
Robust LiDAR SLAM with a versatile plug-and-play loop closing and pose-graph optimization.
Navigation & SLAM Repository
 Open source
Code and Data of the CVPR 2022 paper: Bridging the Gap Between Learning in Discrete and Continuous Environments for Vision-and-Language Navigation
Navigation & SLAM Repository
 Open source
An Optimization-Based GNSS/INS Integrated Navigation System
Navigation & SLAM Repository
 Research
 code for mapping multimodal instructions to robotic actions.
Navigation & SLAM Repository
 Open source
Deep Reinforcement Learning for mobile robot navigation in ROS2 Gazebo simulator. Using DRL (SAC, TD3) neural networks, a robot learns to navigate to a random goal point in a simulated environment…
Navigation & SLAM Repository
 Open source
Edge deployment guide for InternNav-based perception and navigation on Unitree Go2 / Go2W / B2 robots (ROS 2, RealSense, Python).
Navigation & SLAM Repository
 Open source
A Python-based lightweight robot simulator designed for navigation, control, and learning
Navigation & SLAM Repository
 Open source
Tightly coupled GNSS-Visual-Inertial system for locally smooth and globally consistent state estimation in complex environment.
Navigation & SLAM Repository
 Open source
KISS-Matcher: Fast, Robust, and Scalable Registration + ROS2 SLAM examples
Navigation & SLAM Repository
 Repository
 Research
Intensity Scan Context based full SLAM implementation for autonomous driving. ICRA 2020
Navigation & SLAMSELECTION NOTES
Match sensors, coordinate frames and localization assumptions to the deployment environment. Mapping, pose estimation, path planning and obstacle avoidance serve different parts of the navigation stack.
Know a resource that belongs here?