 Repository
 Research
NVIDIA Cosmos
World-model resources for physical AI and synthetic-data workflows.
World modelsTHE EMBODIED AI DIRECTORY
Explore predictive and generative world-model resources for physical AI and robot planning.
Repository
Research
World-model resources for physical AI and synthetic-data workflows.
World models Repository
 Research
Repository for our papers: Robotic World Model: A Neural Network Simulator for Robust Policy Optimization in Robotics and Uncertainty-Aware Robotic World Model Makes Offline Model-Based…
World models Repository
 Research
DayDreamer provides world-model methods for physical robot learning.
World models Repository
 Repository
 Research
DreamDojo studies robot world models learned from human video data.
World models Repository
 Research
Official Implementation for the paper "SR-AIF: Solving Sparse-Reward Robotic Tasks from Pixels with Active Inference and World Models"
World models Website
 Repository
 Repository
 Research
A unified framework for training, fine-tuning, and evaluating World Action Models
World models Repository
 Research
ICCV 2025 | TesserAct: Learning 4D Embodied World Models
World models Repository
 Research
Code for RISE: Self-Improving Robot Policy with Compositional World Model
World models Repository
 Research
A world-model-enhanced VLA for steerable dexterous manipulation, along with optimized training infra.
World models Repository
 Research
Lightweight implementation of Robotic World Model (RWM) and Uncertainty-Aware Robotic World Model (RWM-U)
World models Repository
 Research
ACOT-VLA-WM is an advanced Vision-Language-Action robotics framework that uses a predictive world model to generate visual subgoals, improving long-horizon robotic manipulation accuracy and…
World models Repository
 Repository
 Research
C³-JEPA studies a multi-view world model for underwater ROV salvage.
World models Repository
 Research
Official code and data from DexWM ("World Models Can Leverage Human Videos for Dexterous Manipulation").
World models Repository
 Research
DreamX-Phi provides an action-conditioned video world model for robotic manipulation.
World models Repository
 Research
Ego-World JEPA studies ego/world latent factorization for planning on PushT.
World models Repository
 Research
Official Implementation of "EVA: Aligning Video World Models with Executable Robot Actions via Inverse Dynamics Rewards"
World models Repository
 Research
EVEWorld studies physical-evolution supervision and temporal consistency in embodied world models.
World models Repository
 Research
Towards Scalable Gaussian World Models for Robotic Manipulation
World models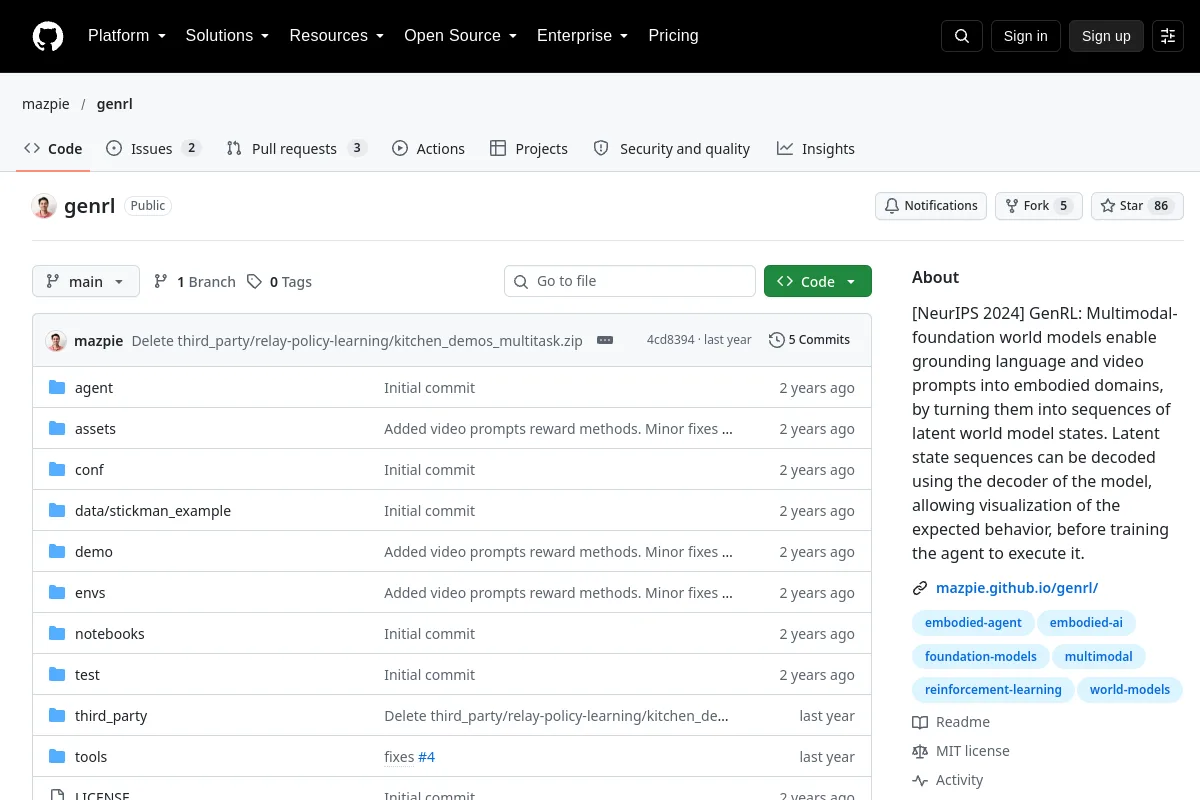 Repository
 Research
GenRL: Multimodal-foundation world models enable grounding language and video prompts into embodied domains, by turning them into sequences of latent world model states. Latent state sequences can…
World models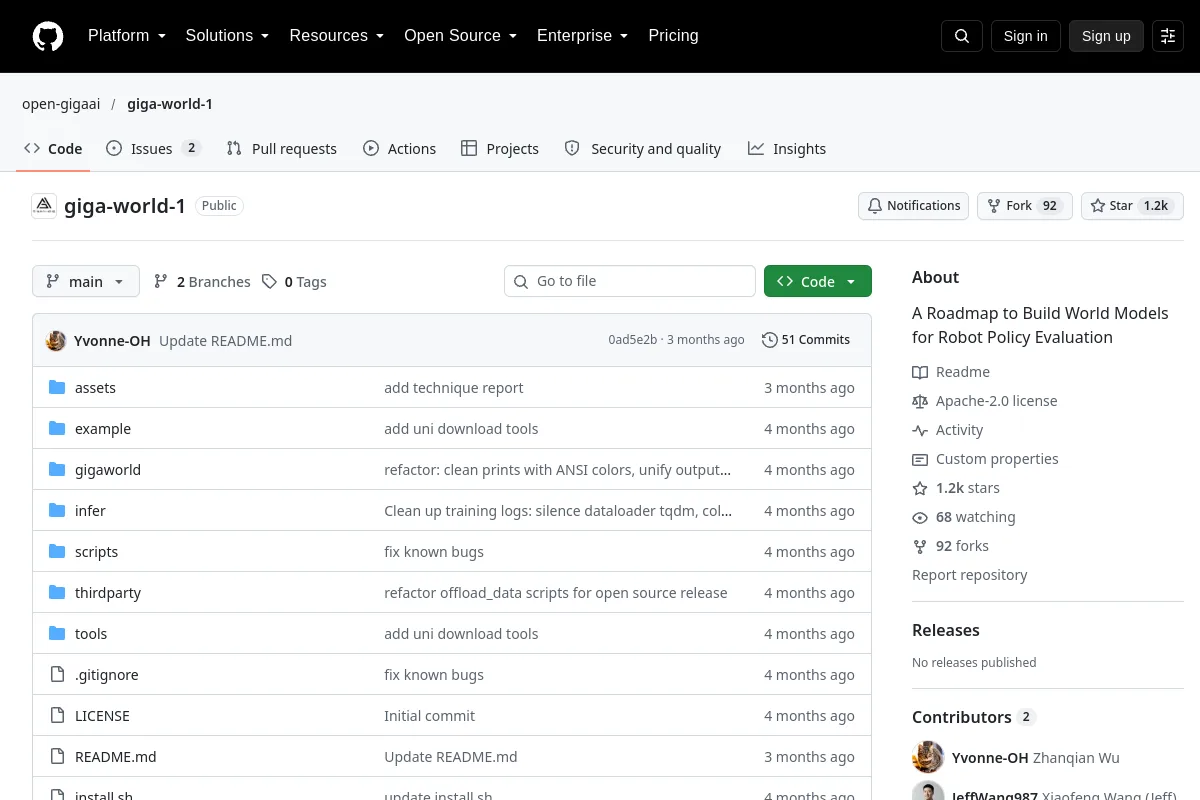 Repository
 Research
A Roadmap to Build World Models for Robot Policy Evaluation
World modelsSELECTION NOTES
Distinguish generated visual futures from validated physical dynamics. Review conditioning inputs, rollout horizon and evaluation protocols before treating predictions as executable plans.
Know a resource that belongs here?