 Repository
 Open source
NVIDIA Isaac Lab
Robot learning tools built around the Isaac simulation ecosystem.
Simulation & physics
Models / Research
Repository for our papers: Robotic World Model: A Neural Network Simulator for Robust Policy Optimization in Robotics and Uncertainty-Aware Robotic World Model Makes Offline Model-Based…
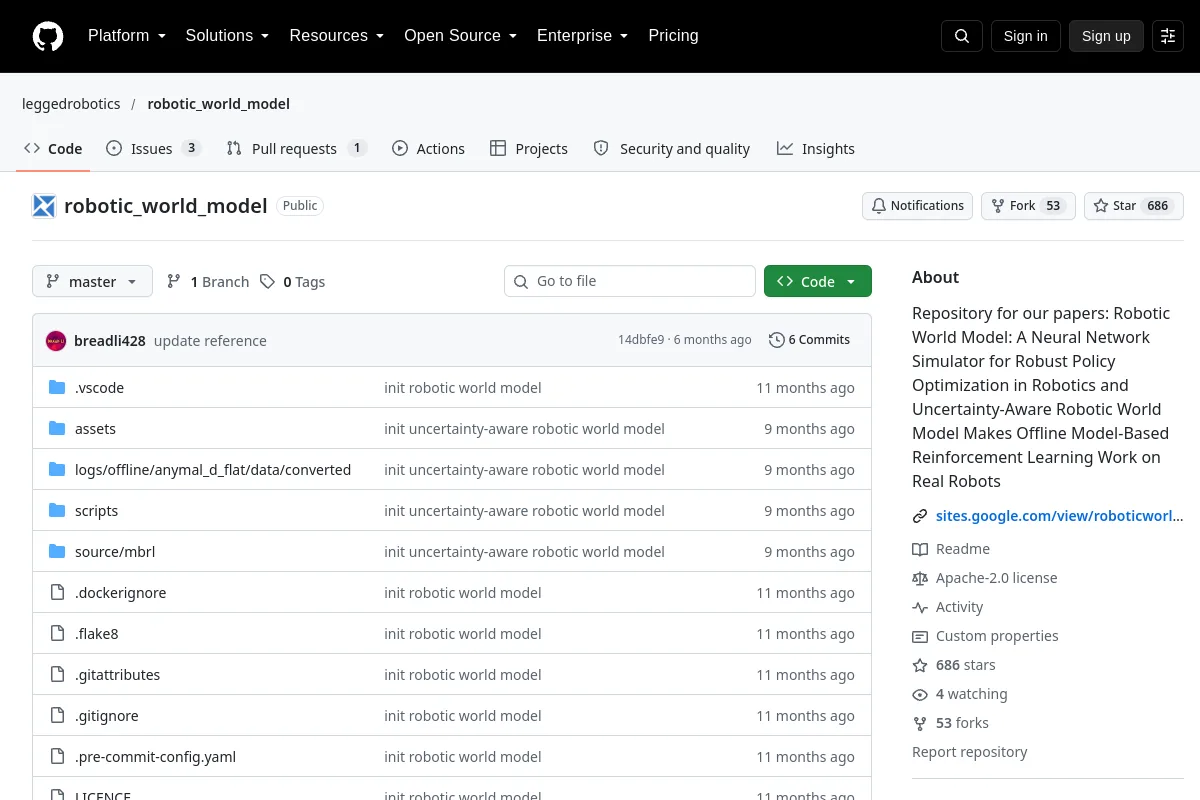
Repository for our papers: Robotic World Model: A Neural Network Simulator for Robust Policy Optimization in Robotics and Uncertainty-Aware Robotic World Model Makes Offline Model-Based…
Publisher purpose: Repository for our papers: Robotic World Model: A Neural Network Simulator for Robust Policy Optimization in Robotics and Uncertainty-Aware Robotic World Model Makes Offline Model-Based Reinforcement Learning Work on Real Robots
Review observation/action interfaces, checkpoints, robot embodiments and adaptation requirements. Repository code licensing does not automatically license weights or training data.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
Robot learning tools built around the Isaac simulation ecosystem.
Simulation & physics