 Repository
 Research
HAIC · ldt29
HAIC: Humanoid Agile Object Interaction Control via Dynamics-Aware World Model
World modelsTHE EMBODIED AI DIRECTORY
Explore predictive and generative world-model resources for physical AI and robot planning.
Repository
Research
HAIC: Humanoid Agile Object Interaction Control via Dynamics-Aware World Model
World models Repository
 Research
Official Implementation of "Kinema4D: Kinematic4D World Modeling for Spatiotemporal Embodied Simulation"
World models Repository
 Research
LiLa-WAM: Lightweight Latent Reasoning World-Action Model for Robotic Manipulation
World models Repository
 Research
Source codes for the paper "MindJourney: Test-Time Scaling with World Models for Spatial Reasoning"
World models Repository
 Research
MotuBrain: An Advanced World Action Model for Robot Control
World models Repository
 Research
Official implementation of NavMorph: A Self-Evolving World Model for Vision-and-Language Navigation in Continuous Environments (ICCV'25).
World models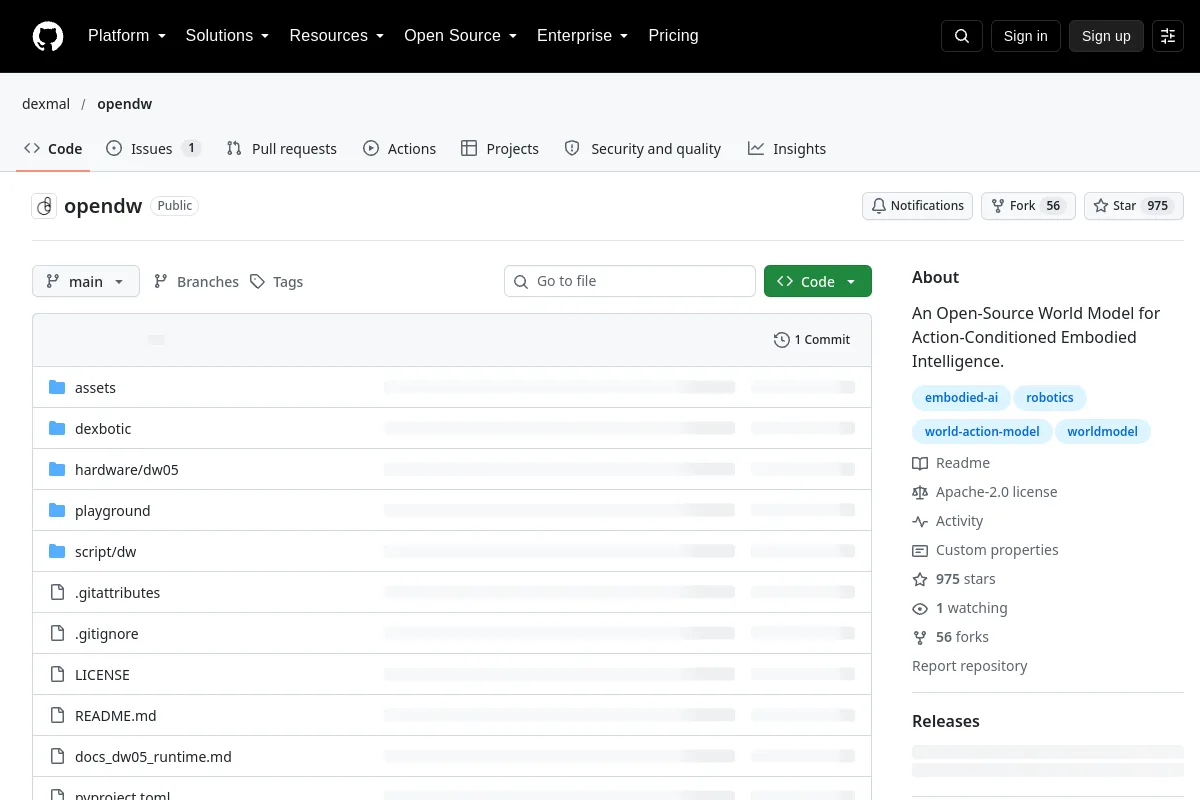 Repository
 Research
OpenDW provides an action-conditioned world-model project for embodied intelligence.
World models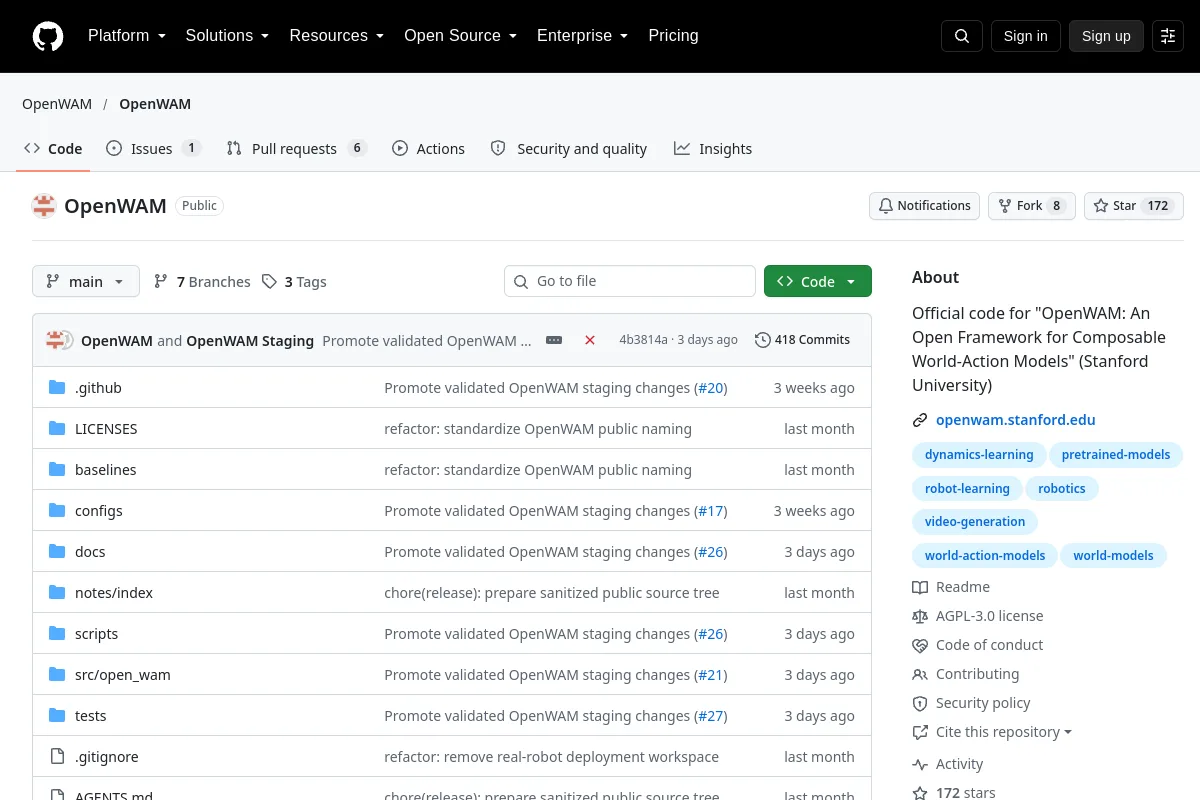 Repository
 Research
Official code for "OpenWAM: An Open Framework for Composable World-Action Models" (Stanford University)
World models Repository
 Research
PointWorld studies 3D world models for robotic manipulation.
World models Repository
 Research
RynnWorld-4D: 4D Embodied World Models for Robotic Manipulation
World models Repository
 Research
repository for training action-conditioned latent diffusion world models for robot video generation
World models Repository
 Research
Offical implementation of ICLR'26 paper "Empowering Multi-Robot Cooperation via Sequential World Models"
World models Repository
 Research
UnifoLM-WMA-0: A World-Model-Action (WMA) Framework under UnifoLM Family
World models Repository
 Research
WAVE-Go: Go2-W world-model action adaptation, verified mapless charging, and Cosmos3-Edge hybrid long-range navigation demos
World models Repository
 Research
WMNav: Integrating Vision-Language Models into World Models for Object Goal Navigation
World models Repository
 Research
WoW (World-Omniscient World Model) is a generative world model trained on 2 million robotic interaction trajectories, designed to imagine, reason, and act in the physical world. Unlike passive…
World modelsSELECTION NOTES
Distinguish generated visual futures from validated physical dynamics. Review conditioning inputs, rollout horizon and evaluation protocols before treating predictions as executable plans.
Know a resource that belongs here?