 Repository
 Open source
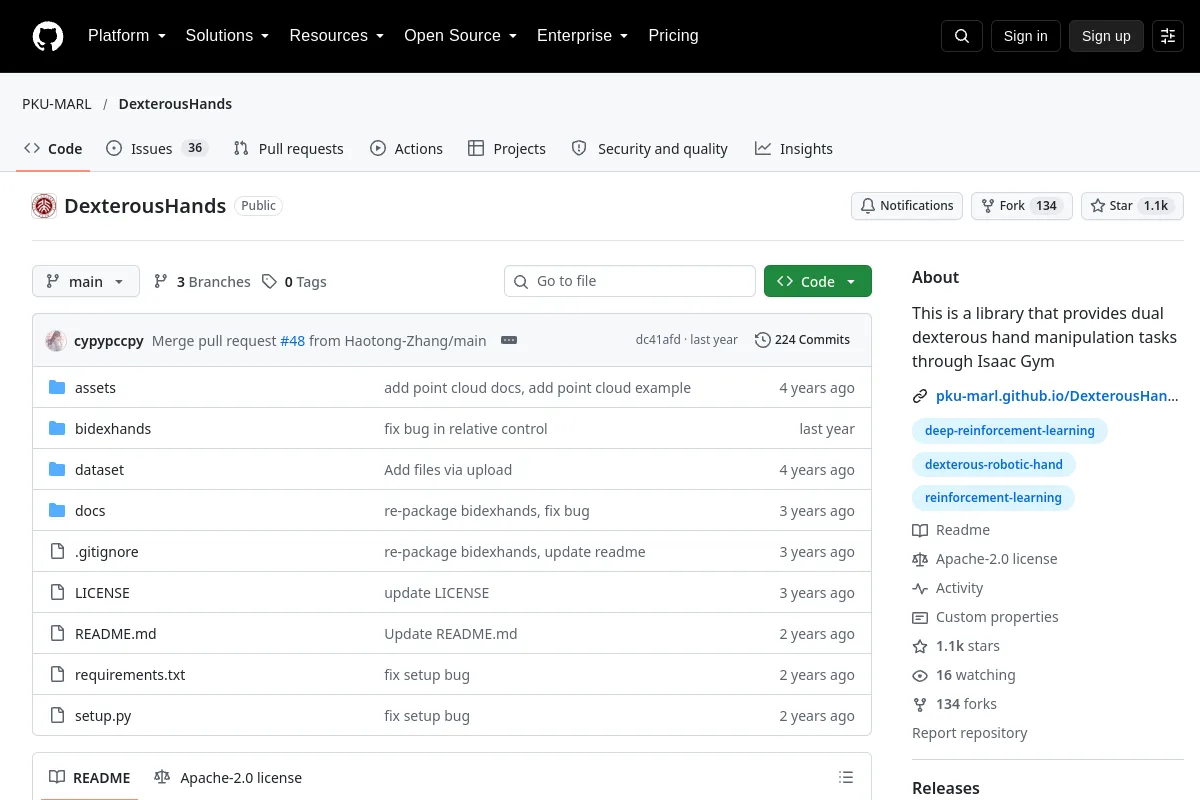
DexterousHands · PKU-MARL
This is a library that provides dual dexterous hand manipulation tasks through Isaac Gym
Robot learning frameworks
Models / Research
Offical implementation of ICLR'26 paper "Empowering Multi-Robot Cooperation via Sequential World Models"
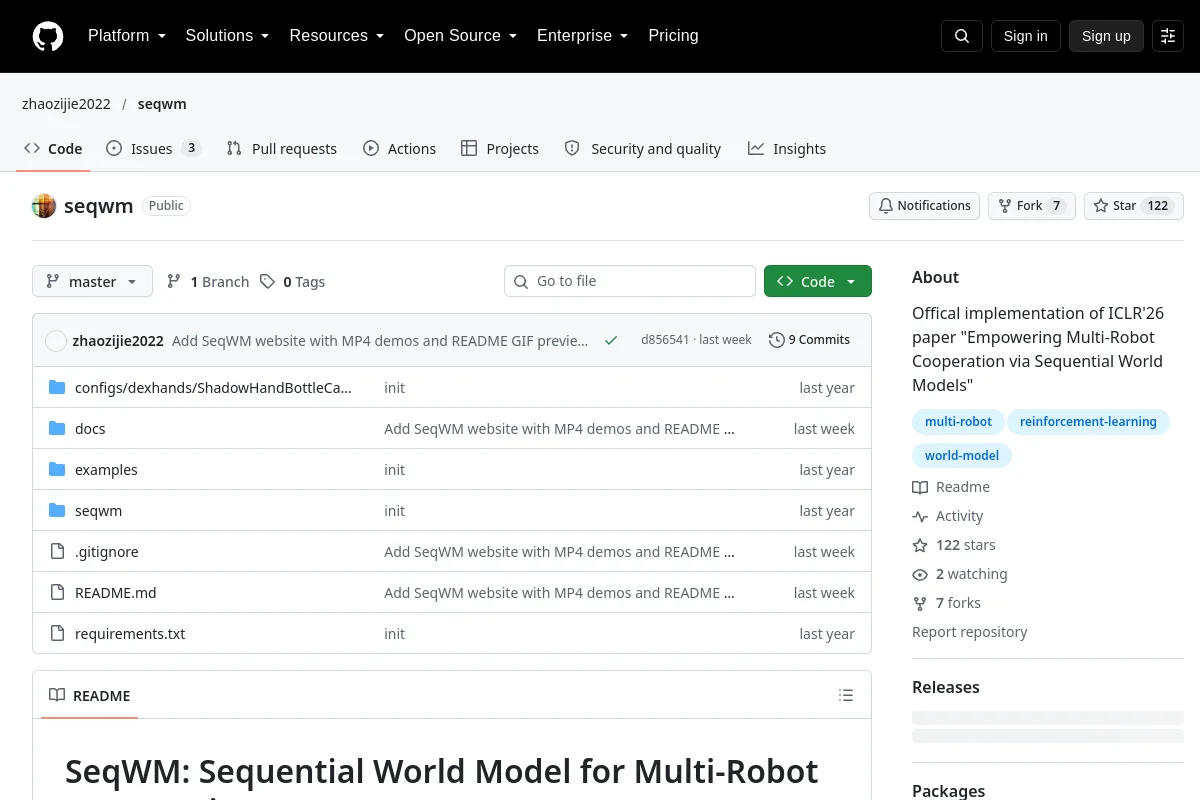
Offical implementation of ICLR'26 paper "Empowering Multi-Robot Cooperation via Sequential World Models"
Review observation/action interfaces, checkpoints, robot embodiments and adaptation requirements. Repository code licensing does not automatically license weights or training data.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
This is a library that provides dual dexterous hand manipulation tasks through Isaac Gym
Robot learning frameworks