 Repository
 Open source
Ground-Fusion · SJTU-ViSYS
Ground-Fusion: A Low-cost Ground SLAM System Robust to Corner Cases (ICRA2024)
Navigation & SLAM
Software / Open source
Ultra-Fusion: A Resilient Tightly-Coupled Multi-Sensor Fusion SLAM Framework under Sensor Degradation and Spatiotemporal Perturbation
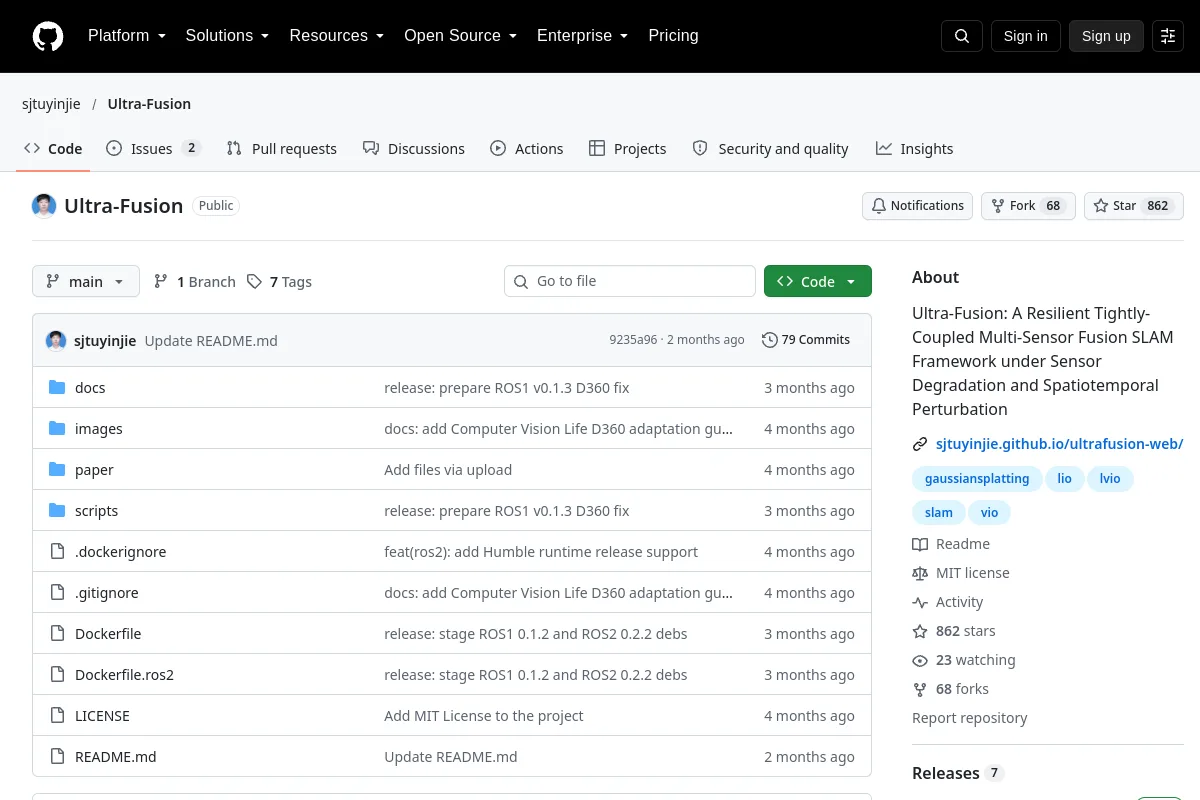
Ultra-Fusion: A Resilient Tightly-Coupled Multi-Sensor Fusion SLAM Framework under Sensor Degradation and Spatiotemporal Perturbation
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
Ground-Fusion: A Low-cost Ground SLAM System Robust to Corner Cases (ICRA2024)
Navigation & SLAM Repository
 Research
M3DGR: A Multi-sensor, Multi-scenario and Massive-baseline SLAM Dataset for Ground Robots(IROS2025)
Robot demonstrations Repository
 Research
Extension and update of M2DGR: a novel Multi-modal and Multi-scenario SLAM Dataset for Ground Robots (ICRA2022 & ICRA2024)
Robot demonstrations Repository
 Research
The GrandTour Dataset: A Legged Robotics Dataset in the Wild
Robot demonstrations