 Repository
 Research
M2DGR · SJTU-ViSYS
M2DGR: a Multi-modal and Multi-scenario Dataset for Ground Robots(RA-L2021 & ICRA2022)
Robot demonstrations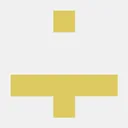
Datasets / Research
Extension and update of M2DGR: a novel Multi-modal and Multi-scenario SLAM Dataset for Ground Robots (ICRA2022 & ICRA2024)
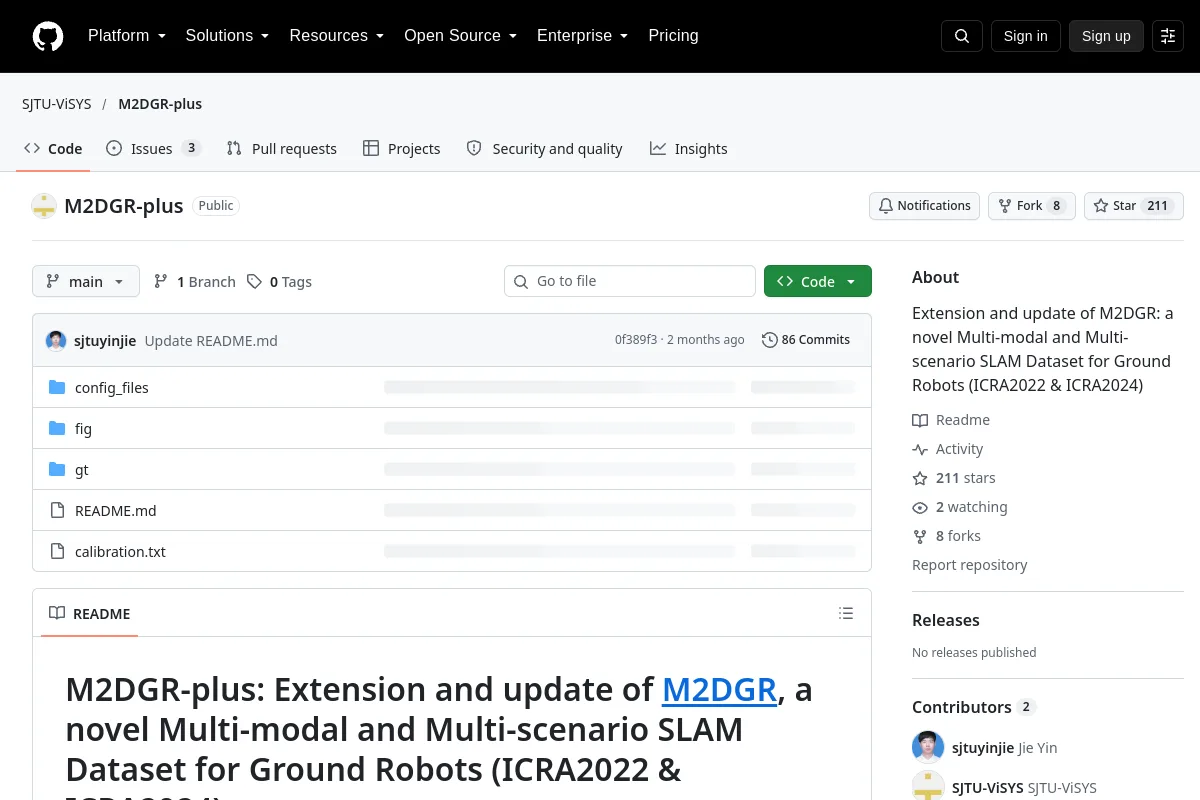
Extension and update of M2DGR: a novel Multi-modal and Multi-scenario SLAM Dataset for Ground Robots (ICRA2022 & ICRA2024)
Review the data card, embodiment, schema, collection conditions and dataset-specific license before use. Data access and fit for a particular training setup need separate confirmation.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
M2DGR: a Multi-modal and Multi-scenario Dataset for Ground Robots(RA-L2021 & ICRA2022)
Robot demonstrations Repository
 Open source
Ground-Fusion: A Low-cost Ground SLAM System Robust to Corner Cases (ICRA2024)
Navigation & SLAM