 Repository
 Research
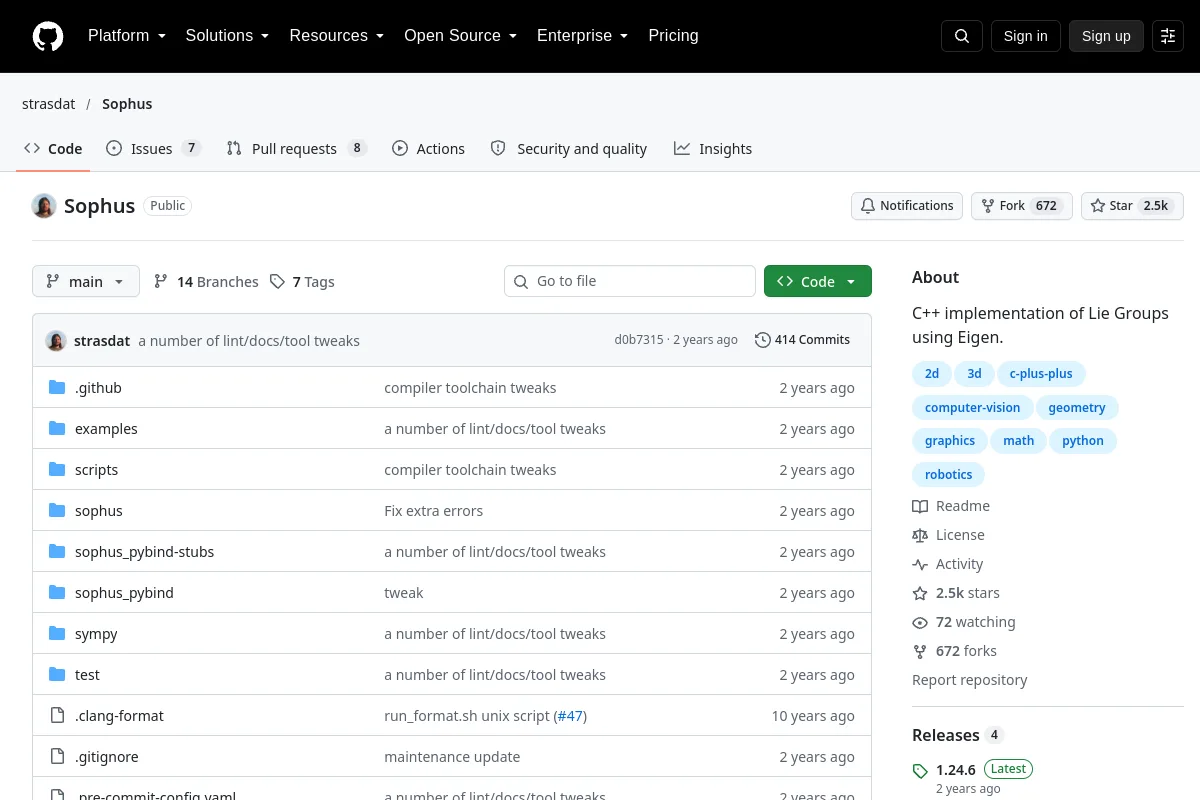
Sophus · strasdat
Eigen-based C++ Lie-group library for geometric computation.
Perception & geometry
Software / Open source
Leg-KILO: Robust Kinematic-Inertial-Lidar Odometry for Dynamic Legged Robots
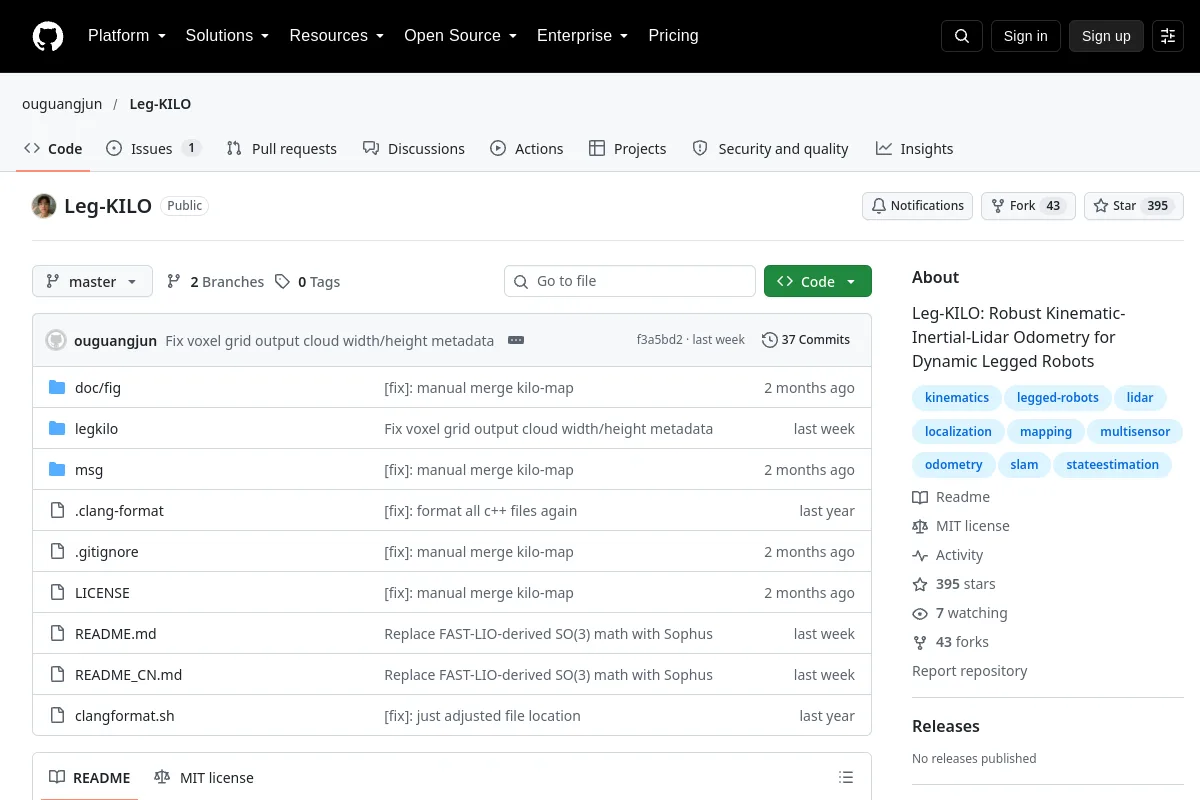
Leg-KILO: Robust Kinematic-Inertial-Lidar Odometry for Dynamic Legged Robots
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Eigen-based C++ Lie-group library for geometric computation.
Perception & geometry Repository
 Research
M3DGR: A Multi-sensor, Multi-scenario and Massive-baseline SLAM Dataset for Ground Robots(IROS2025)
Robot demonstrations Repository
 Research
(ICRA 2025) This repository is the official code for DiTer++: Diverse Terrain and Multi-modal Dataset for Multi-Robot Navigation in Multi-session Outdoor Environments.
Robot demonstrations Repository
 Open source
KISS-Matcher: Fast, Robust, and Scalable Registration + ROS2 SLAM examples
Navigation & SLAM Repository
 Research
a legged robot (Unitree Go1) dataset containing leg kinematics (joint encoders and contact sesors), imu and lidar
Robot demonstrations Repository
 Research
Ready to test your SLAM system in challenging datasets from extreme environments? Try this out! The dataset is provided by the Team CoSTAR that has been intensively testing multi-robot systems in…
Robot demonstrations