 Repository
 Research
example robot data · Gepetto
Example Robot Data collects robot URDF models for benchmarks and examples.
Scene & object assets
Datasets / Research
Ready to test your SLAM system in challenging datasets from extreme environments? Try this out! The dataset is provided by the Team CoSTAR that has been intensively testing multi-robot systems in…
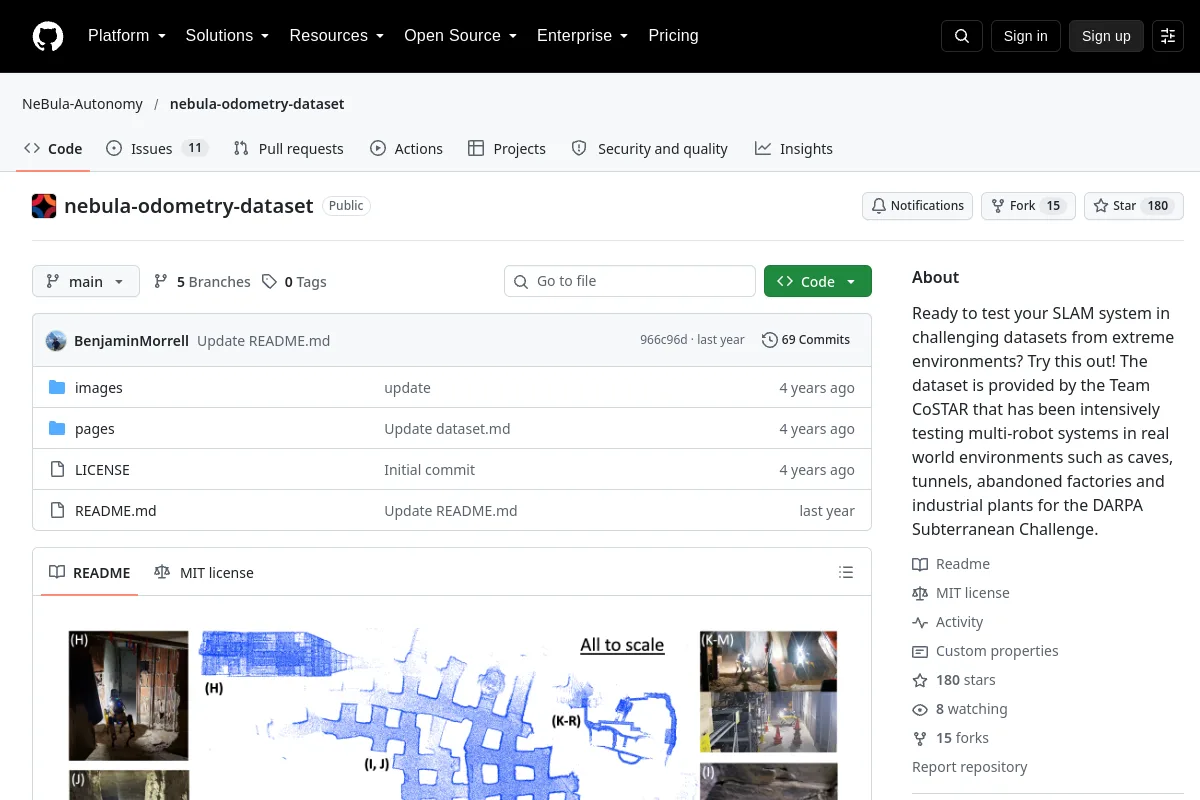
Ready to test your SLAM system in challenging datasets from extreme environments? Try this out! The dataset is provided by the Team CoSTAR that has been intensively testing multi-robot systems in…
Publisher purpose: Ready to test your SLAM system in challenging datasets from extreme environments? Try this out! The dataset is provided by the Team CoSTAR that has been intensively testing multi-robot systems in real world environments such as caves, tunnels, abandoned factories and industrial plants for the DARPA Subterranean Challenge.
Review the data card, embodiment, schema, collection conditions and dataset-specific license before use. Data access and fit for a particular training setup need separate confirmation.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Example Robot Data collects robot URDF models for benchmarks and examples.
Scene & object assets Repository
 Research
Robot model assets for MuJoCo simulation and control experiments.
Scene & object assets Repository
 Research
M2DGR: a Multi-modal and Multi-scenario Dataset for Ground Robots(RA-L2021 & ICRA2022)
Robot demonstrations Repository
 Research
M3DGR: A Multi-sensor, Multi-scenario and Massive-baseline SLAM Dataset for Ground Robots(IROS2025)
Robot demonstrations Repository
 Research
Open-source vacuum cleaner, model One - ROS2 robot description package
Scene & object assets Repository
 Research
ROS2 robot description for Proscenic M6 Pro
Scene & object assets