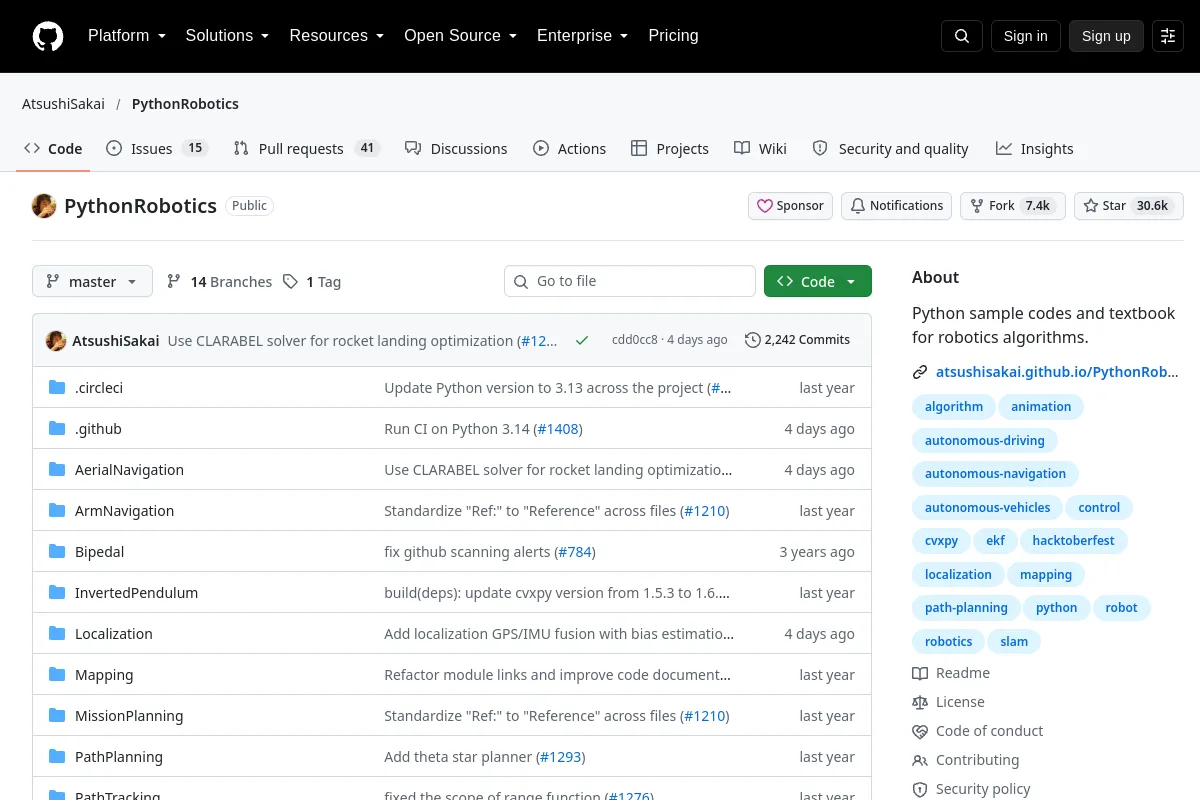
 Repository
 Research
PythonRobotics
Python implementations illustrating robotics algorithms and planning methods.
Navigation & SLAM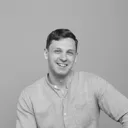
Software / Research
Deep Reinforcement Learning for mobile robot navigation in IR-SIM simulation. Using DRL (SAC, TD3, PPO, DDPG) neural networks, a robot learns to navigate to a random goal point in a simulated…
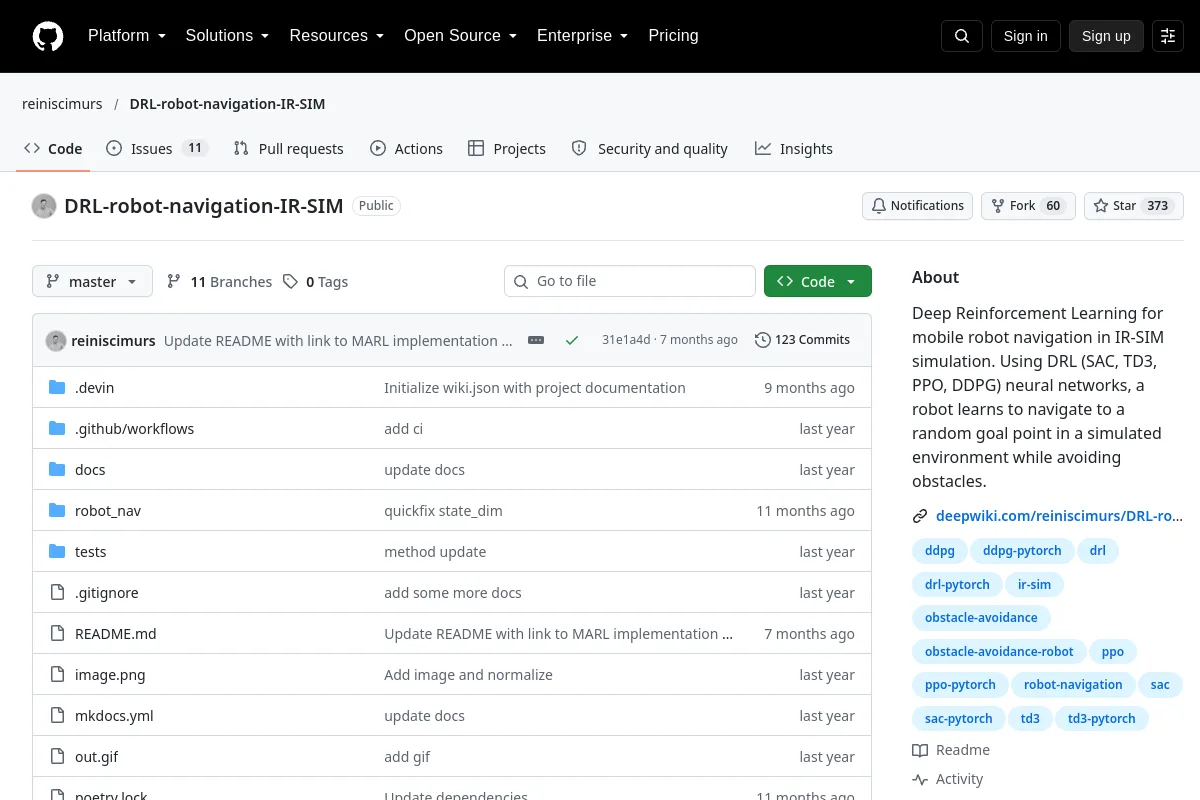
Deep Reinforcement Learning for mobile robot navigation in IR-SIM simulation. Using DRL (SAC, TD3, PPO, DDPG) neural networks, a robot learns to navigate to a random goal point in a simulated…
Publisher purpose: Deep Reinforcement Learning for mobile robot navigation in IR-SIM simulation. Using DRL (SAC, TD3, PPO, DDPG) neural networks, a robot learns to navigate to a random goal point in a simulated environment while avoiding obstacles.
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Python implementations illustrating robotics algorithms and planning methods.
Navigation & SLAM Repository
 Open source
Deep Reinforcement Learning for mobile robot navigation in ROS2 Gazebo simulator. Using DRL (SAC, TD3) neural networks, a robot learns to navigate to a random goal point in a simulated environment…
Navigation & SLAM Repository
 Open source
A Python-based lightweight robot simulator designed for navigation, control, and learning
Navigation & SLAM