 Repository
 Open source
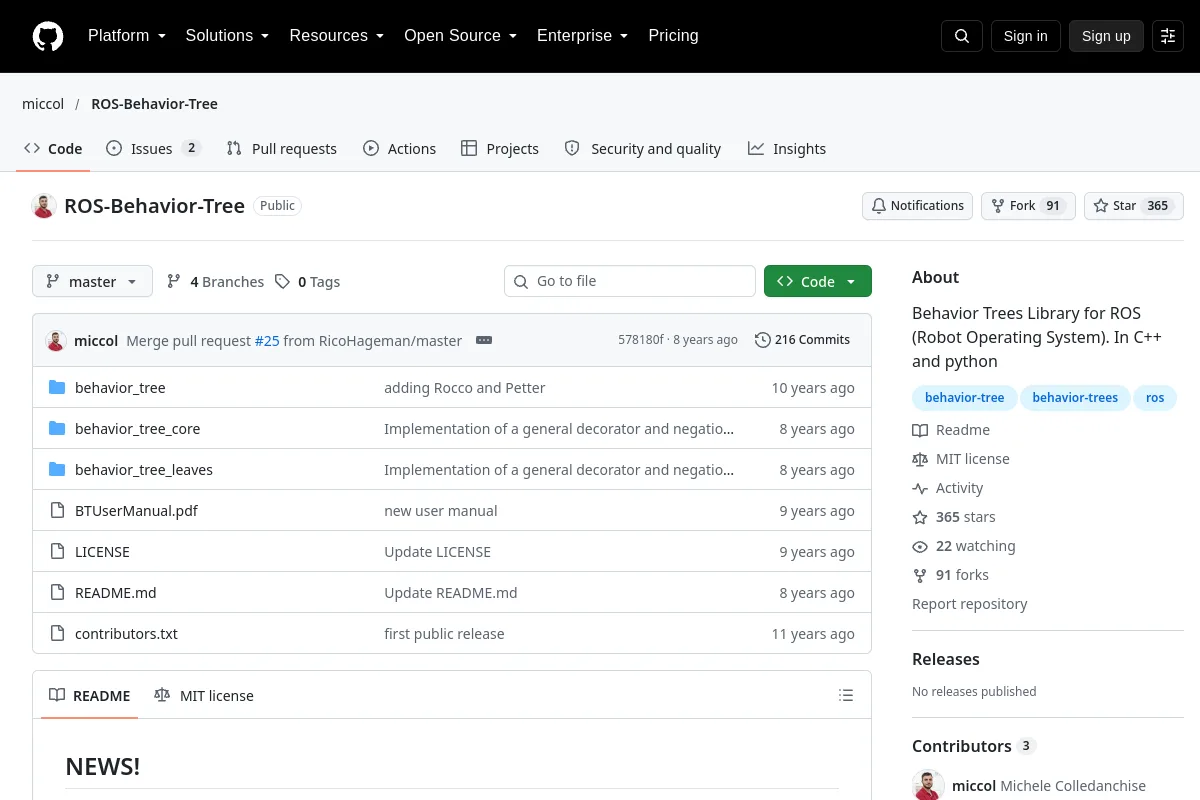
ROS Behavior Tree · miccol
Behavior-tree library for ROS, with C++ and Python interfaces.
Robot learning frameworksTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
Behavior-tree library for ROS, with C++ and Python interfaces.
Robot learning frameworks Repository
 Open source
Active Neural SLAM code for learning to explore environments.
Navigation & SLAM Repository
 Research
ROS 2 driver for the Kinova Gen3 robot arm.
Robot learning frameworks Repository
 Research
Robot model collection for OpenRAVE.
Robot learning frameworks Repository
 Research
Choreonoid simulation integration with ROS and hrpsys tooling.
Simulation & physics Repository
 Open source
Leg-KILO: Robust Kinematic-Inertial-Lidar Odometry for Dynamic Legged Robots
Navigation & SLAM Repository
 Research
Robust LiDAR SLAM with a versatile plug-and-play loop closing and pose-graph optimization.
Navigation & SLAM Repository
 Open source
Code and Data of the CVPR 2022 paper: Bridging the Gap Between Learning in Discrete and Continuous Environments for Vision-and-Language Navigation
Navigation & SLAM Repository
 Research
URDF and SDF models of the iCub humanoid robot.
Simulation & physics Repository
 Open source
Official implementation of "Data Scaling Laws in Imitation Learning for Robotic Manipulation"
Robot learning frameworks Repository
 Open source
🦀 Appearance and scene design for Jumper, an open-source crab robot.
Robot learning frameworks Repository
 Open source
An Optimization-Based GNSS/INS Integrated Navigation System
Navigation & SLAM Repository
 Research
 code for mapping multimodal instructions to robotic actions.
Navigation & SLAM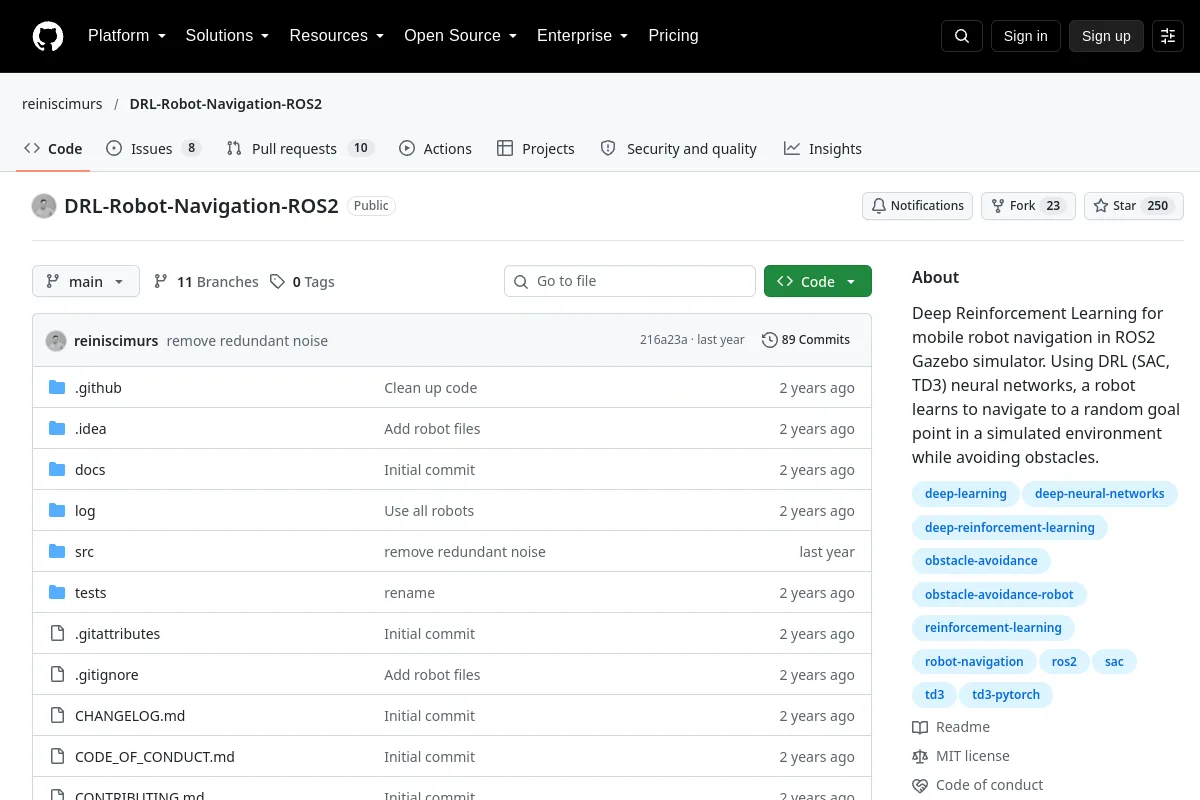 Repository
 Open source
Deep Reinforcement Learning for mobile robot navigation in ROS2 Gazebo simulator. Using DRL (SAC, TD3) neural networks, a robot learns to navigate to a random goal point in a simulated environment…
Navigation & SLAM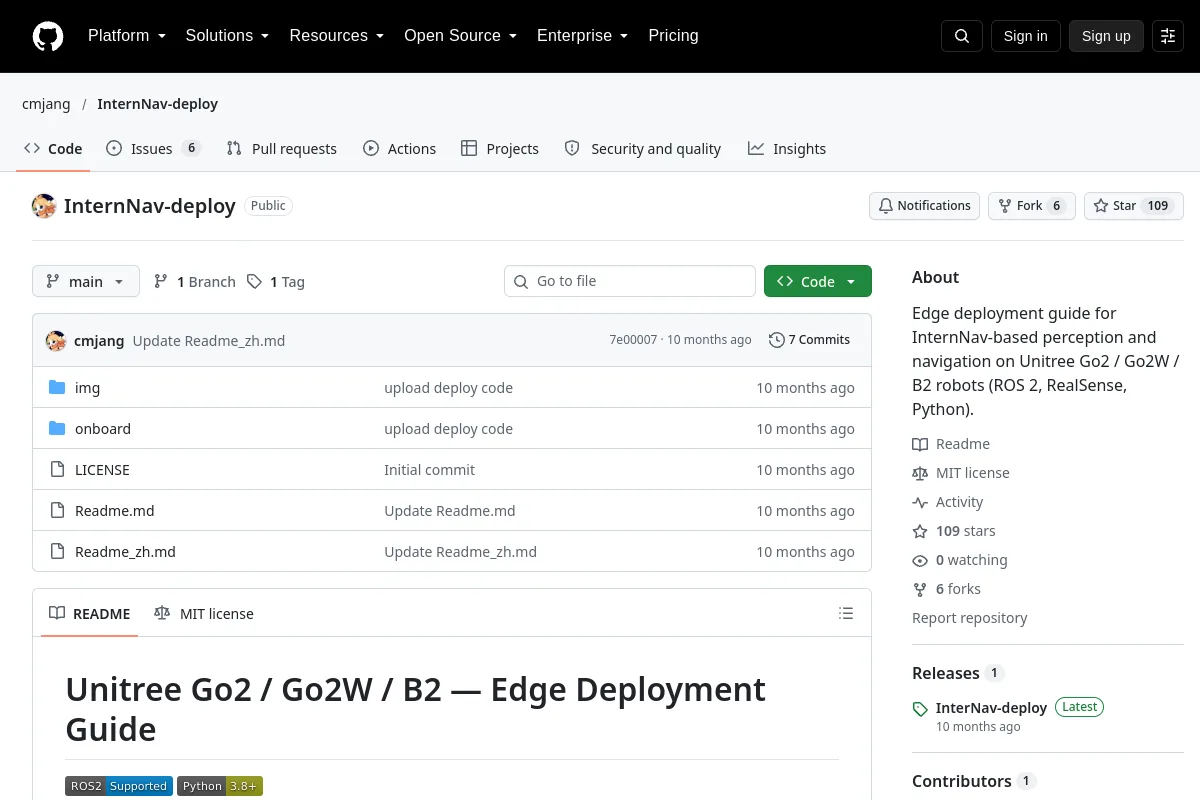 Repository
 Open source
Edge deployment guide for InternNav-based perception and navigation on Unitree Go2 / Go2W / B2 robots (ROS 2, RealSense, Python).
Navigation & SLAM Repository
 Open source
A Python-based lightweight robot simulator designed for navigation, control, and learning
Navigation & SLAM Repository
 Open source
Collection of online robotics courses and learning resources.
Robot learning frameworks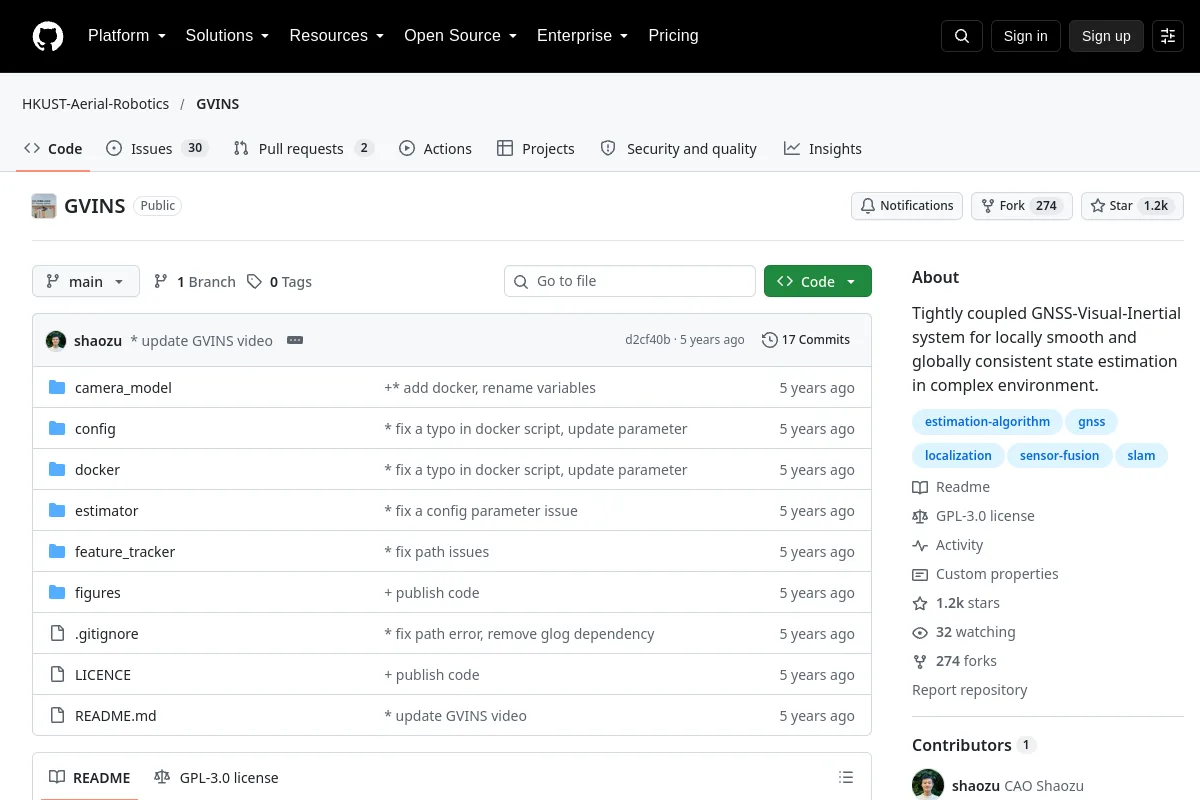 Repository
 Open source
Tightly coupled GNSS-Visual-Inertial system for locally smooth and globally consistent state estimation in complex environment.
Navigation & SLAM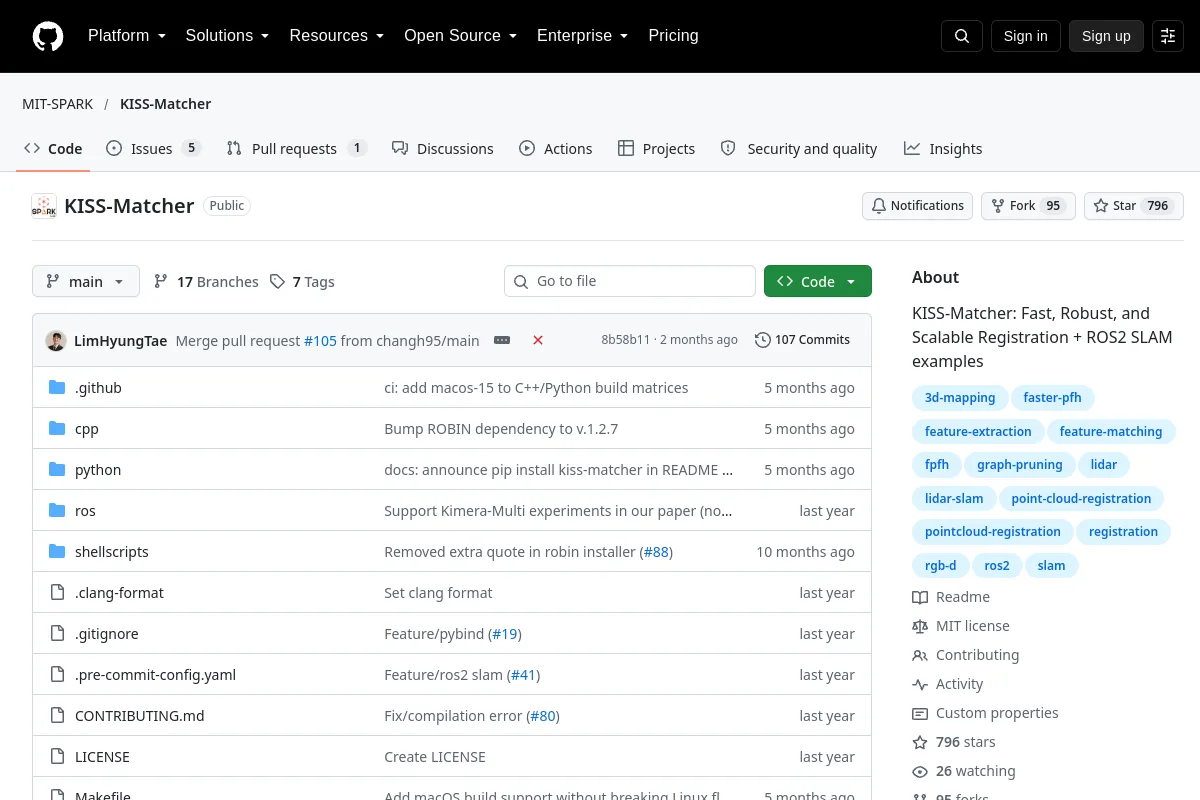 Repository
 Open source
KISS-Matcher: Fast, Robust, and Scalable Registration + ROS2 SLAM examples
Navigation & SLAM Repository
 Repository
 Research
A visual fiducial system for robotics research.
Robot learning frameworks Repository
 Repository
 Open source
Assistive Gym, a physics-based simulation framework for physical human-robot interaction and robotic assistance.
Simulation & physics Repository
Know a resource that belongs here?