Repository
genesislab · Renforce-Dynamics
A lightweight robotics RL framework built on Genesis with IsaacLab-aligned APIs, enabling fast task development and easy migration from existing IsaacLab environments.
Simulation & physicsTHE EMBODIED AI DIRECTORY
Explore robot simulation software for physics, control and robot learning.
Repository
A lightweight robotics RL framework built on Genesis with IsaacLab-aligned APIs, enabling fast task development and easy migration from existing IsaacLab environments.
Simulation & physics
Repository
Generating Robotic Simulation Tasks via Large Language Models
Simulation & physics
Repository
GRADE: Generating Animated Dynamic Environments for Robotics Research
Simulation & physics
Repository
Webots Simulation of Wheeled Bipedal Robot Using Model Based LQR (from an undergraduate graduation project)
Simulation & physics
Repository
Platform for General Robot Intelligence Development
Simulation & physics
Repository
An archived toolkit for RL experiments with ROS 2 and Gazebo.
Simulation & physics
Repository
Framework for developing OpenAI Gym robotics environments simulated with Ignition Gazebo
Simulation & physics
Repository
Mujoco Gym environment for the control of quadruped robots
Simulation & physics
Repository
Reproducible reinforcement-learning experiments in Gazebo.
Simulation & physics
Repository
Simulation Software (ROS/MATLAB) for HECTOR Humanoid Robot Locomotion Control/Bipedal Locomotion Control/Force-and-moment-based MPC
Simulation & physics
Repository
URDF models of humans created to perform human robot interaction experiments.
Simulation & physics
Repository
A human-vehicle simulation platform for autonomous-system and interaction experiments.
Simulation & physics
Repository
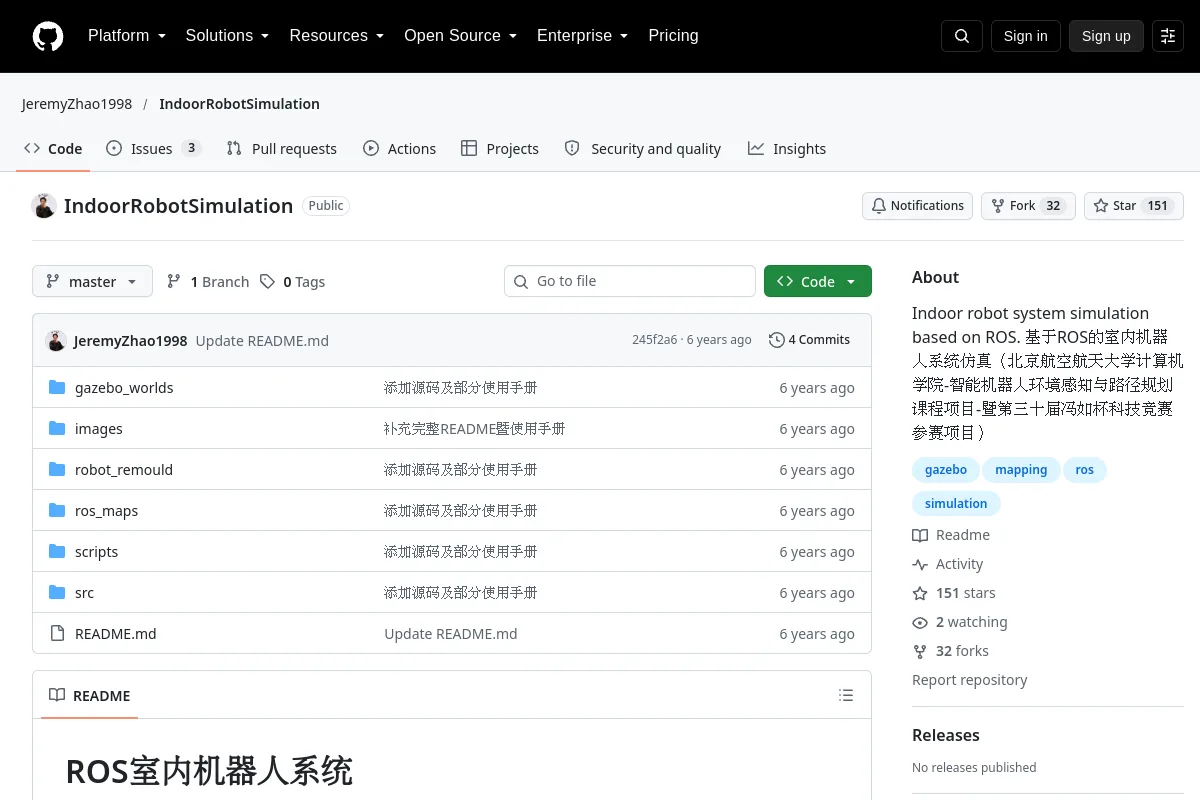
An indoor robot-system simulation and navigation project using ROS.
Simulation & physics
Repository
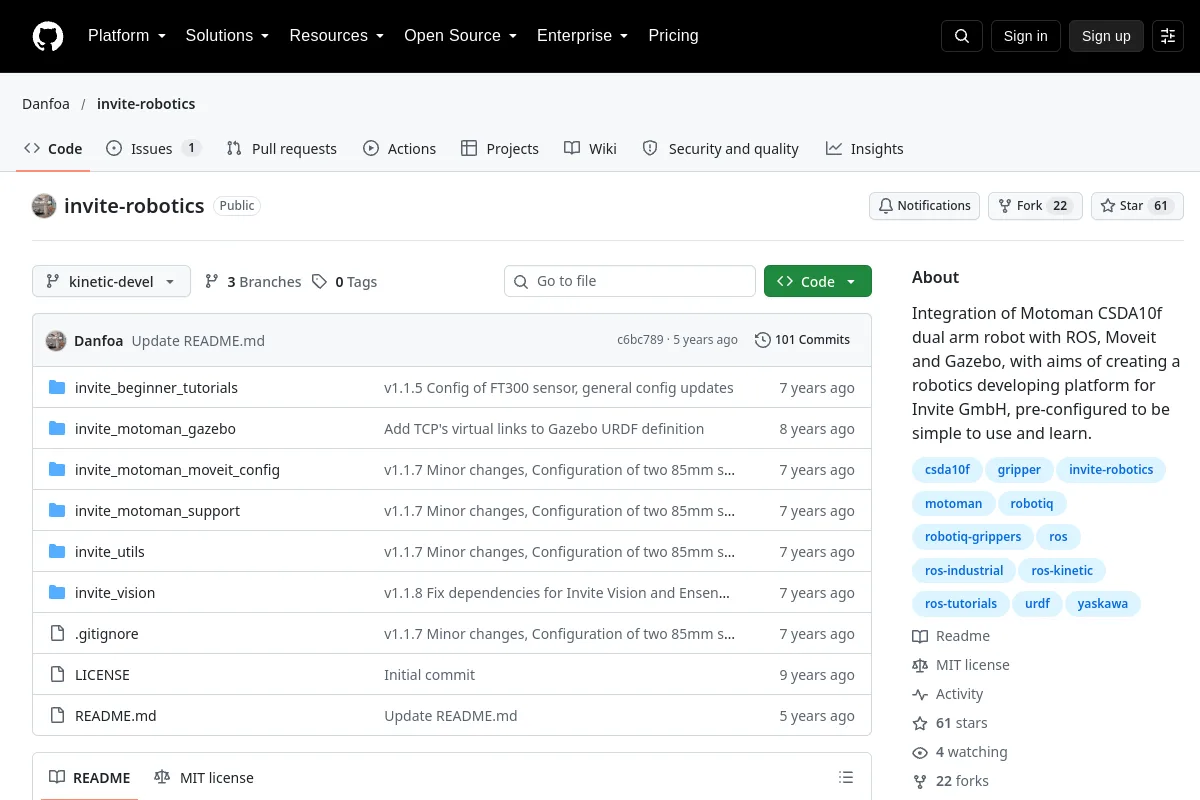
Integration of Motoman CSDA10f dual arm robot with ROS, Moveit and Gazebo, with aims of creating a robotics developing platform for Invite GmbH, pre-configured to be simple to use and learn.
Simulation & physics
Repository
An independent extension based on IsaacLab. It provides support for Robot Manipulation tasks (Robot Arm and Dextrous Hand).
Simulation & physics
Repository
A differentiable physics engine and multibody dynamics library for control and robot learning.
Simulation & physics
Repository
Python/C++ articulated-robot simulator with Gym interfaces for reinforcement learning.
Simulation & physics
Repository
C++ rigid-body physics and collision detection library.
Simulation & physics
Repository
Codebase for Kinova Gen3 training in Isaac Lab, sim2real transfer and ROS deployment.
Simulation & physics
Repository
Framework for building parallel multiphysics simulation software.
Simulation & physics
Repository
RL training library for humanoid locomotion and manipulation. Built on top of MuJoCo and JAX.
Simulation & physics
Repository
Repository
A Genesis–LeRobot bridge for running, recording and evaluating robot policies.
Simulation & physics
Repository
Perceptive Learning for Legged Robots in IsaacLab. | LocoTouch: Learning Dynamic Quadrupedal Transport with Tactile Sensing (CoRL'25)
Simulation & physicsSELECTION NOTES
Compare physics fidelity, rendering, robot asset support and Python interfaces. MuJoCo suits physics and control experiments; Gazebo connects simulation with the ROS ecosystem; Isaac Sim supports robotics simulation and synthetic data. Check current GPU and license requirements before choosing.
Know a resource that belongs here?