 Repository
 Open source
LeRobot · huggingface
LeRobot tools for robot control, datasets and end-to-end learning.
Robot learning frameworks
Software / Research
An indoor robot-system simulation and navigation project using ROS.
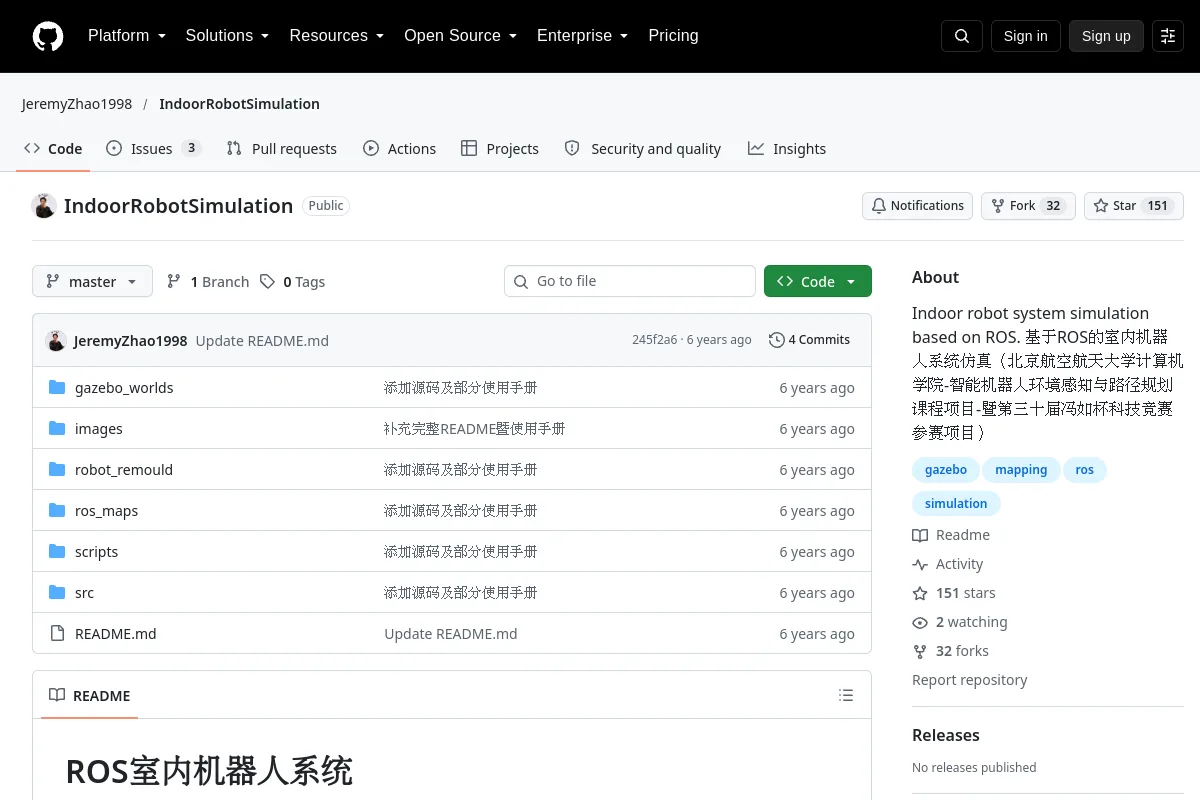
An indoor robot-system simulation and navigation project using ROS.
Publisher purpose: Indoor robot system simulation based on ROS. 基于ROS的室内机器人系统仿真(北京航空航天大学计算机学院-智能机器人环境感知与路径规划课程项目-暨第三十届冯如杯科技竞赛参赛项目)
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
LeRobot tools for robot control, datasets and end-to-end learning.
Robot learning frameworks Repository
 Open source
MuJoCo physics simulator for multijoint dynamics and contact.
Motion planning & control Repository
 Open source
Robot learning tools built around the Isaac simulation ecosystem.
Simulation & physics Repository
 Research
A physics SDK for collision detection and multi-physics simulation.
Robot SDKs Repository
 Open source
Converts Onshape assemblies into URDF, SDF, and MuJoCo robot descriptions.
Simulation & physics Repository
 Open source
A Robust and Versatile Monocular Visual-Inertial State Estimator
Navigation & SLAM