 Repository
 Open source
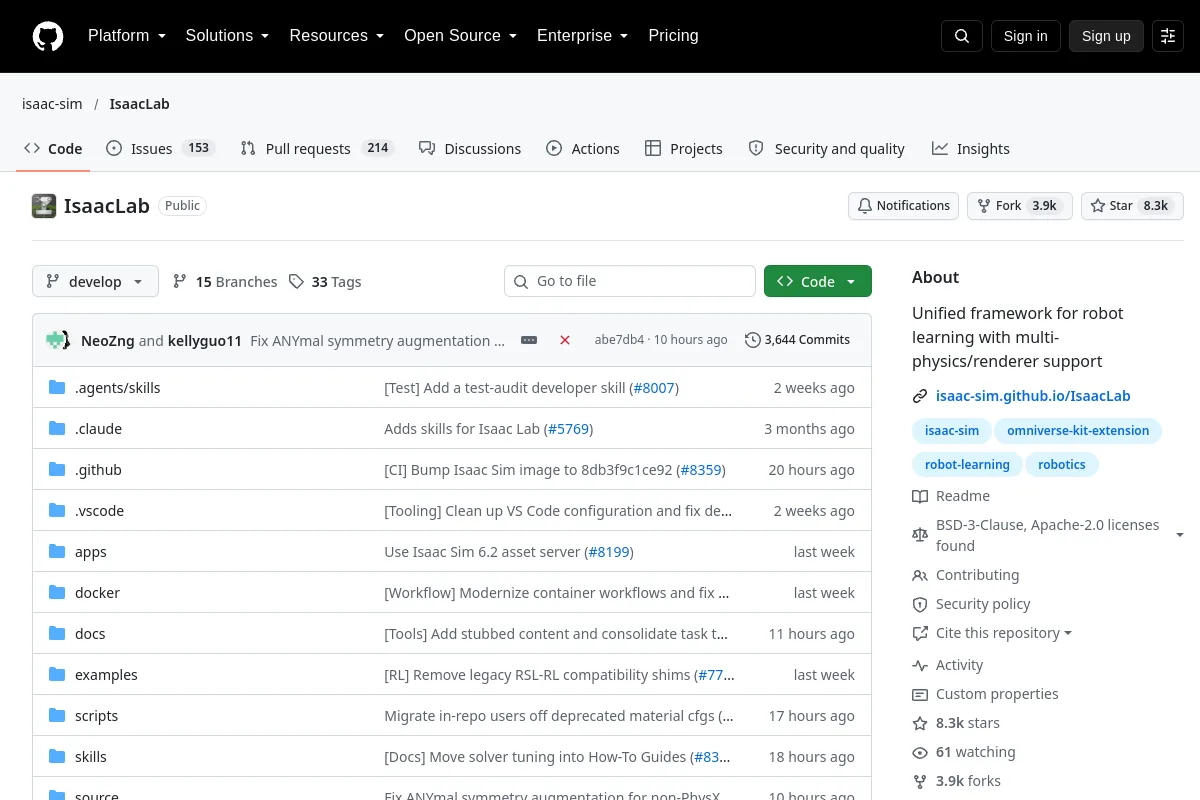
NVIDIA Isaac Lab
Robot learning tools built around the Isaac simulation ecosystem.
Simulation & physicsTHE EMBODIED AI DIRECTORY
Explore robot simulation software for physics, control and robot learning.
Repository
Open source
Robot learning tools built around the Isaac simulation ecosystem.
Simulation & physics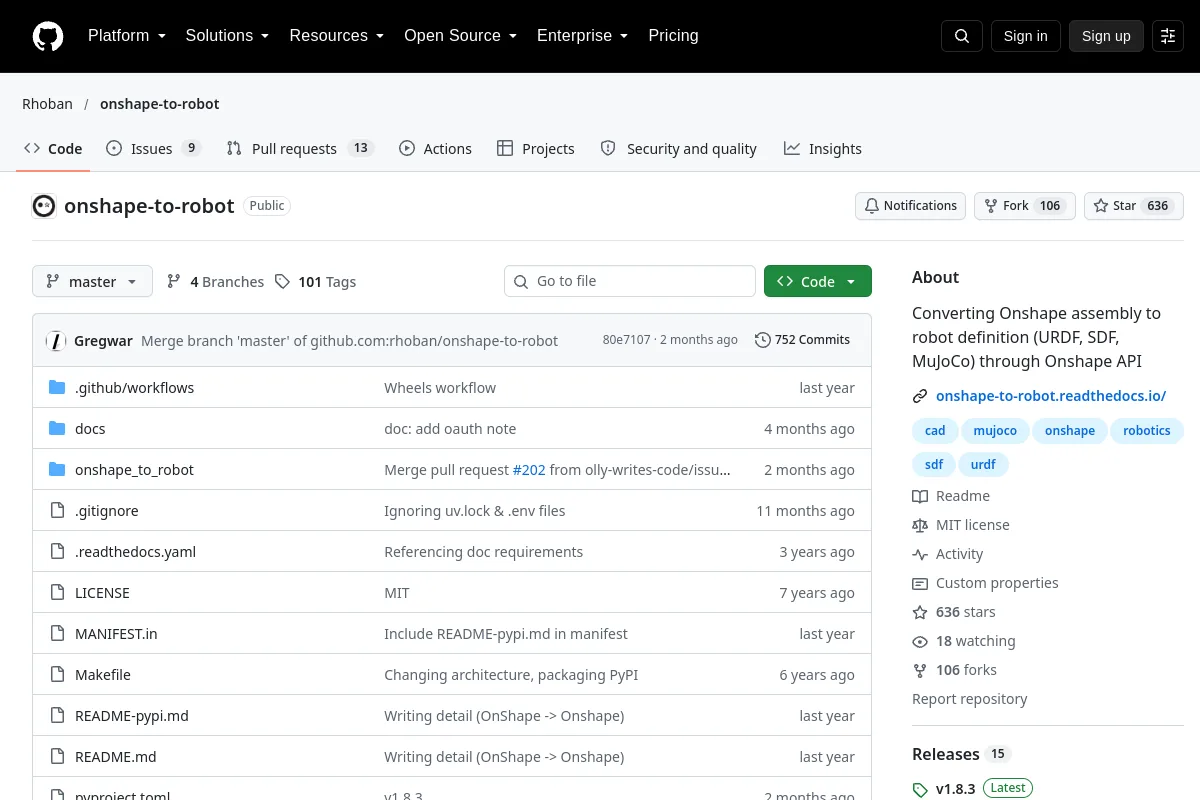 Repository
 Open source
Converts Onshape assemblies into URDF, SDF, and MuJoCo robot descriptions.
Simulation & physics Repository
 Research
MuJoCo-based manipulation environments for robot learning experiments.
Simulation & physics Repository
 Open source
Gazebo Sim robotics simulator source code and development resources.
Simulation & physics Repository
 Open source
Abstract physics interface designed to support simulation and rapid development of robot applications.
Simulation & physics Repository
 Open source
MuJoCo-Warp robotics and reinforcement-learning workflows using an Isaac Lab-style API.
Simulation & physics Repository
 Open source
ROS 2 packages for ROBOTIS OpenMANIPULATOR robot arms.
Simulation & physics Repository
 Open source
Consensus and formation simulations of swarm robots.
Simulation & physics Repository
 Open source
A swarm robot simulation environment for ROS to be used with Gazebo
Simulation & physics Repository
 Open source
Robot learning environments built around accelerated MuJoCo simulation.
Simulation & physics Repository
 Repository
 Open source
A JAX-based physics and learning environment for control research.
Simulation & physics Repository
 Research
Deprecated robot simulation package integrated with OpenAI Gym.
Simulation & physics Repository
 Open source
Python framework for GPU-accelerated simulation and differentiable computing.
Simulation & physics Repository
 Open source
Robot learning infrastructure connecting simulation and evaluation workflows.
Simulation & physics Repository
 Open source
Robotic reinforcement-learning environments built on PyBullet and Gymnasium.
Simulation & physics Repository
 Research
Robotics research tool for simulation and visualization.
Simulation & physics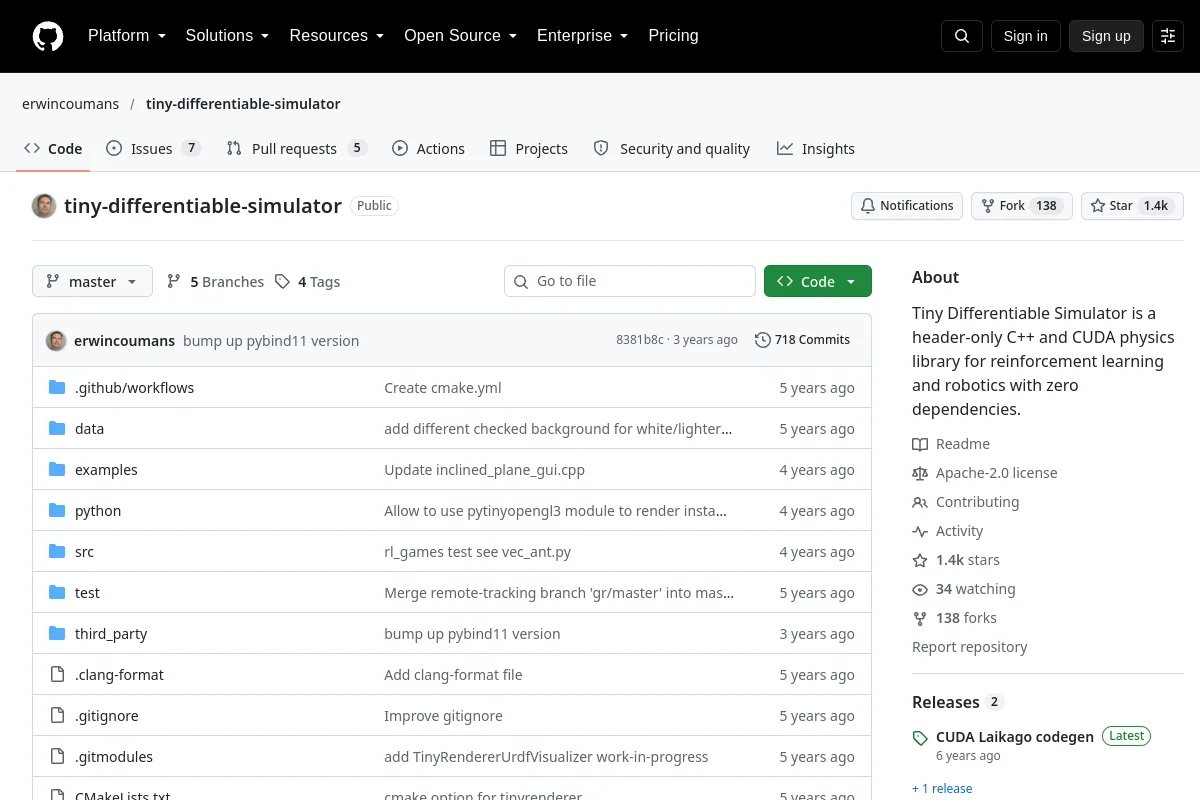 Repository
 Open source
C++ and CUDA differentiable physics library for reinforcement learning and robotics.
Simulation & physics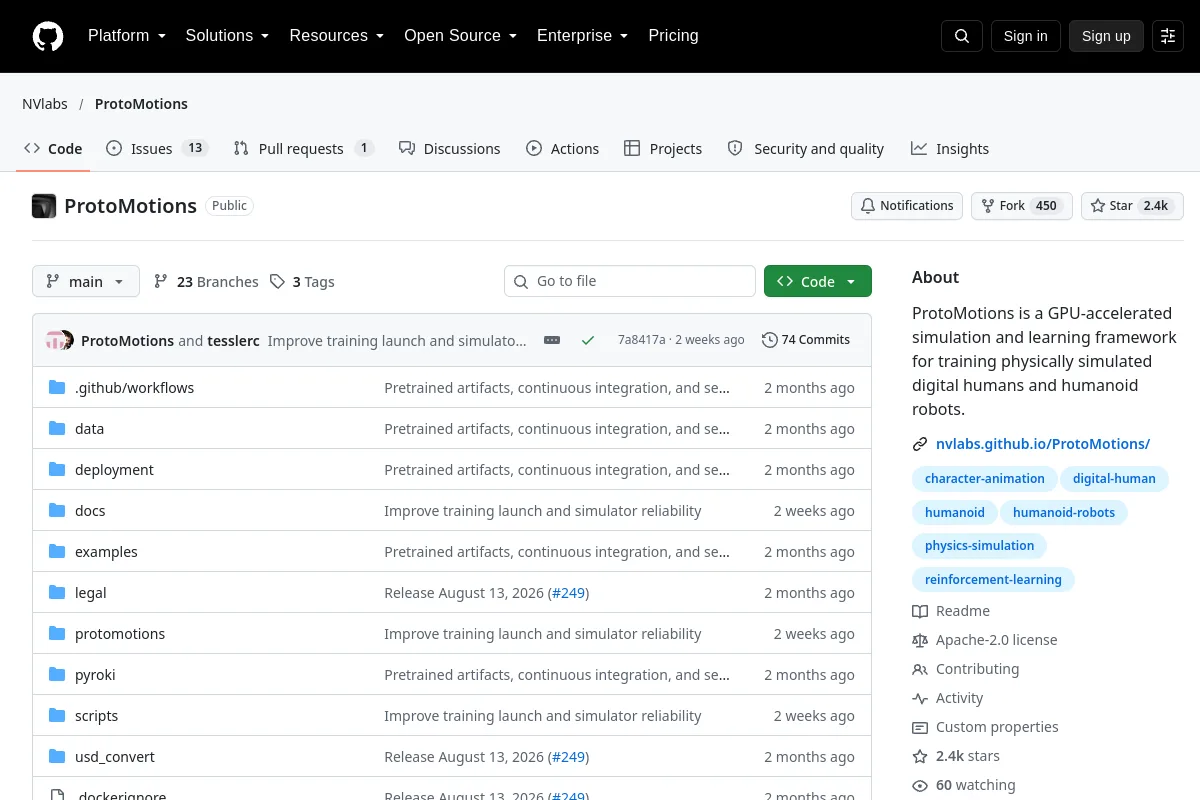 Repository
 Open source
ProtoMotions is a GPU-accelerated simulation and learning framework for training physically simulated digital humans and humanoid robots.
Simulation & physics Repository
 Open source
ROS-based software for quadruped gait and locomotion experiments.
Simulation & physics Repository
 Open source
Reinforcement-learning algorithms for MuJoCo tasks.
Simulation & physics Repository
 Open source
Research implementation for simulation alignment and agile humanoid whole-body skills.
Simulation & physics Repository
 Research
Toolkit for training intelligent agents in Unity games and simulations.
Simulation & physics Repository
 Open source
Robot simulation environment with interactive indoor scenes.
Simulation & physicsSELECTION NOTES
Compare physics fidelity, rendering, robot asset support and Python interfaces. MuJoCo suits physics and control experiments; Gazebo connects simulation with the ROS ecosystem; Isaac Sim supports robotics simulation and synthetic data. Check current GPU and license requirements before choosing.
Know a resource that belongs here?