 Repository
 Open source
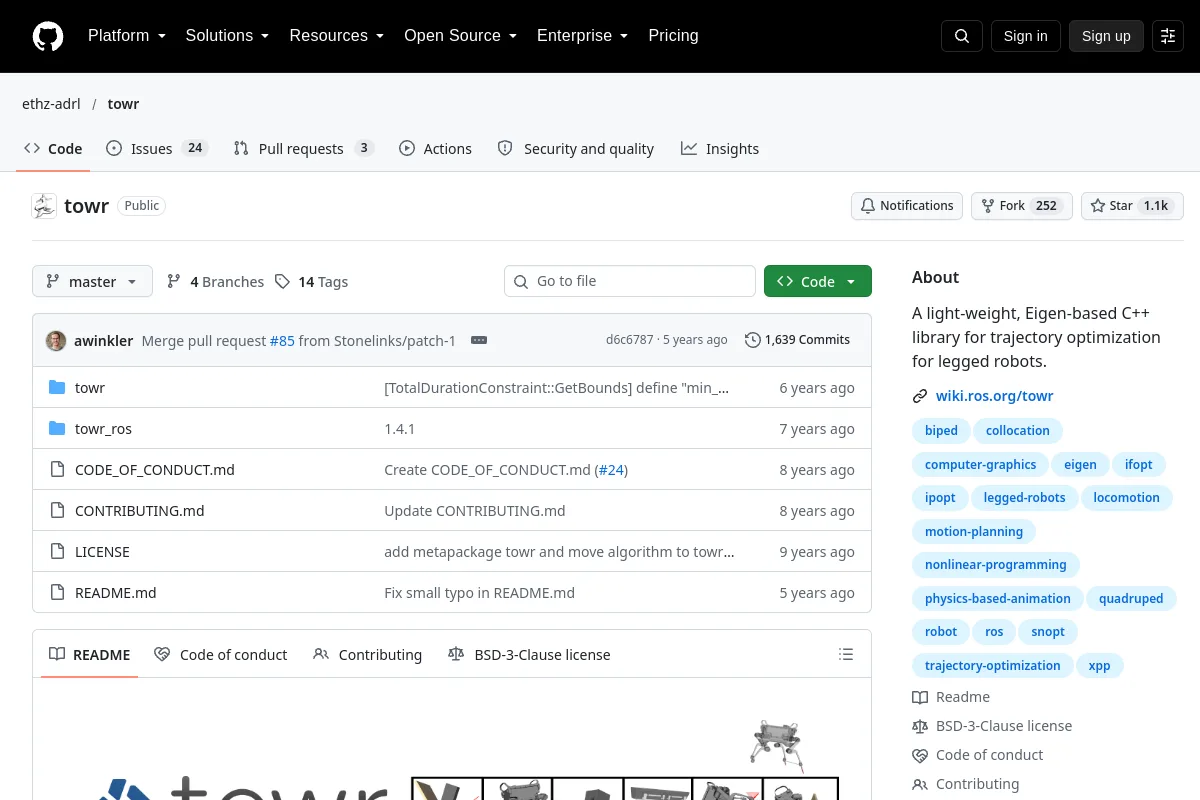
towr · ethz-adrl
C++ trajectory optimization library for legged robots.
Motion planning & control
Software / Open source
ROS-based software for quadruped gait and locomotion experiments.
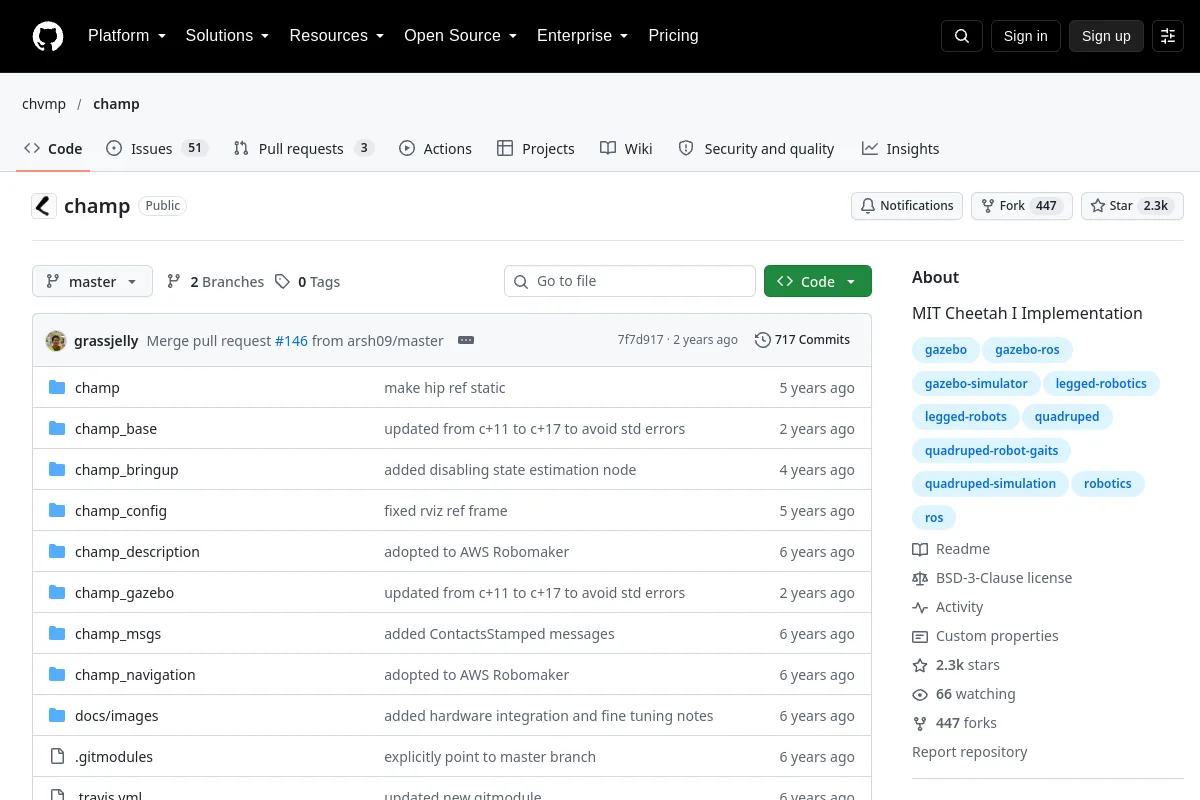
ROS-based software for quadruped gait and locomotion experiments.
Publisher summary: “MIT Cheetah I Implementation”
Use its repository to inspect the implementation, documentation and supported workflows. This directory record identifies the maintainer, code license and related resources; it does not claim that the project has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
C++ trajectory optimization library for legged robots.
Motion planning & control Repository
 Research
open-quadruped is a 3D-printed quadrupedal robot project with gait generation and body-pose control.
DIY & education hardware Repository
 Research
Collection of quadrupedal robots configured to work in CHAMP development framework
Scene & object assets