 Repository
 Research
copa · HaoxuHuang
Official implementation of CoPa: General Robotic Manipulation through Spatial Constraints of Parts with Foundation Models
Robot policiesTHE EMBODIED AI DIRECTORY
Explore vision-language-action models and robotics foundation models for perception, manipulation and control.
Repository
Research
Official implementation of CoPa: General Robotic Manipulation through Spatial Constraints of Parts with Foundation Models
Robot policies Website
 Repository
 Research
DEAS Isaac GR00T provides setup resources combining DEAS, Isaac GR00T and RoboCasa.
Vision-language-action Repository
 Open source
The offical Implementation of "DecisionNCE: Embodied Multimodal Representations via Implicit Preference Learning"
Perception models Repository
 Research
Deep RL Grasping provides training and evaluation code for depth/RGB-D robotic grasping policies.
Robot policies Repository
 Research
Dexora provides VLA policy resources for high-degree-of-freedom bimanual dexterity.
Vision-language-action Repository
 Research
Official code and data from DexWM ("World Models Can Leverage Human Videos for Dexterous Manipulation").
World models Repository
 Research
DreamX-Phi provides an action-conditioned video world model for robotic manipulation.
World models Repository
 Research
DynamicVLA provides research resources for dynamic-object robotic manipulation.
Vision-language-action Repository
 Research
EAI2025 Project combines 3D semantic mapping and VLA deployment for manipulation.
Vision-language-action Repository
 Open source
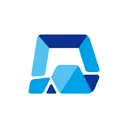
The first framework enabling humanoid robots to learn whole-body loco-manipulation from egocentric human demos
Robot policies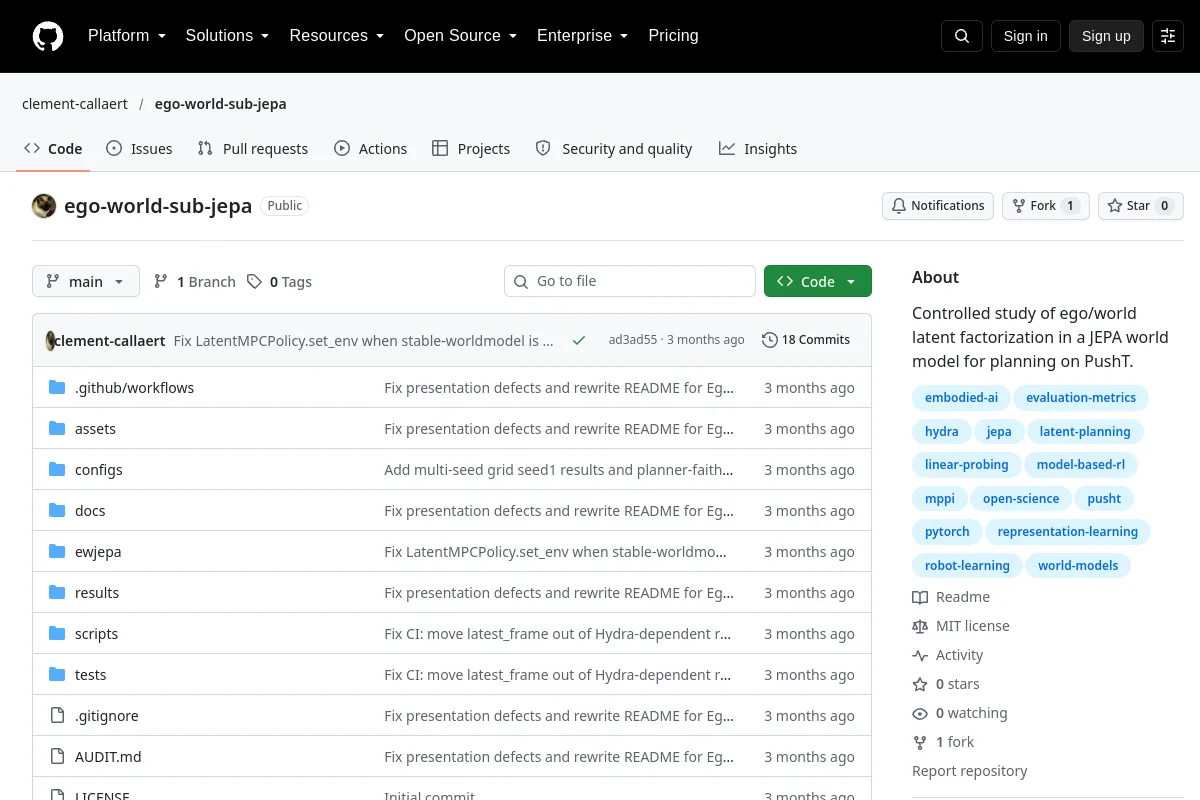 Repository
 Research
Ego-World JEPA studies ego/world latent factorization for planning on PushT.
World models Repository
 Research
Emma-X: An Embodied Multimodal Action Model with Grounded Chain of Thought and Look-ahead Spatial Reasoning
Vision-language-action Repository
 Research
EquiDexFlow provides contact-grounded generative flows for dexterous grasping.
Grasping models Repository
 Research
Official Implementation of "EVA: Aligning Video World Models with Executable Robot Actions via Inverse Dynamics Rewards"
World models Repository
 Research
EVEWorld studies physical-evolution supervision and temporal consistency in embodied world models.
World models Repository
 Research
FLUX 3 Action provides world-action modeling and action-prediction resources for robots and simulators.
Vision-language-action Repository
 Open source
G3Flow: Generative 3D Semantic Flow for Pose-aware and Generalizable Object Manipulation
Robot policies Repository
 Research
Towards Scalable Gaussian World Models for Robotic Manipulation
World models Website
 Research
Google DeepMind robotics models connecting perception and action.
Vision-language-action Repository
 Research
Official code of GEM: Generative Supervision Helps Embodied Intelligence
Robot policies Repository
 Research
GenRL: Multimodal-foundation world models enable grounding language and video prompts into embodied domains, by turning them into sequences of latent world model states. Latent state sequences can…
World models Repository
 Open source
PyTorch Code for "Generalization in Dexterous Manipulation via Geometry-Aware Multi-Task Learning"
Robot policies Repository
 Research
A Roadmap to Build World Models for Robot Policy Evaluation
World modelsKnow a resource that belongs here?