 Repository
 Open source
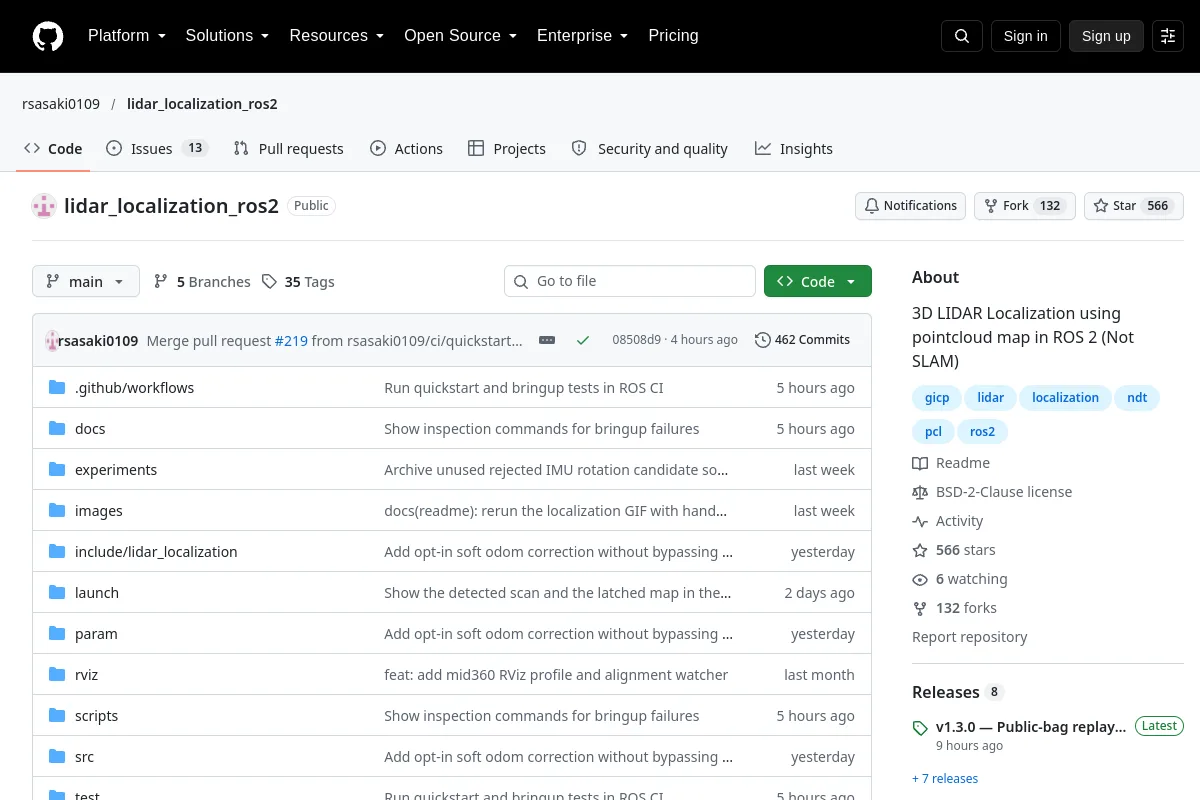
lidar_localization_ros2 · rsasaki0109
3D LIDAR Localization using pointcloud map in ROS 2 (Not SLAM)
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Explore mapping, localization, odometry and navigation software for autonomous robots.
Repository
Open source
3D LIDAR Localization using pointcloud map in ROS 2 (Not SLAM)
Navigation & SLAM Repository
 Open source
A ROS 2 navigation workspace combining LiDAR-inertial odometry, relocalization and Nav2.
Navigation & SLAM Repository
 Repository
 Open source
LSD (LiDAR SLAM & Detection) is an open source perception architecture for autonomous vehicle/robotic
Navigation & SLAM Repository
 Open source
A simple system that can relocalize a robot on a built map is developed in this system. The system is based on LIO-SAM.
Navigation & SLAM Repository
 Open source
ROS 2 package of tightly-coupled lidar inertial ndt/gicp slam
Navigation & SLAM Repository
 Repository
 Repository
 Open source
My End-of-Degree thesis. Visual SLAM, DL, 3D sparse and dense maps and Computer Vision.
Navigation & SLAM Repository
 Open source
A ROS package for probabilistic mobile-robot localization with 3D lidar.
Navigation & SLAM Repository
 Open source
Factor-graph framework for nonlinear least-squares optimization.
Navigation & SLAM Repository
 Research
Learning World Transition Model for Socially Aware Robot Navigation
Navigation & SLAM Repository
 Research
A Modular Optimization framework for Localization and mApping (MOLA)
Navigation & SLAM Repository
 Open source
Robot path planning, mapping and exploration algorithms
Navigation & SLAM Repository
 Open source
ROS 2 nodes wrapping core MRPT functionality: localization, autonomous navigation, rawlogs, etc. SLAM is in other packages.
Navigation & SLAM Repository
 Open source
A modularized multi-robot SLAM system with elevation mapping and a costmap converter for easy navigation. Different odometry and loop closure algorithms can be easily integrated into the system.
Navigation & SLAM Repository
 Open source
CVPR 2026 - MSGNav: Unleashing the Power of Multi-modal 3D Scene Graph for Zero-Shot Embodied Navigation
Navigation & SLAM Repository
 Research
EMKG: multimodal memory and retrieval for open-world object-goal navigation in dynamic environments.
Navigation & SLAM Repository
 Open source
"Multi-robot Coordination with Agent-Server Architecture for Autonomous Navigation in Partially Unknown Environments", IROS 2020
Navigation & SLAM Repository
 Research
Educational Python implementation of pose-graph optimization.
Navigation & SLAM Repository
 Research
Real time Nav2 parameter tuning GUI for ROS2, no kill or relaunch needed
Navigation & SLAM Repository
 Open source
MCP server that provides tools and resources to control and monitor robots using Nav2.
Navigation & SLAM Repository
 Research
Nav-R1: Reasoning and Navigation in Embodied Scenes
Navigation & SLAM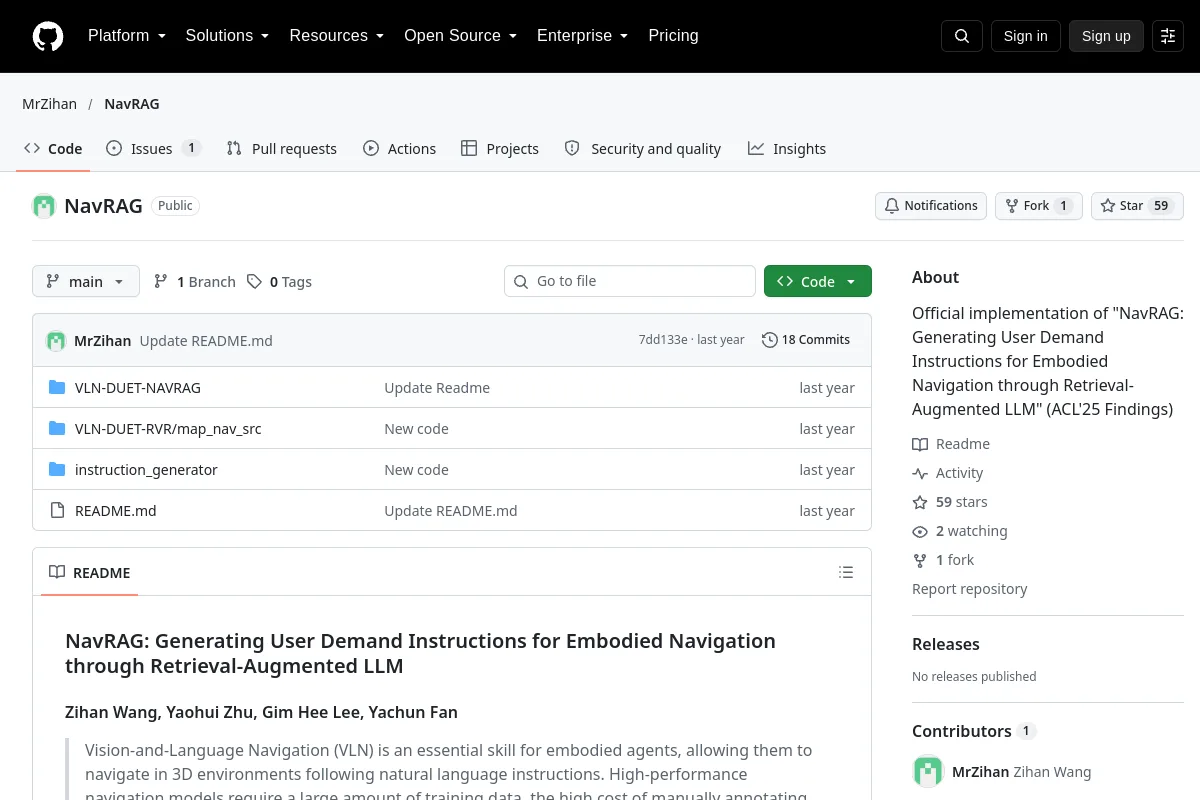 Repository
 Research
Official implementation of "NavRAG: Generating User Demand Instructions for Embodied Navigation through Retrieval-Augmented LLM" (ACL'25 Findings)
Navigation & SLAMSELECTION NOTES
Match sensors, coordinate frames and localization assumptions to the deployment environment. Mapping, pose estimation, path planning and obstacle avoidance serve different parts of the navigation stack.
Know a resource that belongs here?