 Repository
 Research
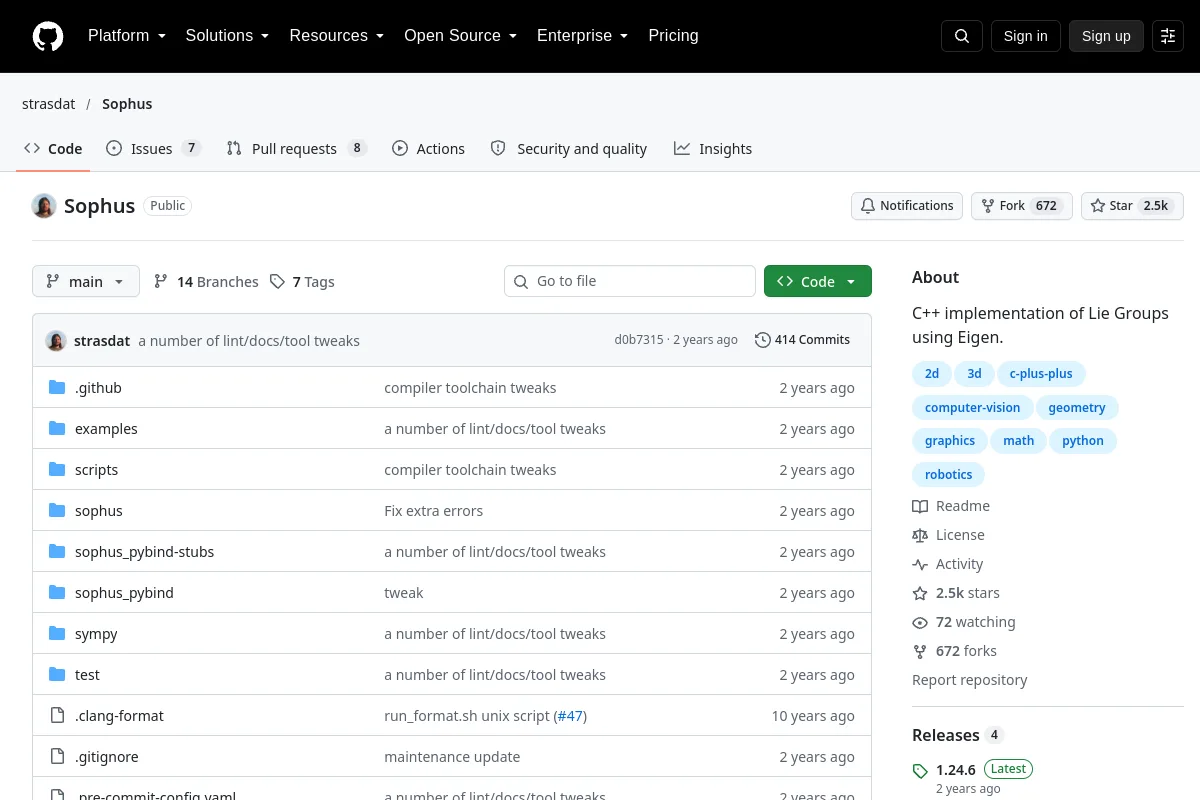
Sophus · strasdat
Eigen-based C++ Lie-group library for geometric computation.
Perception & geometry
Software / Open source
A ROS 2 navigation workspace combining LiDAR-inertial odometry, relocalization and Nav2.
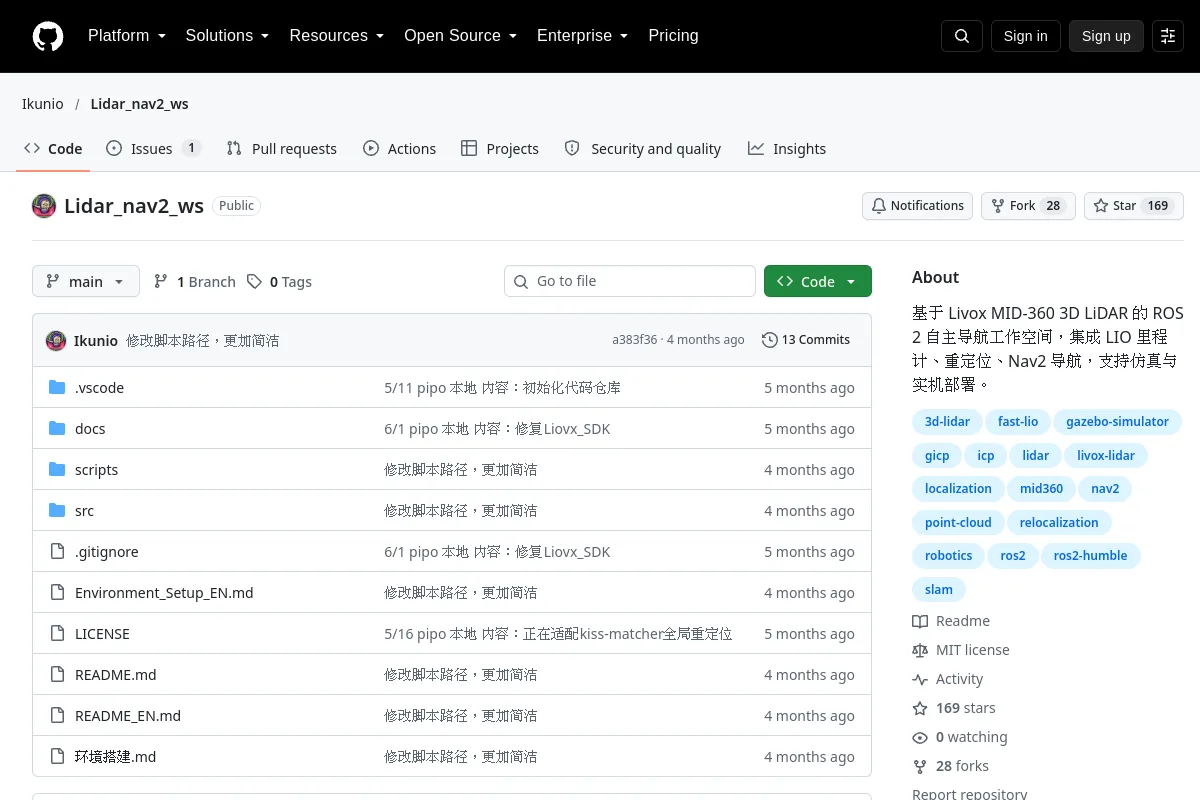
A ROS 2 navigation workspace combining LiDAR-inertial odometry, relocalization and Nav2.
Publisher purpose: 基于 Livox MID-360 3D LiDAR 的 ROS 2 自主导航工作空间,集成 LIO 里程计、重定位、Nav2 导航,支持仿真与实机部署。
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Eigen-based C++ Lie-group library for geometric computation.
Perception & geometry Repository
 Open source
LiDAR-inertial odometry tools for mobile robotic state estimation.
Navigation & SLAM Repository
 Open source
Mapping and localization tools for ROS 2 navigation workflows.
Navigation & SLAM Repository
 Open source
KISS-Matcher: Fast, Robust, and Scalable Registration + ROS2 SLAM examples
Navigation & SLAM