 Repository
 Open source
dynamic robot localization · carlosmccosta
A point-cloud registration pipeline for robot localization and 3D perception.
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Explore mapping, localization, odometry and navigation software for autonomous robots.
Repository
Open source
A point-cloud registration pipeline for robot localization and 3D perception.
Navigation & SLAM Repository
 Open source
Master's Thesis on Simultaneous Localization and Mapping in dynamic environments. Separately reconstructs both the static environment and the dynamic objects from it, such as cars.
Navigation & SLAM Repository
 Research
EAO-SLAM: Monocular Semi-Dense Object SLAM Based on Ensemble Data Association
Navigation & SLAM Repository
 Open source
Robot-centric elevation mapping for rough-terrain navigation.
Navigation & SLAM Repository
 Research
Implementation for learning a mapping from urban images that contain dynamic objects to static realistic images suitable for SLAM
Navigation & SLAM Repository
 Open source
Research code for scene imagination and efficient robotic exploration.
Navigation & SLAM Repository
 Research
Sensor fusion architecture for robot state estimation, localization and mapping.
Navigation & SLAM Repository
 Open source
ROS 2 localization for outdoor robots: IMU, wheel encoders and GPS fused in a 23-state UKF at 100 Hz. When the estimate goes wrong it reports which sensor and why, instead of drifting silently.…
Navigation & SLAM Repository
 Research
This is the official implementation of the voxel-based humanoid locomotion in "Gallant: Voxel Grid-based Humanoid Locomotion and Local-navigation across 3D Constrained Terrains"
Navigation & SLAM Repository
 Open source
Gaussian-SLAM: Photo-realistic Dense SLAM with Gaussian Splatting
Navigation & SLAM Repository
 Research
Geometry-Aware Learning of Maps for Camera Localization (CVPR2018)
Navigation & SLAM Repository
 Open source
Modern C++20 GNSS toolkit — RTK/PPP/CLAS/IMU fusion.
Navigation & SLAM Repository
 Research
Habitat-GS: A High-Fidelity Navigation Simulator with Dynamic Gaussian Splatting
Navigation & SLAM Repository
 Open source
Hierarchical RL for interactive navigation with mobile manipulators.
Navigation & SLAM Repository
 Open source
HybVIO visual-inertial odometry and SLAM system
Navigation & SLAM Repository
 Open source
This package provides localization in a pre-built map using ICP and odometry (or the IMU measurements).
Navigation & SLAM Repository
 Research
AUTONOMOUS ROBOT NAVIGATION USING ROS Clearpath Husky A200 robot with Gazebo and RViz simulations using different SLAM and Path Planning algorithms. 360 degrees laser scan with two SICK LMS511…
Navigation & SLAM Repository
 Open source
ROS 2 implementation of a Teleoperated robot with live video feed using webrtc and SLAM using realsense's stereocameras. Running on a Jetson Nano
Navigation & SLAM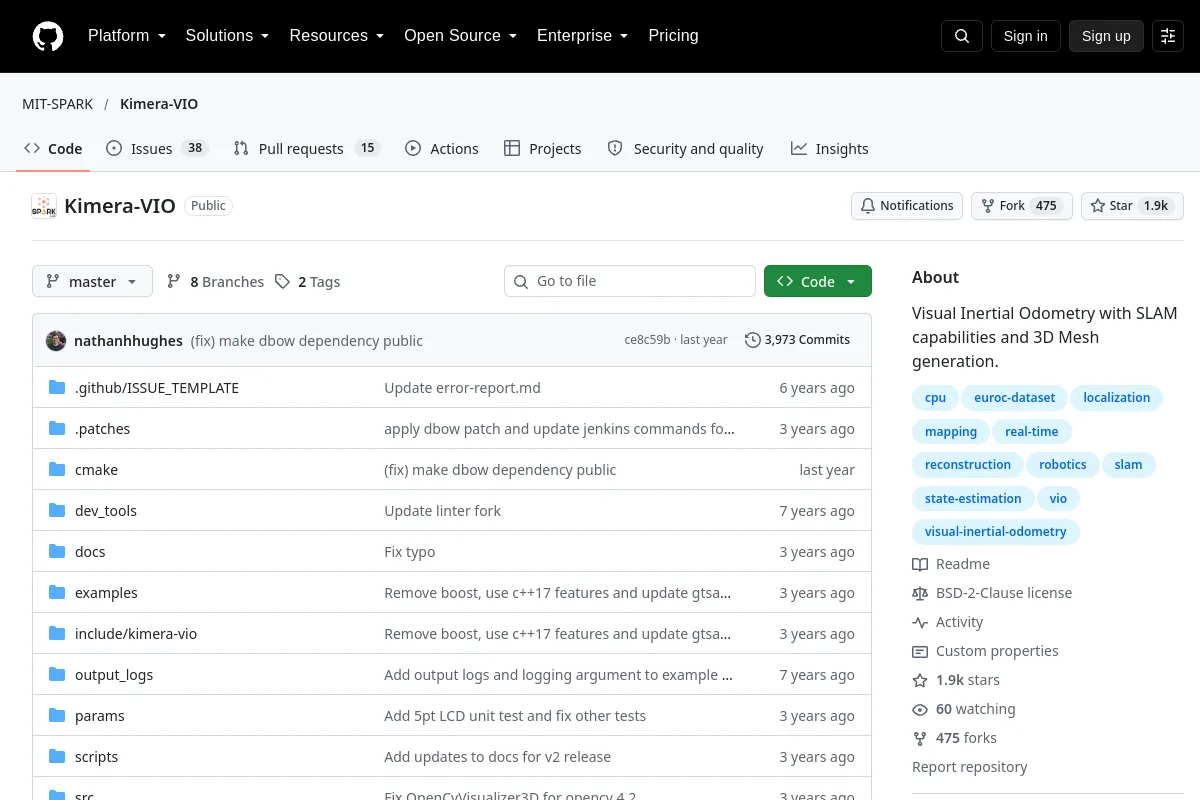 Repository
 Open source
Visual Inertial Odometry with SLAM capabilities and 3D Mesh generation.
Navigation & SLAM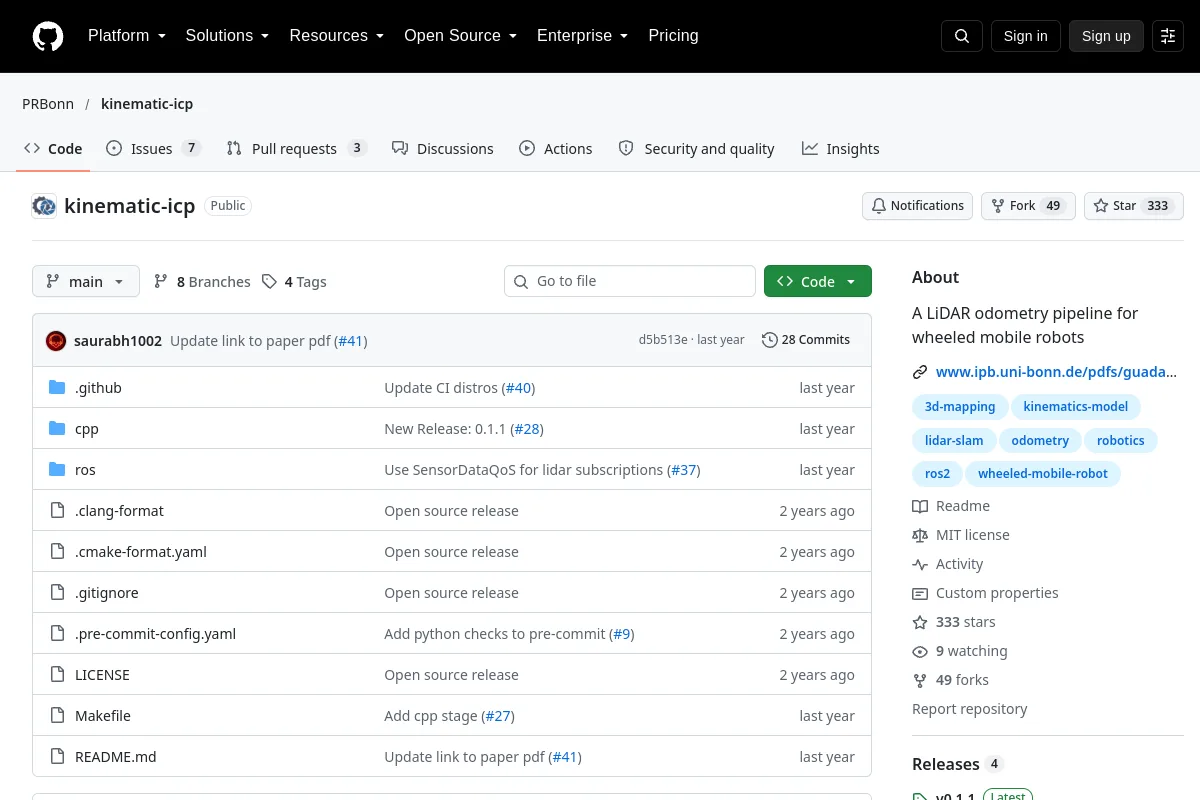 Repository
 Open source
A LiDAR odometry pipeline for wheeled mobile robots
Navigation & SLAM Repository
 Repository
 Research
Code for LGX (Language Guided Exploration). We use LLMs to perform embodied robot navigation in a zero-shot manner.
Navigation & SLAM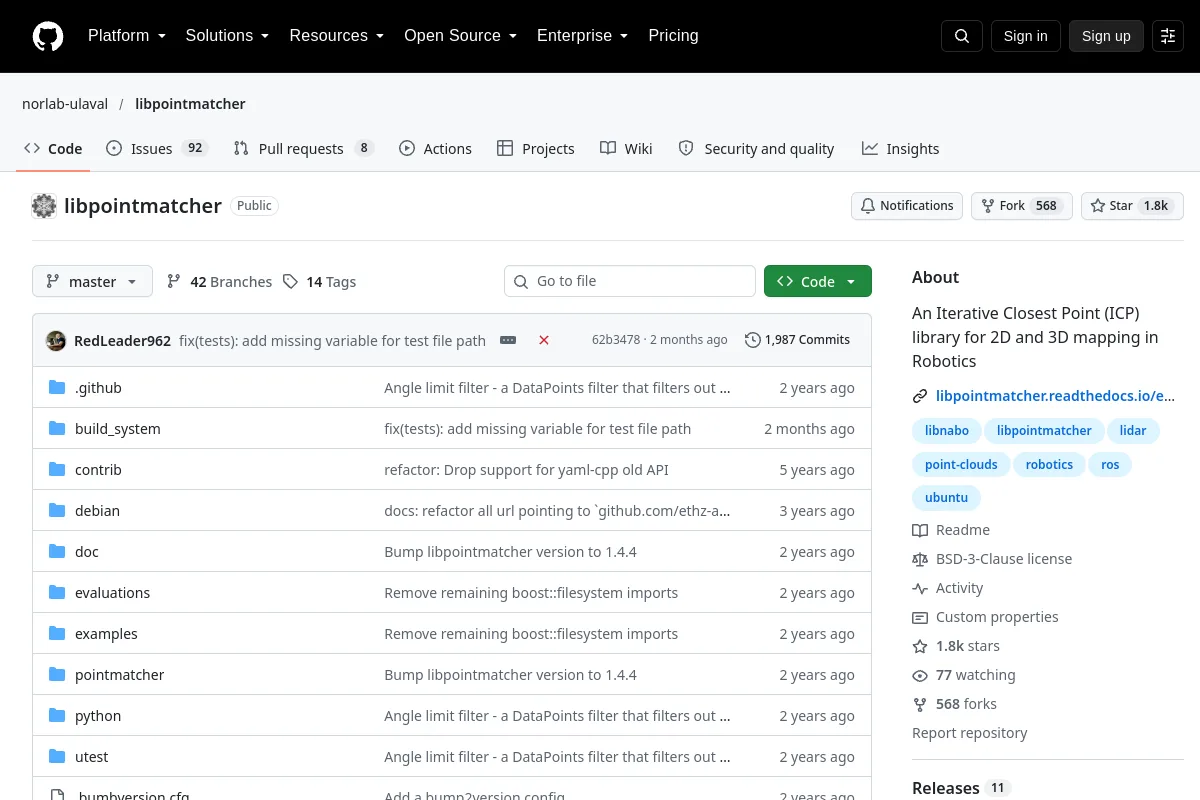 Repository
 Open source
Iterative closest-point library for 2D and 3D robotic mapping.
Navigation & SLAM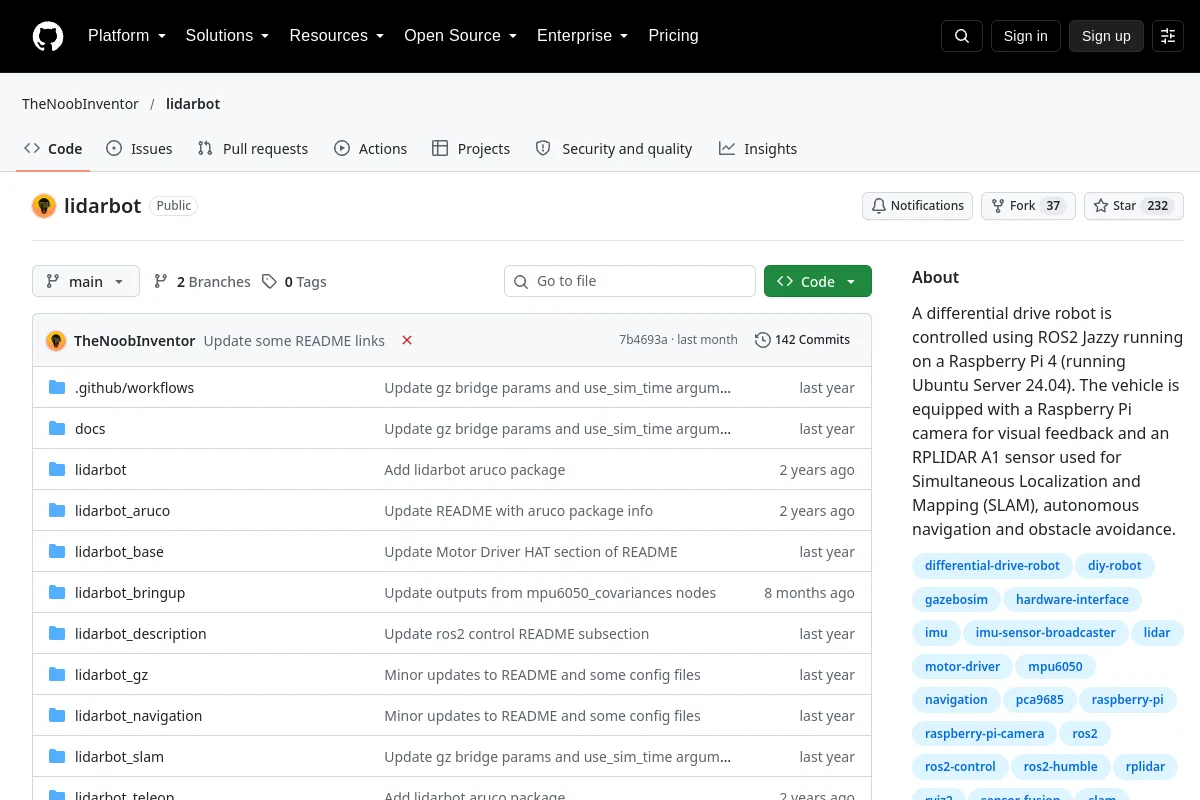 Repository
 Open source
A differential drive robot is controlled using ROS2 Jazzy running on a Raspberry Pi 4 (running Ubuntu Server 24.04). The vehicle is equipped with a Raspberry Pi camera for visual feedback and an…
Navigation & SLAMSELECTION NOTES
Match sensors, coordinate frames and localization assumptions to the deployment environment. Mapping, pose estimation, path planning and obstacle avoidance serve different parts of the navigation stack.
Know a resource that belongs here?