 Repository
 Open source
open3d_slam · leggedrobotics
Pointcloud-based graph SLAM written in C++ using open3D library.
Navigation & SLAM
Software / Open source
This package provides localization in a pre-built map using ICP and odometry (or the IMU measurements).
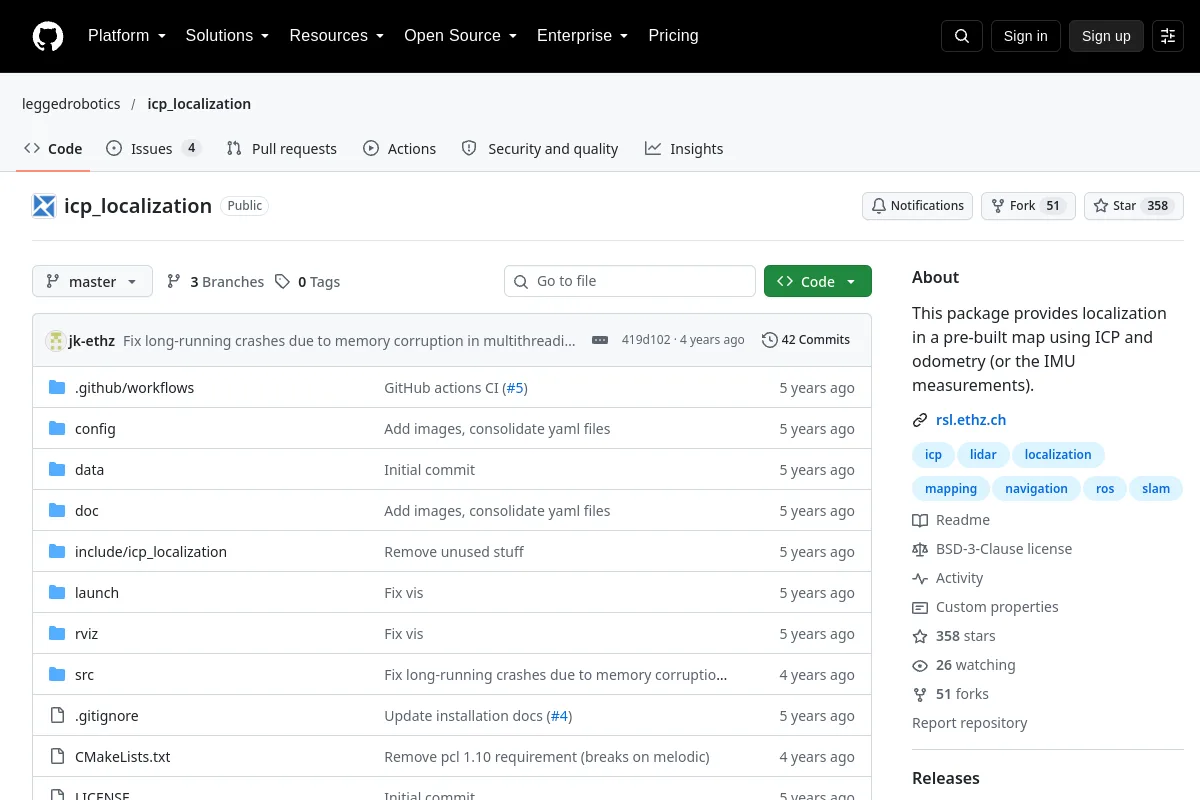
This package provides localization in a pre-built map using ICP and odometry (or the IMU measurements).
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
Pointcloud-based graph SLAM written in C++ using open3D library.
Navigation & SLAM