 Repository
 Open source
ros_autonomous_slam · fazildgr8
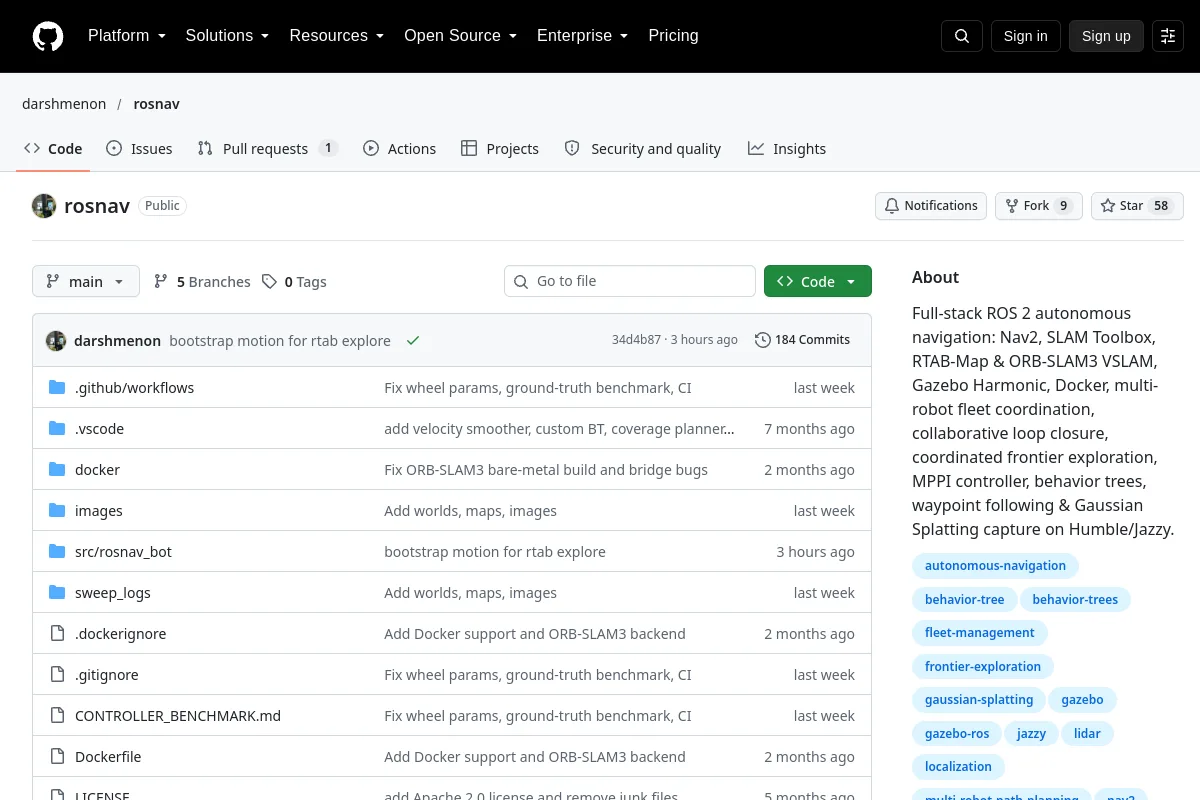
ROS package which uses the Navigation Stack to autonomously explore an unknown environment with help of GMAPPING and constructs a map of the explored environment. Finally, a path planning…
Navigation & SLAM