 Repository
Software / Open source
ros_autonomous_slam · fazildgr8
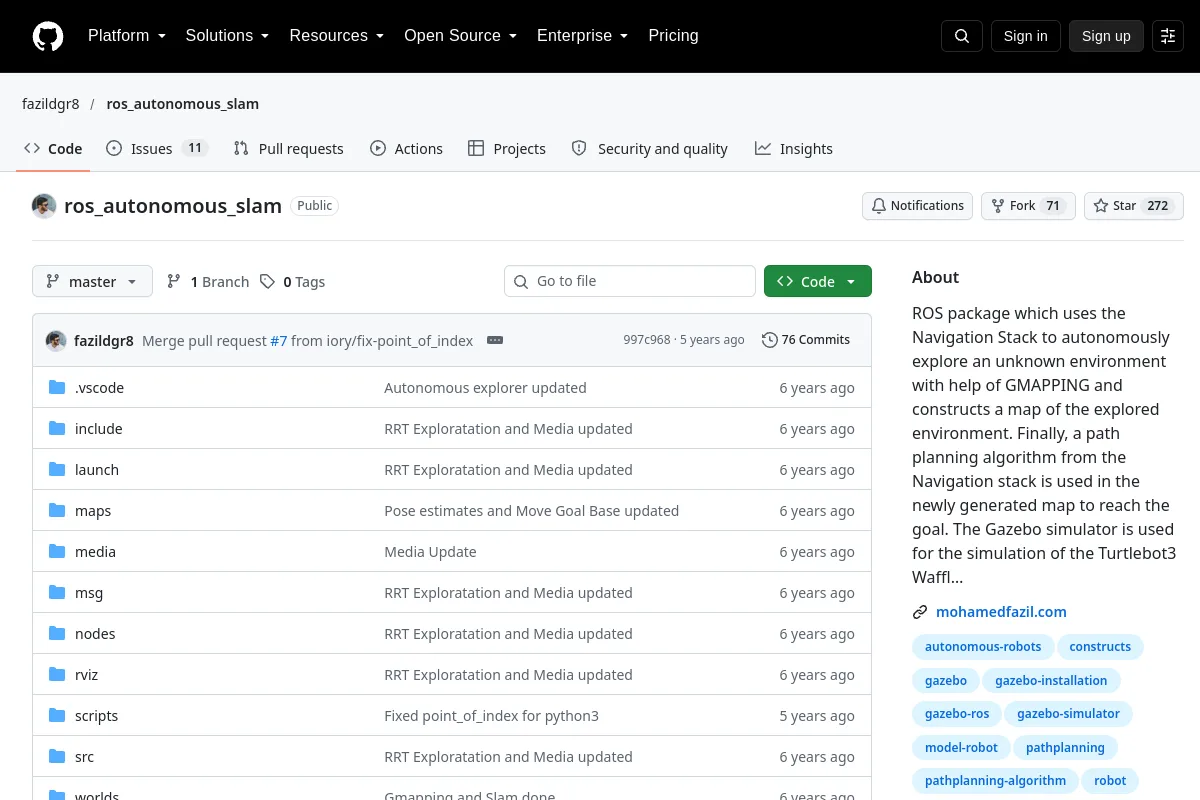
ROS package which uses the Navigation Stack to autonomously explore an unknown environment with help of GMAPPING and constructs a map of the explored environment. Finally, a path planning…
Overview
ROS package which uses the Navigation Stack to autonomously explore an unknown environment with help of GMAPPING and constructs a map of the explored environment. Finally, a path planning…
Publisher purpose: ROS package which uses the Navigation Stack to autonomously explore an unknown environment with help of GMAPPING and constructs a map of the explored environment. Finally, a path planning algorithm from the Navigation stack is used in the newly generated map to reach the goal. The Gazebo simulator is used for the simulation of the Turtlebot3 Waffle Pi robot. Various algorithms have been integrated for Autonomously exploring the region and constructing the map with help of the 360-degree Lidar sensor. Different environments can be swapped within launch files to generate a map of the environment.
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Project information
- Maintainer
- fazildgr8
- Primary language
- Python
- Repository code license
- MIT
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2022-05-26
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- ros_autonomous_slam
- There are three Main steps to be executed in this project.
- Follow the execution of the different Launch files to acheive the required tasks of each step. (Look below for Project prerequisites and setup)
- Step 1 : Place the Robot in the Environment within Gazebo
- Step 2 : Perform Autonomous exploration of the environment and generate the Map
- Setting Exploration region for RRT in RVIZ Window ([More Details](http://wiki.ros.org/rrt_exploration/Tutorials/singleRobot))
Browse this resource’s categories
Explore related collections
Browse Software →More in Software
Repository
 Repository