 Repository
Software / Research
SLAM application · engcang
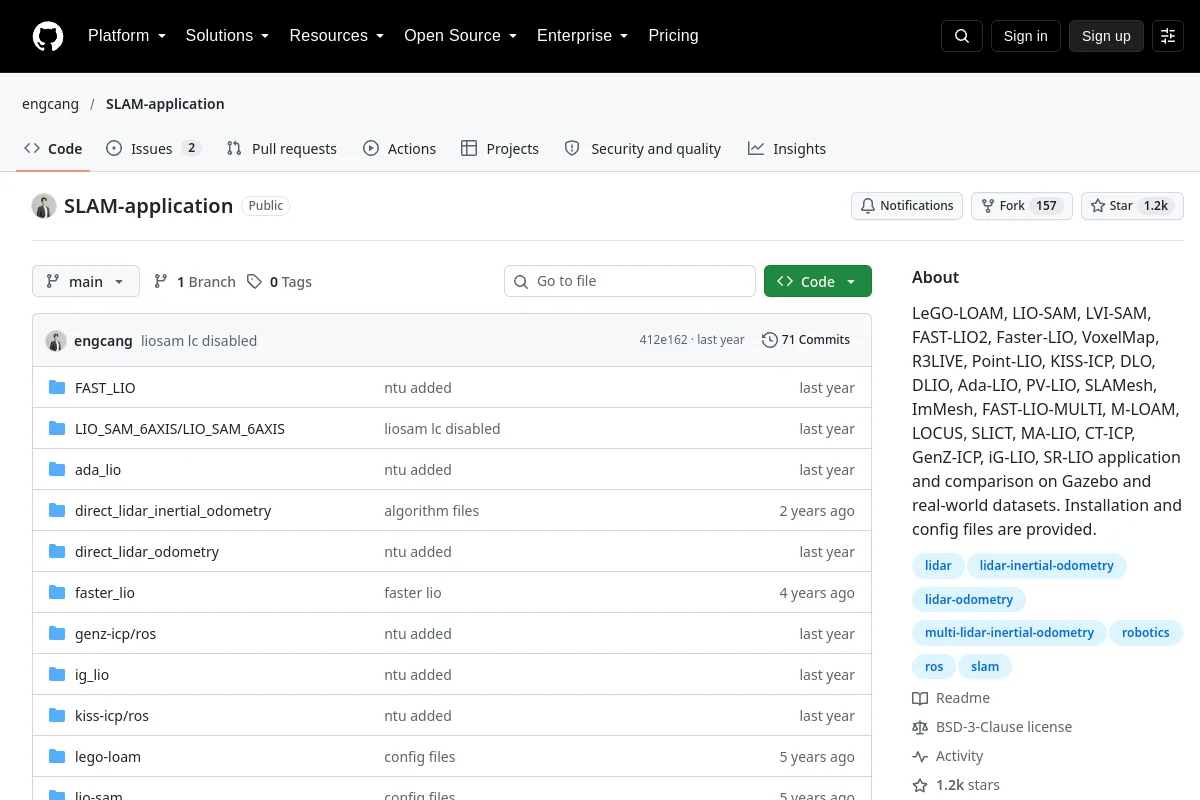
SLAM-application collects installation and testing resources for LiDAR and visual-inertial SLAM systems.
Overview
SLAM-application collects installation and testing resources for LiDAR and visual-inertial SLAM systems.
Publisher summary: “LeGO-LOAM, LIO-SAM, LVI-SAM, FAST-LIO2, Faster-LIO, VoxelMap, R3LIVE, Point-LIO, KISS-ICP, DLO, DLIO, Ada-LIO, PV-LIO, SLAMesh, ImMesh, FAST-LIO-MULTI, M-LOAM, LOCUS, SLICT, MA-LIO, CT-ICP, GenZ-ICP, iG-LIO, SR-LIO…”
Use its repository to inspect the implementation, documentation and supported workflows. This directory record identifies the maintainer, code license and related resources; it does not claim that the project has been installed or tested on your robot.
Project information
- Maintainer
- engcang
- Primary language
- C++
- Repository code license
- BSD-3-Clause
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2025-01-31
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- SLAM-application: installation and test
- Results:
- ● Single-LiDAR
- ● Multi-LiDARs
- Dependencies
- 🌟🌟🌟 Note: Ouster-ros package cannot be built with gcc and g++ with the version higher than 6,
Browse this resource’s categories
Explore related collections
Browse Software →More in Software
Repository
 Repository
 Open source
KISS-ICP
A LiDAR odometry pipeline built around point-cloud registration.
Navigation & SLAM Repository
 Research
Kalibr
Calibration tools for multi-camera and camera-inertial systems.
Perception & geometry Repository
 Open source
FAST-LIO
LiDAR-inertial odometry tools for mobile robotic state estimation.
Navigation & SLAM Repository
 Repository