 Repository
Software / Open source
SplaTAM · spla-tam
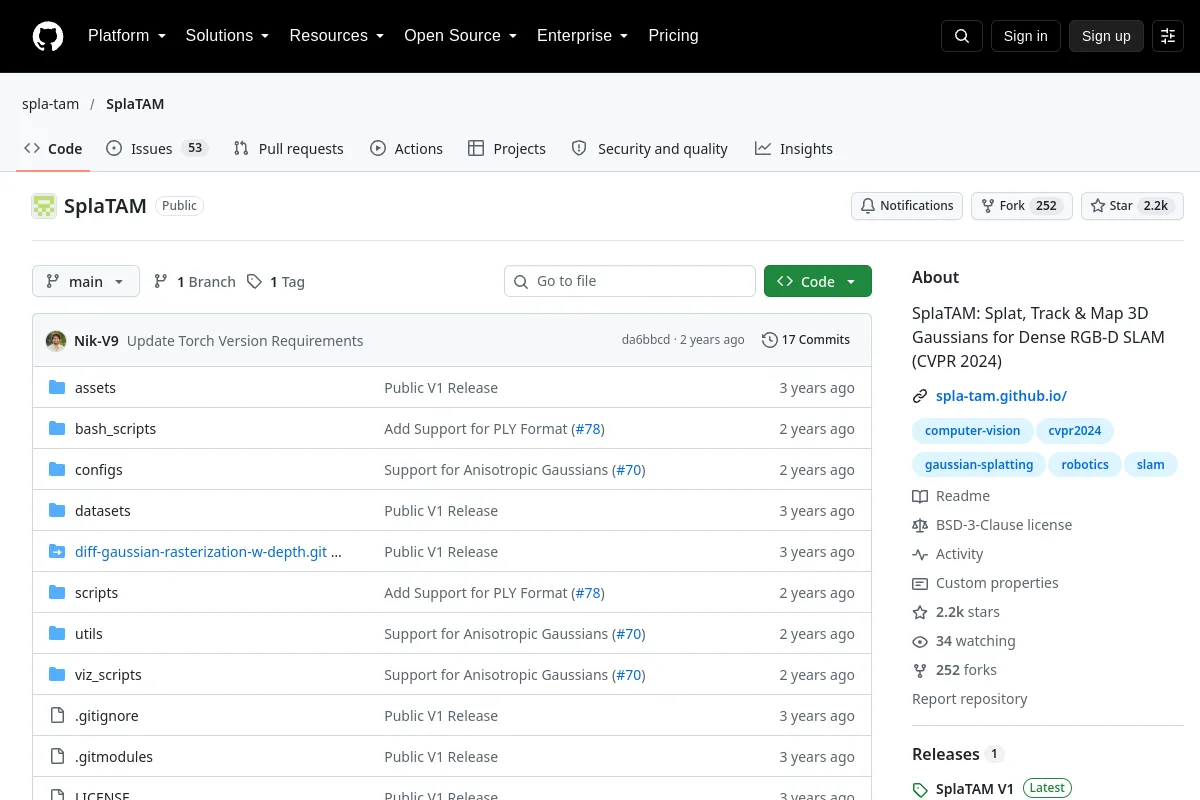
SplaTAM: Splat, Track & Map 3D Gaussians for Dense RGB-D SLAM (CVPR 2024)
Overview
SplaTAM: Splat, Track & Map 3D Gaussians for Dense RGB-D SLAM (CVPR 2024)
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Project information
- Maintainer
- spla-tam
- Primary language
- Python
- Repository code license
- BSD-3-Clause
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2024-06-19
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- Stay Tuned for a Faster and Better Variant of SplaTAM!
- Installation
- Windows
- Docker and Singularity Setup
- Demo
- Online
Browse this resource’s categories
Explore related collections
Browse Software →More in Software
Repository
 Repository
 Research
gaussian splatting · graphdeco-inria
Reference implementation of 3D Gaussian Splatting for radiance-field rendering.
Perception & geometry Repository
 Open source
Point-SLAM · eriksandstroem
Point-SLAM: Dense Neural Point Cloud-based SLAM
Navigation & SLAM Repository
 Open source
gradslam · gradslam
gradslam is an open source differentiable dense SLAM library for PyTorch
Navigation & SLAM Repository