 Repository
 Open source
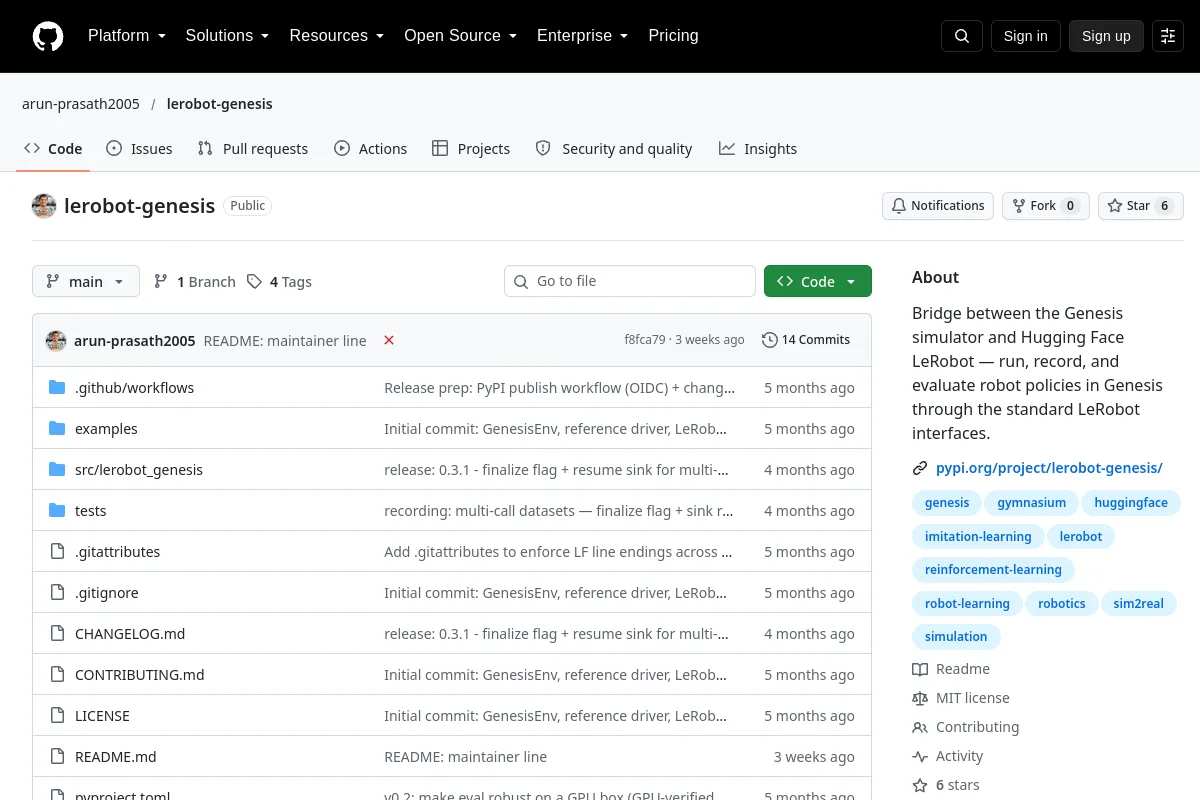
lerobot genesis · arun-prasath2005
A Genesis–LeRobot bridge for running, recording and evaluating robot policies.
Simulation & physicsTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
A Genesis–LeRobot bridge for running, recording and evaluating robot policies.
Simulation & physics Repository
 Open source
Lightweight interface for controlling ROS-based robotic arms using LeRobot
Robot learning frameworks Repository
 Open source
Community imitation-learning and RL workflows for a real SO-101 arm.
Robot learning frameworks Repository
 Research
Code for LGX (Language Guided Exploration). We use LLMs to perform embodied robot navigation in a zero-shot manner.
Navigation & SLAM Repository
 Open source
Iterative closest-point library for 2D and 3D robotic mapping.
Navigation & SLAM Repository
 Open source
A differential drive robot is controlled using ROS2 Jazzy running on a Raspberry Pi 4 (running Ubuntu Server 24.04). The vehicle is equipped with a Raspberry Pi camera for visual feedback and an…
Navigation & SLAM Repository
 Open source
3D LIDAR Localization using pointcloud map in ROS 2 (Not SLAM)
Navigation & SLAM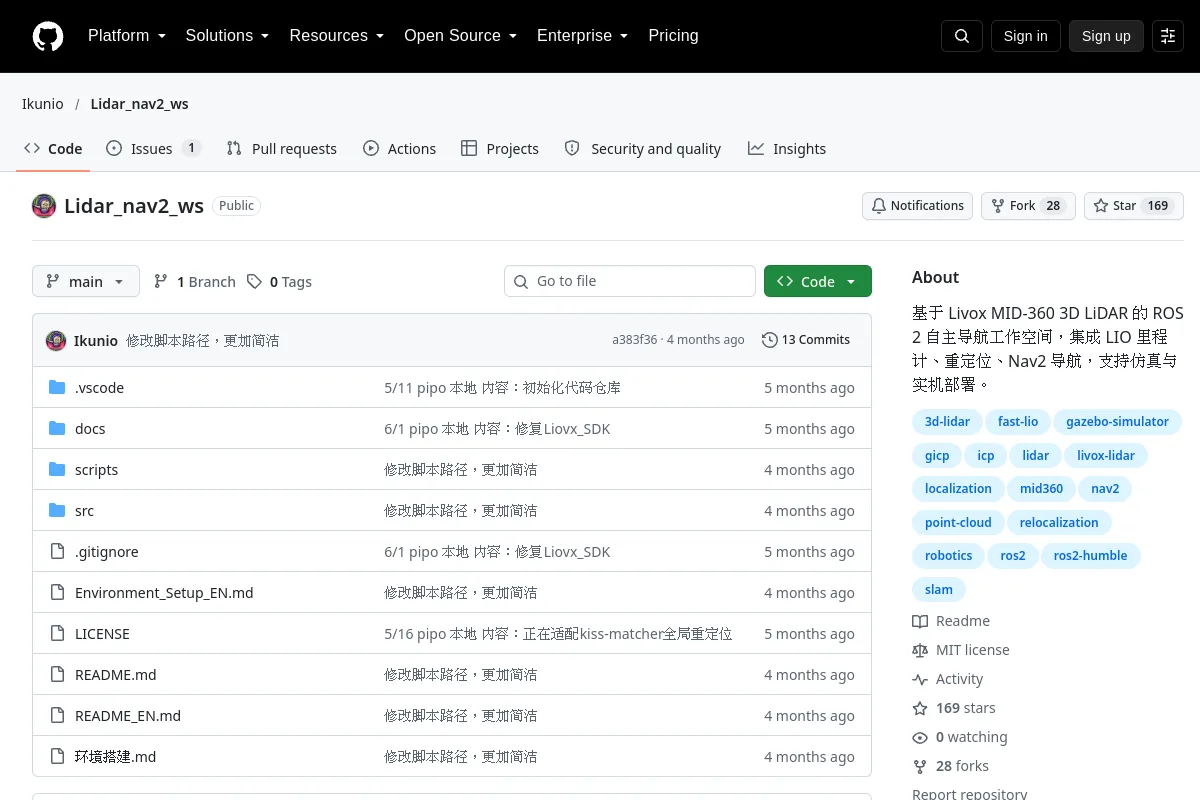 Repository
 Open source
A ROS 2 navigation workspace combining LiDAR-inertial odometry, relocalization and Nav2.
Navigation & SLAM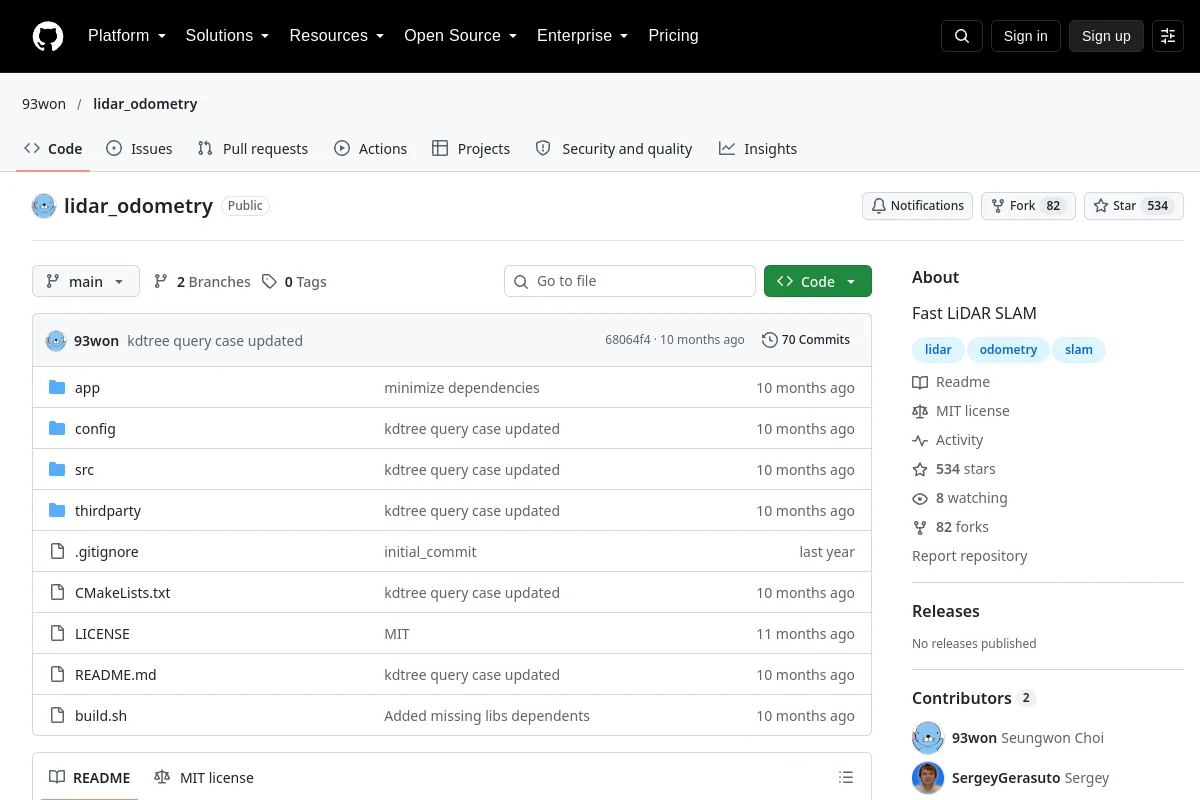 Repository
 Repository
 Open source
LSD (LiDAR SLAM & Detection) is an open source perception architecture for autonomous vehicle/robotic
Navigation & SLAM Repository
 Open source
Tools to compose, validate and compile URDF, XACRO and SRDF models.
Motion planning & control Repository
 Open source
Linux process isolation using unshare, with ROS use cases.
Robot learning frameworks Repository
 Open source
Linux and Docker setup guidance for real-time ROS applications.
Motion planning & control Repository
 Open source
A simple system that can relocalize a robot on a built map is developed in this system. The system is based on LIO-SAM.
Navigation & SLAM Repository
 Open source
ROS 2 package of tightly-coupled lidar inertial ndt/gicp slam
Navigation & SLAM Repository
 Open source
Toolkit for commanding robots through mixed interaction modalities.
Robot learning frameworks Repository
 Open source
LIV-Eye: A Low-Cost LiDAR-Inertial-Visual Fusion 3D Sensor for Robotics and Embodied AI.
Robot learning frameworks Repository
 Repository
 Research
LMFAO augments LeRobot demonstration videos with visual variations for robot learning.
Visualization & data tools Repository
 Open source
Perceptive Learning for Legged Robots in IsaacLab. | LocoTouch: Learning Dynamic Quadrupedal Transport with Tactile Sensing (CoRL'25)
Simulation & physics Repository
 Repository
 Open source
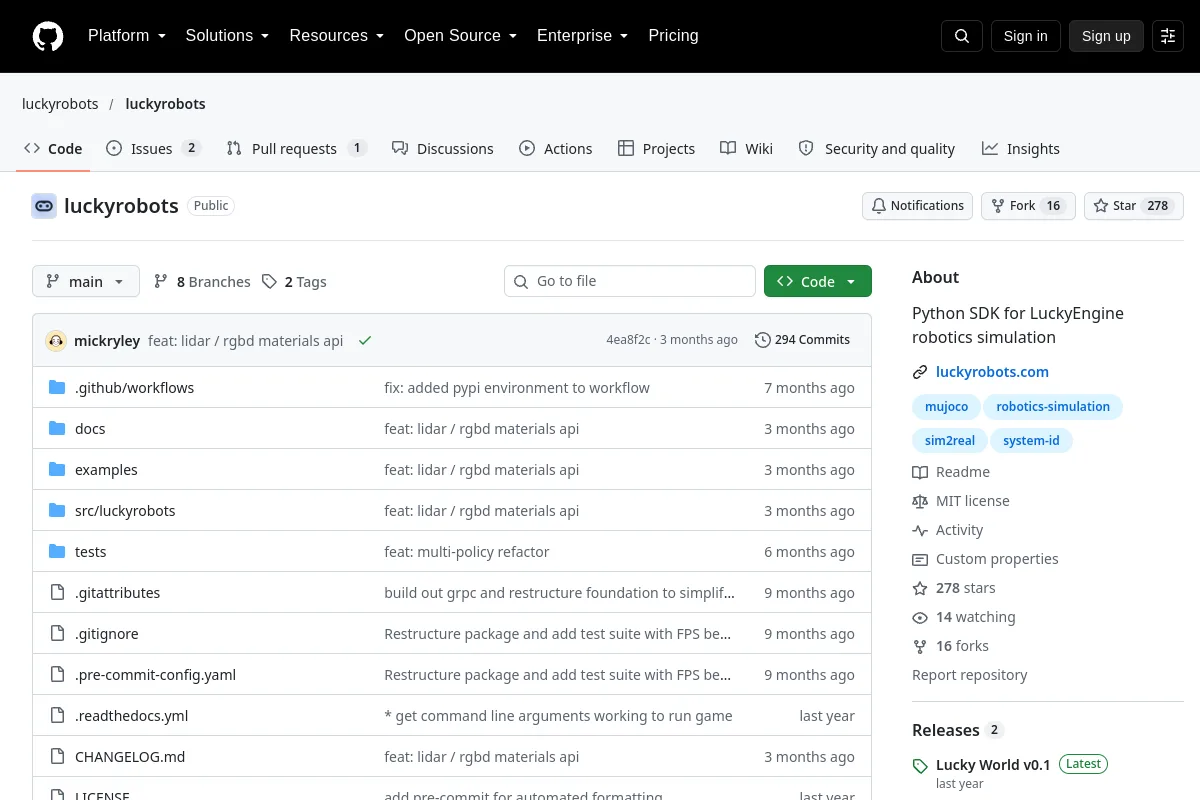
Python SDK for LuckyEngine robotics simulation
Simulation & physics Repository
 Open source
LLM-first, 3D-native robotics and simulation workspace.
Simulation & physics Repository
 Open source
Code for the IEEE Robotics and Automation Letters paper titled "Multi-Modal MPPI and Active Inference for Reactive Task and Motion Planning"
Motion planning & controlKnow a resource that belongs here?