 Repository
 Open source
differentiable robot model · facebookresearch
Differentiable robot manipulator models for learning dynamics and control.
Motion planning & controlTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
Differentiable robot manipulator models for learning dynamics and control.
Motion planning & control Repository
 Open source
URDF model of the Fanuc M-710iC manipulator.
Robot learning frameworks Repository
 Open source
ROS 2 integration stack for KUKA LBR IIWA and Med robot arms.
Robot learning frameworks Repository
 Research
ROS 1 URDF and Collada model assets for the Poppy Ergo Jr robot.
Robot learning frameworks Repository
 Research
ROS packages for Kinova Kortex robot arms.
Robot learning frameworks Repository
 Open source
ROS 2 developer packages for UFACTORY robot products.
Simulation & physics Repository
 Research
Additional indoor and outdoor simulation environments for Clearpath robots.
Simulation & physics Repository
 Open source
A learning roadmap for visual-SLAM development.
Navigation & SLAM Repository
 Research
An open robotic-mower upgrade project using RTK GPS.
Robot learning frameworks Repository
 Research
Vision-action pretraining on desktop data for transfer to embodied AI.
Perception & geometry Repository
 Research
Embodied question-answering environment and agent training code.
Robot learning frameworks Repository
 Research
Common utilities, packages, scripts, and testing infrastructure for Isaac ROS packages.
Robot SDKs Repository
 Open source
NVIDIA-accelerated ROS 2 packages for camera image processing.
Robot learning frameworks Repository
 Open source
Visual SLAM/odometry package based on NVIDIA-accelerated cuVSLAM
Navigation & SLAM Repository
 Repository
 Research
Robust Stereo Visual Inertial Odometry for Fast Autonomous Flight
Navigation & SLAM Repository
 Open source
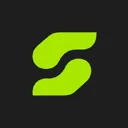
ROS 2 diagnostics gateway with a REST API for robot data and operations.
Fleet & autonomy systems Repository
 Open source
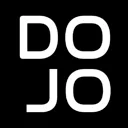
Differentiable physics engine for robotics, learning and control.
Motion planning & control Repository
 Open source
A powerful Isaac Sim extension for converting MuJoCo XML Configuration Format (MJCF) files to Universal Scene Description (USD) format
Simulation & physics Repository
 Open source
Official Repository of “MotionTrans: Human VR Data Enable Motion-Level Learning for Robotic Manipulation Policies"
Robot learning frameworks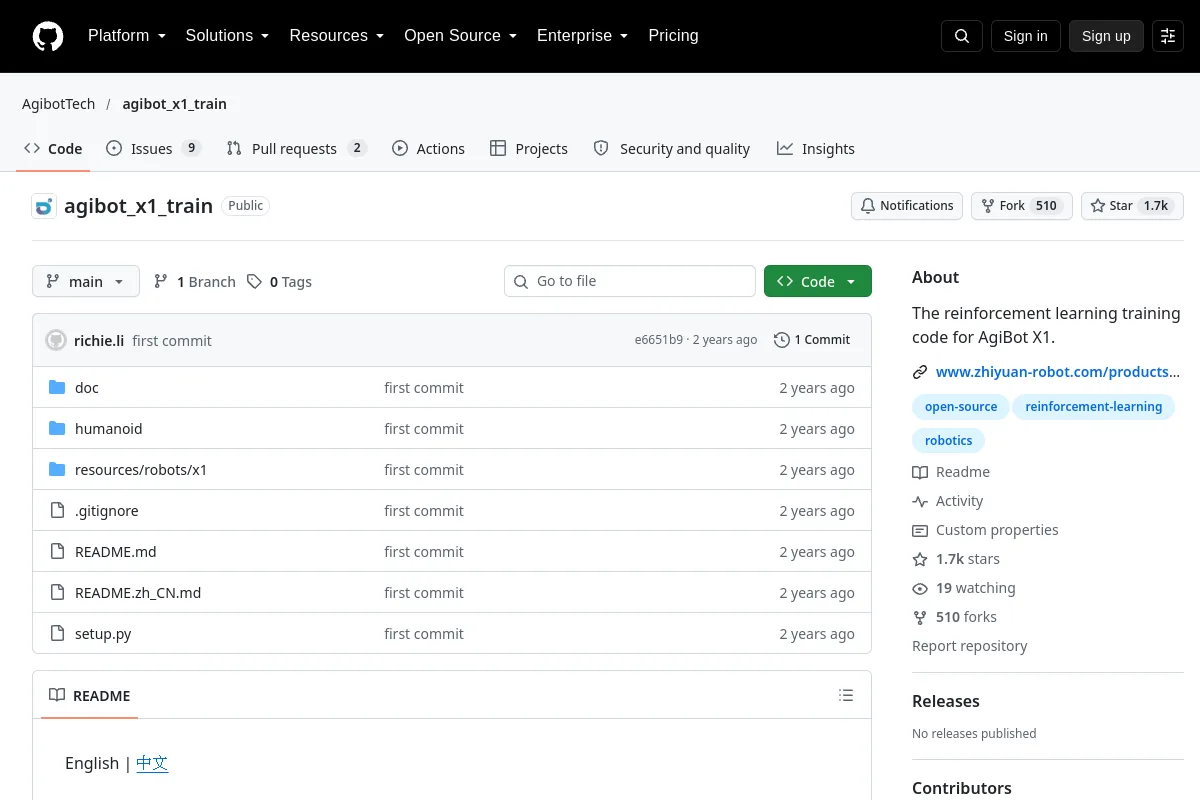 Repository
 Research
Reinforcement-learning training code for AgiBot X1.
Robot learning frameworks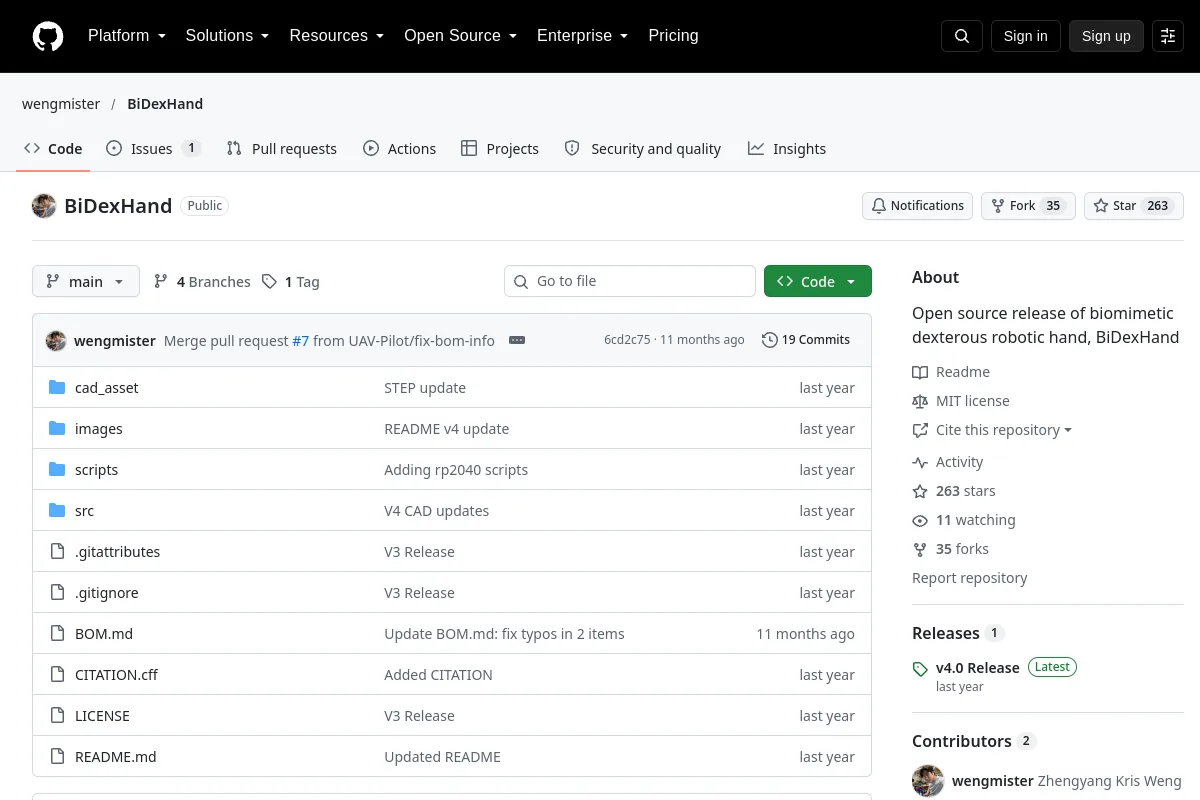 Repository
 Open source
Hardware and software resources for a biomimetic dexterous robotic hand.
Robot learning frameworks Repository
 Open source
CoSLAM is a visual SLAM software that aims to use multiple freely moving cameras to simultaneously compute their egomotion and the 3D map of the surrounding scenes in a highly dynamic environment.
Navigation & SLAM Repository
 Open source
RGB-D Encoder SLAM for a Differential-Drive Robot in Dynamic Environments
Navigation & SLAMKnow a resource that belongs here?