 Repository
 Open source
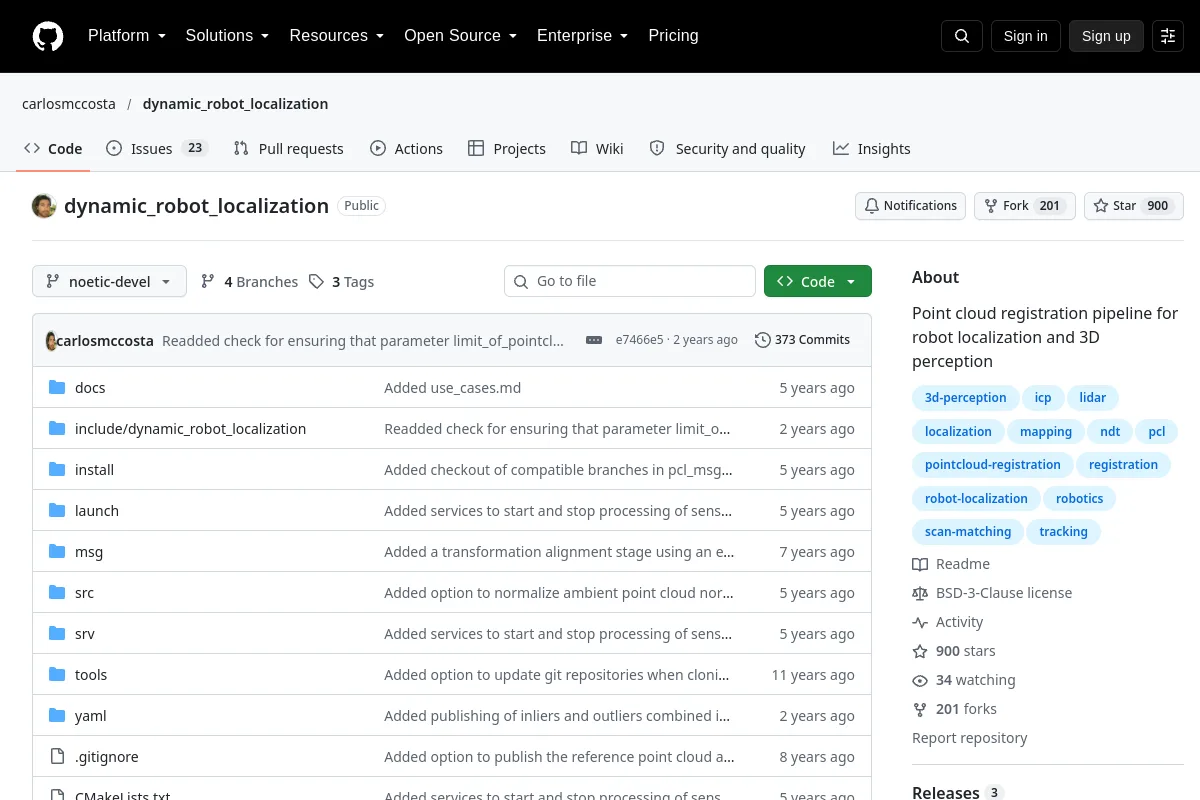
dynamic robot localization · carlosmccosta
A point-cloud registration pipeline for robot localization and 3D perception.
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Explore mapping, localization, odometry and navigation software for autonomous robots.
Repository
Open source
A point-cloud registration pipeline for robot localization and 3D perception.
Navigation & SLAM Repository
 Open source
Master's Thesis on Simultaneous Localization and Mapping in dynamic environments. Separately reconstructs both the static environment and the dynamic objects from it, such as cars.
Navigation & SLAM Repository
 Open source
Robot-centric elevation mapping for rough-terrain navigation.
Navigation & SLAM Repository
 Open source
Research code for scene imagination and efficient robotic exploration.
Navigation & SLAM Repository
 Open source
ROS 2 localization for outdoor robots: IMU, wheel encoders and GPS fused in a 23-state UKF at 100 Hz. When the estimate goes wrong it reports which sensor and why, instead of drifting silently.…
Navigation & SLAM Repository
 Open source
Gaussian-SLAM: Photo-realistic Dense SLAM with Gaussian Splatting
Navigation & SLAM Repository
 Open source
Modern C++20 GNSS toolkit — RTK/PPP/CLAS/IMU fusion.
Navigation & SLAM Repository
 Open source
Hierarchical RL for interactive navigation with mobile manipulators.
Navigation & SLAM Repository
 Open source
HybVIO visual-inertial odometry and SLAM system
Navigation & SLAM Repository
 Open source
This package provides localization in a pre-built map using ICP and odometry (or the IMU measurements).
Navigation & SLAM Repository
 Open source
ROS 2 implementation of a Teleoperated robot with live video feed using webrtc and SLAM using realsense's stereocameras. Running on a Jetson Nano
Navigation & SLAM Repository
 Open source
Visual Inertial Odometry with SLAM capabilities and 3D Mesh generation.
Navigation & SLAM Repository
 Open source
A LiDAR odometry pipeline for wheeled mobile robots
Navigation & SLAM Repository
 Repository
 Open source
Iterative closest-point library for 2D and 3D robotic mapping.
Navigation & SLAM Repository
 Open source
A differential drive robot is controlled using ROS2 Jazzy running on a Raspberry Pi 4 (running Ubuntu Server 24.04). The vehicle is equipped with a Raspberry Pi camera for visual feedback and an…
Navigation & SLAM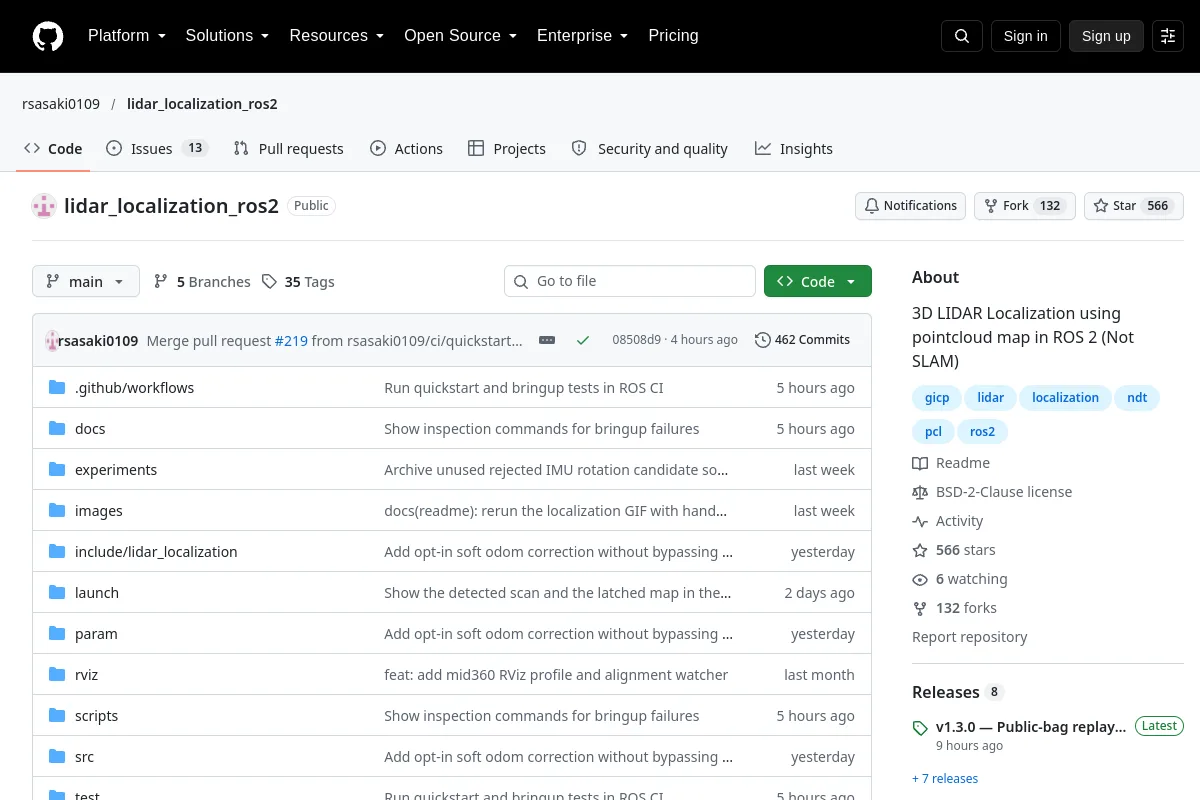 Repository
 Open source
3D LIDAR Localization using pointcloud map in ROS 2 (Not SLAM)
Navigation & SLAM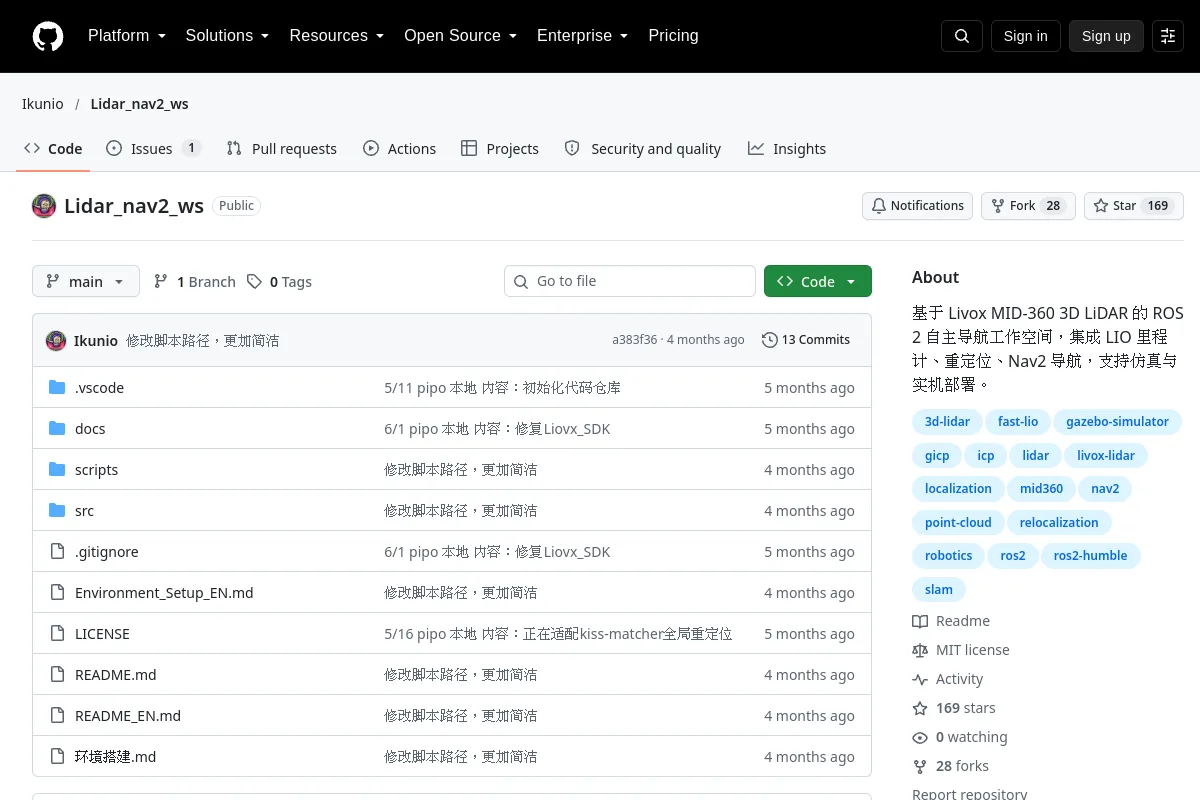 Repository
 Open source
A ROS 2 navigation workspace combining LiDAR-inertial odometry, relocalization and Nav2.
Navigation & SLAM Repository
 Repository
 Open source
LSD (LiDAR SLAM & Detection) is an open source perception architecture for autonomous vehicle/robotic
Navigation & SLAM Repository
 Open source
A simple system that can relocalize a robot on a built map is developed in this system. The system is based on LIO-SAM.
Navigation & SLAM Repository
 Open source
ROS 2 package of tightly-coupled lidar inertial ndt/gicp slam
Navigation & SLAM Repository
 Open source
My End-of-Degree thesis. Visual SLAM, DL, 3D sparse and dense maps and Computer Vision.
Navigation & SLAM Repository
 Open source
A ROS package for probabilistic mobile-robot localization with 3D lidar.
Navigation & SLAMSELECTION NOTES
Match sensors, coordinate frames and localization assumptions to the deployment environment. Mapping, pose estimation, path planning and obstacle avoidance serve different parts of the navigation stack.
Know a resource that belongs here?