 Repository
 Open source
Unity-RL-Playground · loongOpen
Reinforcement Learning & Robot Simulation & Embodied Intelligence
Simulation & physicsTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
Reinforcement Learning & Robot Simulation & Embodied Intelligence
Simulation & physics Repository
 Open source
Using the repository
Simulation & physics Repository
 Open source
URDF and Xacro model descriptions for Upkie wheeled bipeds.
Robot learning frameworks Repository
 Open source
ROS-based Universal Robots (e.g., UR3/e UR5/5, ...) with simulation in Gazebo.
Simulation & physics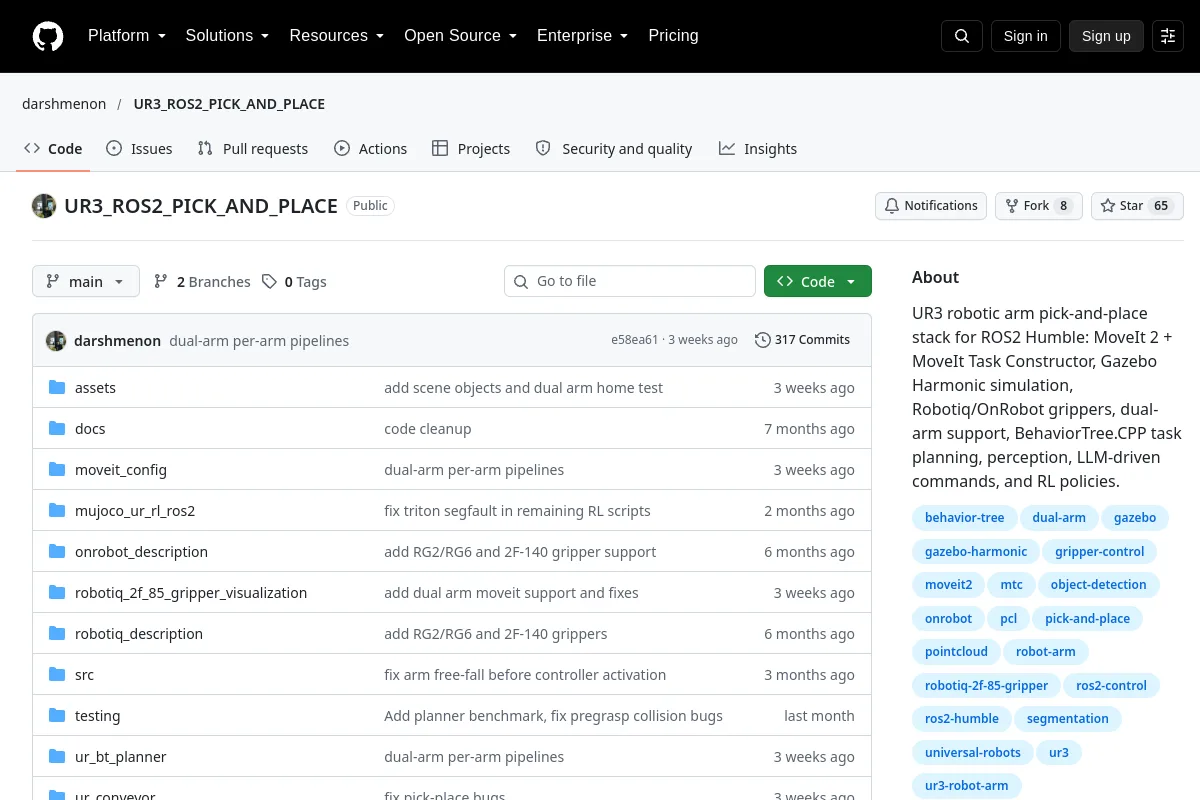 Repository
 Open source
UR3 robotic arm pick-and-place stack for ROS2 Humble: MoveIt 2 + MoveIt Task Constructor, Gazebo Harmonic simulation, Robotiq/OnRobot grippers, dual-arm support, BehaviorTree.CPP task planning…
Simulation & physics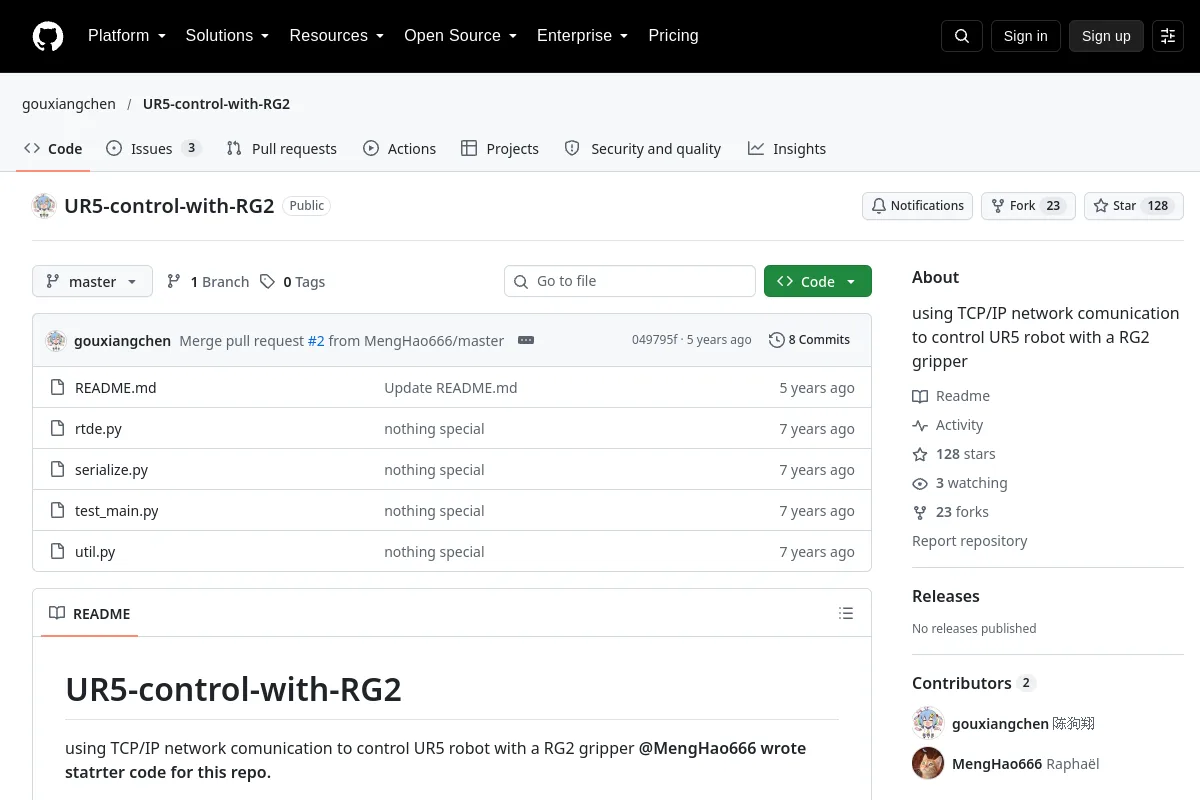 Repository
 Research
using TCP/IP network comunication to control UR5 robot with a RG2 gripper
Robot SDKs Repository
 Research
This is a project about robotic manipulation motion planning using deep reinforcement learning based on ROS and Gazebo simulation
Motion planning & control Repository
 Open source
This project simulates a UR5 robotic arm with a Robotiq 85 gripper, performing autonomous object grasping and placement tasks in the PyBullet environment.
Simulation & physics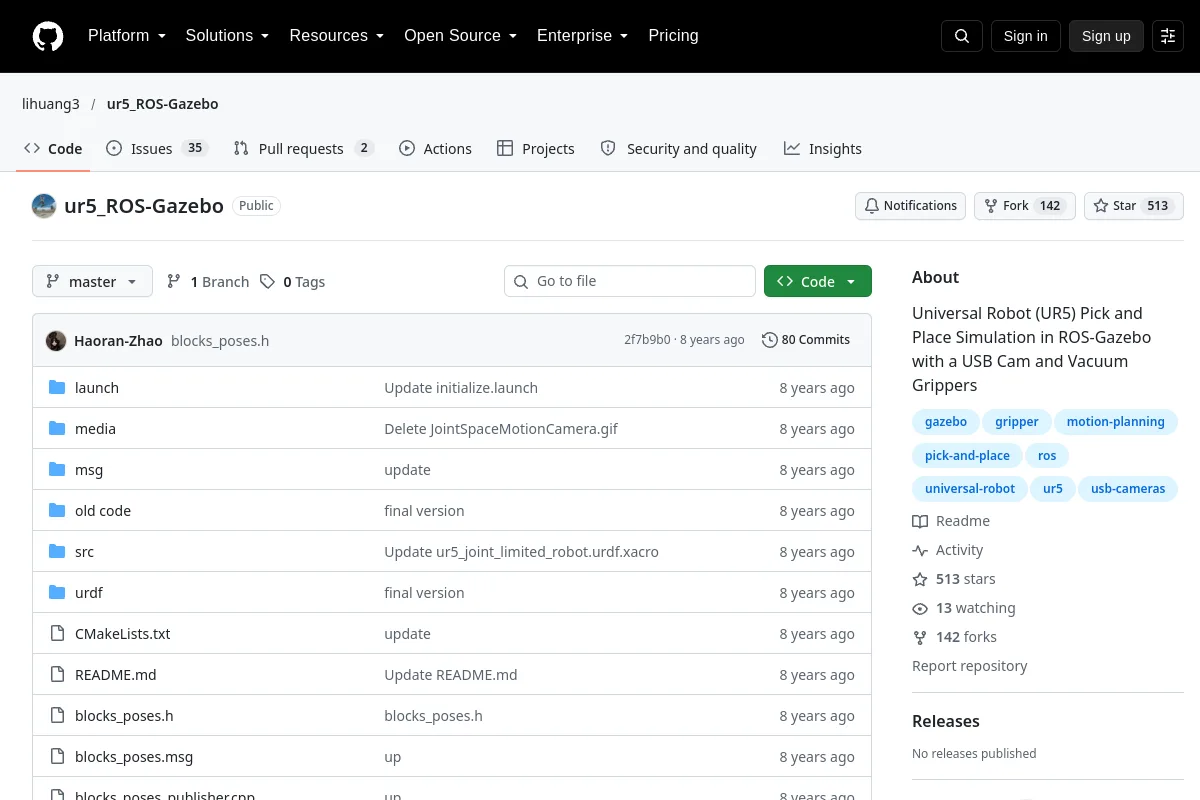 Repository
 Research
Universal Robot (UR5) Pick and Place Simulation in ROS-Gazebo with a USB Cam and Vacuum Grippers
Simulation & physics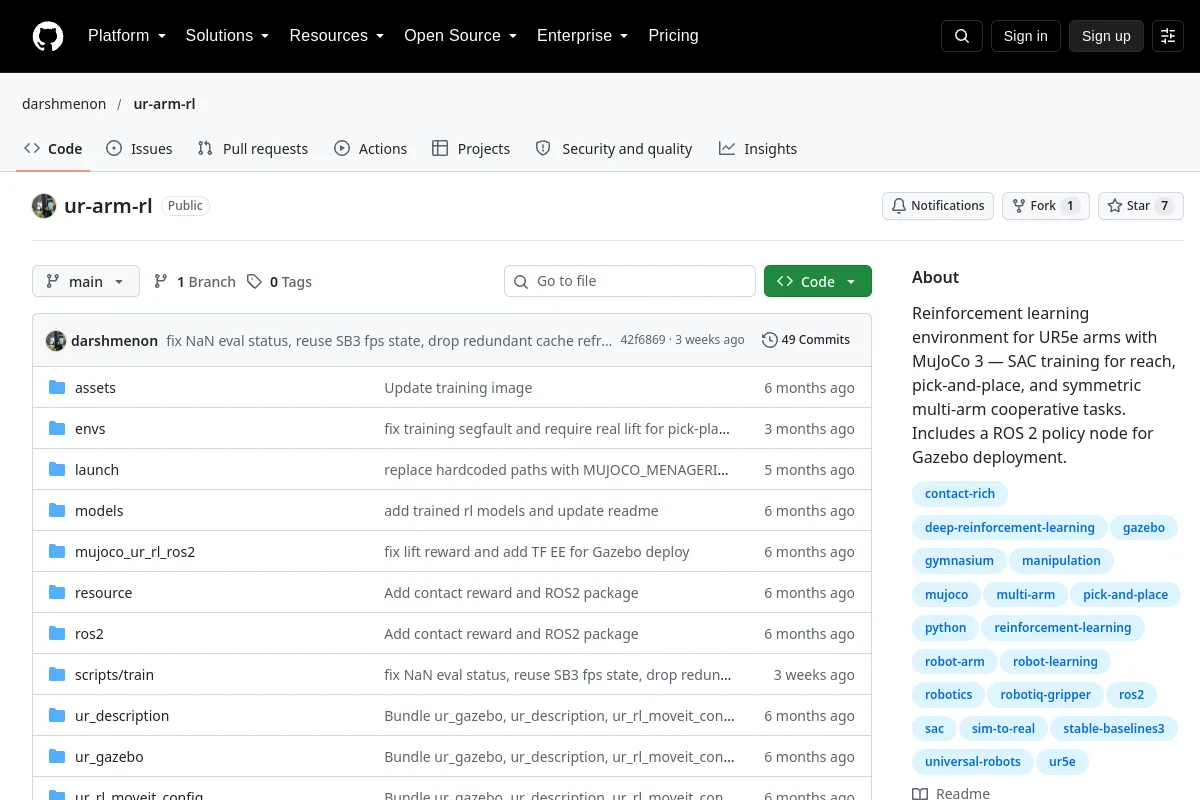 Repository
 Research
MuJoCo reinforcement learning environments for UR5e reaching and manipulation.
Simulation & physics Repository
 Open source
Official implementation of paper "UrbanNav: Learning Language-Guided Embodied Urban Navigation from Web-Scale Human Trajectories."
Navigation & SLAM Repository
 Open source
Web-based URDF robot-model editor with 3D visualization and export workflows.
Simulation & physics Repository
 Open source
Historical reference: (deprecated) ROS 1 driver for CB1 and CB2 controllers with UR5 or UR10 robots from Universal Robots
Motion planning & control Repository
 Research
Reinforcement learning using rlkit, UR5, Robotiq gripper on ROS(Robot Operating System)
Middleware & communication Repository
 Open source
Research implementation of visual embodied reasoning and control with multimodal models.
Motion planning & control Repository
 Repository
 Open source
A Collision Avoidance and Path Planning Framework implemented for a dual arm Pick and Place robot task simulation. Velocity Obstacles and RRTStar Motion Planner are used in the algorithm to plan…
Simulation & physics Repository
 Research
Ventura research code for task-conditioned navigation with diffusion models.
Navigation & SLAM Repository
 Research
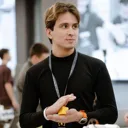
ViKi converts human RGB-D demonstrations into retargeted robot motions and LeRobot datasets.
Teleoperation software Repository
 Open source
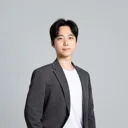
VINS-Fusion, VINS-Fisheye, OpenVINS, EnVIO, ROVIO, S-MSCKF, ORB-SLAM2, NVIDIA Elbrus application of different sets of cameras and imu on different board including desktop and Jetson boards
Navigation & SLAM Repository
 Open source
Open-Source Millimeter-Wave Radar Simulation Framework by Institute of Smart System Technologies, University of Klagenfurt and Institute of Mechatronics and Robotics, JOANNEUM RESEARCH
Simulation & physics Repository
 Research
The Visibility-Aware RRT* implementation for safety-critical navigation with perception-limited robots.
Navigation & SLAM Repository
 Research
Toolkit for vision-guided quadruped locomotion, with simulation and deployment workflows.
Perception & geometry Repository
 Open source
An open L2 driver-assistance stack using end-to-end AI.
Fleet & autonomy systemsKnow a resource that belongs here?