 Repository
 Research
visp · lagadic
Visual servoing platform for perception-based motion control.
Perception & geometryTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Research
Visual servoing platform for perception-based motion control.
Perception & geometry Repository
 Research
 references for visual and semantic SLAM.
Navigation & SLAM Repository
 Research
Vitruvio is a framework for rapid leg design analysis and optimization for legged robots. The purpose of the simulation framework is to guide the early stages of legged robot design. The end…
Simulation & physics Repository
 Open source
A mission planner and visualizer for controlling outdoor ROS robots.
Visualization & data tools Repository
 Open source
VLink is a high-performance C++ communication middleware for autonomous driving and embodied intelligence, positioned as a full-scenario alternative to ROS 2.
Middleware & communication Repository
 Research
Modular perception, grasp planning, tracking, and sorting pipeline for ML robotics
Perception & geometry Repository
 Open source
Variational neural-belief research for dexterous grasping.
Motion planning & control Repository
 Open source
Voxel mapping library for truncated and Euclidean signed distance fields.
Navigation & SLAM Repository
 Open source
A navigation system for outdoor robotics in rough uneven terrains.
Navigation & SLAM Repository
 Research
Learning Robotics by Playing with V-REP
Simulation & physics Repository
 Open source
An open-source VR teleoperation kit for the TRLC-DK1, driving the arms from a Meta Quest headset with inverse kinematics and a drop-in LeRobot teleoperator.
Teleoperation software Repository
 Open source
Bipedal locomotion software for the humanoid robot platform iCub.
Motion planning & control Repository
 Research
Sim-to-real RL training and deployment tools for the Unitree Go1 robot.
Robot learning frameworks Repository
 Open source
Wanderland: Geometrically Grounded Simulation for Open-World Embodied AI
Simulation & physics Repository
 Open source
Multi-resolution 3D occupancy mapping from multiple sensors.
Navigation & SLAM Repository
 Open source
Whole-Body Nonlinear MPC for Realtime Humanoid Loco-Manipulation Planning and Control
Motion planning & control Website
 Research
A robot simulation environment with sensor models and controller interfaces.
Simulation & physics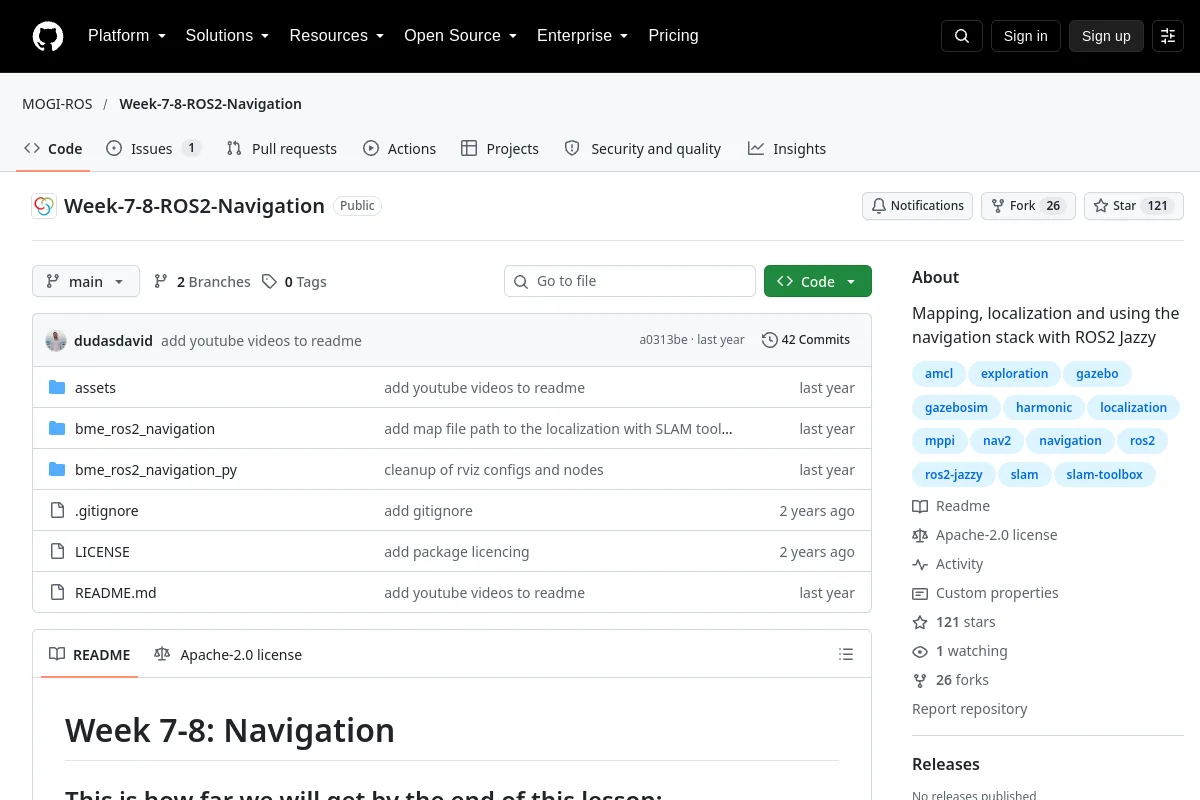 Repository
 Open source
Mapping, localization and using the navigation stack with ROS2 Jazzy
Navigation & SLAM Repository
 Research
Isaac Lab environments and workflows for mobile robotics.
Robot learning frameworks Repository
 Repository
 Research
Robotics MOM and RPC middleware wrapper with deep-learning framework integration
Middleware & communication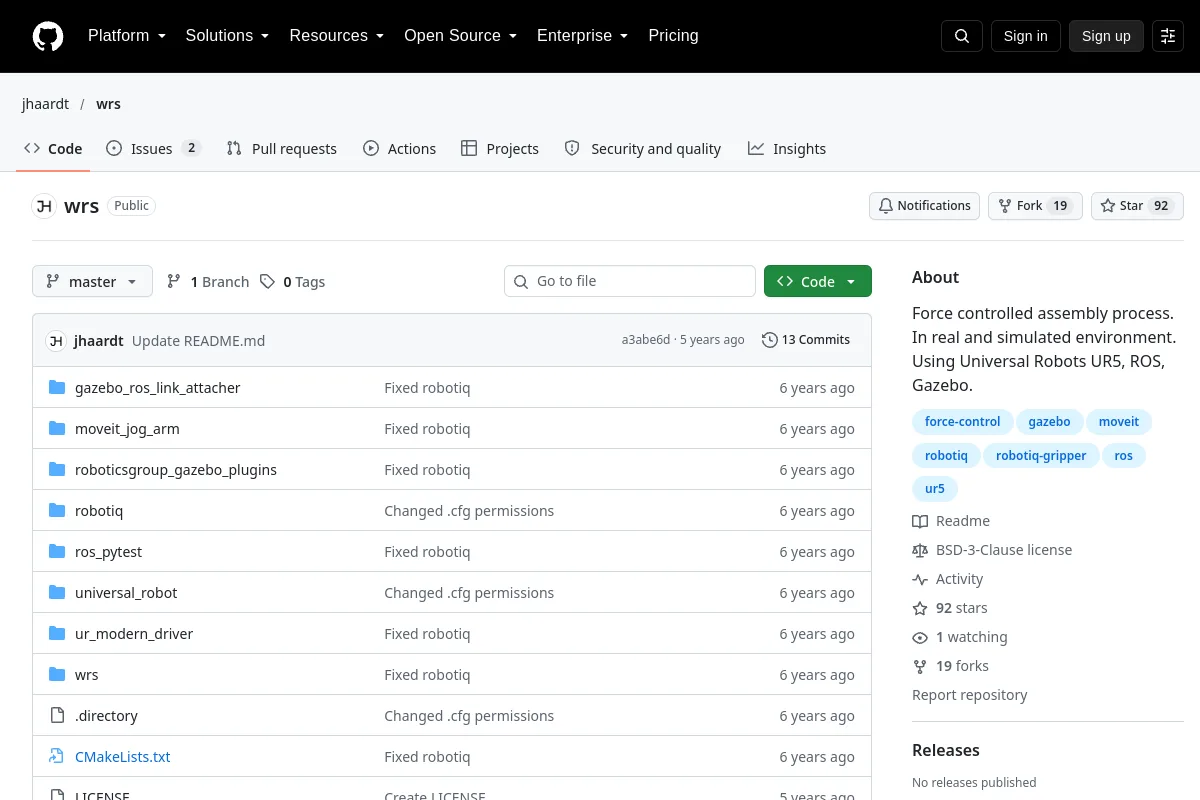 Repository
 Open source
Force controlled assembly process. In real and simulated environment. Using Universal Robots UR5, ROS, Gazebo.
Simulation & physics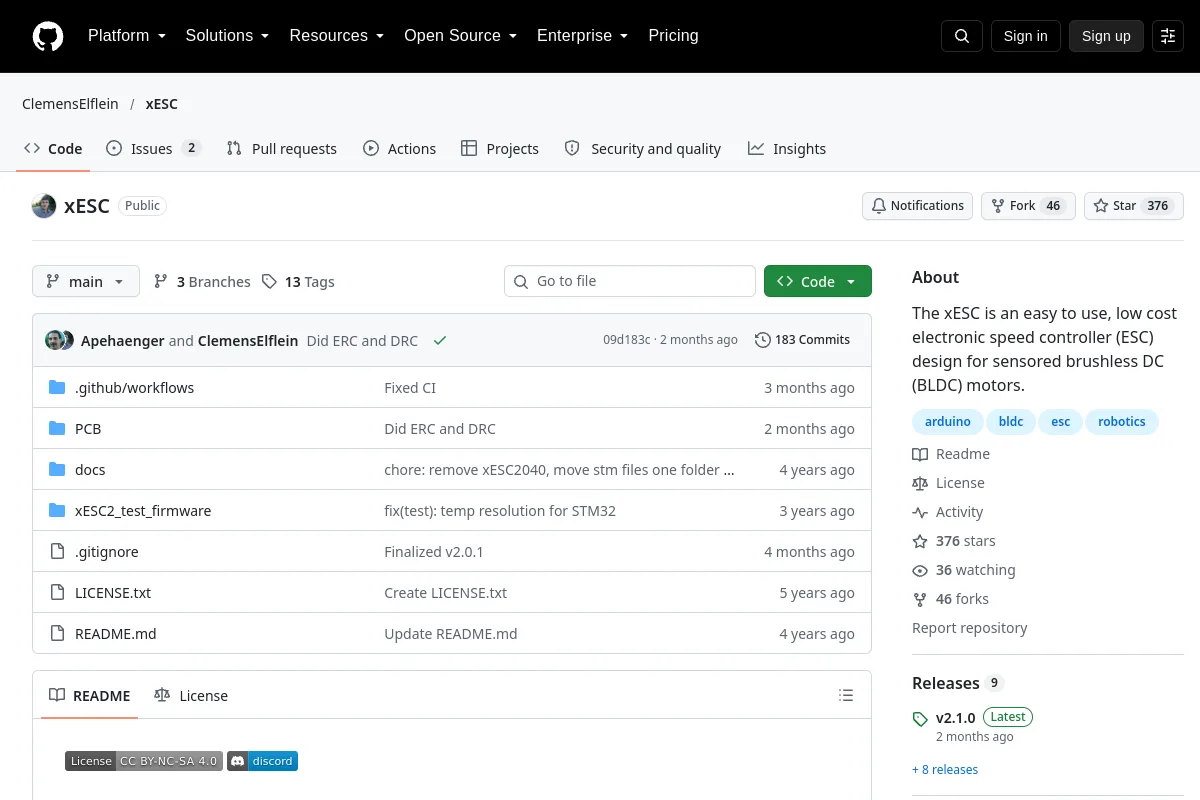 Repository
 Research
An electronic speed-controller design for sensored BLDC motors.
Motion planning & control Repository
 Research
XR-device teleoperation tools for Unitree humanoid robots.
Teleoperation softwareKnow a resource that belongs here?