 Repository
THE EMBODIED AI DIRECTORY
Software
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
 Repository
 Open source
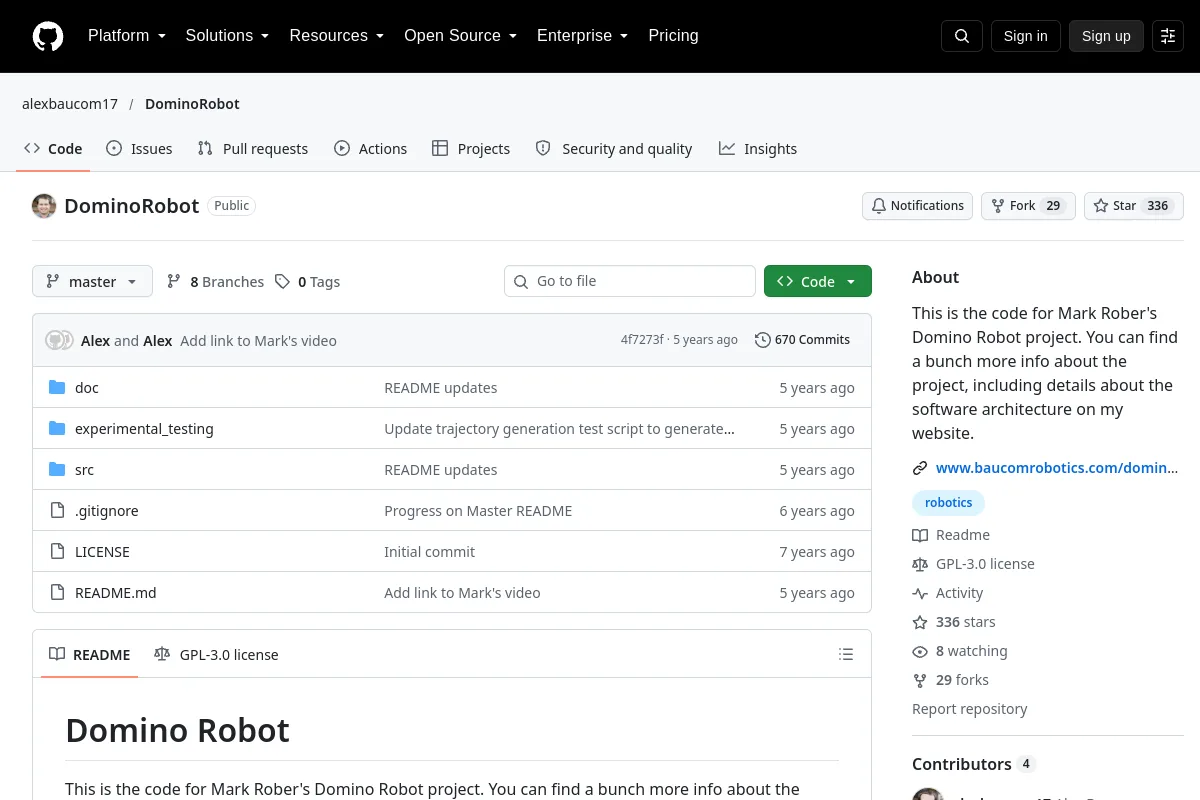
DominoRobot · alexbaucom17
Software for Mark Rober's Domino Robot project.
Robot learning frameworks Repository
 Research
dqn navigation · am-shb
A reinforcement-learning navigation agent using lidar and camera observations.
Navigation & SLAM Repository
 Open source
draco3 description · shbang91
URDF model of the Draco3 humanoid robot.
Robot learning frameworks Website
 Repository
 Open source
dreamer-pytorch · juliusfrost
Dream to Control: Learning Behaviors by Latent Imagination, implemented in PyTorch.
Robot learning frameworks Repository
 Open source
drl grasping · AndrejOrsula
Deep reinforcement-learning experiments for robotic grasping from octrees.
Simulation & physics Repository
 Open source
DRL_robot_exploration · RobustFieldAutonomyLab
Self-Learning Exploration and Mapping for Mobile Robots via Deep Reinforcement Learning
Navigation & SLAM Repository
 Open source
DROID-Splat · ChenHoy
End-to-End SLAM with camera calibration, monocular prior integration and dense Rendering
Navigation & SLAM Repository
 Research
dr soro · andreaprotopapa
Domain-randomization experiments for closed-loop soft-robot control.
Motion planning & control Repository
 Open source
DSP-SLAM · JingwenWang95
DSP-SLAM: Object Oriented SLAM with Deep Shape Priors
Navigation & SLAM Repository
 Open source
Dstar-lite-pathplanner · Sollimann
Implementation of the D* lite algorithm in Python for "Improved Fast Replanning for Robot Navigation in Unknown Terrain"
Navigation & SLAM Repository
 Open source
dwa planner · amslabtech
A ROS implementation of the Dynamic Window Approach planner.
Navigation & SLAM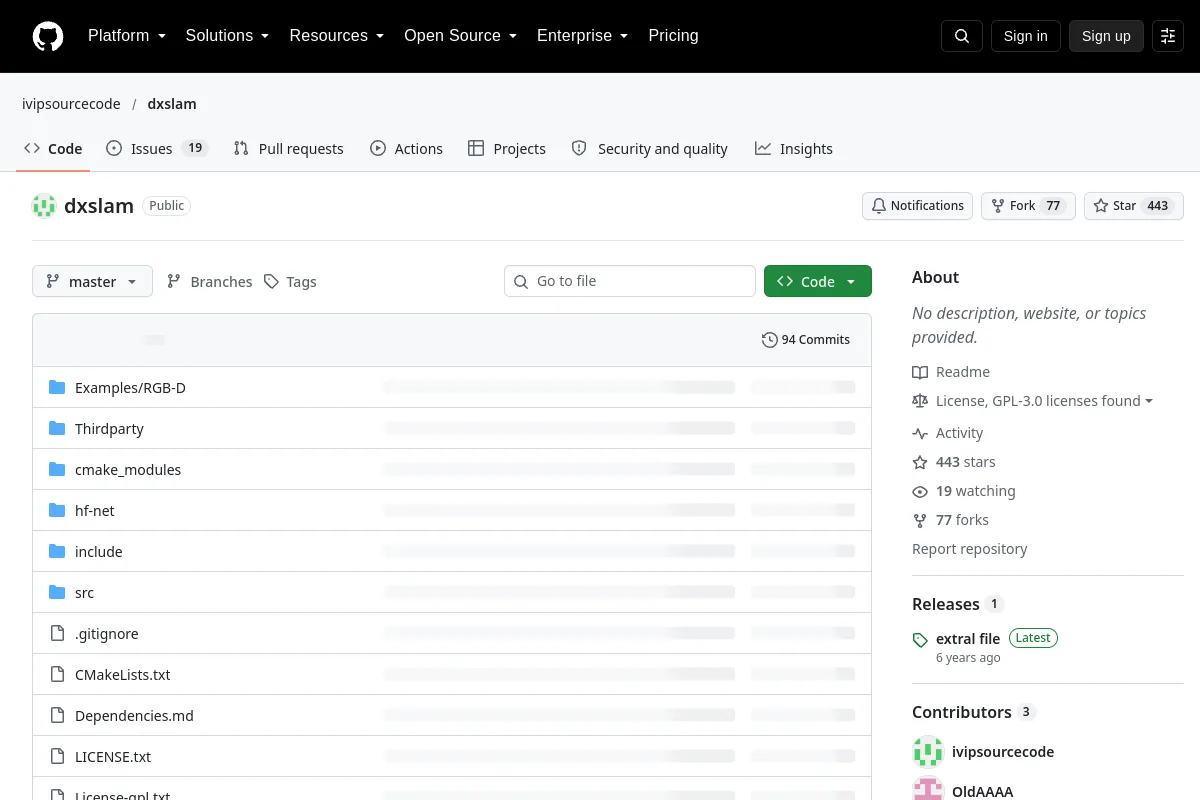 Repository
 Repository
 Open source
dynamic robot localization · carlosmccosta
A point-cloud registration pipeline for robot localization and 3D perception.
Navigation & SLAM Repository
 Open source
dynamic_task_allocation · nubot-nudt
A simulation system based on ROS and Gazebo which is specially built for multi-robot task allocation (exploration and destruction problem)
Simulation & physics Repository
 Open source
DynSLAM · AndreiBarsan
Master's Thesis on Simultaneous Localization and Mapping in dynamic environments. Separately reconstructs both the static environment and the dynamic objects from it, such as cars.
Navigation & SLAM Repository
 Research
EAO-SLAM · yanmin-wu
EAO-SLAM: Monocular Semi-Dense Object SLAM Based on Ensemble Data Association
Navigation & SLAM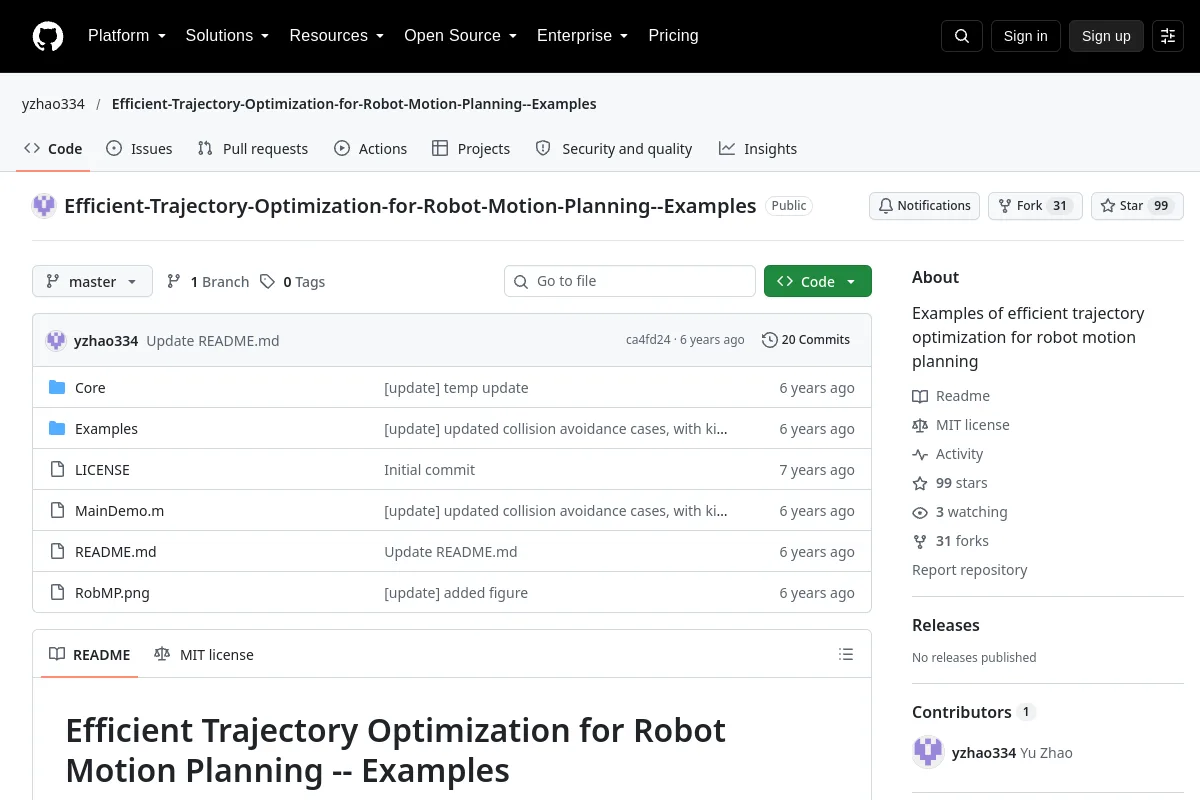 Repository
 Open source
Efficient-Trajectory-Optimization-for-Robot-Motion-Planning--Examples · yzhao334
Examples of efficient trajectory optimization for robot motion planning
Motion planning & control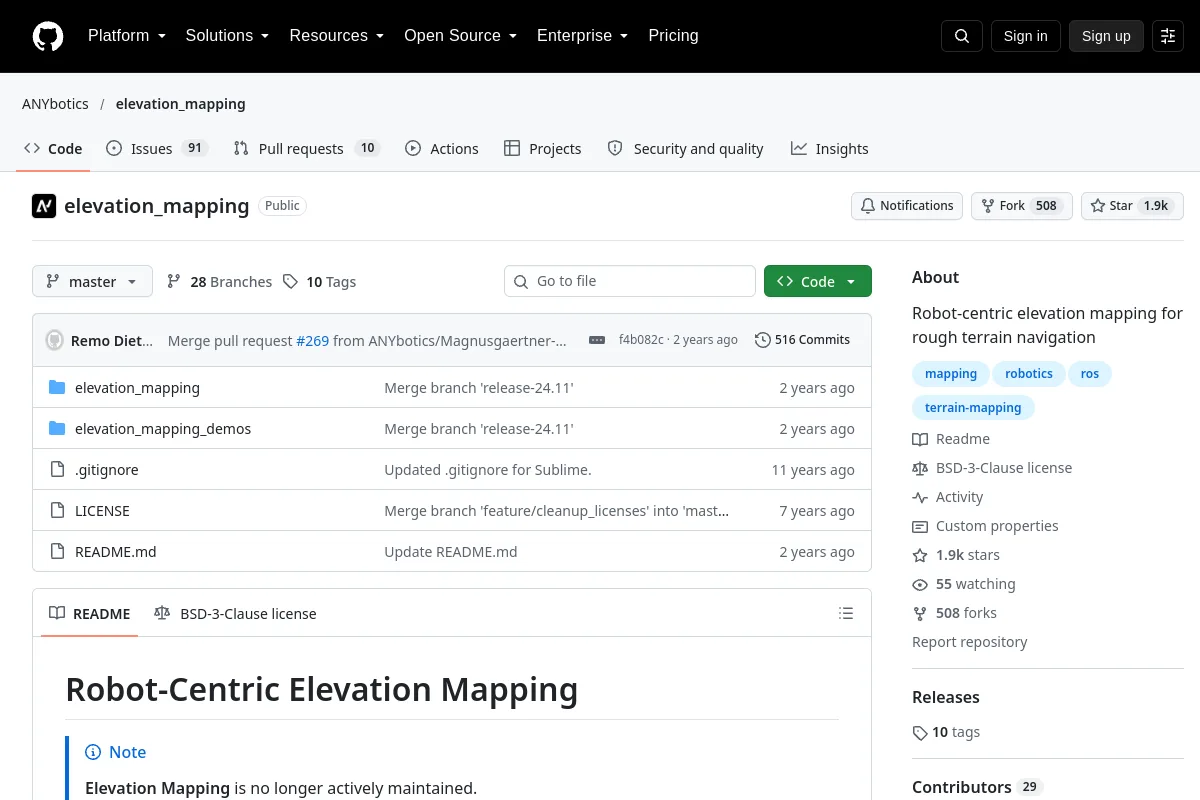 Repository
 Open source
elevation mapping · ANYbotics
Robot-centric elevation mapping for rough-terrain navigation.
Navigation & SLAM Repository
 Repository
 Research
embodied agent arm · ConnorLuis
SO-ARM101 dual-view ACT experiments with documented runtime safeguards.
Robot learning frameworks Repository
 Research
embodied eval automation · Evidentiary-operatingmicroscope154
Embodied Eval Automation provides workflows for collecting robot-benchmark and simulator episodes.
Visualization & data tools Repository
 Open source
Embodied R1 · pickxiguapi
Research code for reinforced embodied reasoning in robot manipulation.
Robot learning frameworksA PLACE FOR YOUR NEXT DISCOVERY
Suggest a resource ↗The ecosystem keeps growing.
Know a resource that belongs here?