 Repository
 Research
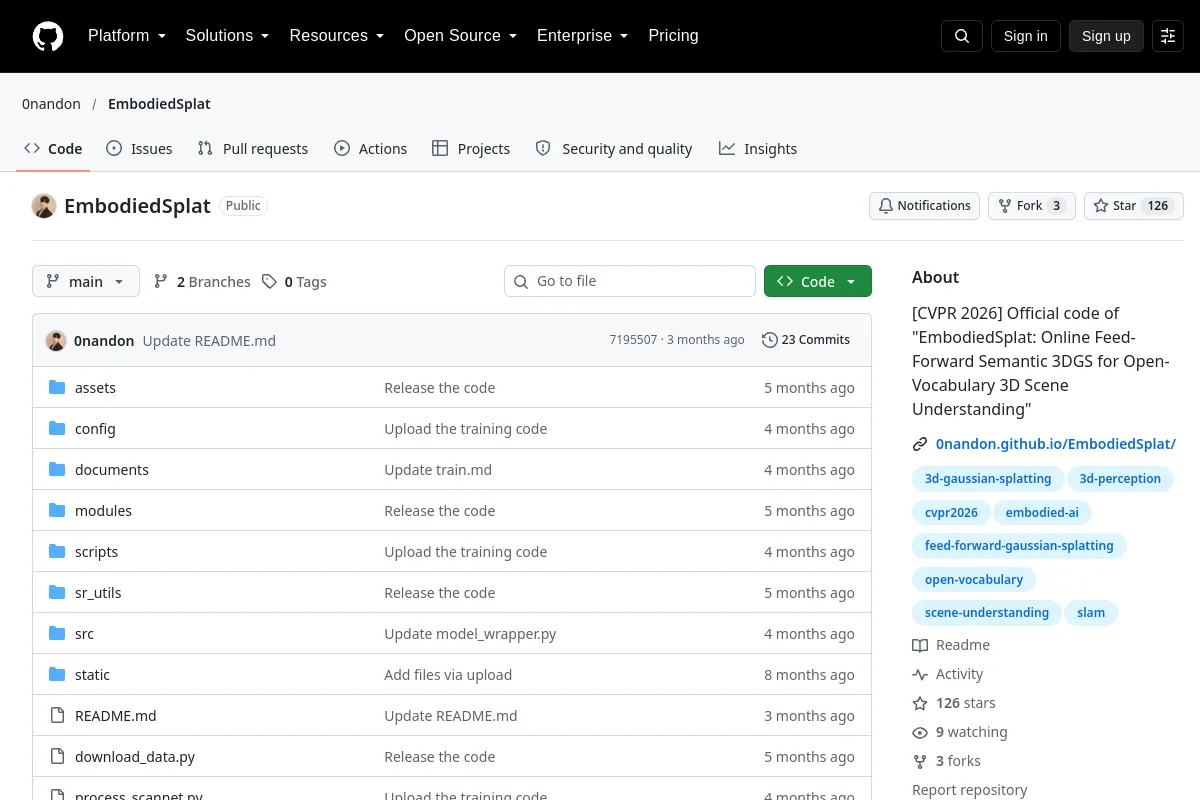
EmbodiedSplat · 0nandon
Official code of "EmbodiedSplat: Online Feed-Forward Semantic 3DGS for Open-Vocabulary 3D Scene Understanding"
Perception & geometryTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Research
Official code of "EmbodiedSplat: Online Feed-Forward Semantic 3DGS for Open-Vocabulary 3D Scene Understanding"
Perception & geometry Repository
 Research
Implementation for learning a mapping from urban images that contain dynamic objects to static realistic images suitable for SLAM
Navigation & SLAM Repository
 Open source
Hardware Interface for EtherCAT module integration with ros2_control
Robot SDKs Repository
 Open source
EVA-Client: A Unified Framework for Deployment, Evaluation, and Data Collection on Real Robots
Visualization & data tools Repository
 Research
EvoBot provides an agent and reusable skill library for LIBERO manipulation tasks.
Motion planning & control Repository
 Research
Genetic-algorithm joint-control experiments for a quadruped robot.
Motion planning & control Repository
 Repository
 Open source
Research code and evaluation records for executable robot-manipulation goals.
Robot learning frameworks Repository
 Open source
Optimization framework for robot motion planning and control.
Motion planning & control Repository
 Research
MuJoCo framework for studying robot behavior under sensor, actuator and hardware failures.
Motion planning & control Repository
 Research
A C++ implementation of Fastron based on the paper "Learning-Based Proxy Collision Detection for Robot Motion Planning Applications".
Motion planning & control Repository
 Open source
ROS 2 MoveIt 2 control for a 6-DoF STS3215 servo robotic arm.
Robot SDKs Repository
 Open source
C++ machine learning library for embedded electronics and robotics.
Robot learning frameworks Repository
 Open source
Coverage path planning library for autonomous agricultural vehicles.
Motion planning & control Repository
 Open source
Fast Incremental Euclidean Distance Fields for Online Motion Planning of Aerial Robots
Motion planning & control Repository
 Open source
A system identification framework for robots
Motion planning & control Repository
 Open source
NVIDIA Fixer is a single-step diffusion model that removes reconstruction artifacts from rendered views for autonomous vehicle and robotics simulation.
Simulation & physics Repository
 Repository
 Open source
An open source dynamic simulation for flapping wing robots and animals
Simulation & physics Repository
 Repository
 Open source
3D flow-based policy for robot manipulation.
Robot learning frameworks Repository
 Research
FluxVLA provides VLA engineering resources spanning data preparation and robot deployment.
Robot learning frameworks Repository
 Open source
Embodied Drosophila: 138,639-neuron whole-brain connectome simulation (FlyWire v783) in a biomechanical body (NeuroMechFly v2 / MuJoCo). Vision, olfaction, gustation, flight, and emergent…
Simulation & physics Repository
 Open source
Embedded autopilot firmware and system resources.
Robot learning frameworksKnow a resource that belongs here?