 Repository
 Research
M2DGR · SJTU-ViSYS
M2DGR: a Multi-modal and Multi-scenario Dataset for Ground Robots(RA-L2021 & ICRA2022)
Robot demonstrationsTHE EMBODIED AI DIRECTORY
Find recorded robot interactions and demonstrations for learning manipulation and control.
Repository
Research
M2DGR: a Multi-modal and Multi-scenario Dataset for Ground Robots(RA-L2021 & ICRA2022)
Robot demonstrations Repository
 Research
M3DGR: A Multi-sensor, Multi-scenario and Massive-baseline SLAM Dataset for Ground Robots(IROS2025)
Robot demonstrations Repository
 Research
Extension and update of M2DGR: a novel Multi-modal and Multi-scenario SLAM Dataset for Ground Robots (ICRA2022 & ICRA2024)
Robot demonstrations Repository
 Research
AgiBot World provides manipulation-platform resources for embodied-system data and learning.
Robot demonstrations Repository
 Research
A Multi-sensor SLAM Dataset Focusing on Corner Cases for Ground Robots (ROBIO2023)
Robot demonstrations Repository
 Research
The GrandTour Dataset: A Legged Robotics Dataset in the Wild
Robot demonstrations Repository
 Research
(ICRA 2025) This repository is the official code for DiTer++: Diverse Terrain and Multi-modal Dataset for Multi-Robot Navigation in Multi-session Outdoor Environments.
Robot demonstrations Repository
 Research
RELLIS-3D: A Multi-modal Dataset for Off-Road Robotics
Robot demonstrations Repository
 Research
Unfied World Models: Coupling Video and Action Diffusion for Pretraining on Large Robotic Datasets
Robot demonstrations Repository
 Research
BotanicGarden: A high-quality dataset for robot navigation in unstructured natural environments
Robot demonstrations Repository
 Research
a legged robot (Unitree Go1) dataset containing leg kinematics (joint encoders and contact sesors), imu and lidar
Robot demonstrations Repository
 Research
Ready to test your SLAM system in challenging datasets from extreme environments? Try this out! The dataset is provided by the Team CoSTAR that has been intensively testing multi-robot systems in…
Robot demonstrations Repository
 Research
Robotic grasp dataset for multi-object multi-grasp evaluation with RGB-D data. This dataset is annotated using the same protocal as Cornell Dataset, and can be used as multi-object extension of…
Robot demonstrations Repository
 Research
The DROID repository provides setup resources for its robot demonstration-collection platform.
Robot demonstrations Repository
 Research
Open-H-Embodiment is a community‑driven dataset initiative building the open, shared foundation needed to train and evaluate a generalist Vision‑Language‑Action (VLA) model for healthcare robotics
Robot demonstrations Repository
 Research
Deep learning techniques for skin segmentation on novel abdominal dataset. Work conducted as part of the development process of an autonomous robotic ultrasound system.
Robot demonstrations Website
 Research
Robot demonstration data and tools for embodied manipulation research.
Robot demonstrations Website
 Research
Multi-task demonstration data for robot manipulation learning.
Robot demonstrations Repository
 Research
Navigation and localisation dataset for self driving cars and autonomous robots
Robot demonstrations Repository
 Research
A driving dataset for the development and validation of fused pose estimators and mapping algorithms
Robot demonstrations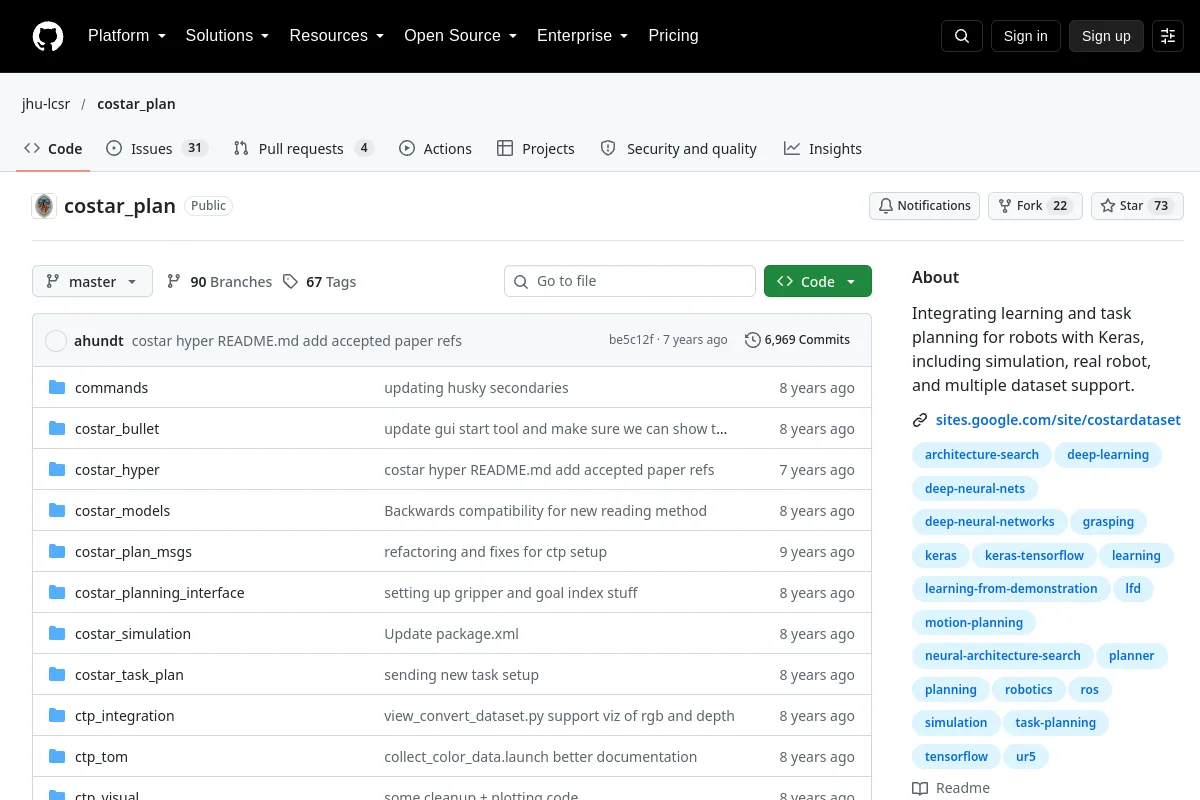 Repository
 Research
Integrating learning and task planning for robots with Keras, including simulation, real robot, and multiple dataset support.
Robot demonstrations Website
 Research
A dataset and collection workflow for robot manipulation in varied environments.
Robot demonstrations Repository
 Research
FiftyOne ABC130k provides a viewer-oriented subset of robot teleoperation MCAP data.
Robot demonstrations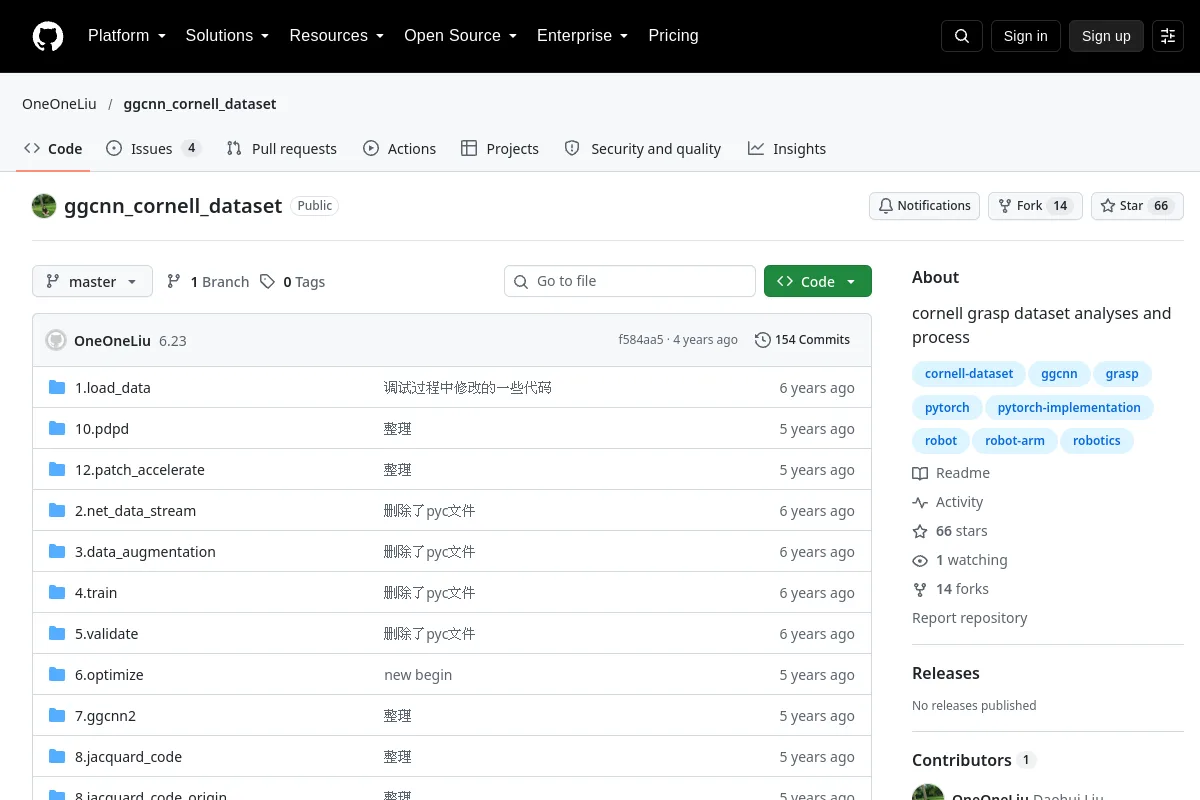 Repository
 Research
cornell grasp dataset analyses and process
Robot demonstrationsSELECTION NOTES
Inspect robot embodiments, observation/action formats, task diversity and collection procedures. Check train/test splits and dataset licenses before mixing sources.
Know a resource that belongs here?