 Repository
 Research
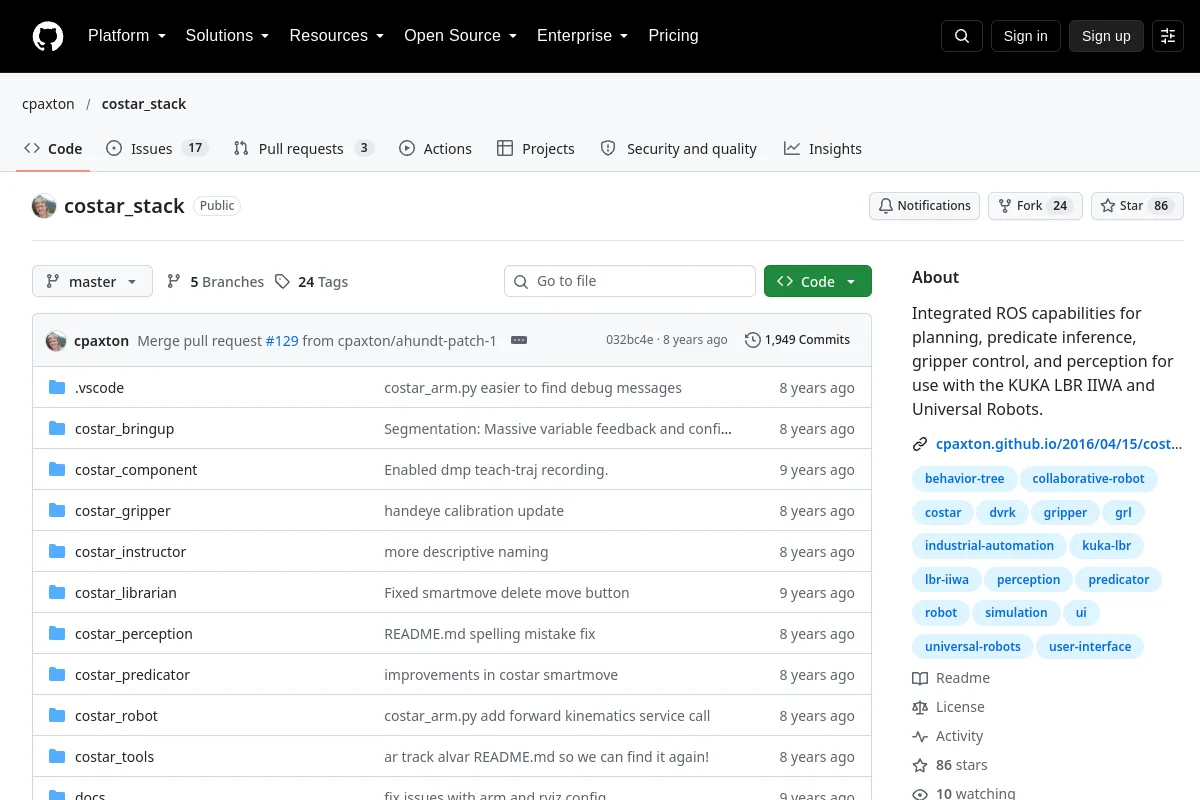
costar_stack · cpaxton
Integrated ROS capabilities for planning, predicate inference, gripper control, and perception for use with the KUKA LBR IIWA and Universal Robots.
Perception & geometry
Datasets / Research
Integrating learning and task planning for robots with Keras, including simulation, real robot, and multiple dataset support.
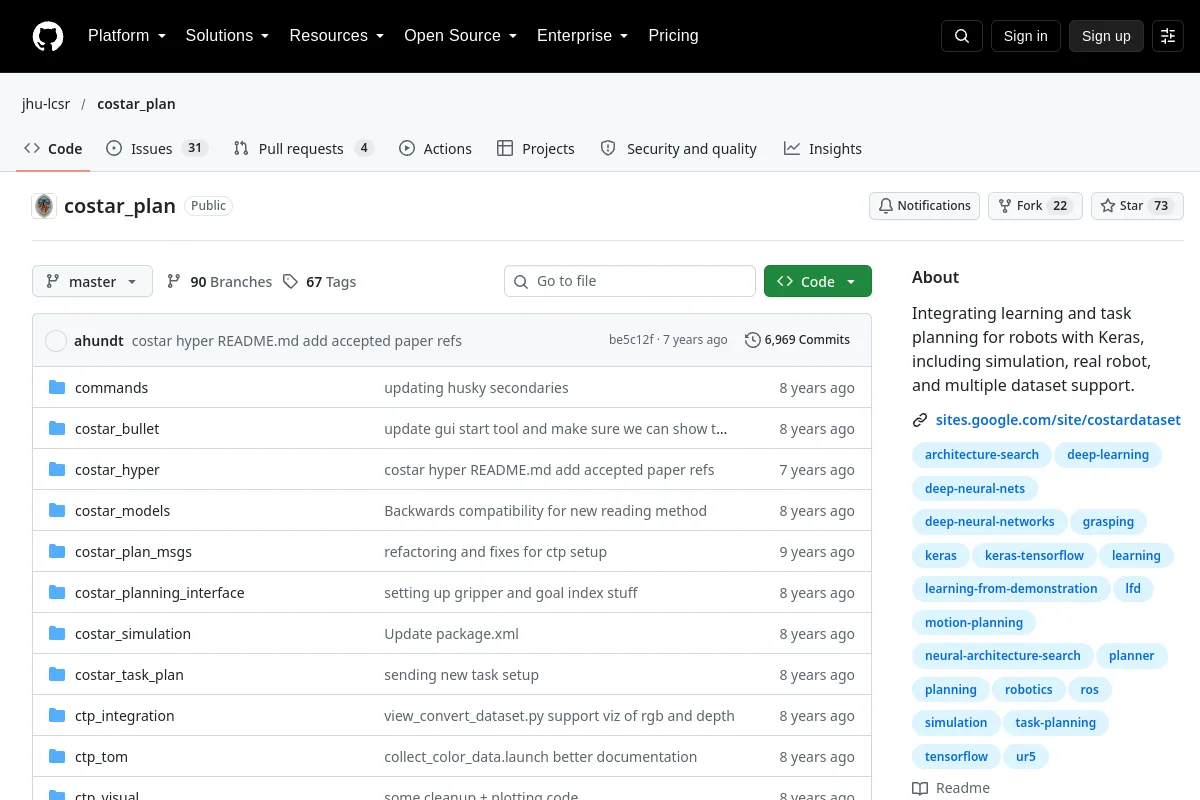
Integrating learning and task planning for robots with Keras, including simulation, real robot, and multiple dataset support.
Review the data card, embodiment, schema, collection conditions and dataset-specific license before use. Data access and fit for a particular training setup need separate confirmation.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
Integrated ROS capabilities for planning, predicate inference, gripper control, and perception for use with the KUKA LBR IIWA and Universal Robots.
Perception & geometry