 Repository
 Research
benchmarks · robotperf
Benchmarking suite to evaluate 🤖 robotics computing performance. Vendor-neutral. ⚪Grey-box and ⚫Black-box approaches.
Policy evaluationTHE EMBODIED AI DIRECTORY
Explore tasks and evaluation suites for manipulation, navigation and control.
Repository
Research
Benchmarking suite to evaluate 🤖 robotics computing performance. Vendor-neutral. ⚪Grey-box and ⚫Black-box approaches.
Policy evaluation Repository
 Research
MapEval: Towards Unified, Robust and Efficient SLAM Map Evaluation Framework.
Navigation & embodied interaction Repository
 Research
Open datasets for training and benchmarking AI and robotic systems in agriculture and off-road environments
Navigation & embodied interaction Repository
 Research
Evolution Gym benchmarks joint optimization of soft-robot design and control.
Locomotion & whole-body control Repository
 Research
Faultline studies LIBERO policy robustness using perturbation and ablation workflows.
Policy evaluation Repository
 Research
GeoPolicy-Bench compares perception and policy designs on Panda manipulation tasks.
Manipulation Repository
 Research
A simulation environment and benchmark for human-to-robot object handovers
Manipulation Repository
 Research
Open source evals for physical AI. Run any LLM/VLA on any arm/humanoid against any real/sim benchmark.
Locomotion & whole-body control Repository
 Research
An All-in-one robot manipulation learning suite for policy models training and evaluation on various datasets and benchmarks.
Manipulation Repository
 Research
Isaac Lab - Arena is a robotics simulation framework that enhances NVIDIA Isaac Lab by providing a composable, scalable system for creating diverse simulation environments and evaluating robot…
Policy evaluation Repository
 Research
LIBERO Camera Ablation studies how camera-input changes affect robot-policy behavior.
Policy evaluation Repository
 Research
Generate and benchmark datasets for robot manipulation problems
Manipulation Repository
 Research
OceanGym: A Benchmark Environment for Underwater Embodied Agents
Policy evaluation Repository
 Research
Open-source robotics simulator for coding agents: HTTP/JSON + MCP control, Newton physics, wgpu rendering, ROS 2, and reproducible benchmarks.
Policy evaluation Repository
 Research
ParcelStow evaluates imitation-learned robot-policy robustness under execution-timing variation in Isaac Lab.
Policy evaluation Repository
 Research
Pre-Execution Return studies robot initial-state robustness around frozen VLA policies.
Policy evaluation Website
 Repository
 Research
Repository associated with paper titled "RoboGaze: Evaluating Robot World Models via Structured Vision-Language Analysis"
Policy evaluation Repository
 Research
A simulation benchmarking platform for evaluating generalist robot policies
Policy evaluation Repository
 Research
A software framework integrating various imitation learning methods and benchmark environments for robotic manipulation
Manipulation Repository
 Research
RoboPianist Cost-Aware Intervention provides a benchmark for teacher interventions in RoboPianist.
Policy evaluation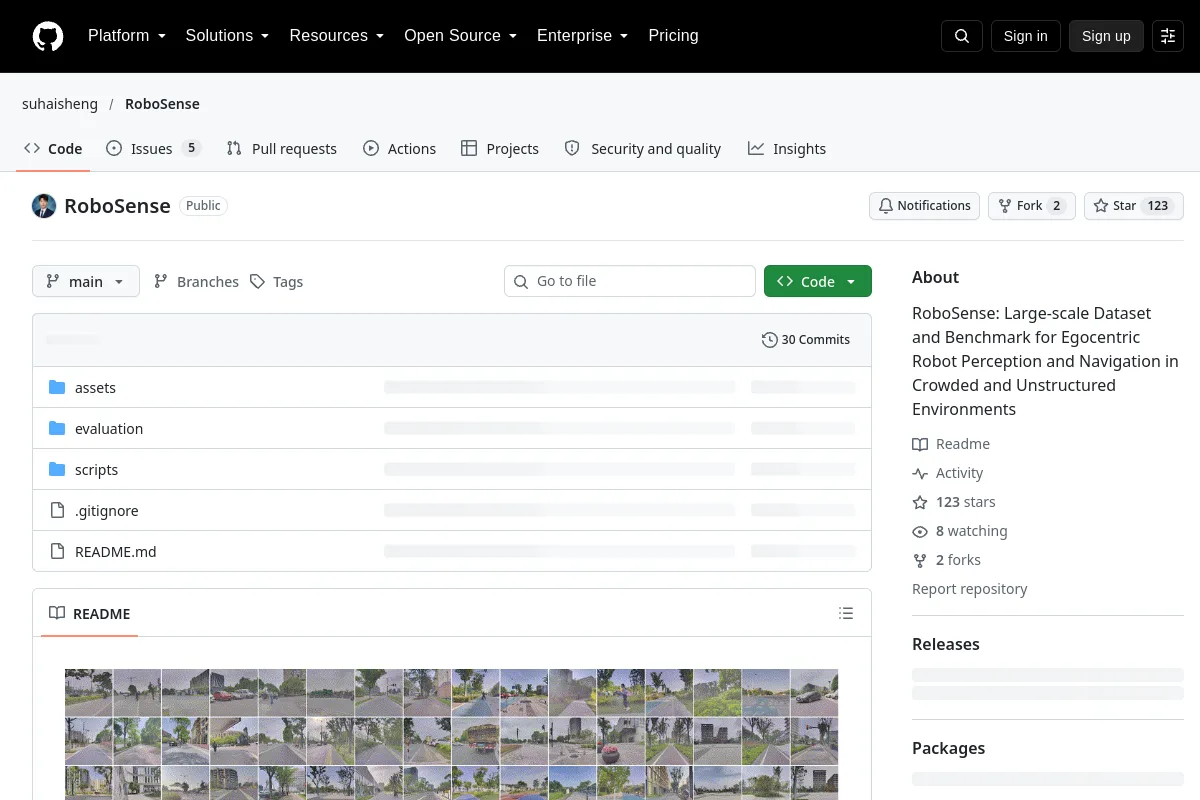 Repository
 Research
RoboSense: Large-scale Dataset and Benchmark for Egocentric Robot Perception and Navigation in Crowded and Unstructured Environments
Navigation & embodied interaction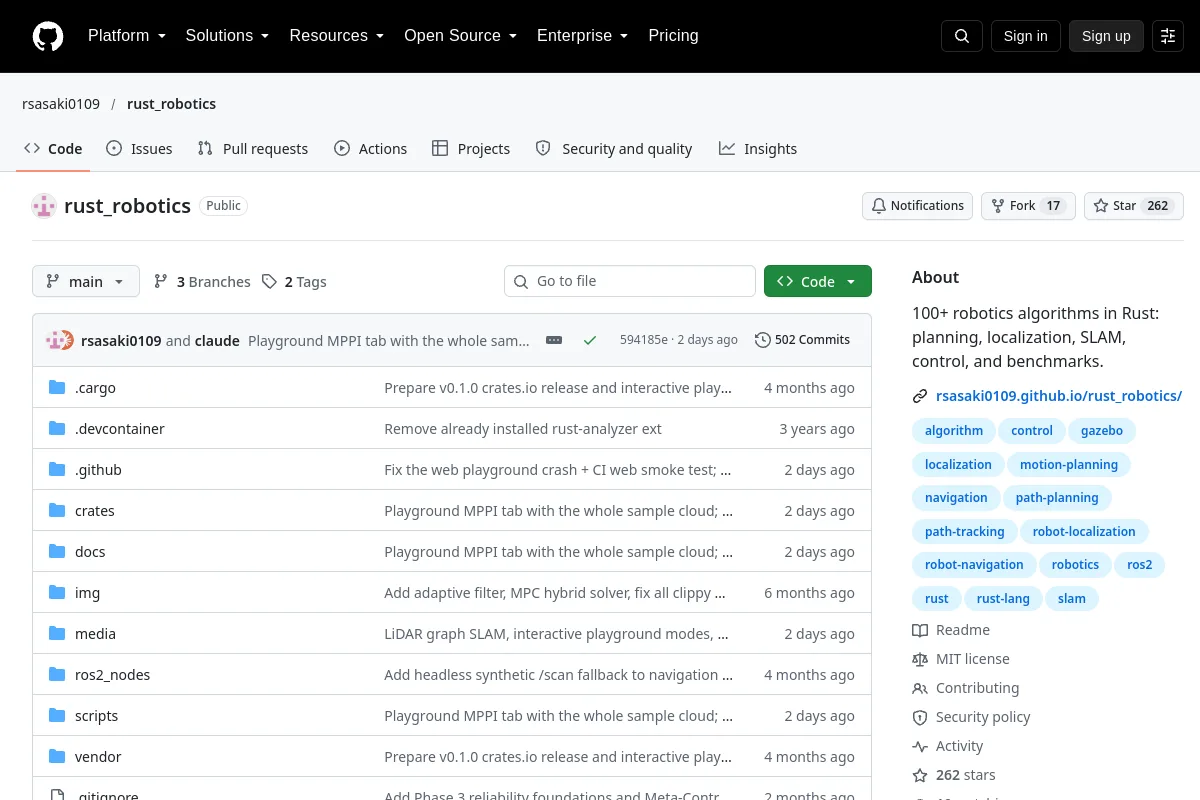 Repository
 Research
100+ robotics algorithms in Rust: planning, localization, SLAM, control, and benchmarks.
Navigation & embodied interaction Repository
 Research
SLAM performance evaluation framework
Navigation & embodied interactionKnow a resource that belongs here?
