 Repository
 Research
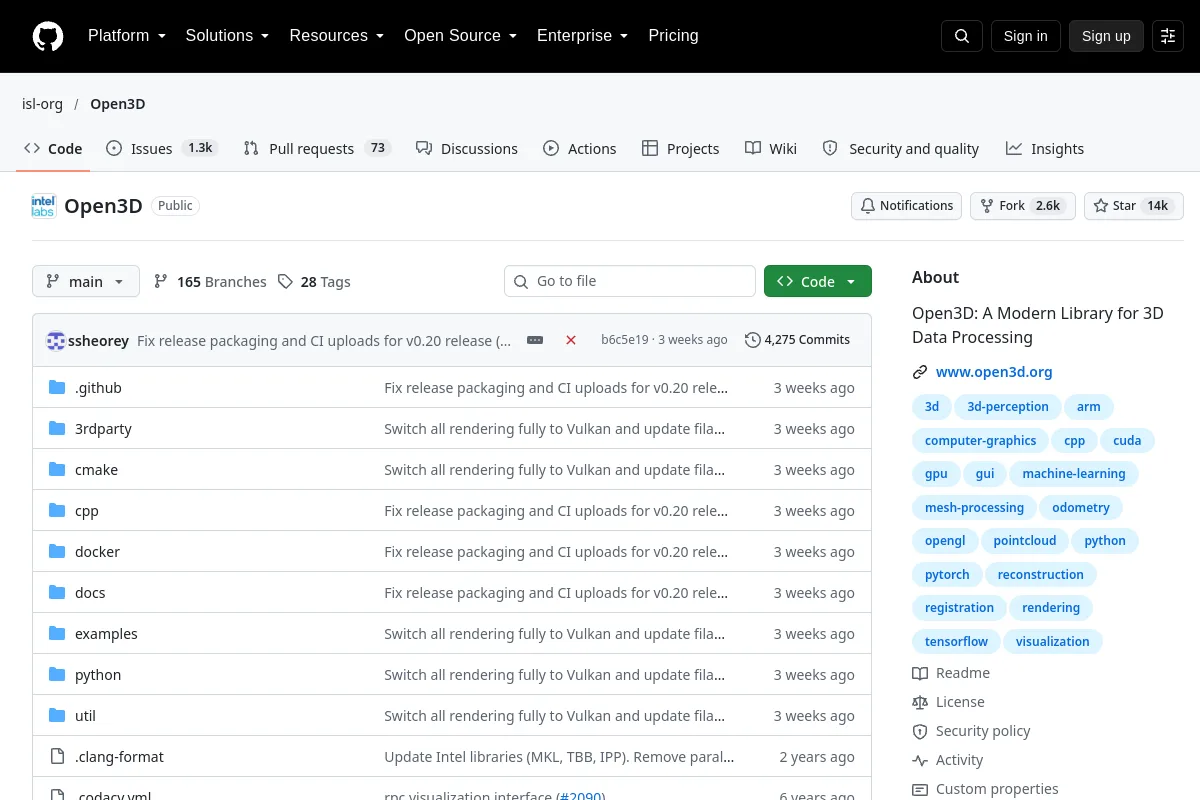
Open3D
3D data processing tools for point clouds and geometric perception.
Perception & geometry
Benchmarks / Research
MapEval: Towards Unified, Robust and Efficient SLAM Map Evaluation Framework.
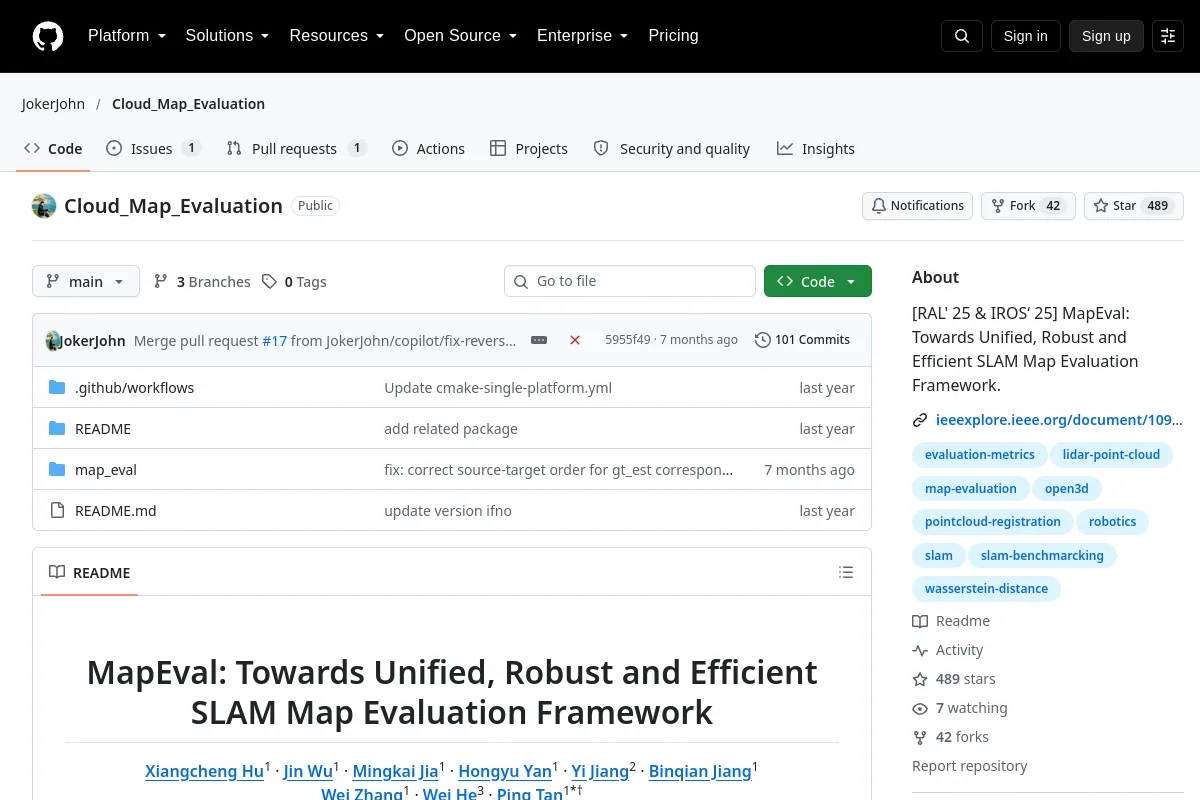
MapEval: Towards Unified, Robust and Efficient SLAM Map Evaluation Framework.
Publisher purpose: [RAL' 25 & IROS‘ 25] MapEval: Towards Unified, Robust and Efficient SLAM Map Evaluation Framework.
Compare tasks, protocols, dataset/environment versions and hardware before interpreting reported results. A benchmark repository is not a certification of a robot system.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Research
3D data processing tools for point clouds and geometric perception.
Perception & geometry