 Repository
 Open source
SO ARM100 · TheRobotStudio
Designs and setup documentation for Standard Open Arm robots and LeRobot integration.
Robot learning frameworks
Benchmarks / Research
Open source evals for physical AI. Run any LLM/VLA on any arm/humanoid against any real/sim benchmark.
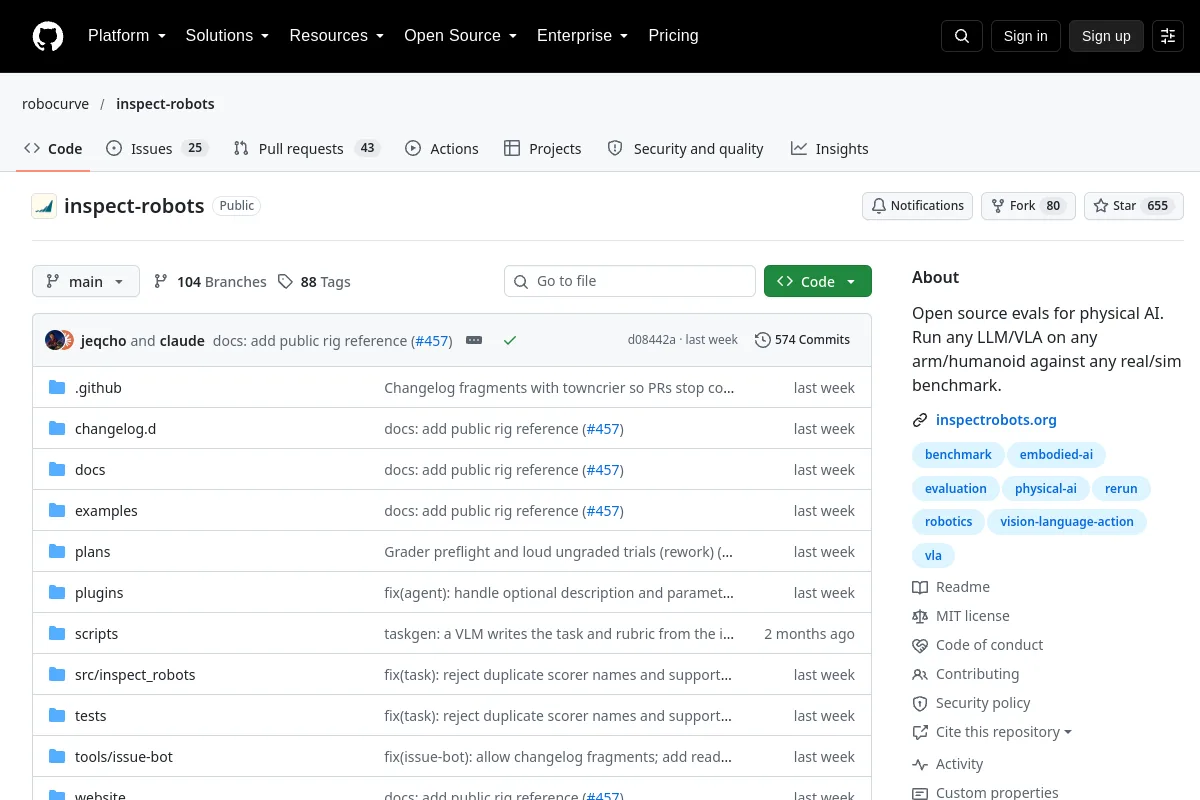
Open source evals for physical AI. Run any LLM/VLA on any arm/humanoid against any real/sim benchmark.
Compare tasks, protocols, dataset/environment versions and hardware before interpreting reported results. A benchmark repository is not a certification of a robot system.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
Designs and setup documentation for Standard Open Arm robots and LeRobot integration.
Robot learning frameworks Repository
 Open source
Involving over 50 Advanced Manipulation Policies
Visualization & data tools Repository
 Open source
Visualize, query, and stream to train on multimodal robotics data.
Visualization & data tools