 Repository
 Open source
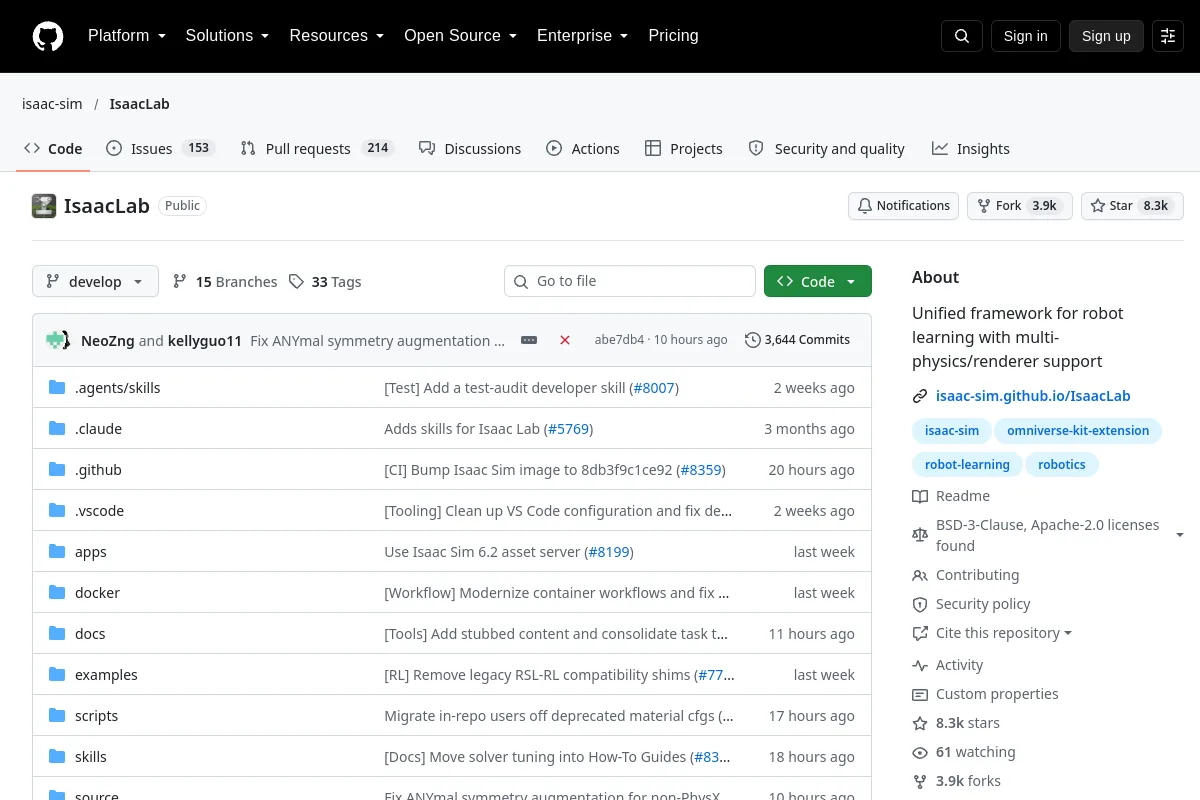
NVIDIA Isaac Lab
Robot learning tools built around the Isaac simulation ecosystem.
Simulation & physics
Benchmarks / Research
A simulation benchmarking platform for evaluating generalist robot policies
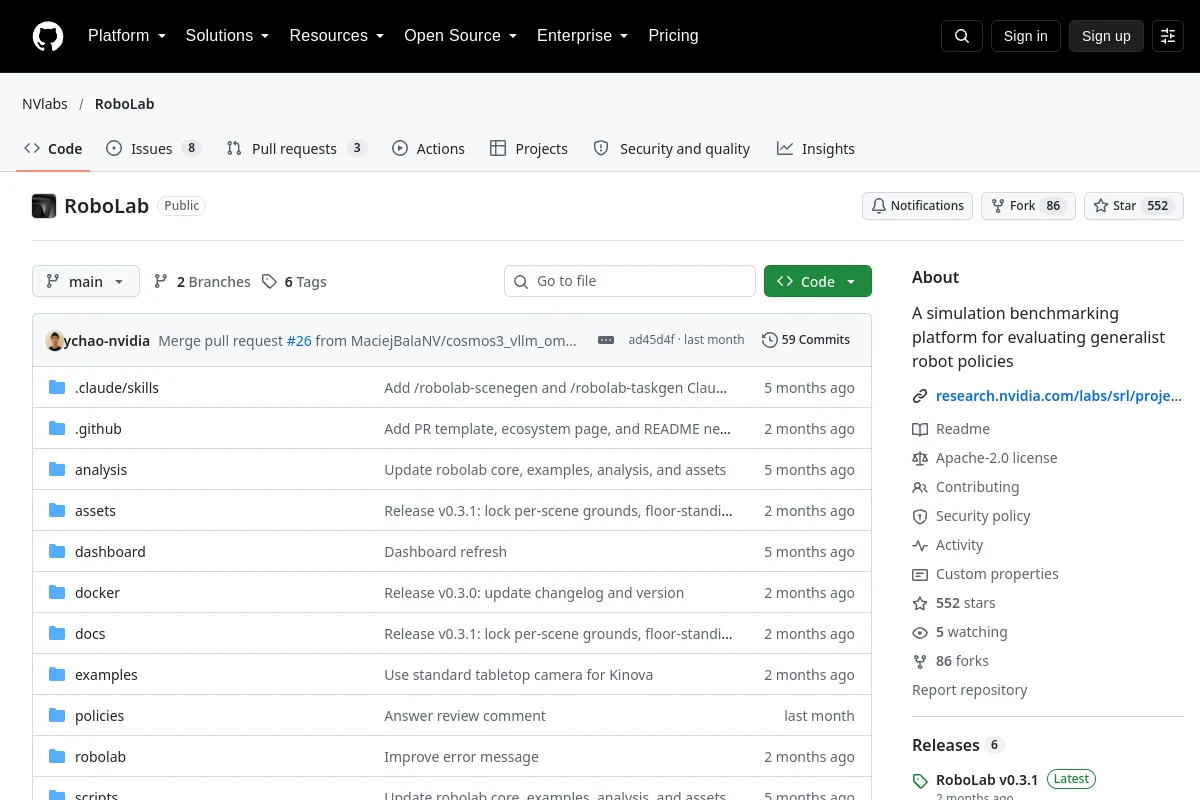
A simulation benchmarking platform for evaluating generalist robot policies
Compare tasks, protocols, dataset/environment versions and hardware before interpreting reported results. A benchmark repository is not a certification of a robot system.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
Robot learning tools built around the Isaac simulation ecosystem.
Simulation & physics