 Repository
 Open source
LeRobot · huggingface
LeRobot tools for robot control, datasets and end-to-end learning.
Robot learning frameworks
Benchmarks / Research
RoboSense: Large-scale Dataset and Benchmark for Egocentric Robot Perception and Navigation in Crowded and Unstructured Environments
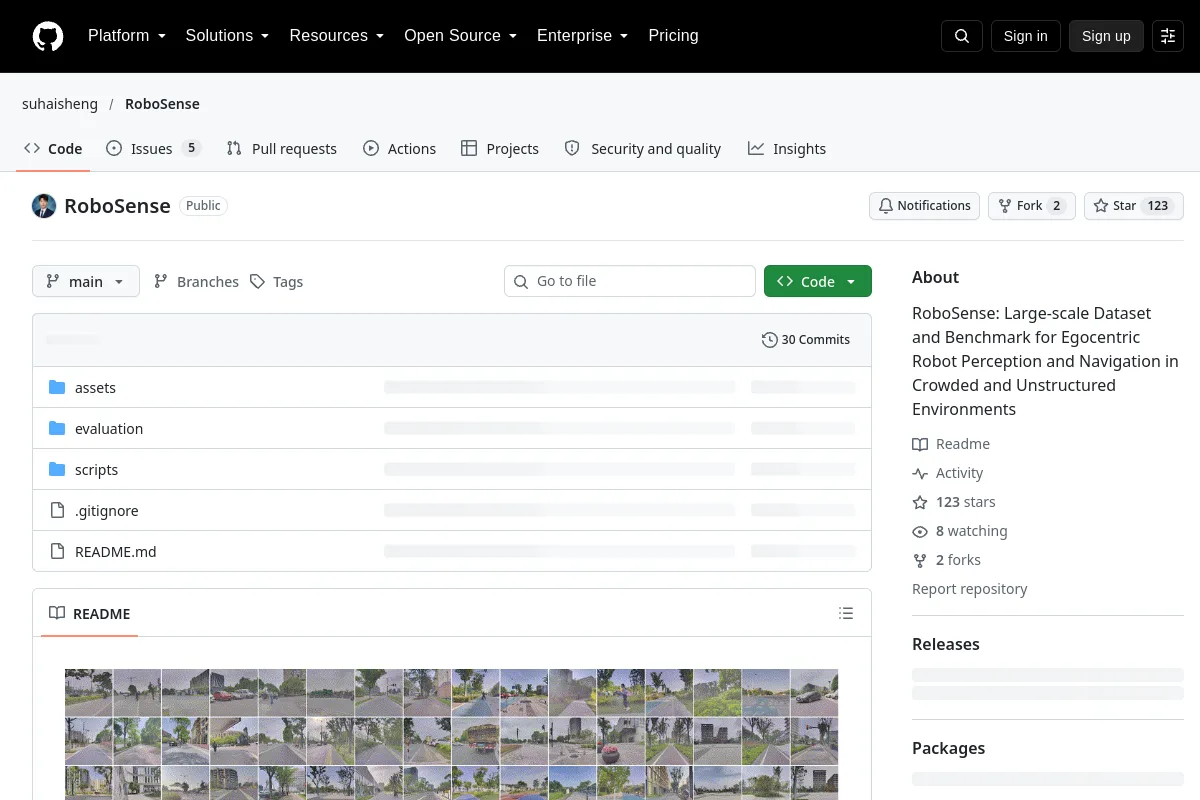
RoboSense: Large-scale Dataset and Benchmark for Egocentric Robot Perception and Navigation in Crowded and Unstructured Environments
Compare tasks, protocols, dataset/environment versions and hardware before interpreting reported results. A benchmark repository is not a certification of a robot system.
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Repository
Open source
LeRobot tools for robot control, datasets and end-to-end learning.
Robot learning frameworks