 Repository
 Research
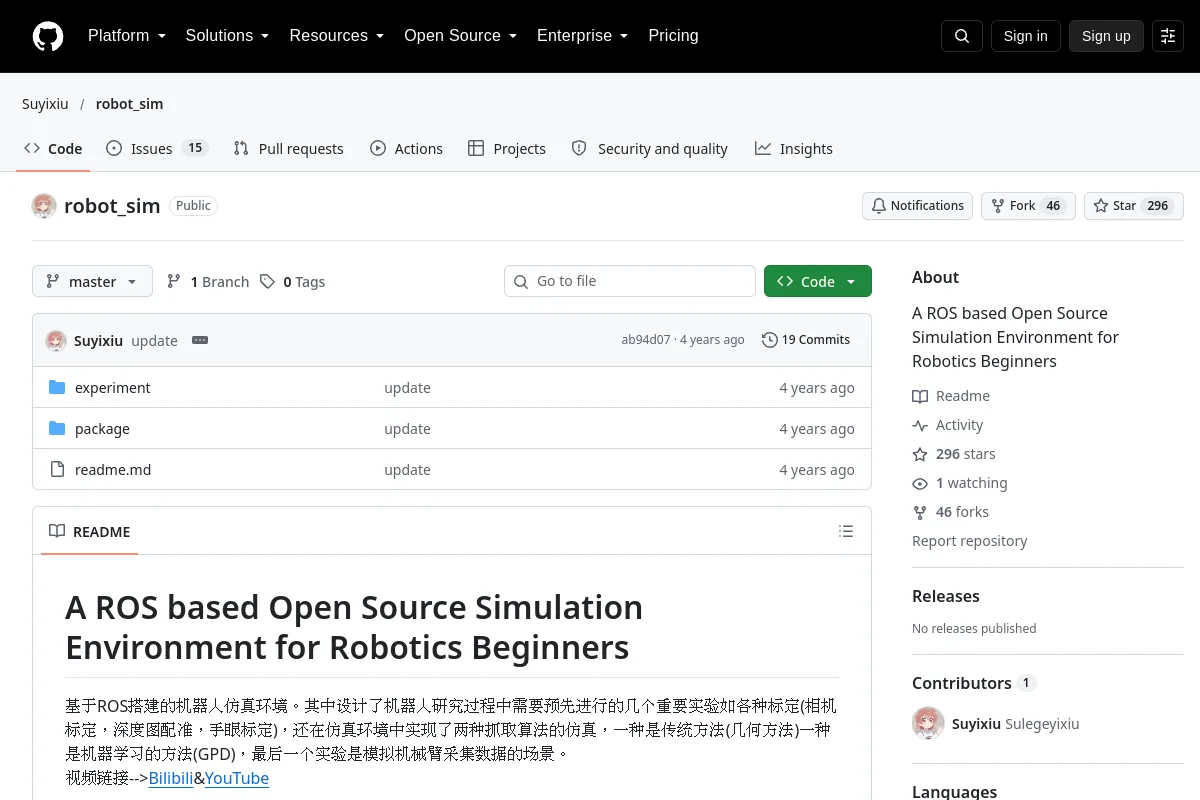
robot_sim · Suyixiu
A ROS based Open Source Simulation Environment for Robotics Beginners
Simulation & physicsTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Research
A ROS based Open Source Simulation Environment for Robotics Beginners
Simulation & physics Repository
 Research
Source repository for the robots.ros.org robot catalog.
Robot learning frameworks Repository
 Open source
ROS package of helper functions related to bringing up roslaunch on system startup.
Robot SDKs Repository
 Open source
Python toolkit for robot learning from demonstration and manipulation.
Motion planning & control Repository
 Research
ROS stack for the Aldebaran Romeo robot.
Robot learning frameworks Repository
 Open source
RoomTour3D - Geometry-aware, cheap and automatic data from web videos for embodied navigation
Navigation & SLAM Repository
 Research
ROS 2 bag export tools for images, point clouds and other recorded data.
Visualization & data tools Repository
 Open source
Generic robotic controllers to accompany ros2_control
Motion planning & control Repository
 Open source
Agent skill for production-grade ROS 2 development. Progressive-disclosure SKILL.md covering workspace, nodes, executors, QoS, ros2_control, Nav2, MoveIt 2, real-time, and deployment. Works with…
Navigation & SLAM Repository
 Research
Autonomous exploration for ROS 2, featuring two algorithms: Wanderer (heuristic-based) and Discoverer (frontier-based, efficient for large maps). Mapping is handled by Google Cartographer (SLAM)…
Navigation & SLAM Repository
 Open source
High-performance ROS2 solution for Unity3D
Middleware & communication Repository
 Open source
A ROS2 Humble package that natively implementing ORB-SLAM3 V1.0 VSLAM framework
Navigation & SLAM Repository
 Open source
Framework to evaluate peformance of ROS 2
Visualization & data tools Repository
 Research
This repository contains ROS2 packages for controlling a UR5 robot with a Robotiq gripper, facilitating precise pick and place operations using MoveIt and providing a comprehensive toolkit for…
Robot SDKs Repository
 Open source
ROS2.0 Foxy and Humble repositories which provide ready-to-use ROS2.0 Gazebo + MoveIt!2 simulation packages for different Industrial and Collaborative Robots.
Simulation & physics Repository
 Open source
This repository provides ready-to-use ROS2 (Humble) packages to execute simple programs and sequences and control different Industrial and Collaborative Robots using ROS 2.
Robot SDKs Repository
 Repository
 Open source
Walking Pattern Generator (= Walking Controller) using ROS2 for Humanoid Robots
Motion planning & control Repository
 Open source
ROS package which uses the Navigation Stack to autonomously explore an unknown environment with help of GMAPPING and constructs a map of the explored environment. Finally, a path planning…
Navigation & SLAM Website
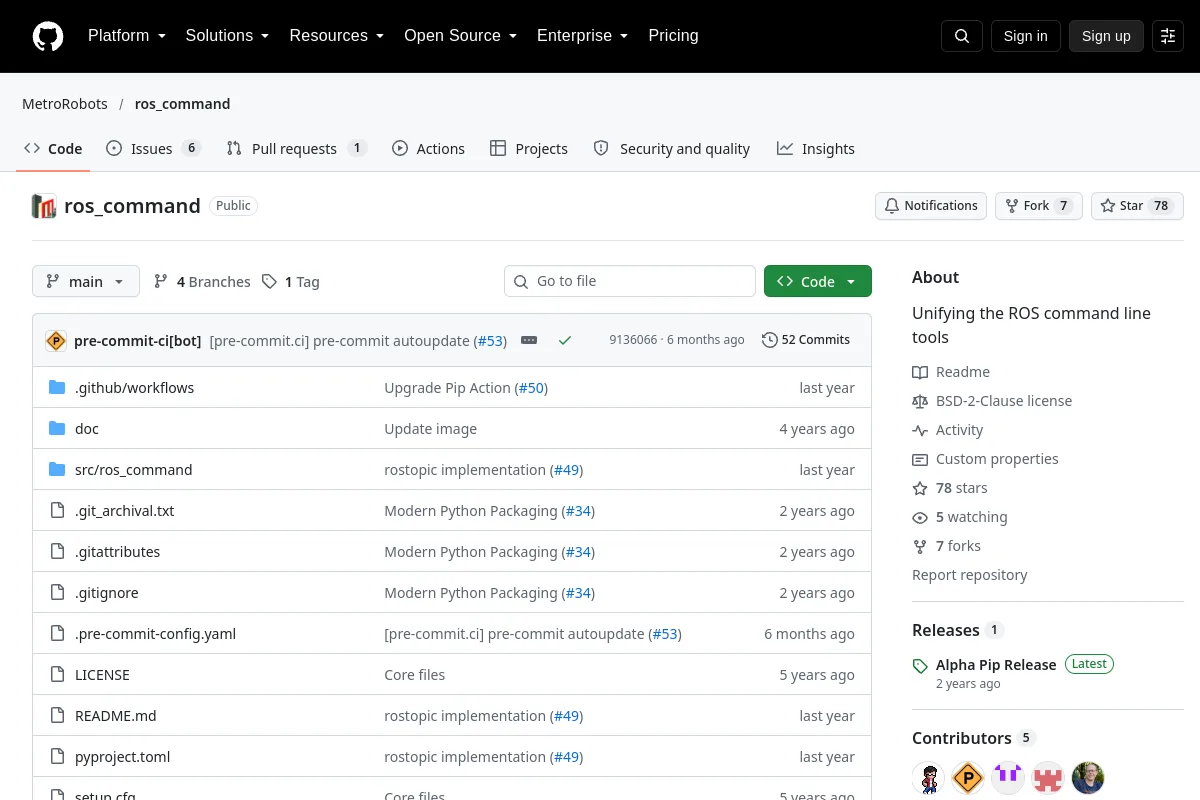 Repository
 Open source
Unified command-line interface for ROS development tools.
Robot learning frameworks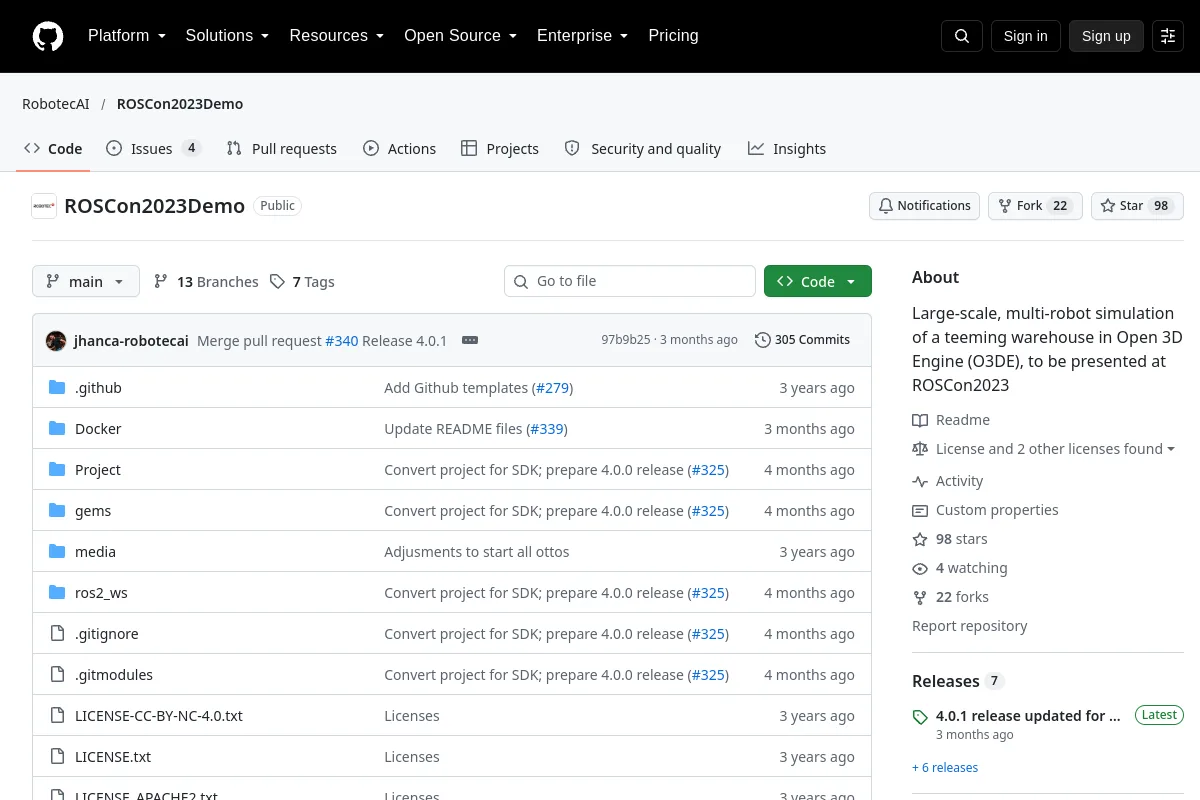 Repository
 Research
Large-scale, multi-robot simulation of a teeming warehouse in Open 3D Engine (O3DE), to be presented at ROSCon2023
Simulation & physics Repository
 Open source
Integration between ROS (1 and 2) and Gazebo simulation
Simulation & physics Repository
 Open source
Connect AI models like Claude & GPT with robots using MCP and ROS.
Middleware & communicationKnow a resource that belongs here?