 Repository
 Open source
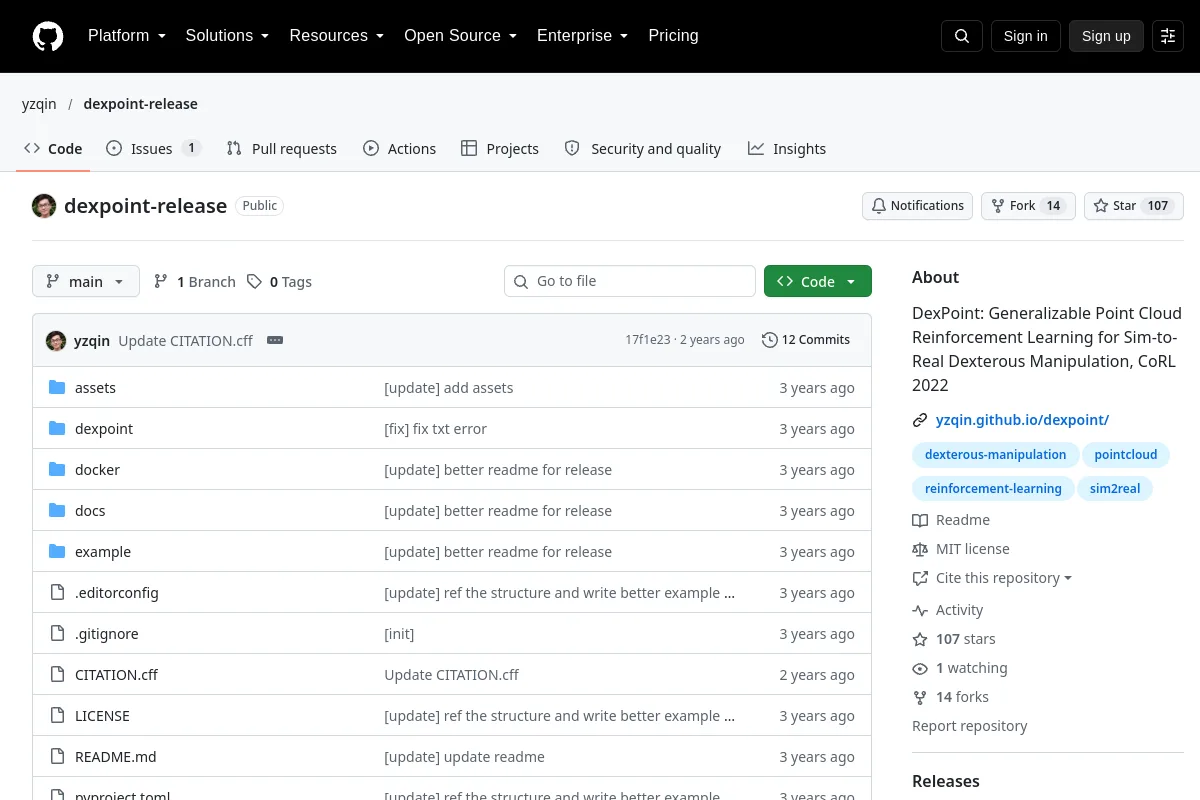
dexpoint-release · yzqin
DexPoint: Generalizable Point Cloud Reinforcement Learning for Sim-to-Real Dexterous Manipulation, CoRL 2022
Perception & geometryTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
DexPoint: Generalizable Point Cloud Reinforcement Learning for Sim-to-Real Dexterous Manipulation, CoRL 2022
Perception & geometry Repository
 Research
Eigen-based C++ Lie-group library for geometric computation.
Perception & geometry Repository
 Open source
LiDAR-inertial odometry tools for mobile robotic state estimation.
Navigation & SLAM Repository
 Open source
Mapping and localization tools for ROS 2 navigation workflows.
Navigation & SLAM Repository
 Open source
Computer-vision library for image processing, calibration, and perception.
Perception & geometry Repository
 Research
Dexbotic provides a toolbox for vision-language-action model development.
Robot learning frameworks Repository
 Open source
C++ interface to nonlinear programming solvers.
Motion planning & control Repository
 Research
Deprecated robot simulation package integrated with OpenAI Gym.
Simulation & physics Repository
 Open source
Python framework for GPU-accelerated simulation and differentiable computing.
Simulation & physics Repository
 Open source
This is a library that provides dual dexterous hand manipulation tasks through Isaac Gym
Robot learning frameworks Repository
 Open source
ROS2 bridge to operate some robot vacuum cleaners
Robot SDKs Repository
 Research
Simulator for autonomous vehicles built on Unreal Engine and Unity.
Perception & geometry Repository
 Research
Algorithms for point-cloud filtering, registration and geometric analysis.
Perception & geometry Website
 Research
Teleoperation tools for collecting bimanual manipulation demonstrations.
Teleoperation software Repository
 Open source
UMI on Legs: Making Manipulation Policies Mobile with Manipulation-Centric Whole-body Controllers
Motion planning & control Repository
 Open source
YOLO toolkit for detection, segmentation, pose estimation, and tracking.
Perception & geometry Repository
 Open source
SuMa++: Efficient LiDAR-based Semantic SLAM (Chen et al IROS 2019)
Navigation & SLAM Repository
 Repository
 Open source
Optimization and algorithmic differentiation tools used in robotic control.
Robot learning frameworks Repository
 Open source
Collaborative Dynamic 3D Scene Graphs for Automated Driving
Robot learning frameworks Repository
 Open source
Interactive Map Correction for 3D Graph SLAM
Navigation & SLAM Repository
 Open source
Decentralized Multi-Robot Graph Simultaneous Localization and Mapping
Navigation & SLAM Repository
 Repository
Know a resource that belongs here?