 Repository
 Research
CarlaAir · louiszengCN
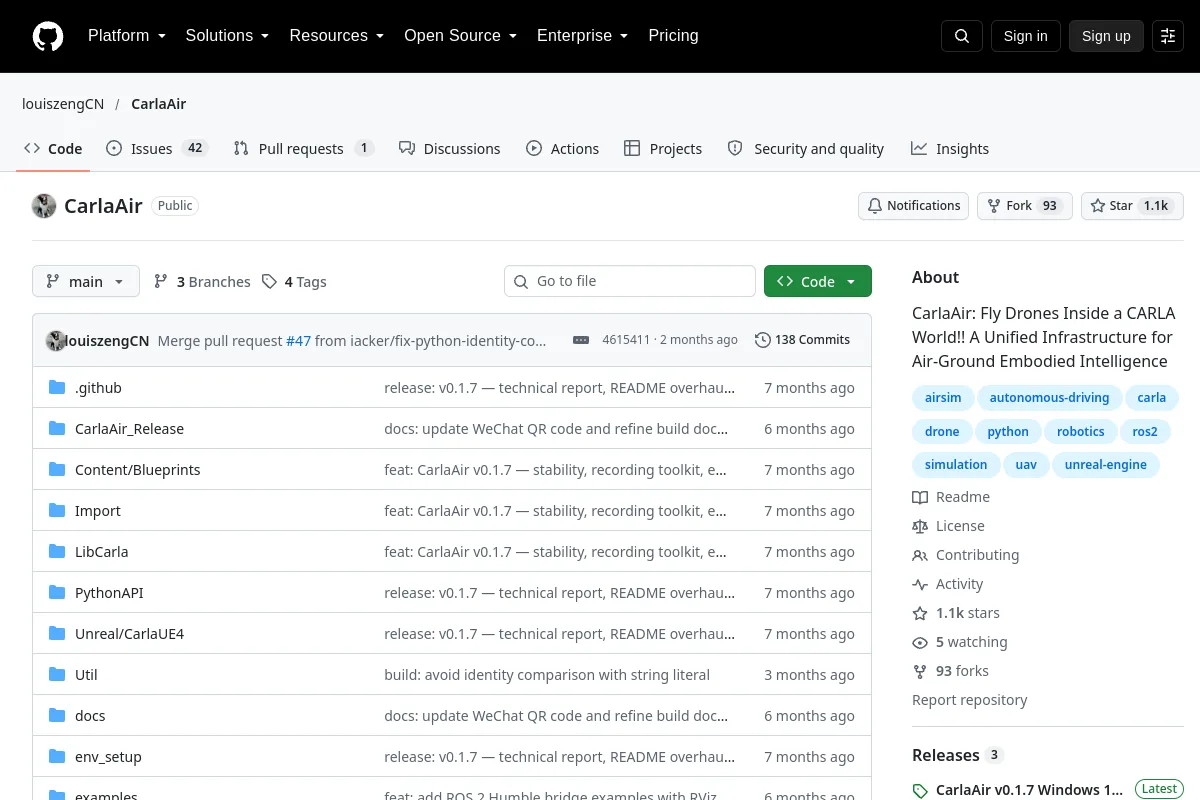
CarlaAir: Fly Drones Inside a CARLA World!! A Unified Infrastructure for Air-Ground Embodied Intelligence
Simulation & physicsTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Research
CarlaAir: Fly Drones Inside a CARLA World!! A Unified Infrastructure for Air-Ground Embodied Intelligence
Simulation & physics Repository
 Repository
 Open source
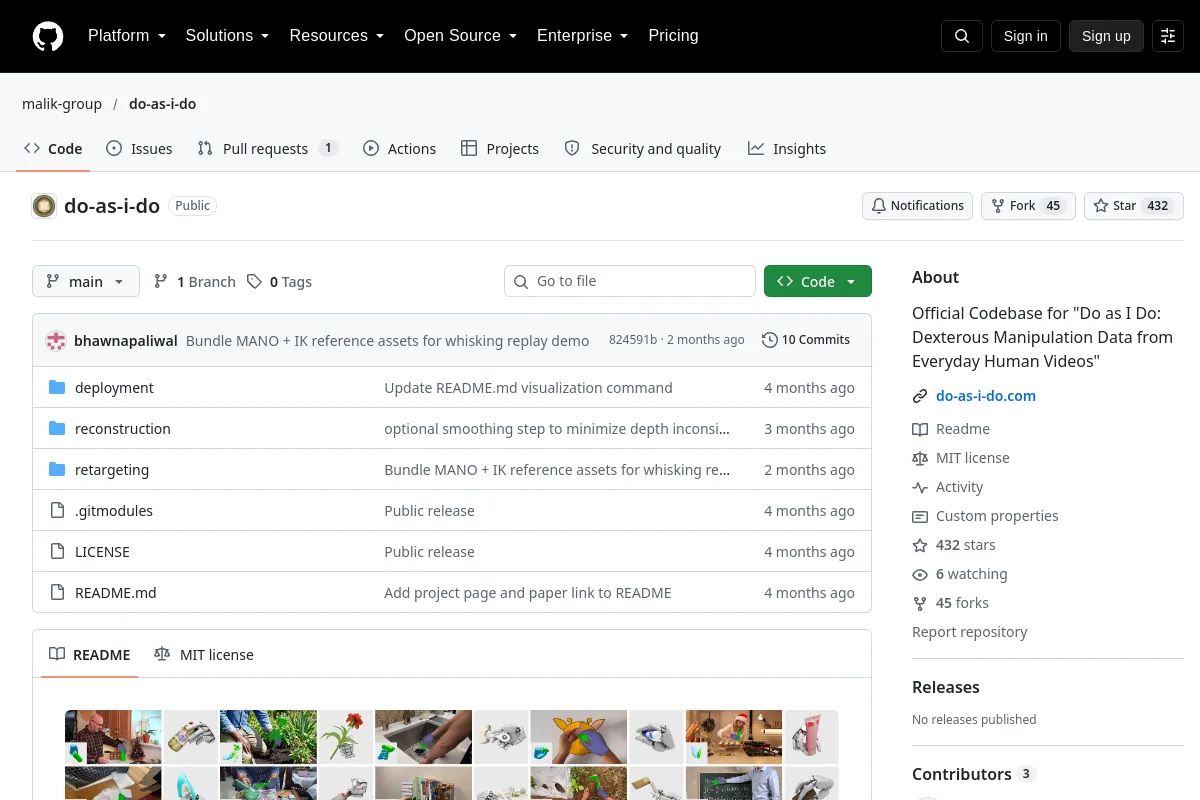
Official Codebase for "Do as I Do: Dexterous Manipulation Data from Everyday Human Videos"
Robot learning frameworks Repository
 Open source
DynaVINS : A Visual-Inertial SLAM for Dynamic Environments
Navigation & SLAM Repository
 Open source
A General Simultaneous Localization and Mapping Framework which supports feature based or direct method and different sensors including monocular camera, RGB-D sensors or any other input types can…
Navigation & SLAM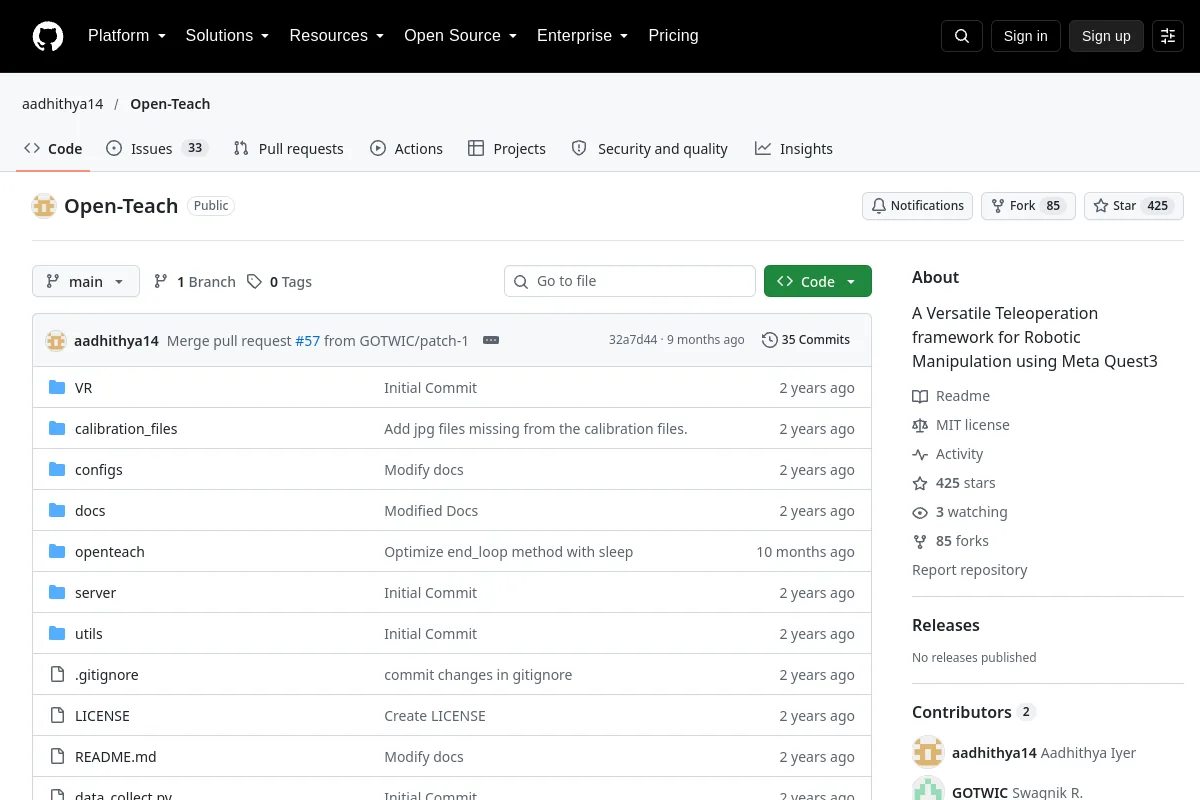 Repository
 Open source
A Versatile Teleoperation framework for Robotic Manipulation using Meta Quest3
Teleoperation software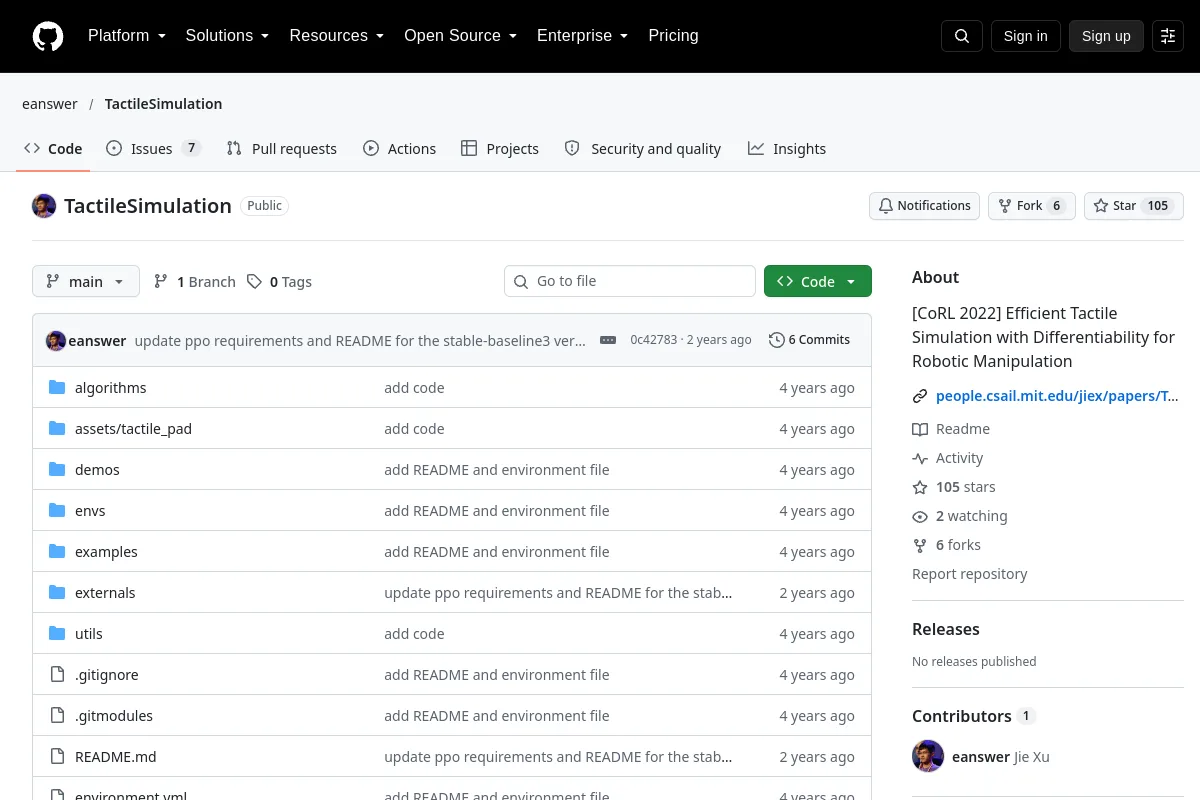 Repository
 Research
Efficient Tactile Simulation with Differentiability for Robotic Manipulation
Simulation & physics Repository
 Open source
An open-source, full-stack robotic neck for active perception
Perception & geometry Repository
 Open source
DexUMI: Using Human Hand as the Universal Manipulation Interface for Dexterous Manipulation
Teleoperation software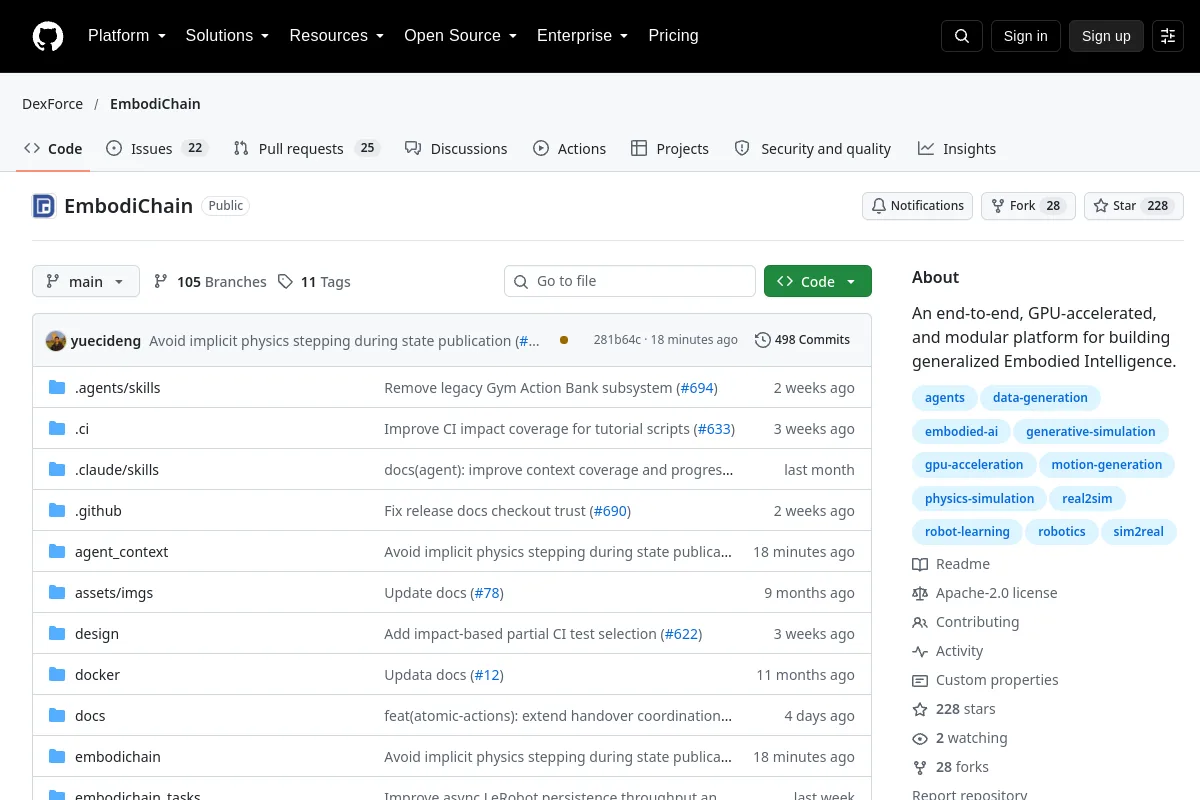 Repository
 Open source
Modular platform for embodied intelligence simulation and learning workflows.
Simulation & physics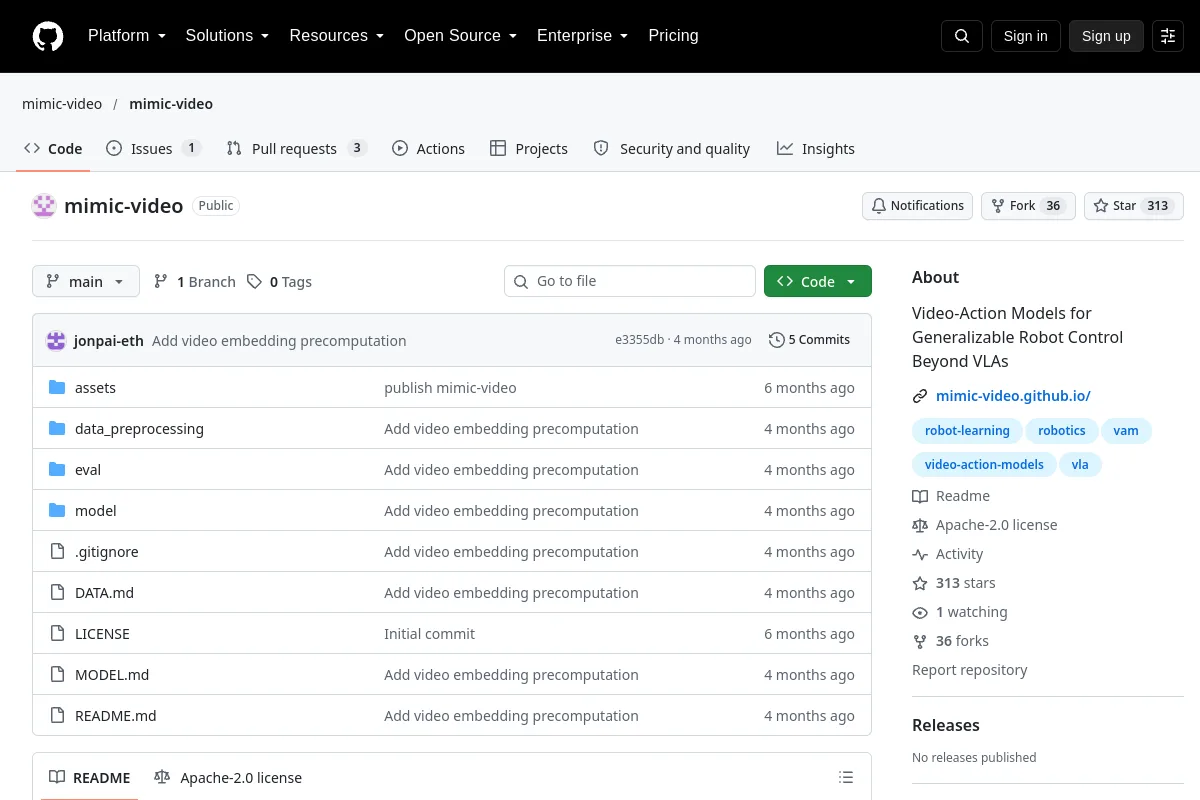 Repository
 Open source
Video-Action Models for Generalizable Robot Control Beyond VLAs
Robot learning frameworks Repository
 Research
URDF, SDF, and mesh assets for robotics projects.
Robot learning frameworks Repository
 Research
Key.Net: Keypoint Detection by Handcrafted and Learned CNN Filters
Perception & geometry Repository
 Open source
Public implementation of "Beyond Cartesian Representations for Local Descriptors", ICCV 2019
Perception & geometry Repository
 Research
Official PyTorch implementation of ODISE: Open-Vocabulary Panoptic Segmentation with Text-to-Image Diffusion Models [CVPR 2023 Highlight]
Perception & geometry Repository
 Repository
 Research
Official implementation of "Emergent Outlier View Rejection in Visual Geometry Grounded Transformers"
Perception & geometry Repository
 Research
It is one of the part of my master's thesis, involving computing the Absolute Pose Error (APE) and Relative Pose Error (RPE) of trajectories collected from two environments: PySLAM and ORB-SLAM3
Navigation & SLAM Repository
 Open source
A toy implementation of monocular SLAM written while livestreaming
Navigation & SLAM Repository
 Open source
gradslam is an open source differentiable dense SLAM library for PyTorch
Navigation & SLAM Repository
 Repository
 Open source
Motion-capture data collection tools for dexterous robot manipulation.
Robot learning frameworks Repository
 Research
DynaSLAM is a SLAM system robust in dynamic environments for monocular, stereo and RGB-D setups
Navigation & SLAM Repository
 Research
📈 RISE: 3D Perception Makes Real-World Robot Imitation Simple and Effective
Perception & geometryKnow a resource that belongs here?