 Repository
 Research
RNR-Map · rllab-snu
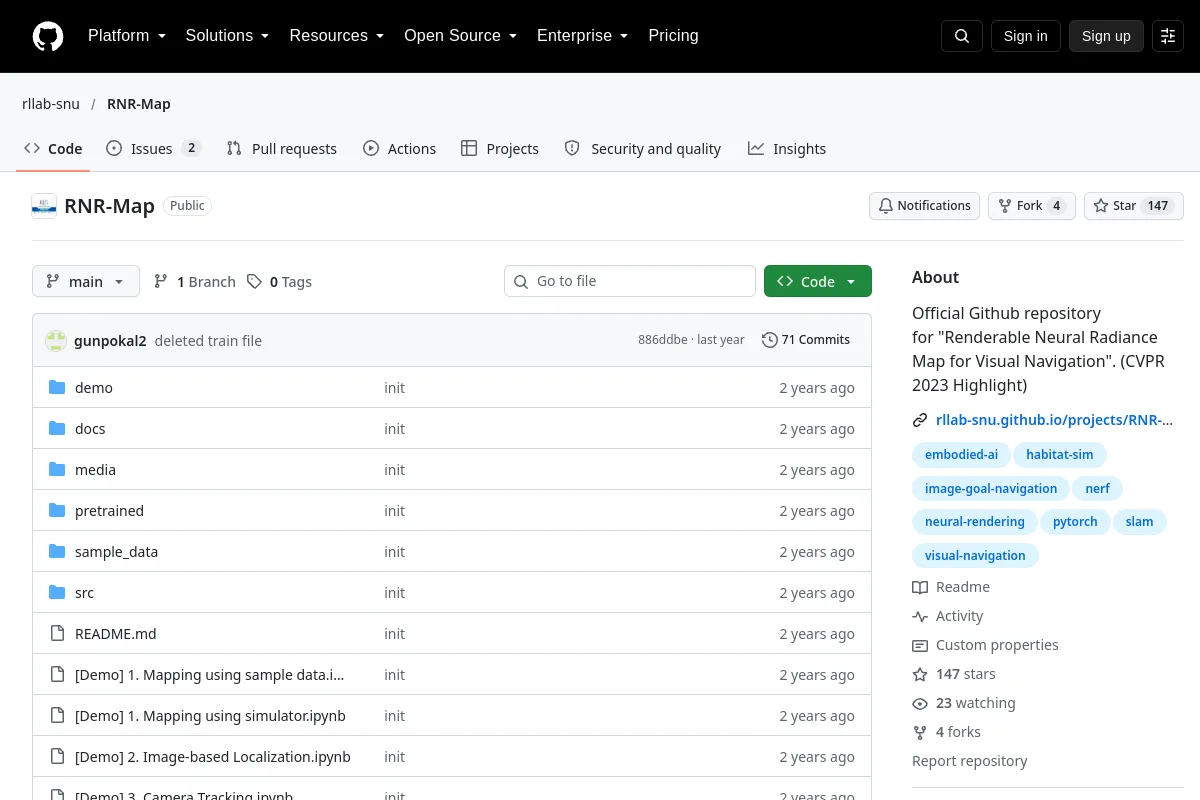
Official Github repository for "Renderable Neural Radiance Map for Visual Navigation". (CVPR 2023 Highlight)
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Explore mapping, localization, odometry and navigation software for autonomous robots.
Repository
Research
Official Github repository for "Renderable Neural Radiance Map for Visual Navigation". (CVPR 2023 Highlight)
Navigation & SLAM Repository
 Research
Autonomous exploration for ROS 2, featuring two algorithms: Wanderer (heuristic-based) and Discoverer (frontier-based, efficient for large maps). Mapping is handled by Google Cartographer (SLAM)…
Navigation & SLAM Repository
 Research
Full-stack ROS 2 autonomous navigation: Nav2, SLAM Toolbox, RTAB-Map & ORB-SLAM3 VSLAM, Gazebo Harmonic, Docker, multi-robot fleet coordination, collaborative loop closure, coordinated frontier…
Navigation & SLAM Repository
 Research
This is the official repository of the paper "Towards Physically Executable 3D Gaussian for Embodied Navigation".
Navigation & SLAM Repository
 Repository
 Research
SLAM-application collects installation and testing resources for LiDAR and visual-inertial SLAM systems.
Navigation & SLAM Repository
 Repository
 Research
slamplay is a collection of powerful tools to start playing and experimenting with SLAM in C++
Navigation & SLAM Repository
 Research
Sparse Video Generation Model for Embodied Navigation conditioned on loose language guidance, 100% real world verification
Navigation & SLAM Repository
 Research
SPOC: Imitating Shortest Paths in Simulation Enables Effective Navigation and Manipulation in the Real World
Navigation & SLAM Repository
 Research
Relative-SLAM framework using sparse bundle adjustment; maintainers recommend MOLA for newer work.
Navigation & SLAM Repository
 Research
This is a basic point-line SLAM system based on ORBSLAM2.
Navigation & SLAM Repository
 Repository
 Research
TortoiseBot is an extremely learner-friendly and cost-efficient ROS-based Open-sourced Mobile Robot that is capable of doing Teleoperation, Manual as well as Autonomous Mapping, Navigation…
Navigation & SLAM Repository
 Research
Ventura research code for task-conditioned navigation with diffusion models.
Navigation & SLAM Repository
 Research
The Visibility-Aware RRT* implementation for safety-critical navigation with perception-limited robots.
Navigation & SLAM Repository
 Research
 references for visual and semantic SLAM.
Navigation & SLAM Repository
 Research
This is an improved version of ORB-SLAM3 that adds an object detection module implemented with YOLOv5 to achieve SLAM in dynamic environments.
Navigation & SLAM Repository
 Research
ZSON: Zero-Shot Object-Goal Navigation using Multimodal Goal Embeddings. NeurIPS 2022
Navigation & SLAMSELECTION NOTES
Match sensors, coordinate frames and localization assumptions to the deployment environment. Mapping, pose estimation, path planning and obstacle avoidance serve different parts of the navigation stack.
Know a resource that belongs here?