 Repository
 Open source
KISS-Matcher · MIT-SPARK
KISS-Matcher: Fast, Robust, and Scalable Registration + ROS2 SLAM examples
Navigation & SLAMTHE EMBODIED AI DIRECTORY
Explore mapping, localization, odometry and navigation software for autonomous robots.
Repository
Open source
KISS-Matcher: Fast, Robust, and Scalable Registration + ROS2 SLAM examples
Navigation & SLAM Repository
 Open source
ROS 2 packages for connecting robots and controllers to Webots.
Navigation & SLAM Repository
 Open source
Adaptive non-maximal suppression for spatial keypoint distribution.
Navigation & SLAM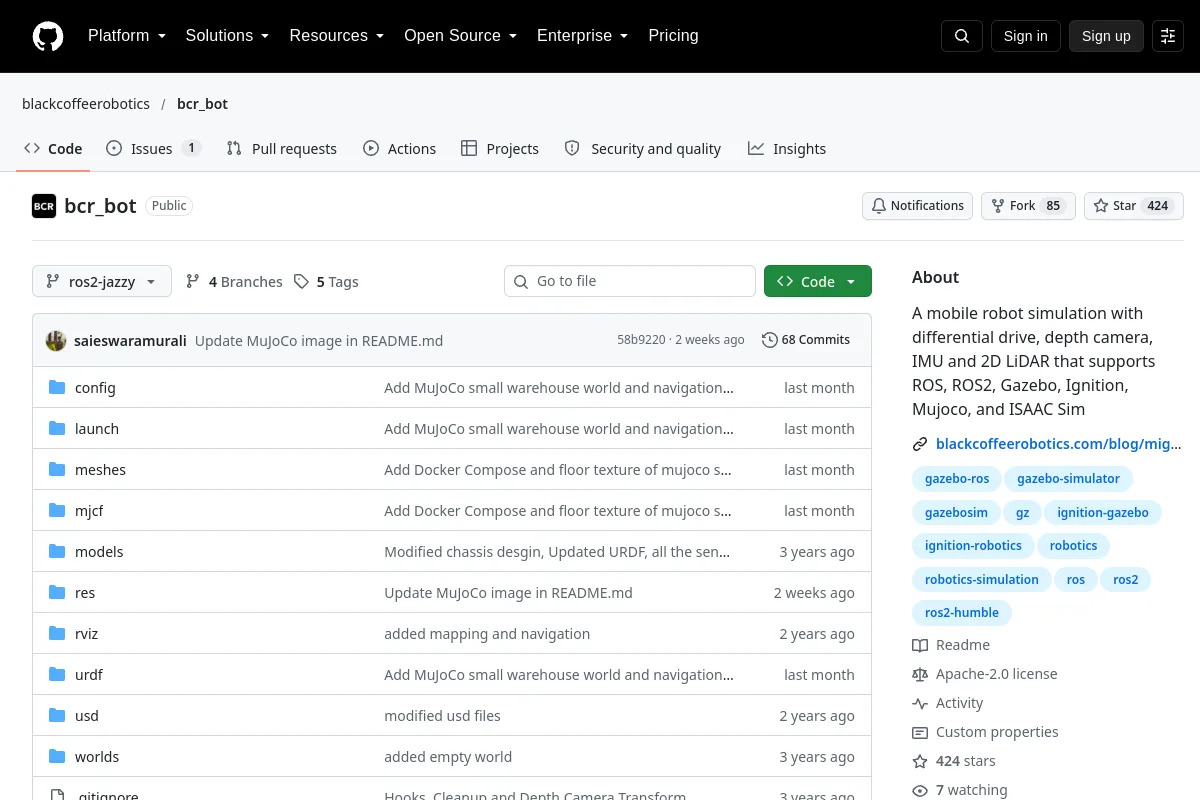 Repository
 Open source
A sensor-equipped mobile-robot model for multiple simulation platforms.
Navigation & SLAM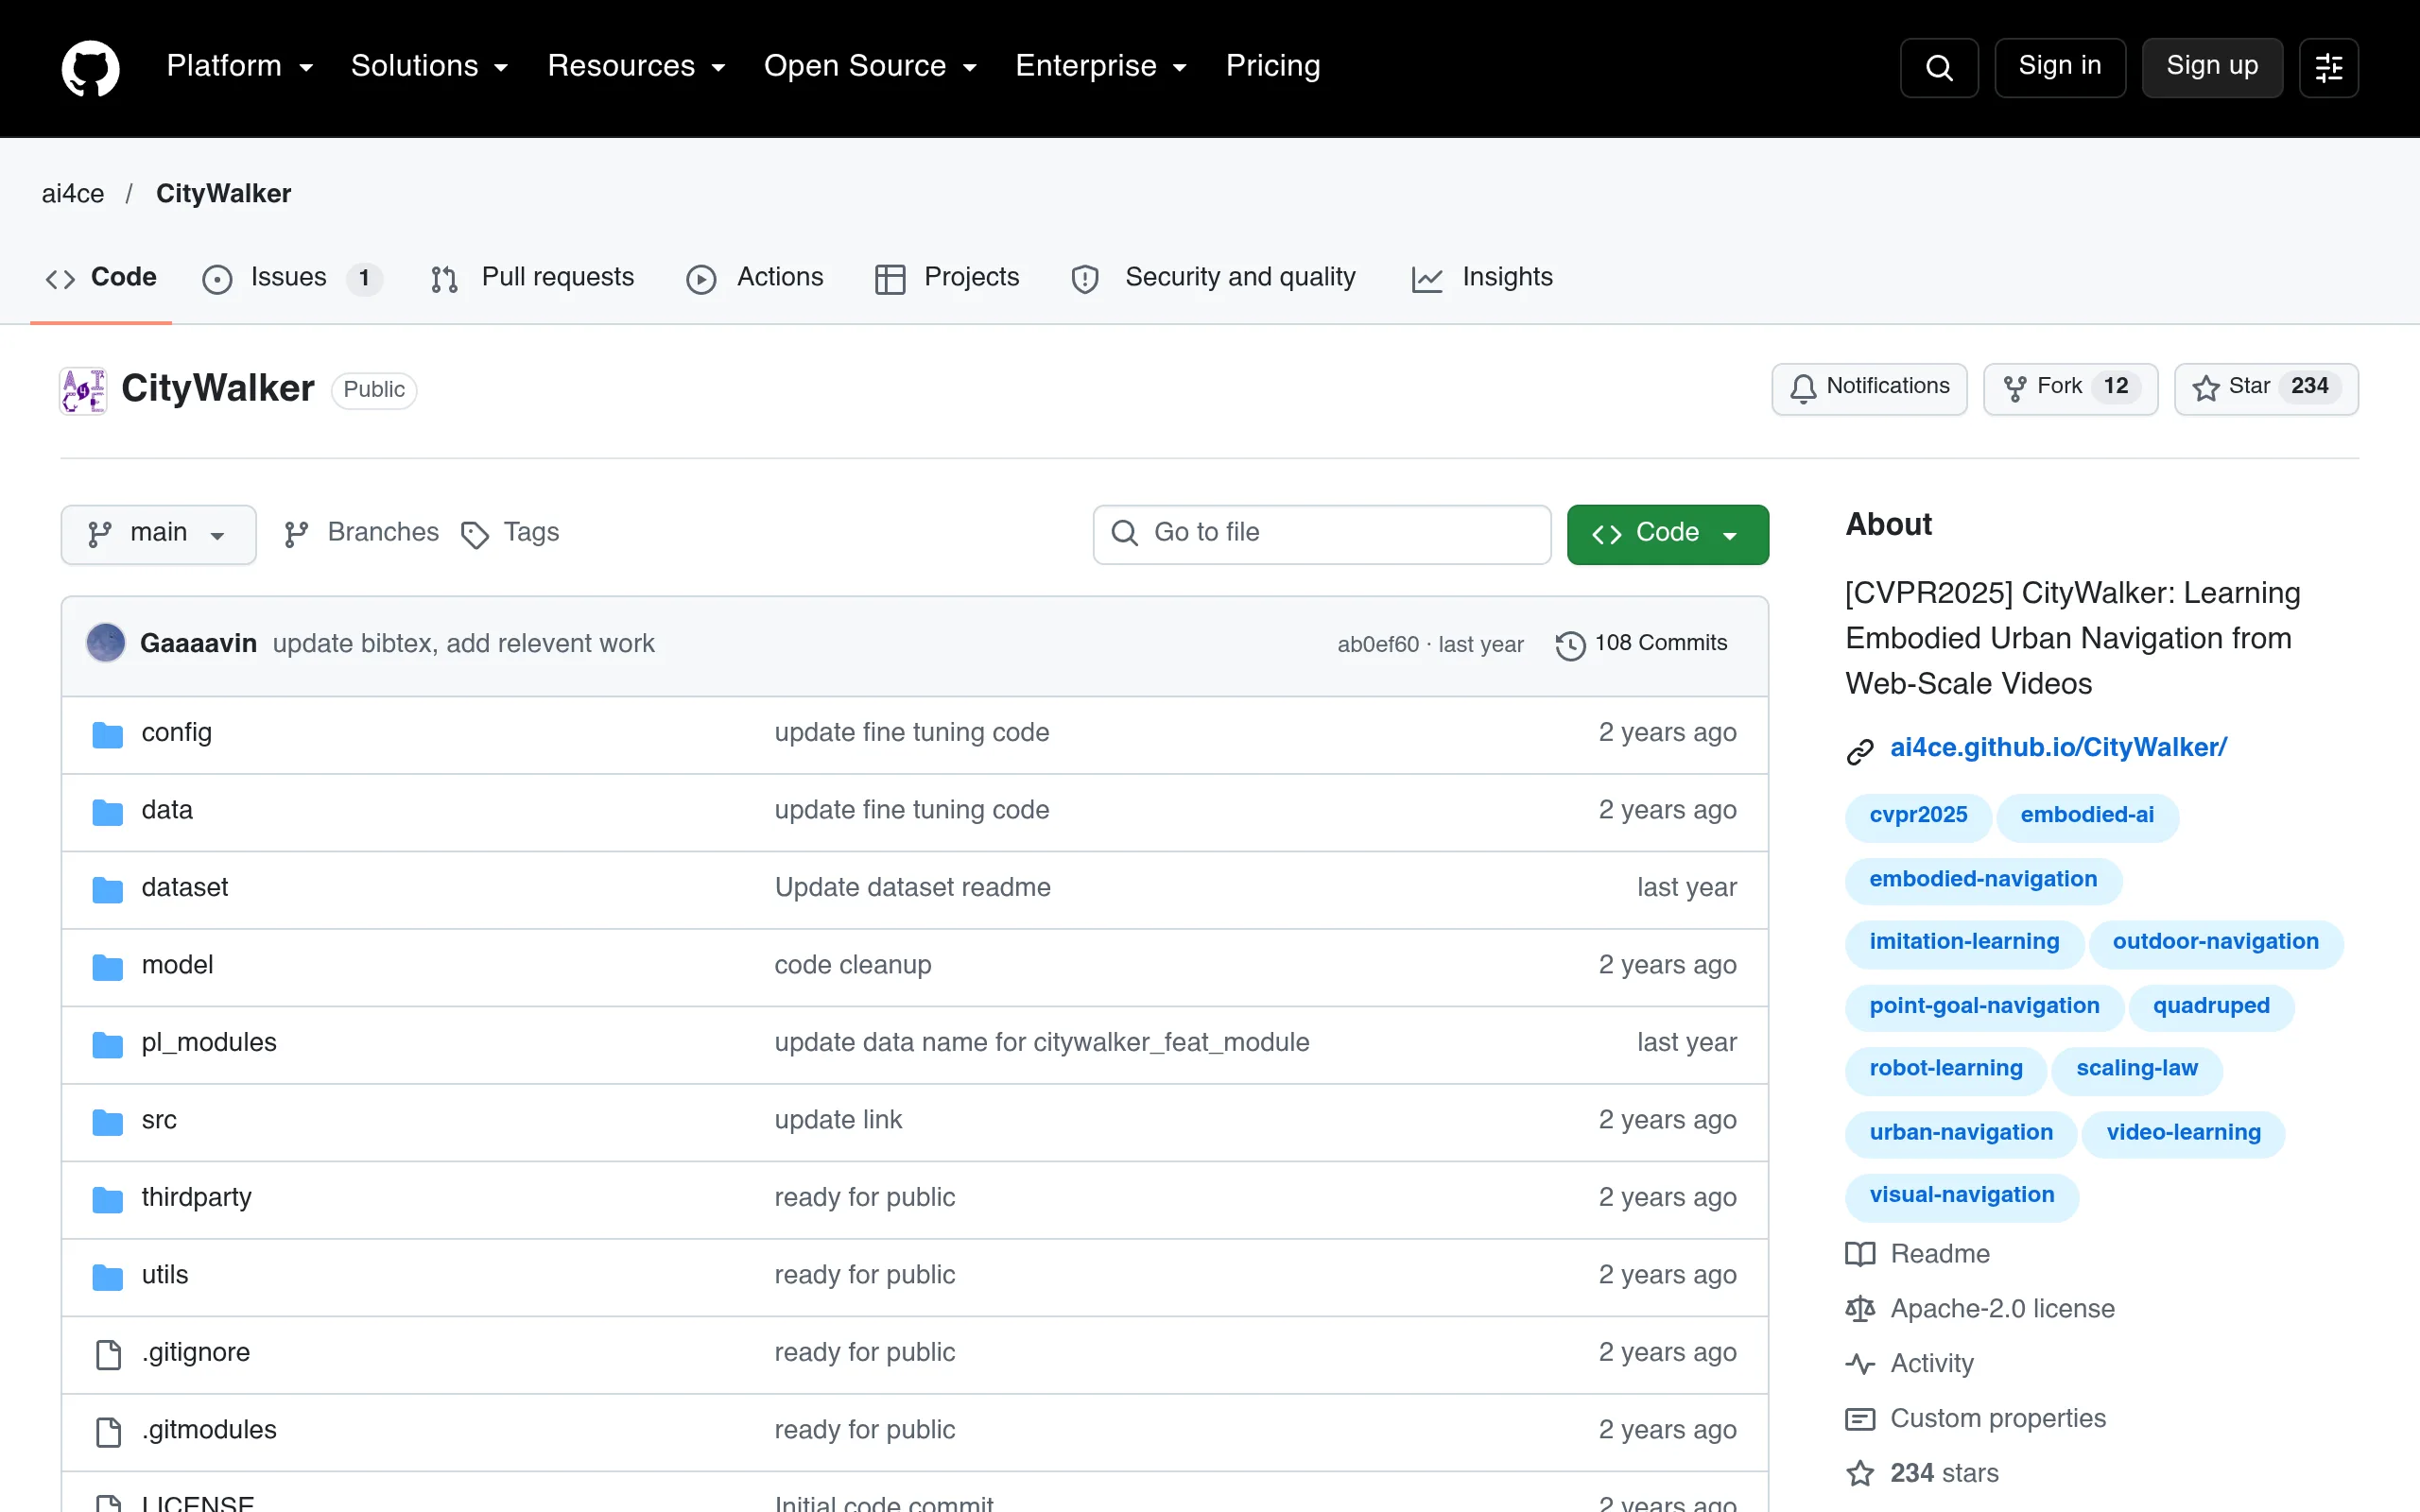 Repository
 Open source
CityWalker research code for learning embodied urban navigation from videos.
Navigation & SLAM Repository
 Repository
 Open source
Marker-based simultaneous localization and mapping for robots.
Navigation & SLAM Repository
 Open source
Official repo of "Neighbor-view Enhanced Model for Vision and Language Navigation"
Navigation & SLAM Repository
 Open source
Official implementation of "The Surprising Effectiveness of Visual Odometry Techniques for Embodied PointGoal Navigation"
Navigation & SLAM Repository
 Open source
Topological Semantic Graph Memory for Image Goal Navigation (CoRL 2022 oral)
Navigation & SLAM Repository
 Open source
📍PIN-SLAM: LiDAR SLAM Using a Point-Based Implicit Neural Representation for Achieving Global Map Consistency [TRO 24]
Navigation & SLAM Repository
 Open source
Sparse Decentralized Collaborative Simultaneous Localization and Mapping Framework for Multi-Robot Systems
Navigation & SLAM Repository
 Open source
DynaVINS : A Visual-Inertial SLAM for Dynamic Environments
Navigation & SLAM Repository
 Open source
A General Simultaneous Localization and Mapping Framework which supports feature based or direct method and different sensors including monocular camera, RGB-D sensors or any other input types can…
Navigation & SLAM Repository
 Open source
A toy implementation of monocular SLAM written while livestreaming
Navigation & SLAM Repository
 Open source
gradslam is an open source differentiable dense SLAM library for PyTorch
Navigation & SLAM Repository
 Repository
 Open source
A Robust, Real-time, INS-Centric GNSS-Visual-Inertial Navigation System
Navigation & SLAM Repository
 Open source
**Loosely-Coupled Semi-Direct Monocular SLAM**
Navigation & SLAM Repository
 Open source
OV²SLAM is a Fully Online and Versatile Visual SLAM for Real-Time Applications
Navigation & SLAM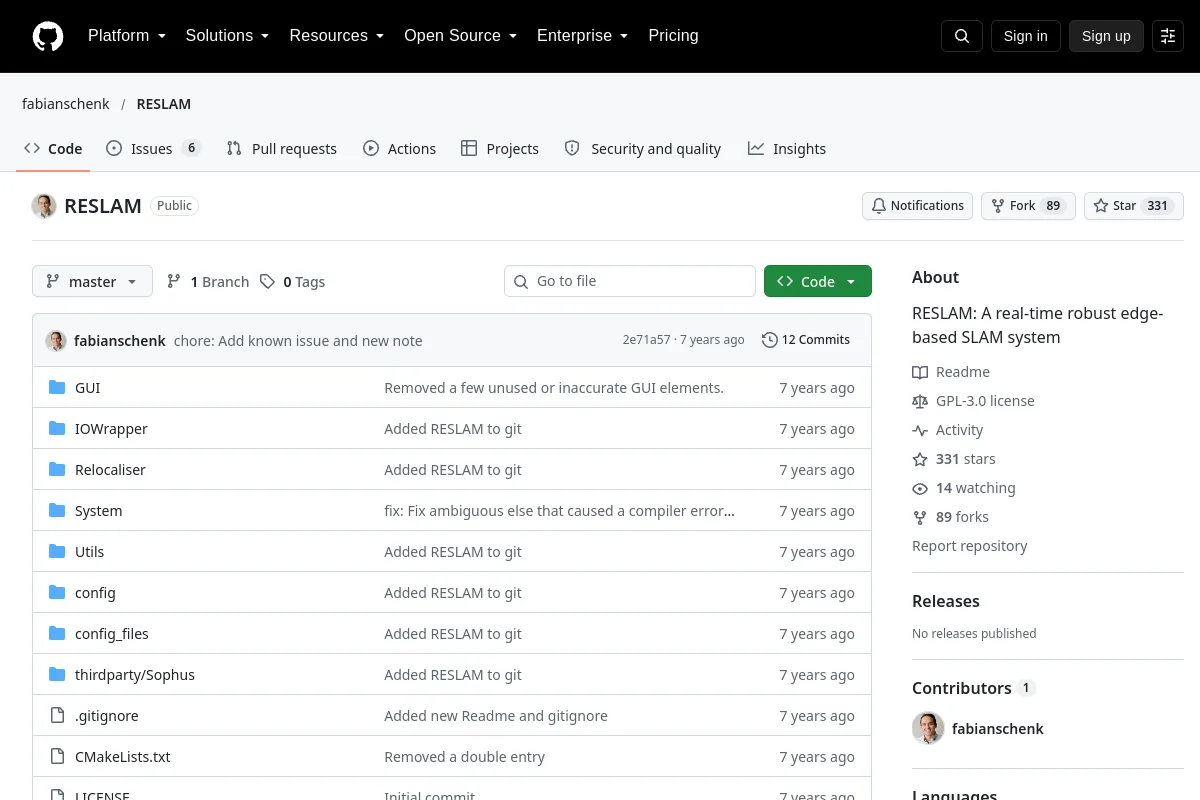 Repository
 Open source
RESLAM: A real-time robust edge-based SLAM system
Navigation & SLAM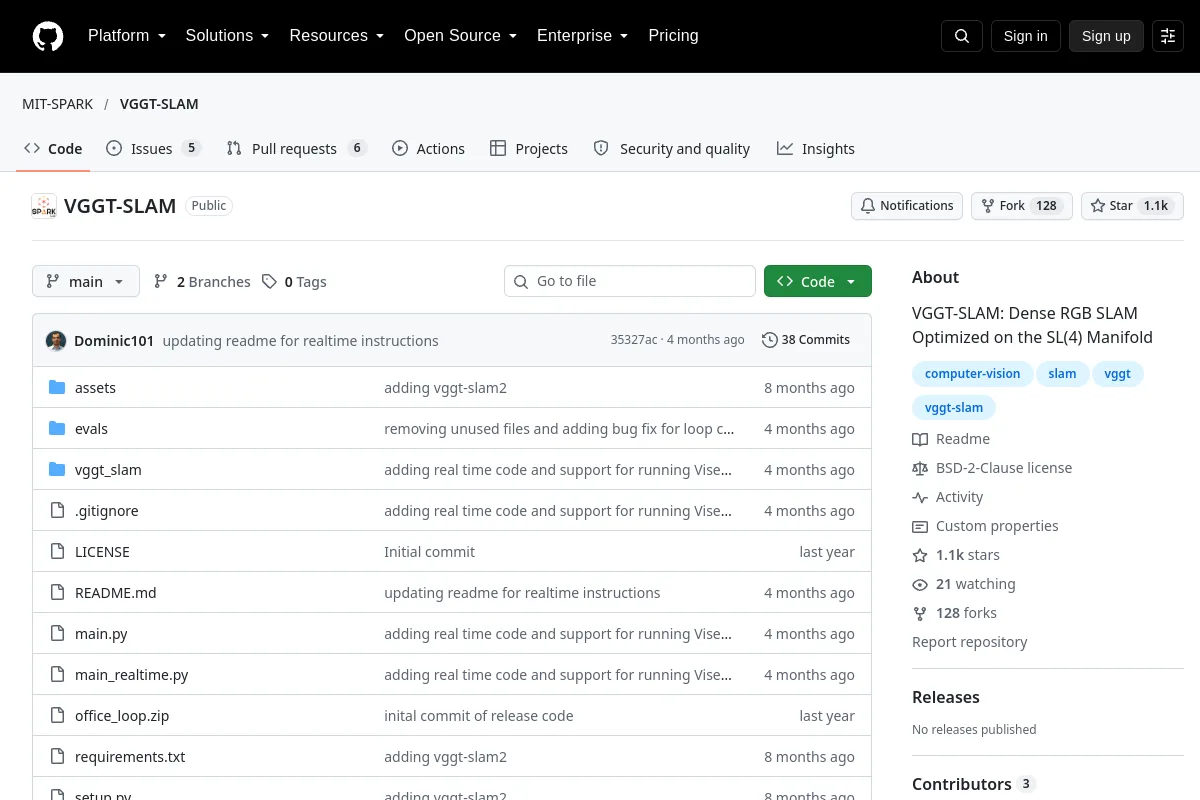 Repository
 Open source
VGGT-SLAM: Dense RGB SLAM Optimized on the SL(4) Manifold
Navigation & SLAM Repository
 Open source
A learning roadmap for visual-SLAM development.
Navigation & SLAM Repository
 Open source
Visual SLAM/odometry package based on NVIDIA-accelerated cuVSLAM
Navigation & SLAMSELECTION NOTES
Match sensors, coordinate frames and localization assumptions to the deployment environment. Mapping, pose estimation, path planning and obstacle avoidance serve different parts of the navigation stack.
Know a resource that belongs here?