 Repository
 Open source
maple-sim · Shenzhen-Robotics-Alliance
Elevating FRC Java Robot Simulations to the Next Level with Physics Engines
Simulation & physicsTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
Elevating FRC Java Robot Simulations to the Next Level with Physics Engines
Simulation & physics Repository
 Open source
My End-of-Degree thesis. Visual SLAM, DL, 3D sparse and dense maps and Computer Vision.
Navigation & SLAM Repository
 Open source
MATRiX is an advanced simulation platform that integrates MuJoCo, Unreal Engine 5, and CARLA to provide high-fidelity, interactive environments for robotics research.
Simulation & physics Repository
 Open source
A digital twin for robotics-assisted chemistry laboratory automation.
Simulation & physics Repository
 Open source
Container format and tooling for pub/sub and robotics recordings.
Robot learning frameworks Repository
 Open source
A ROS package for probabilistic mobile-robot localization with 3D lidar.
Navigation & SLAM Repository
 Open source
MesaTask: Towards Task-Driven Tabletop Scene Generation via 3D Spatial Reasoning
Robot learning frameworks Repository
 Open source
Driving simulator for autonomous-driving research and multi-agent experiments.
Simulation & physics Repository
 Repository
 Open source
MIGHTY: Hermite spline-based real-time trajectory planner for single- and multi-agent UAVs and ground robots (ROS 2). Accepted to IEEE RA-L.
Motion planning & control Repository
 Open source
Factor-graph framework for nonlinear least-squares optimization.
Navigation & SLAM Repository
 Repository
 Repository
 Open source
The ModAR world-action model implementation with RoboTwin training workflows.
Robot learning frameworks Repository
 Open source
Research on distilling motion-planner policies into visual robot control.
Motion planning & control Repository
 Open source
Mosaico - The data platform for Physical AI
Visualization & data tools Repository
 Open source
A repository for affordable, easy-to-assemble robot arms designed for teleoperation applications.
Teleoperation software Repository
 Open source
🤖 A motion planning MATLAB & V-rep implementation for the KUKA LBR iiwa robotic arm, performing null-space reconfiguration for obstacle avoidance.
Motion planning & control Repository
 Open source
Robot path planning, mapping and exploration algorithms
Navigation & SLAM Repository
 Open source
Algorithm and model experiments for robot motion planning. Implemented in Julia.
Motion planning & control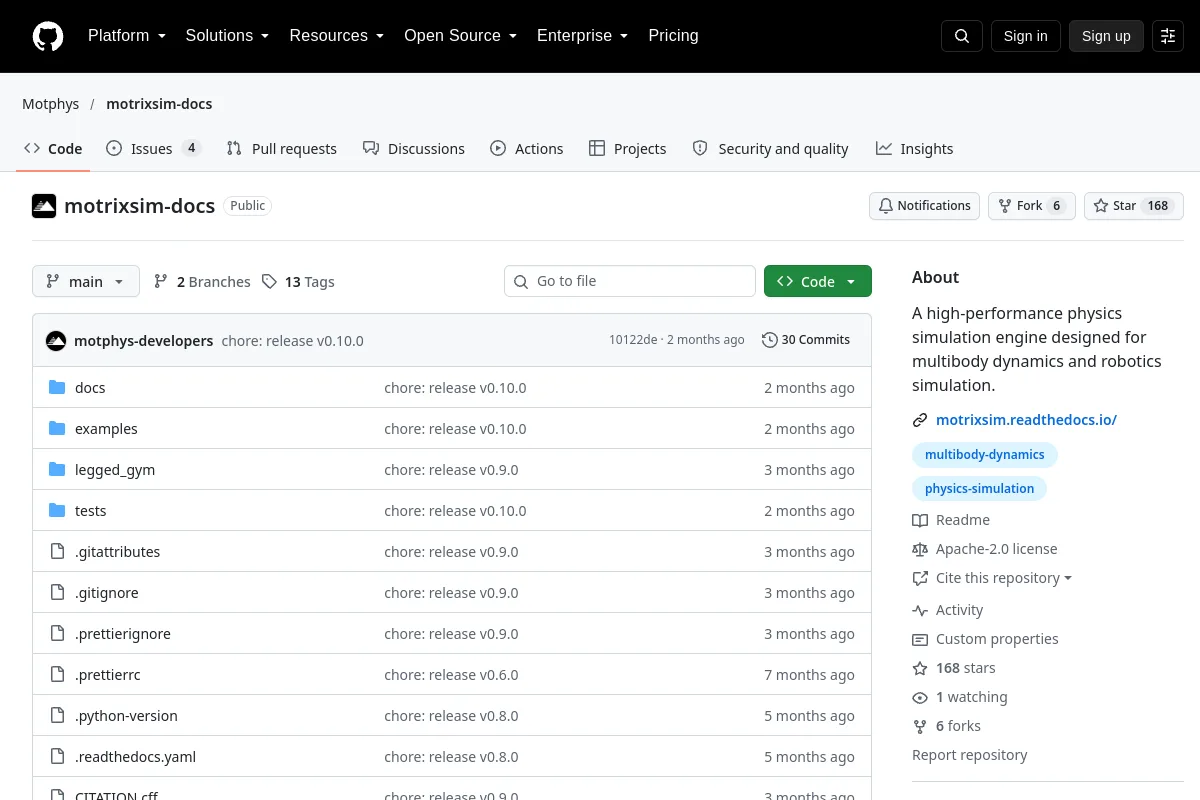 Repository
 Open source
Documentation for the MotrixSim multibody dynamics and robotics simulation engine.
Motion planning & control Repository
 Repository
 Open source
ROS packages and Arduino scripts that can be used to control the BCN3D Moveo robotic arm in simulation and real-life.
Simulation & physics Repository
 Open source
MPC-guided RL for Humanoid Locomotion and Manipulation
Motion planning & controlKnow a resource that belongs here?