 Repository
 Open source
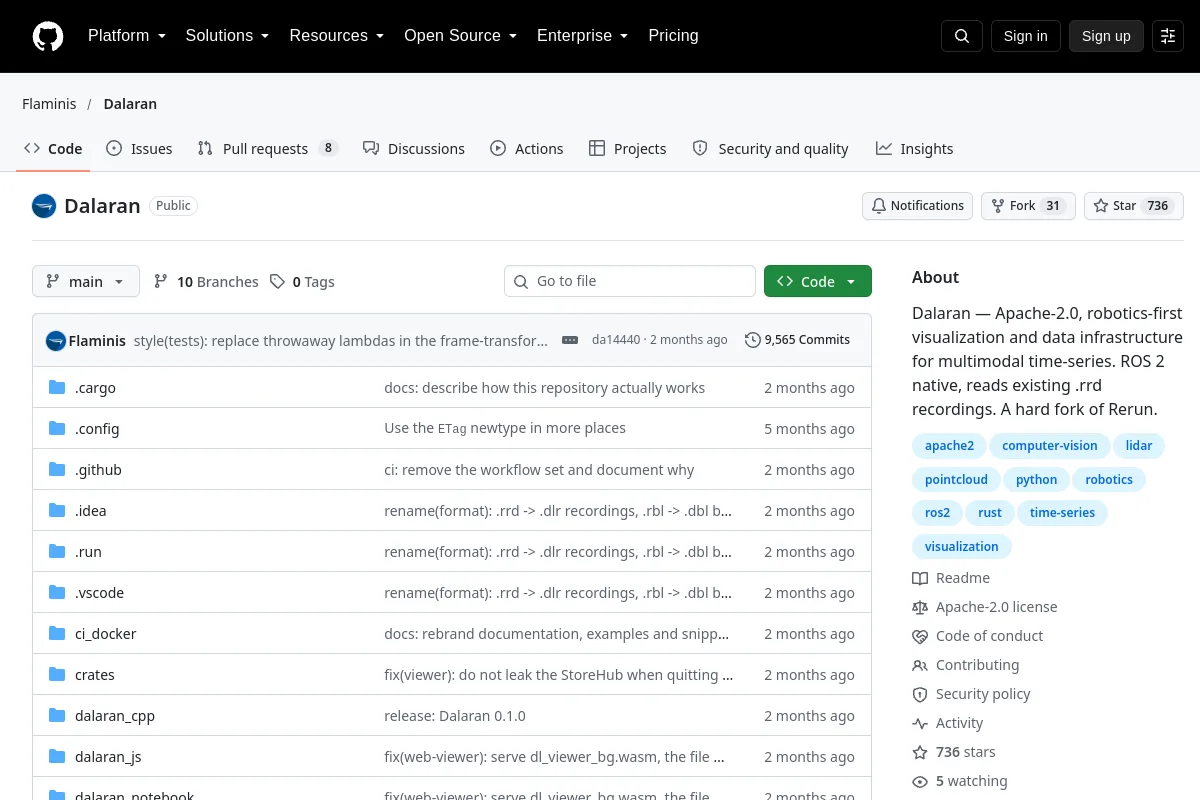
Dalaran · Flaminis
Visualization and data infrastructure for robotics multimodal time series.
Visualization & data toolsTHE EMBODIED AI DIRECTORY
Discover robot simulation software, ROS 2 middleware, motion planning and Python robot learning tools.
Repository
Open source
Visualization and data infrastructure for robotics multimodal time series.
Visualization & data tools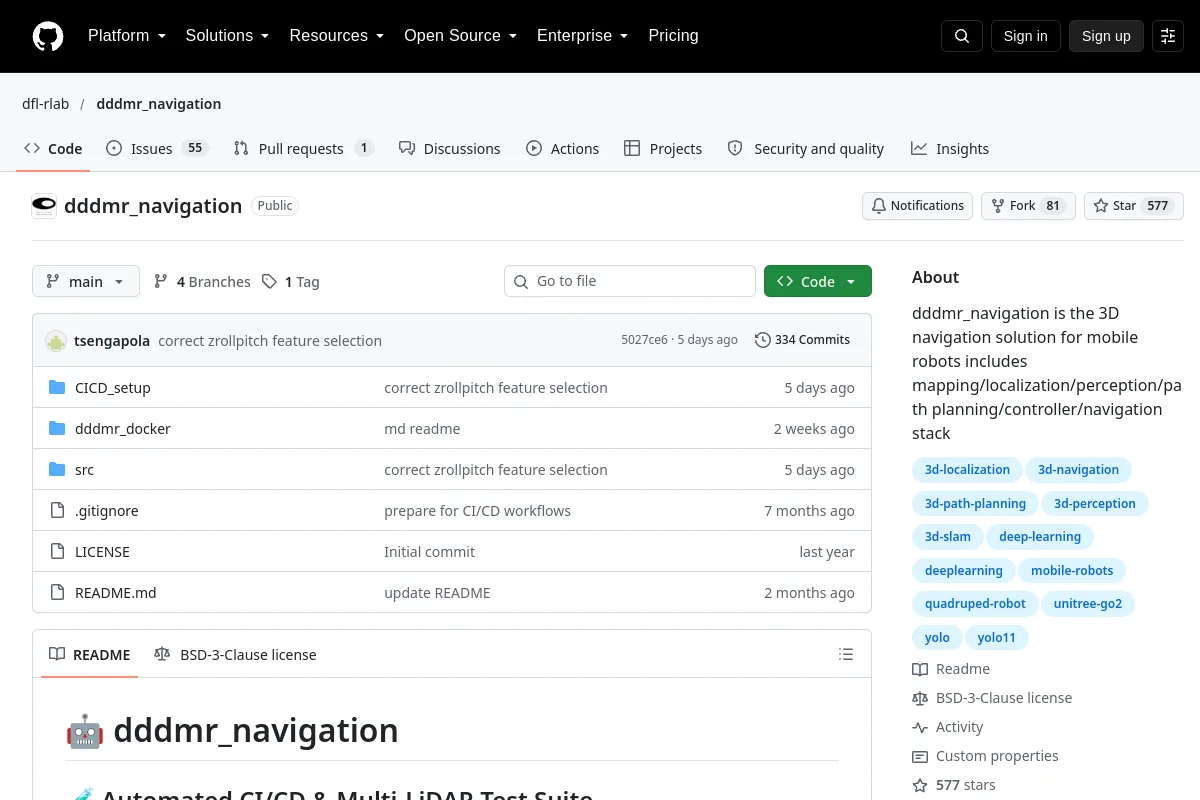 Repository
 Open source
dddmr_navigation is the 3D navigation solution for mobile robots includes mapping/localization/perception/path planning/controller/navigation stack
Navigation & SLAM Repository
 Open source
A Python reinforcement-learning wrapper for Webots.
Simulation & physics Repository
 Open source
The Official Deep Learning Framework for Robot Place Learning
Navigation & SLAM Repository
 Open source
Robot learning research using separate forward and inverse dynamics pretraining.
Motion planning & control Repository
 Open source
Self-supervised Deep LiDAR Odometry for Robotic Applications
Navigation & SLAM Repository
 Open source
Learning Dexterous Manipulation Skills from Imperfect Simulations
Simulation & physics Repository
 Open source
Path planning and control algorithms for a differential drive robot using ROS2
Motion planning & control Repository
 Open source
Libraries, tools and tasks for robotics research from Google DeepMind.
Robot learning frameworks Repository
 Open source
Docker and Docker Compose practices for ROS simulation and hardware workflows.
Simulation & physics Repository
 Repository
 Open source
Software for Mark Rober's Domino Robot project.
Robot learning frameworks Repository
 Open source
URDF model of the Draco3 humanoid robot.
Robot learning frameworks Repository
 Open source
Dream to Control: Learning Behaviors by Latent Imagination, implemented in PyTorch.
Robot learning frameworks Repository
 Open source
Deep reinforcement-learning experiments for robotic grasping from octrees.
Simulation & physics Repository
 Open source
Self-Learning Exploration and Mapping for Mobile Robots via Deep Reinforcement Learning
Navigation & SLAM Repository
 Open source
End-to-End SLAM with camera calibration, monocular prior integration and dense Rendering
Navigation & SLAM Repository
 Open source
DSP-SLAM: Object Oriented SLAM with Deep Shape Priors
Navigation & SLAM Repository
 Open source
Implementation of the D* lite algorithm in Python for "Improved Fast Replanning for Robot Navigation in Unknown Terrain"
Navigation & SLAM Repository
 Open source
A ROS implementation of the Dynamic Window Approach planner.
Navigation & SLAM Repository
 Open source
A point-cloud registration pipeline for robot localization and 3D perception.
Navigation & SLAM Repository
 Open source
A simulation system based on ROS and Gazebo which is specially built for multi-robot task allocation (exploration and destruction problem)
Simulation & physics Repository
 Open source
Master's Thesis on Simultaneous Localization and Mapping in dynamic environments. Separately reconstructs both the static environment and the dynamic objects from it, such as cars.
Navigation & SLAM Repository
 Open source
Examples of efficient trajectory optimization for robot motion planning
Motion planning & controlKnow a resource that belongs here?