 Repository
 Open source
CLOVER · OpenDriveLab
CLOVER: Closed-Loop Visuomotor Control with Generative Expectation for Robotic Manipulation
Robot policiesTHE EMBODIED AI DIRECTORY
Explore vision-language-action models and robotics foundation models for perception, manipulation and control.
Repository
Open source
CLOVER: Closed-Loop Visuomotor Control with Generative Expectation for Robotic Manipulation
Robot policies Repository
 Open source
RDT-1B: a Diffusion Foundation Model for Bimanual Manipulation
Vision-language-action Repository
 Open source
Code accompanying the paper "Learning Agile Robotic Locomotion Skills by Imitating Animals"
Robot policies Repository
 Open source
SPA: 3D Spatial-Awareness Enables Effective Embodied Representation
Perception models Repository
 Open source
Official codebase for Manipulation Primitive-augmented reinforcement Learning (MAPLE)
Robot policies Repository
 Open source
DexMV: Imitation Learning for Dexterous Manipulation from Human Videos, ECCV 2022
Robot policies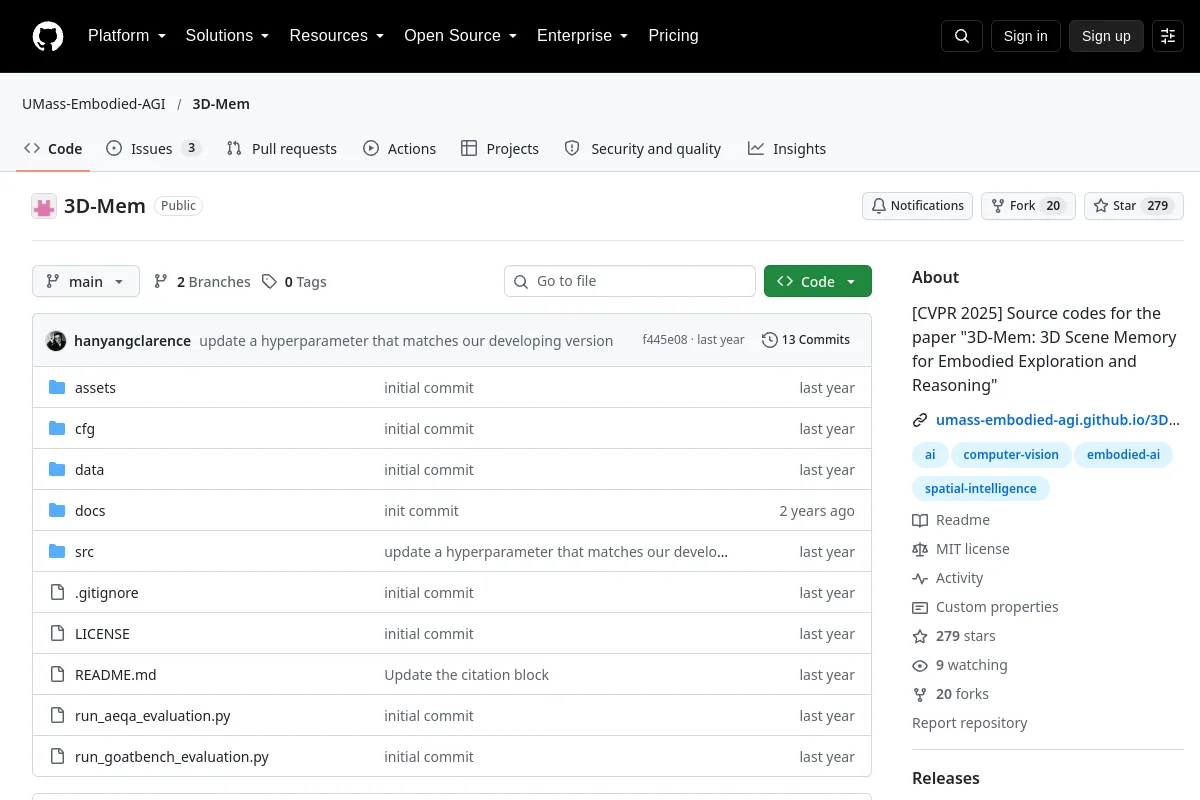 Repository
 Open source
Source codes for the paper "3D-Mem: 3D Scene Memory for Embodied Exploration and Reasoning"
Language-guided planning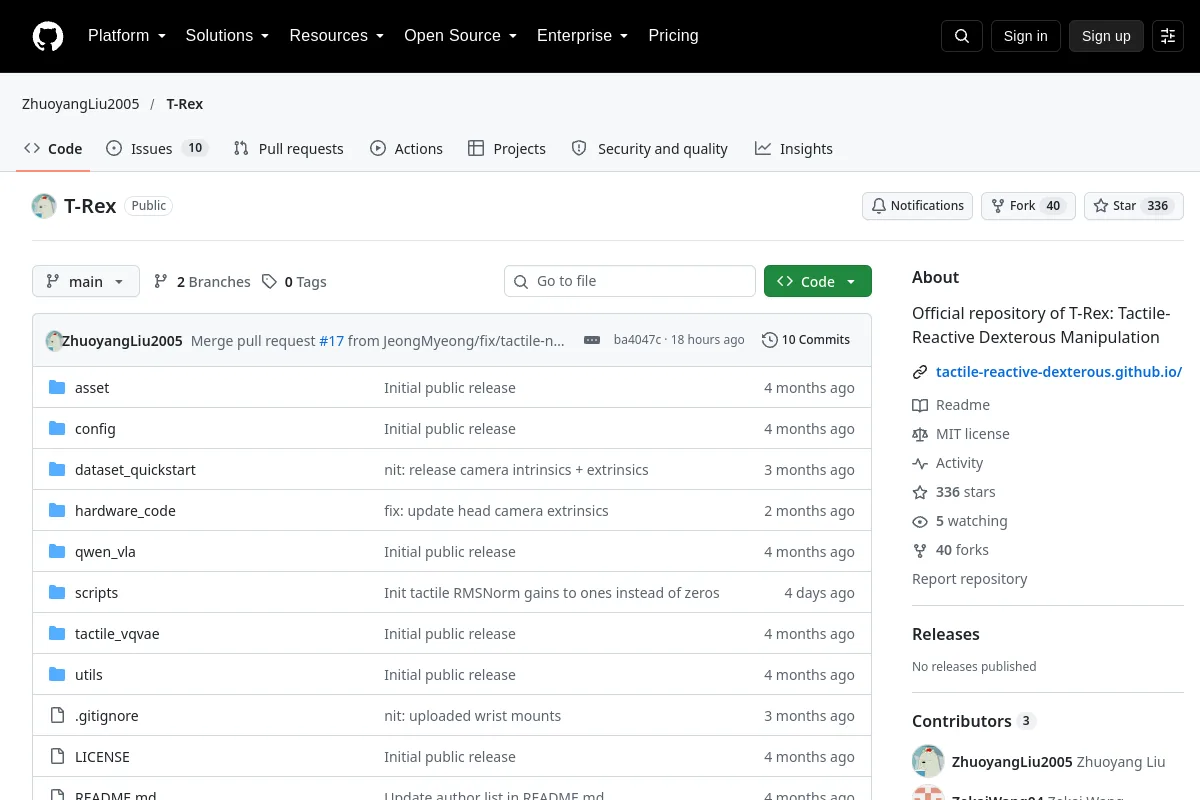 Repository
 Open source
Official repository of T-Rex: Tactile-Reactive Dexterous Manipulation
Robot policies Repository
 Open source
Language-guided whole-body control for general humanoid robots
Robot policies Repository
 Open source
Official Code for "Language Models as Zero-Shot Planners: Extracting Actionable Knowledge for Embodied Agents"
Language-guided planning Repository
 Open source
"FALCON: Learning Force-Adaptive Humanoid Loco-Manipulation"
Robot policies Repository
 Open source
Building General-Purpose Robots Based on Embodied Foundation Model
Vision-language-action Repository
 Open source
Codebase for DexMachina: Functional Retargeting for Bimanual Dexterous Manipulation
Robot policies Repository
 Open source
A Minimalist Retargeting-Guided Reinforcement Learning Recipe for Dexterous Manipulation
Robot policies Repository
 Open source
Visual Imitation Enables Contextual Humanoid Control. CoRL 2025, Best Student Paper Award.
Robot policies Repository
 Open source
https://arxiv.org/abs/2312.10807
Robot policies Repository
 Open source
The official repository for paper: Agentic Robot: A Brain-Inspired Framework for Vision-Language-Action Models in Embodied Agents
Vision-language-action Repository
 Open source
The offical Implementation of "DecisionNCE: Embodied Multimodal Representations via Implicit Preference Learning"
Perception models Repository
 Open source
The first framework enabling humanoid robots to learn whole-body loco-manipulation from egocentric human demos
Robot policies Repository
 Open source
G3Flow: Generative 3D Semantic Flow for Pose-aware and Generalizable Object Manipulation
Robot policies Repository
 Open source
PyTorch Code for "Generalization in Dexterous Manipulation via Geometry-Aware Multi-Task Learning"
Robot policies Repository
 Open source
🎉 Official repository of "ManipTrans: Efficient Dexterous Bimanual Manipulation Transfer via Residual Learning"
Robot policies Repository
 Repository
 Open source
Pelican-VL 1.0 is a new family of open-source embodied brain models with parameter scales ranging from 7B to 72B developed by WFM System Group, Beijing Innovation Center of Humanoid Robotics…
Vision-language-actionKnow a resource that belongs here?