 Repository
Models / Open source
CLOVER · OpenDriveLab
CLOVER: Closed-Loop Visuomotor Control with Generative Expectation for Robotic Manipulation
Overview
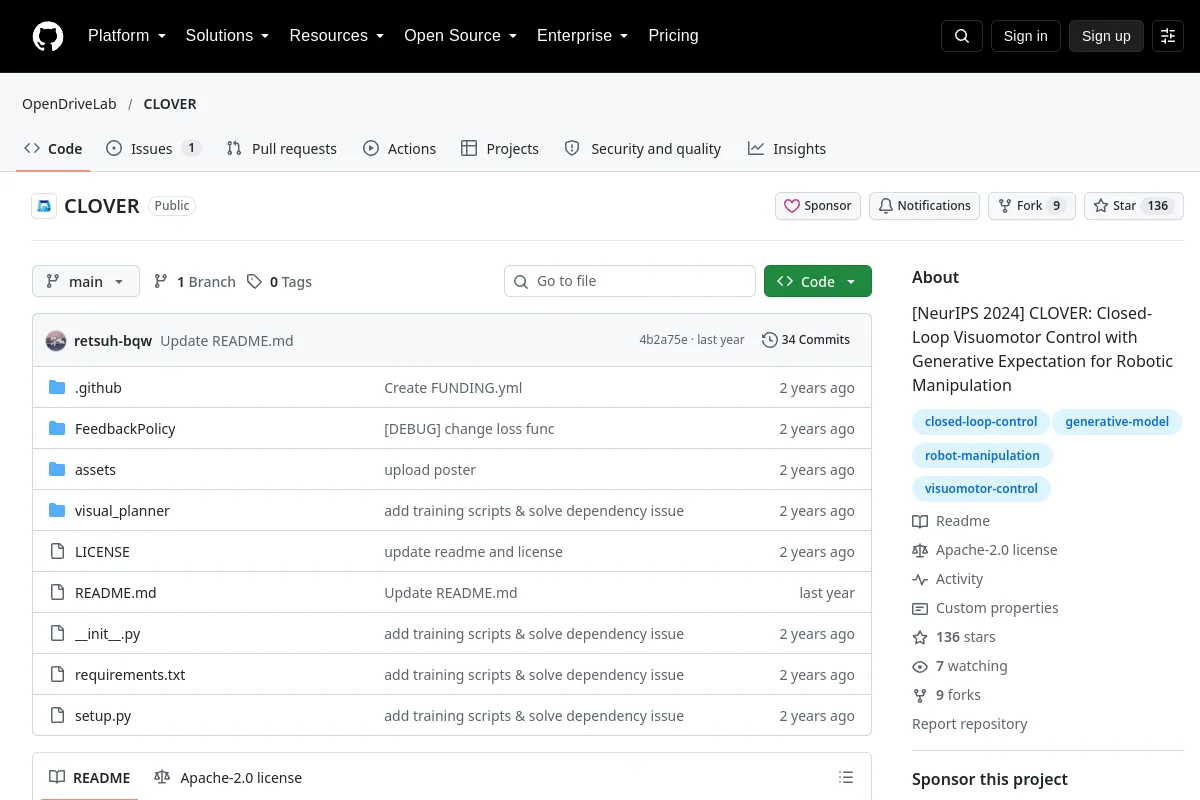
CLOVER: Closed-Loop Visuomotor Control with Generative Expectation for Robotic Manipulation
Publisher purpose: [NeurIPS 2024] CLOVER: Closed-Loop Visuomotor Control with Generative Expectation for Robotic Manipulation
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Project information
- Maintainer
- OpenDriveLab
- Primary language
- Python
- Repository code license
- Apache-2.0
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2025-09-08
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- :fire: Highlight
- :loudspeaker: News
- :pushpin: TODO list
- :video_game: Getting started <a name="installation"></a>
- :cd: Checkpoints
- Training of Visual Planner <a name="TrainingVP"></a>
Browse this resource’s categories
Explore related collections
Browse Models →More in Models
Repository