 Repository
 Open source
dex-hand-teleop · yzqin
From One Hand to Multiple Hands: Imitation Learning for Dexterous Manipulation from Single-Camera Teleoperation, RA-L IROS 2022
Teleoperation softwareTHE EMBODIED AI DIRECTORY
Explore software interfaces and retargeting tools for remotely controlling robots and collecting demonstrations.
Repository
Open source
From One Hand to Multiple Hands: Imitation Learning for Dexterous Manipulation from Single-Camera Teleoperation, RA-L IROS 2022
Teleoperation software Repository
 Open source
Open-source HandUMI software for synchronized bimanual data collection and retargeting to any bimanual robot. Includes calibration, QA, replay, and teleoperation.
Teleoperation software Repository
 Open source
Hand-motion retargeting tools for dexterous robot teleoperation.
Teleoperation software Repository
 Open source
Mobile ALOHA learning and teleoperation resources for bimanual mobile manipulation.
Teleoperation software Repository
 Open source
Extracts and retargets FBX animations into robot motion references.
Teleoperation software Repository
 Open source
SO-101 robot learning stack with teleoperation and MuJoCo learning workflows.
Teleoperation software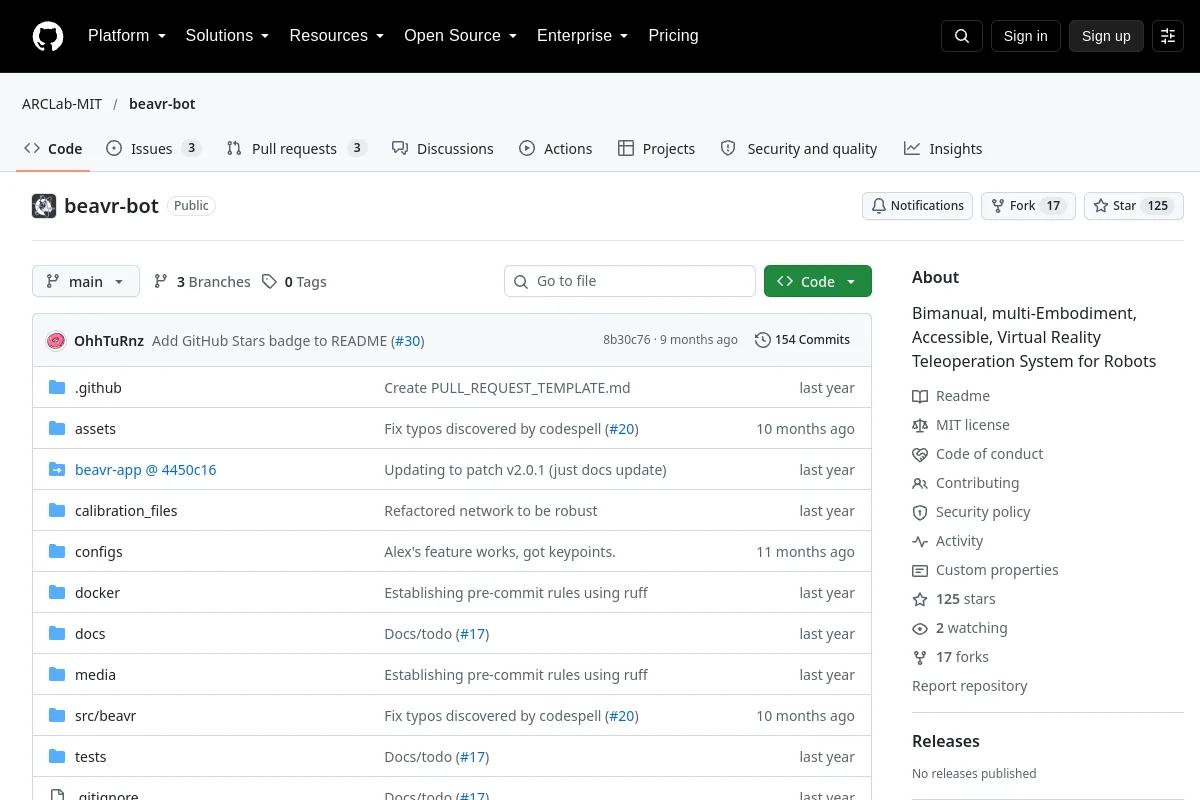 Repository
 Open source
Bimanual, multi-Embodiment, Accessible, Virtual Reality Teleoperation System for Robots
Teleoperation software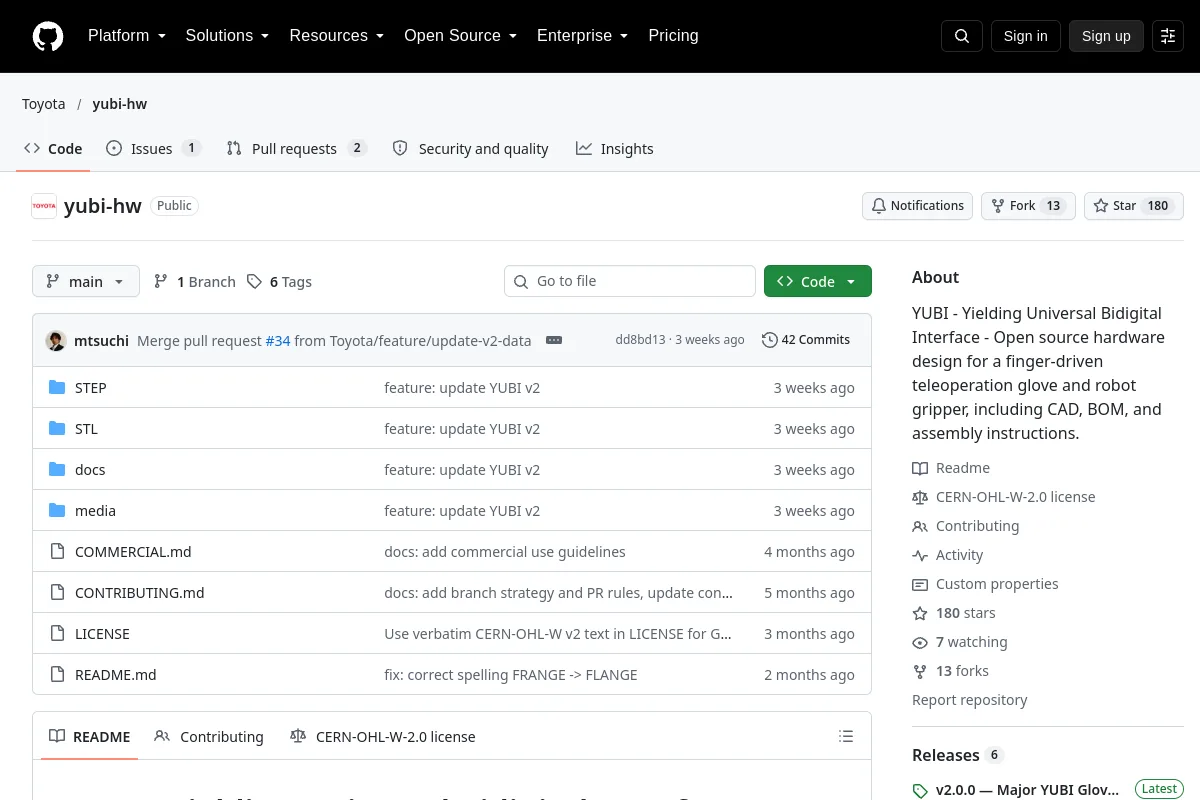 Repository
 Open source
YUBI - Yielding Universal Bidigital Interface - Open source hardware design for a finger-driven teleoperation glove and robot gripper, including CAD, BOM, and assembly instructions.
Teleoperation software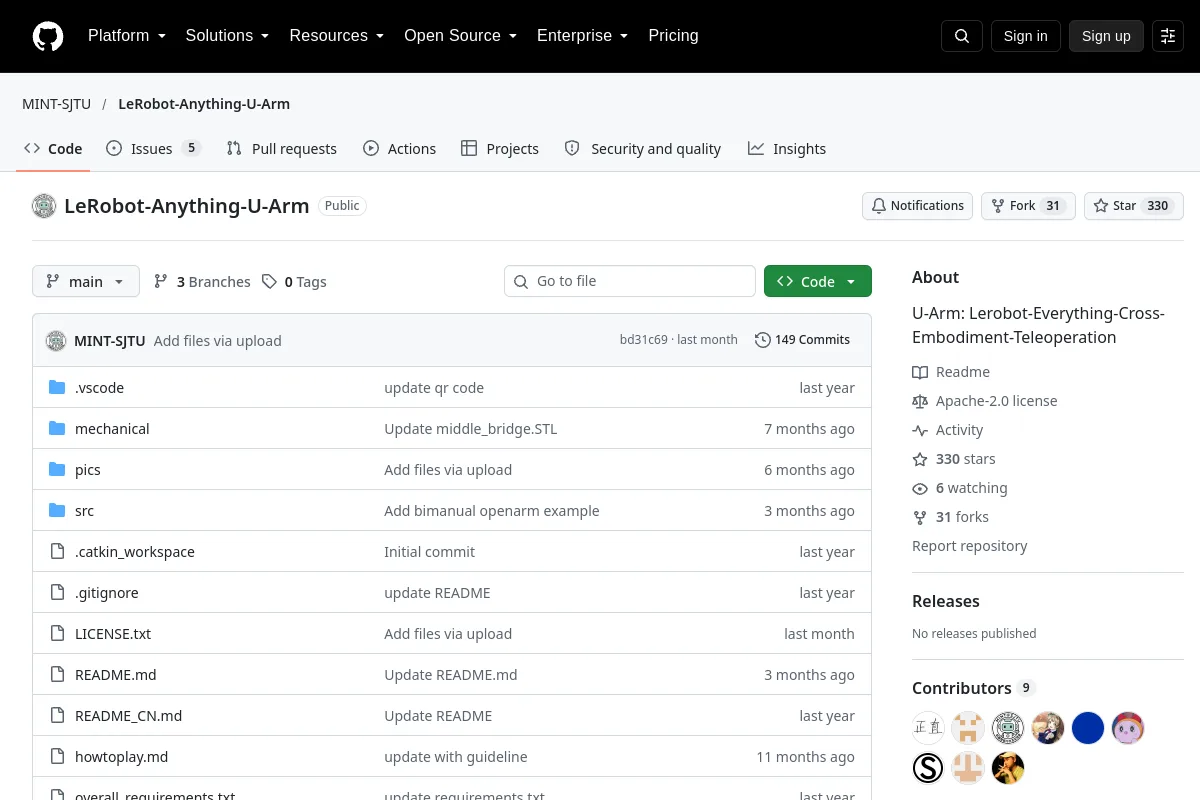 Repository
 Open source
U-Arm: Lerobot-Everything-Cross-Embodiment-Teleoperation
Teleoperation software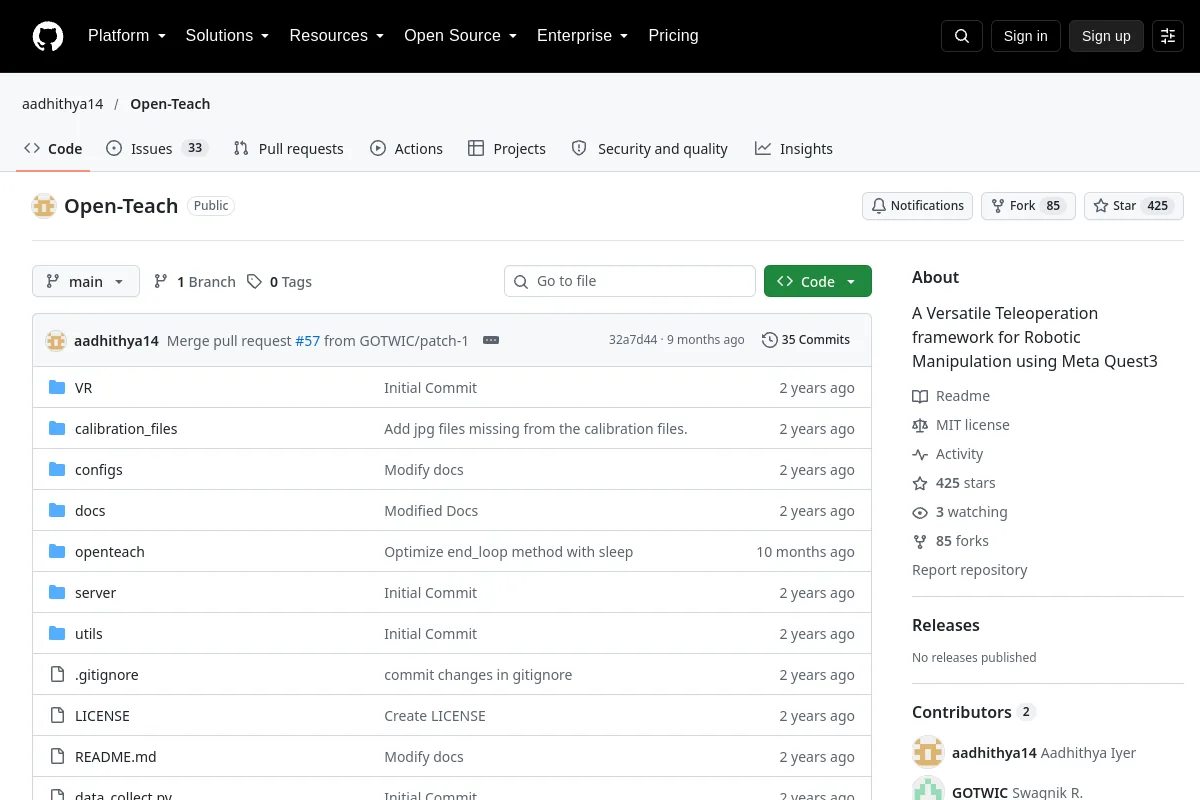 Repository
 Open source
A Versatile Teleoperation framework for Robotic Manipulation using Meta Quest3
Teleoperation software Repository
 Open source
DexUMI: Using Human Hand as the Universal Manipulation Interface for Dexterous Manipulation
Teleoperation software Repository
 Open source
A browser-based robotics studio for scenes, demonstrations and experiments.
Teleoperation software Repository
 Open source
ROS2 package implementing a teleoperation interface using QT
Teleoperation software Repository
 Open source
HEI ReBot Lift is a LeRobot/ReBot-based dual-arm mobile robot with a lifting platform, omnidirectional chassis, three-view vision, and a VR + MuJoCo + Pinocchio IK teleoperation pipeline. It…
Teleoperation software Repository
 Open source
The unified framework for sim & real robot teleoperation
Teleoperation software Repository
 Open source
Joycon-Robotics: Low-Cost, Convenient Teleoperation for One- and Two-Arm Robots
Teleoperation software Repository
 Open source
This repository implements teleoperation of the Unitree humanoid robot H1 / G1 using Azure Kinect DK camera.
Teleoperation software Repository
 Open source
A repository for affordable, easy-to-assemble robot arms designed for teleoperation applications.
Teleoperation software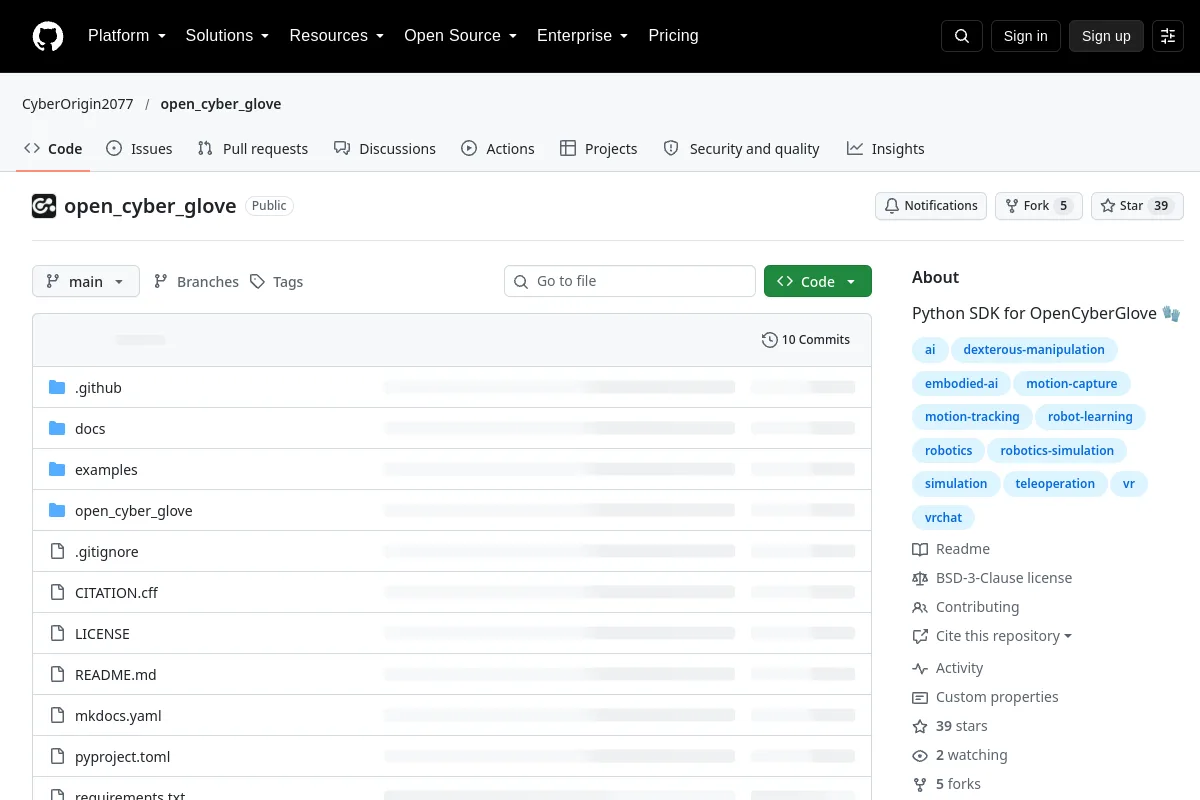 Repository
 Open source
Python SDK for the OpenCyberGlove data glove.
Teleoperation software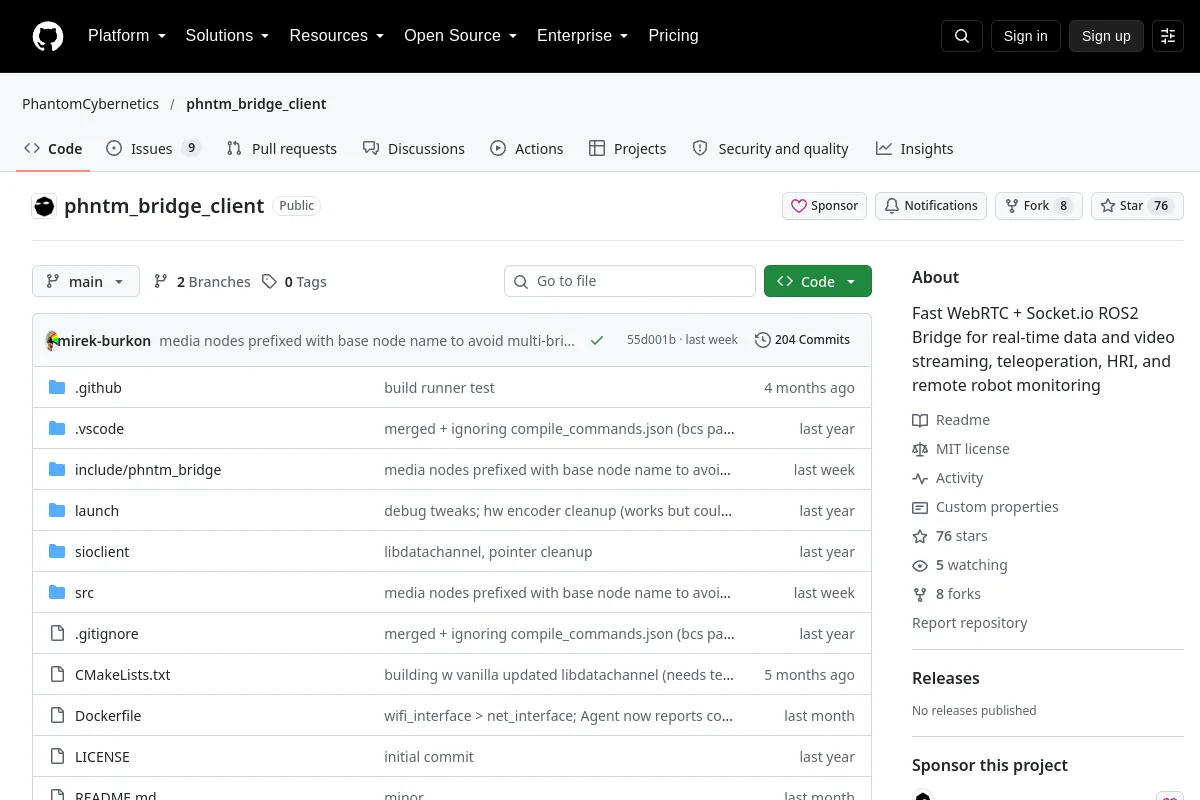 Repository
 Open source
ROS 2 bridge for live data, video streaming, teleoperation, and remote monitoring.
Teleoperation software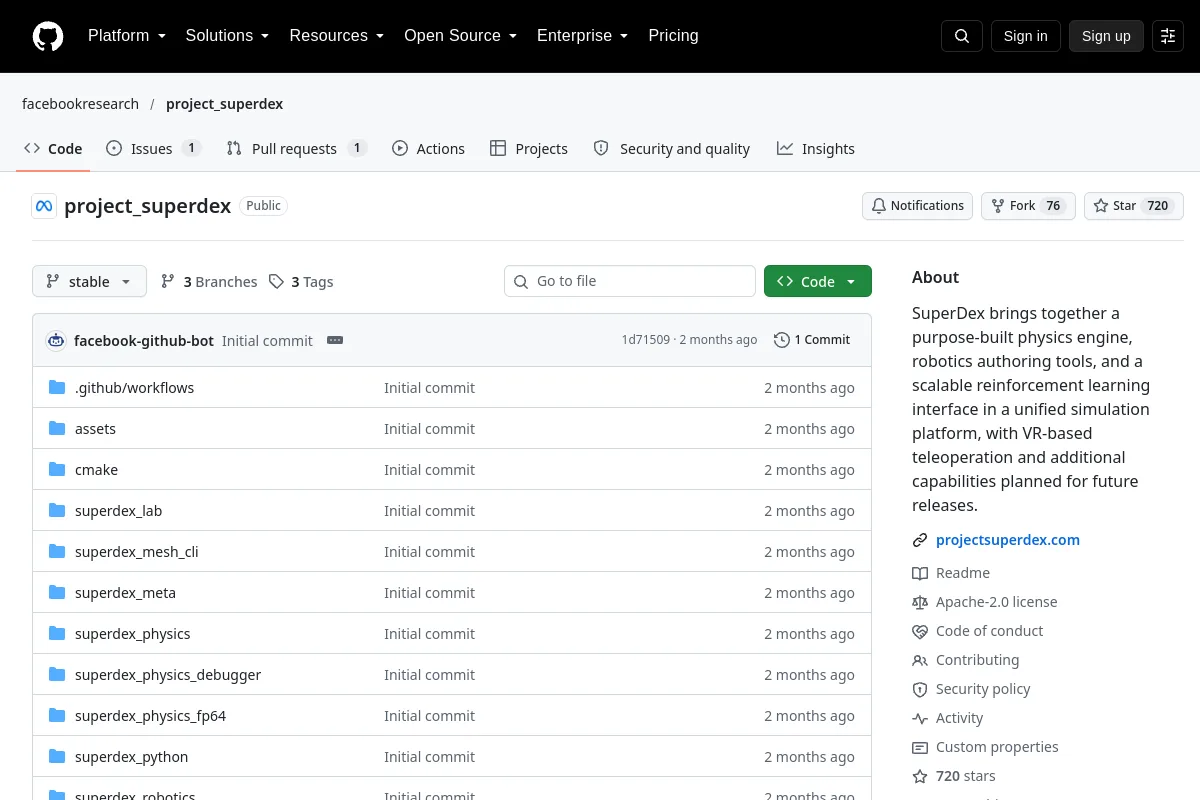 Repository
 Open source
SuperDex brings together a purpose-built physics engine, robotics authoring tools, and a scalable reinforcement learning interface in a unified simulation platform, with VR-based teleoperation and…
Teleoperation software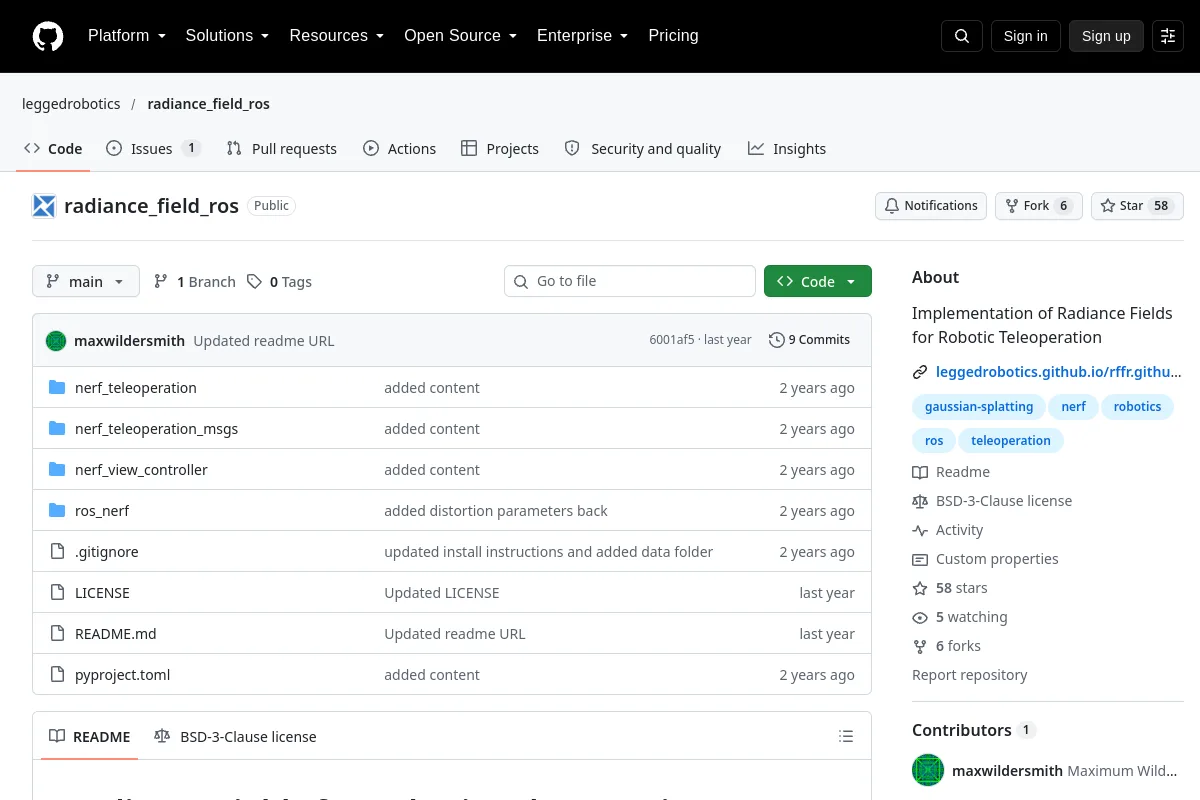 Repository
 Open source
Implementation of Radiance Fields for Robotic Teleoperation
Teleoperation software Repository
 Open source
A WeChat mini-program for remote robot fleet management and teleoperation.
Teleoperation software Repository
 Open source
Vision-based teleoperation project for the SO-ARM100 manipulator.
Teleoperation softwareSELECTION NOTES
Check latency, observation synchronization and supported control devices. Verify robot-side limits and emergency handling before connecting a teleoperation pipeline.
Know a resource that belongs here?