 Repository
Software / Open source
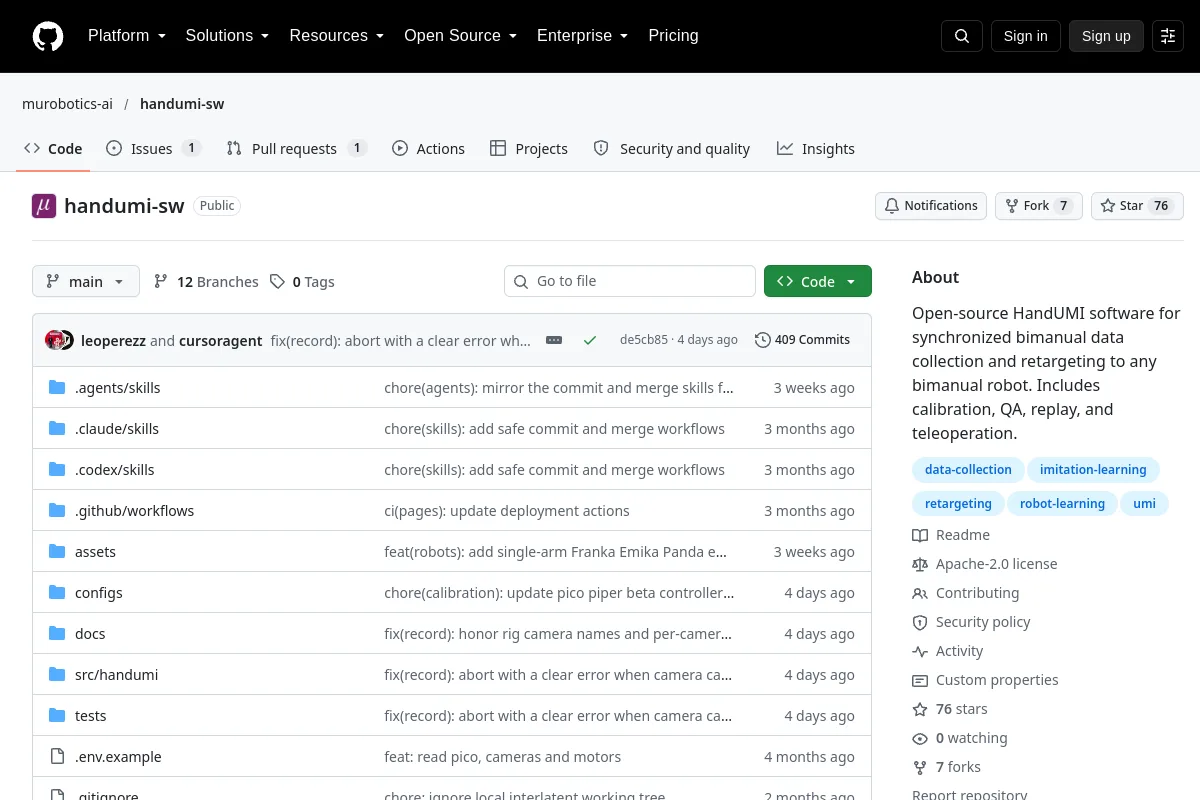
handumi-sw · murobotics-ai
Open-source HandUMI software for synchronized bimanual data collection and retargeting to any bimanual robot. Includes calibration, QA, replay, and teleoperation.
Overview
Open-source HandUMI software for synchronized bimanual data collection and retargeting to any bimanual robot. Includes calibration, QA, replay, and teleoperation.
Inspect installation instructions, supported versions, examples and interfaces in the source. This directory does not claim the software has been installed or tested on your robot.
Project information
- Maintainer
- murobotics-ai
- Primary language
- Python
- Repository code license
- Apache-2.0
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2026-10-07
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- HandUMI - Software
- Quick Start
- Install from GitHub
- Install from GitHub
- Core Workflow
- Supported Bimanual Embodiments
Browse this resource’s categories
Explore related collections
Browse Software →More in Software
Repository
 Repository
 Open source
handumi-hw · murobotics-ai
An open-source, hand-worn variant of UMI for collecting bimanual manipulation data without a robot in the loop: modular for any parallel-jaw gripper.
Teleoperation rigs