 Repository
Hardware / Open source
OpenArm · enactic
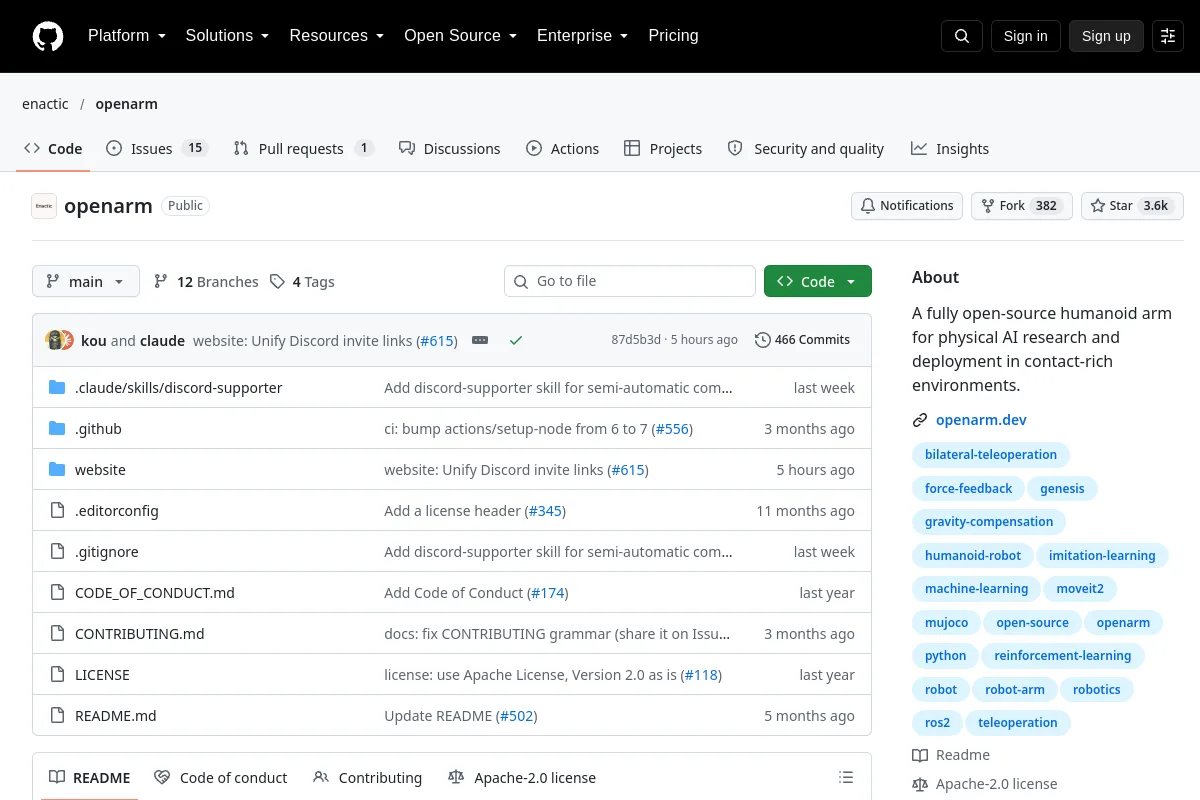
OpenArm humanoid-arm project for physical AI research.
Overview
OpenArm humanoid-arm project for physical AI research.
Publisher summary: “A fully open-source humanoid arm for physical AI research and deployment in contact-rich environments.”
Use its repository to inspect the implementation, documentation and supported workflows. This directory record identifies the maintainer, code license and related resources; it does not claim that the project has been installed or tested on your robot.
Project information
- Maintainer
- enactic
- Primary language
- MDX
- Repository code license
- Apache-2.0
- Model-weight license
- Not recorded
- Dataset license
- Not recorded
- Hardware design license
- Not recorded
- Maintenance
- Not archived in the last recorded metadata
- Last observed repository push
- 2026-10-07
Code licenses do not automatically cover model weights, datasets or hardware designs. Unrecorded license details require confirmation with the publisher.
Documentation sections
- OpenArm
- 🔗 Quick Links
- 📁 Repositories
- 📄 Code of Conduct
Browse this resource’s categories
Explore related collections
Robot arms for learning ↗More in Hardware
Repository
 Repository
 Open source
OpenCatEsp32-Quadruped-Robot · PetoiCamp
An ESP32-based open source quadruped robot pet framework for developing Boston Dynamics-style four-legged robots that are perfect for STEM, coding & robotics education, IoT robotics applications…
DIY & education hardware Repository
 Open source
OpenCat-Quadruped-Robot · PetoiCamp
An open source quadruped robot pet framework for developing Boston Dynamics-style four-legged robots that are perfect for STEM, coding & robotics education, IoT robotics applications, AI-enhanced…
DIY & education hardware Repository
 Open source
popi_project · popi-mkx3
Here is everything you need to know about POPI, our open-source quadruped robot. If you want to check the videos we will release about it, you can have a look at our YouTube channel.
DIY & education hardware Repository
 Research
OpenCat-Old · PetoiCamp
Historical reference: A programmable and highly maneuverable robotic cat for STEM education and AI-enhanced services.
DIY & education hardware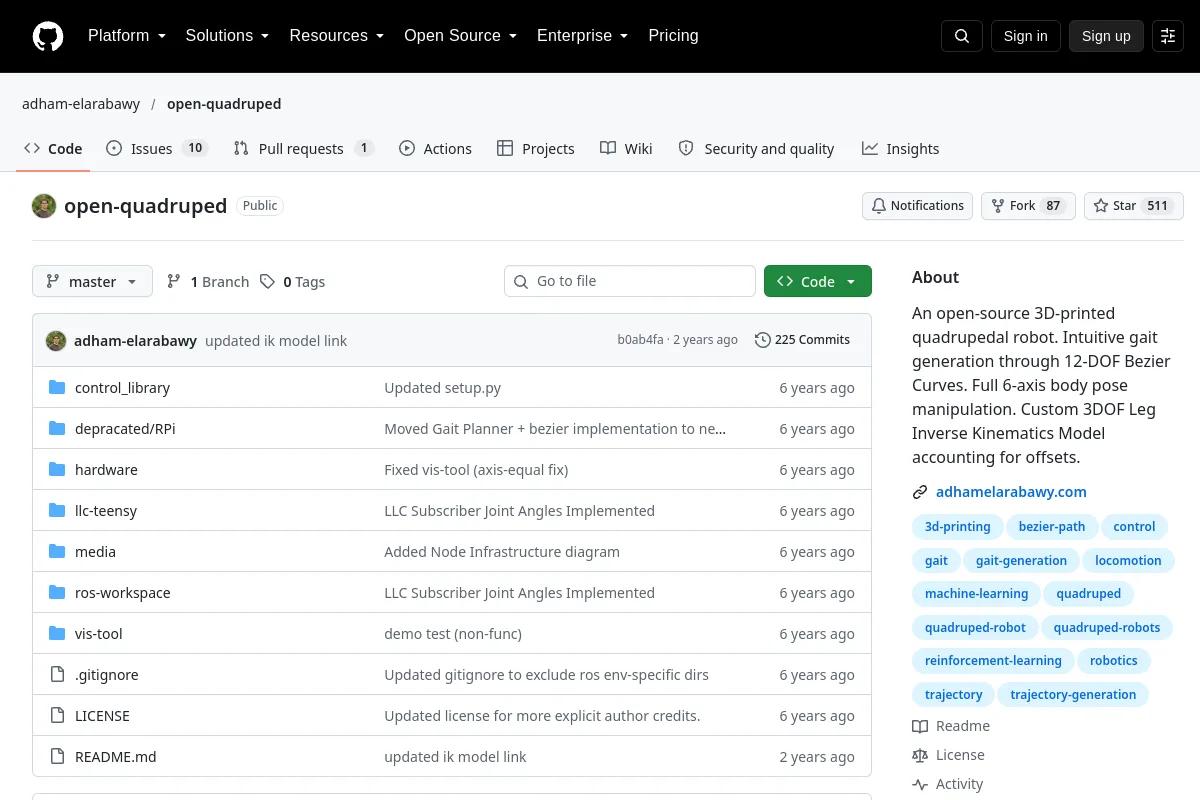 Repository
 Research
open quadruped · adham-elarabawy
open-quadruped is a 3D-printed quadrupedal robot project with gait generation and body-pose control.
DIY & education hardware